- Updated type hints across multiple files to replace `Optional[X]` with `X | None` for better readability and consistency.
- Added `from __future__ import annotations` to files to enable postponed evaluation of type annotations.
- Adjusted function signatures and variable types in various modules including `polygon_zone.py`, `smoother.py`, `transformers.py`, `vlm.py`, and others.
- Ensured compatibility with Python 3.10+ type hinting features.
Signed-off-by: Onuralp SEZER <thunderbirdtr@gmail.com>
- Removed specific version constraint for `supervision` package in installation command.
- Updated references from `sv.BoundingBoxAnnotator` to `sv.BoxAnnotator` for consistency with the latest library changes.
- Removed asset extension of package installation because it is has been included into main package
Signed-off-by: Onuralp SEZER <thunderbirdtr@gmail.com>
- ensures labels are within frame
- May have a few overlaps at edges,in very busy frames, when smart_pos is enabled. but running smart_pos first yields better results
- Added the `match_metric` parameter to the `with_nms` and `with_nmm` methods in the `Detections` class.
- Modified the `box_non_max_suppression` and `box_non_max_merge` functions to support IOS calculation.
- Introduced the `mask_non_max_merge` function for handling non-maximum merging of masks.
- Updated the `box_iou_batch` and `mask_iou_batch` functions to support both IOU and IOS calculations.
- Enhanced the `InferenceSlicer` class to accommodate the IOS matching metric.
Notes
- IOS (Intersection over Smaller): A variation of IOU that compares intersection over the smaller area, useful in scenarios with varying object sizes.
- Refinements: Improved terminology for clarity and consistency, ensuring technical accuracy.
- Added the `match_metric` parameter to the `with_nms` and `with_nmm` methods in the `Detections` class.
- Modified the `box_non_max_suppression` and `box_non_max_merge` functions to support IOS calculation.
- Introduced the `mask_non_max_merge` function for handling non-maximum merging of masks.
- Updated the `box_iou_batch` and `mask_iou_batch` functions to support both IOU and IOS calculations.
- Enhanced the `InferenceSlicer` class to accommodate the IOS matching metric.
### Notes
- IOS (Intersection over Smaller): A variation of IOU that compares intersection over the smaller area, useful in scenarios with varying object sizes.
- Refinements: Improved terminology for clarity and consistency, ensuring technical accuracy.
* Up to 20 tabs can be made at once. This is likely a bug relating to the underlying mkdocs plugin, but a quick check for hardcoded values yielded nothing.
Specified that mask is in bool datatype. Used int8 (gpt generated code) and was debugging this issue for 3 hours until I looked into source code of mask annotator
* External IDs were counted as the numbers grow very large very fast
* Reworked ID counting as a class, as state is necessary, and only STracks know if an external ID is required after the update (see conditions everywhere before self.external_id_counter.new_id() is called).
Replace `YOUR_USERNAME` with your GitHub username.
> Note: Using `--depth 1` creates a shallow clone with minimal history and `-b develop` ensures you start with the development branch. This significantly reduces download size while providing everything needed to contribute.
**Option B: Full repository clone (if you need complete history):**
@@ -181,7 +181,7 @@ Furthermore, we have integrated a pre-commit GitHub Action into our workflow. Th
To run the pre-commit tool, follow these steps:
1. Install pre-commit by running the following command: `poetry install --with dev`. It will not only install pre-commit but also install all the deps and dev-deps of project
1. Install pre-commit by running the following command: `uv pip install -r pyproject.toml --extra dev`. It will not only install pre-commit but also install all the deps and dev-deps of project
2. Once pre-commit is installed, navigate to the project's root directory.
@@ -203,7 +203,7 @@ So far, **there is no type checking with mypy**. See [issue](https://github.com/
The `supervision` documentation is stored in a folder called `docs`. The project documentation is built using `mkdocs`.
To run the documentation, install the project requirements with `poetry install --with dev`. Then, run `mkdocs serve` to start the documentation server.
To run the documentation, install the project requirements with `uv pip install -r pyproject.toml --extra dev --extra docs`. Then, run `mkdocs serve` to start the documentation server.
You can learn more about mkdocs on the [mkdocs website](https://www.mkdocs.org/).
**We write your reusable computer vision tools.** Whether you need to load your dataset from your hard drive, draw detections on an image or video, or count how many detections are in a zone. You can count on us! 🤝
- Fixed [1894](https://github.com/roboflow/supervision/pull/1894): Error in [`sv.MeanAveragePrecision`](https://supervision.roboflow.com/0.26.1/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision) where the area used for size-specific evaluation (small / medium / large) was always zero unless explicitly provided in `sv.Detections.data`.
- Fixed [1895](https://github.com/roboflow/supervision/pull/1895): `ID=0` bug in [`sv.MeanAveragePrecision`](https://supervision.roboflow.com/0.26.1/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision) where objects were getting `0.0` mAP despite perfect IoU matches due to a bug in annotation ID assignment.
- Fixed [1898](https://github.com/roboflow/supervision/pull/1898): Issue where [`sv.MeanAveragePrecision`](https://supervision.roboflow.com/0.26.1/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision) could return negative values when certain object size categories have no data.
- Fixed [1901](https://github.com/roboflow/supervision/pull/1901): `match_metric` support for [`sv.Detections.with_nms`](https://supervision.roboflow.com/0.26.1/metrics/mean_average_precision/#supervision.detection.core.Detections.with_nms).
- Fixed [1906](https://github.com/roboflow/supervision/pull/1906): `border_thickness` parameter usage for [`sv.PercentageBarAnnotator`](https://supervision.roboflow.com/0.26.1/metrics/mean_average_precision/#supervision.annotators.core.PercentageBarAnnotator).
### 0.26.0 <small>Jul 16, 2025</small>
!!! failure "Removed"
`supervision-0.26.0` drops `python3.8` support and upgrade all codes to `python3.9` syntax style.
!!! info "Tip"
Supervision’s documentation theme now has a fresh look that is consistent with the documentations of all Roboflow open-source projects. ([#1858](https://github.com/roboflow/supervision/pull/1858))
- Added [#1774](https://github.com/roboflow/supervision/pull/1774): Support for the IOS (Intersection over Smallest) overlap metric that measures how much of the smaller object is covered by the larger one in [`sv.Detections.with_nms`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.with_nms), [`sv.Detections.with_nmm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.with_nmm), [`sv.box_iou_batch`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.box_iou_batch), and [`sv.mask_iou_batch`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.mask_iou_batch).
```python
import numpy as np
import supervision as sv
boxes_true = np.array([
[100, 100, 200, 200],
[300, 300, 400, 400]
])
boxes_detection = np.array([
[150, 150, 250, 250],
[320, 320, 420, 420]
])
sv.box_iou_batch(
boxes_true=boxes_true,
boxes_detection=boxes_detection,
overlap_metric=sv.OverlapMetric.IOU
)
# array([[0.14285714, 0. ],
# [0. , 0.47058824]])
sv.box_iou_batch(
boxes_true=boxes_true,
boxes_detection=boxes_detection,
overlap_metric=sv.OverlapMetric.IOS
)
# array([[0.25, 0. ],
# [0. , 0.64]])
```
- Added [#1874](https://github.com/roboflow/supervision/pull/1874): [`sv.box_iou`](https://supervision.roboflow.com/0.26.0/detection/utils/iou_and_nms/#supervision.detection.utils.iou_and_nms.box_iou) that efficiently computes the Intersection over Union (IoU) between two individual bounding boxes.
- Added [#1816](https://github.com/roboflow/supervision/pull/1816): Support for frame limitations and progress bar in [`sv.process_video`](https://supervision.roboflow.com/0.26.0/utils/video/#supervision.utils.video.process_video).
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): Support for creating [`sv.KeyPoints`](https://supervision.roboflow.com/0.26.0/keypoint/core/#supervision.keypoint.core.KeyPoints) objects from [ViTPose](https://huggingface.co/docs/transformers/en/model_doc/vitpose) and [ViTPose++](https://huggingface.co/docs/transformers/en/model_doc/vitpose#vitpose-models) inference results via [`sv.KeyPoints.from_transformers`](https://supervision.roboflow.com/0.26.0/keypoint/core/#supervision.keypoint.core.KeyPoints.from_transformers).
- Added [#1823](https://github.com/roboflow/supervision/pull/1823): [`sv.xyxy_to_xcycarh`](https://supervision.roboflow.com/0.26.0/detection/utils/converters/#supervision.detection.utils.converters.xyxy_to_xcycarh) function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` into measurement space to format `(center x, center y, aspect ratio, height)`, where the aspect ratio is `width / height`.
- Added [#1788](https://github.com/roboflow/supervision/pull/1788): [`sv.xyxy_to_xywh`](https://supervision.roboflow.com/0.26.0/detection/utils/converters/#supervision.detection.utils.converters.xyxy_to_xywh) function to convert bounding box coordinates from `(x_min, y_min, x_max, y_max)` format to `(x, y, width, height)` format.
- Changed [#1820](https://github.com/roboflow/supervision/pull/1820): [`sv.LabelAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.LabelAnnotator) now supports the `smart_position` parameter to automatically keep labels within frame boundaries, and the `max_line_length` parameter to control text wrapping for long or multi-line labels.
- Changed [#1825](https://github.com/roboflow/supervision/pull/1825): [`sv.LabelAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.LabelAnnotator) now supports non-string labels.
- Changed [#1792](https://github.com/roboflow/supervision/pull/1792): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes and segmentation masks from responses generated by [Google Gemini models](https://ai.google.dev/gemini-api/docs/vision).
- Changed [#1878](https://github.com/roboflow/supervision/pull/1878): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes from responses generated by [Moondream](https://github.com/vikhyat/moondream).
```python
import supervision as sv
moondream_result = {
'objects': [
{
'x_min': 0.5704046934843063,
'y_min': 0.20069346576929092,
'x_max': 0.7049859315156937,
'y_max': 0.3012596592307091
},
{
'x_min': 0.6210969910025597,
'y_min': 0.3300672620534897,
'x_max': 0.8417936339974403,
'y_max': 0.4961046129465103
}
]
}
detections = sv.Detections.from_vlm(
sv.VLM.MOONDREAM,
moondream_result,
resolution_wh=(1000, 1000),
)
detections.xyxy
# array([[1752.28, 818.82, 2165.72, 1229.14],
# [1908.01, 1346.67, 2585.99, 2024.11]])
```
- Changed [#1709](https://github.com/roboflow/supervision/pull/1790): [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) now supports parsing bounding boxes from responses generated by [Qwen-2.5 VL](https://github.com/QwenLM/Qwen2.5-VL).
- Changed [#1786](https://github.com/roboflow/supervision/pull/1786): Significantly improved the speed of HSV color mapping in [`sv.HeatMapAnnotator`](https://supervision.roboflow.com/0.26.0/detection/annotators/#supervision.annotators.core.HeatMapAnnotator), achieving approximately 28x faster performance on 1920x1080 frames.
- Fixed [#1834](https://github.com/roboflow/supervision/pull/1834): Supervision’s [`sv.MeanAveragePrecision`](https://supervision.roboflow.com/0.26.0/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision) is now fully aligned with [pycocotools](https://github.com/ppwwyyxx/cocoapi), the official COCO evaluation tool, ensuring accurate and standardized metrics. This update enabled us to launch a new version of the [Computer Vision Model Leaderboard](https://leaderboard.roboflow.com/).
```python
import supervision as sv
from supervision.metrics import MeanAveragePrecision
predictions = sv.Detections(...)
targets = sv.Detections(...)
map_metric = MeanAveragePrecision()
map_metric.update(predictions, targets).compute()
# Average Precision (AP) @[ IoU=0.50:0.95 | area= all | maxDets=100 ] = 0.464
# Average Precision (AP) @[ IoU=0.50 | area= all | maxDets=100 ] = 0.637
# Average Precision (AP) @[ IoU=0.75 | area= all | maxDets=100 ] = 0.203
# Average Precision (AP) @[ IoU=0.50:0.95 | area= small | maxDets=100 ] = 0.284
# Average Precision (AP) @[ IoU=0.50:0.95 | area= large | maxDets=100 ] = 0.629
```
- Fixed [#1767](https://github.com/roboflow/supervision/pull/1767): Fixed losing `sv.Detections.data` when detections filtering.
### 0.25.0 <small>Nov 12, 2024</small>
- No removals or deprecations in this release!
- Essential update to the [`LineZone`](https://supervision.roboflow.com/0.25.0/detection/tools/line_zone/): when computing line crossings, detections that jitter might be counted twice (or more). This can now be solved with the `minimum_crossing_threshold` argument. If you set it to `2` or more, extra frames will be used to confirm the crossing, improving the accuracy significantly. ([#1540](https://github.com/roboflow/supervision/pull/1540))
- It is now possible to track objects detected as [`KeyPoints`](https://supervision.roboflow.com/0.25.0/keypoint/core/#supervision.keypoint.core.KeyPoints). See the complete step-by-step guide in the [Object Tracking Guide](https://supervision.roboflow.com/latest/how_to/track_objects/#keypoints). ([#1658](https://github.com/roboflow/supervision/pull/1658))
- Added `is_empty` method to [`KeyPoints`](https://supervision.roboflow.com/0.25.0/keypoint/core/#supervision.keypoint.core.KeyPoints) to check if there are any keypoints in the object. ([#1658](https://github.com/roboflow/supervision/pull/1658))
- Added `as_detections` method to [`KeyPoints`](https://supervision.roboflow.com/0.25.0/keypoint/core/#supervision.keypoint.core.KeyPoints) that converts `KeyPoints` to `Detections`. ([#1658](https://github.com/roboflow/supervision/pull/1658))
- Added a new video to `supervision[assets]`. ([#1657](https://github.com/roboflow/supervision/pull/1657))
```python
from supervision.assets import download_assets, VideoAssets
- Supervision can now be used with [`Python 3.13`](https://docs.python.org/3/whatsnew/3.13.html). The most renowned update is the ability to run Python [without Global Interpreter Lock (GIL)](https://docs.python.org/3/whatsnew/3.13.html#whatsnew313-free-threaded-cpython). We expect support for this among our dependencies to be inconsistent, but if you do attempt it - let us know the results! ([#1595](https://github.com/roboflow/supervision/pull/1595))
- Added [`Mean Average Recall`](https://supervision.roboflow.com/latest/metrics/mean_average_recall/) mAR metric, which returns a recall score, averaged over IoU thresholds, detected object classes, and limits imposed on maximum considered detections. ([#1661](https://github.com/roboflow/supervision/pull/1661))
- Added [`Precision`](https://supervision.roboflow.com/latest/metrics/precision/) and [`Recall`](https://supervision.roboflow.com/latest/metrics/recall/) metrics, providing a baseline for comparing model outputs to ground truth or another model ([#1609](https://github.com/roboflow/supervision/pull/1609))
- Introducing Smart Labels! When `smart_position` is set for [`LabelAnnotator`](https://supervision.roboflow.com/0.25.0/detection/annotators/#supervision.annotators.core.LabelAnnotator), [`RichLabelAnnotator`](https://supervision.roboflow.com/0.25.0/detection/annotators/#supervision.annotators.core.RichLabelAnnotator) or [`VertexLabelAnnotator`](https://supervision.roboflow.com/0.25.0/detection/annotators/#supervision.annotators.core.RichLabelAnnotator), the labels will move around to avoid overlapping others. ([#1625](https://github.com/roboflow/supervision/pull/1625))
- Added the `metadata` variable to [`Detections`](https://supervision.roboflow.com/0.25.0/detection/core/#supervision.detection.core.Detections). It allows you to store custom data per-image, rather than per-detected-object as was possible with `data` variable. For example, `metadata` could be used to store the source video path, camera model or camera parameters. ([#1589](https://github.com/roboflow/supervision/pull/1589))
- Added a `py.typed` type hints metafile. It should provide a stronger signal to type annotators and IDEs that type support is available. ([#1586](https://github.com/roboflow/supervision/pull/1586))
- `ByteTrack` no longer requires `detections` to have a `class_id` ([#1637](https://github.com/roboflow/supervision/pull/1637))
- `draw_line`, `draw_rectangle`, `draw_filled_rectangle`, `draw_polygon`, `draw_filled_polygon` and `PolygonZoneAnnotator` now comes with a default color ([#1591](https://github.com/roboflow/supervision/pull/1591))
- Dataset classes are treated as case-sensitive when merging multiple datasets. ([#1643](https://github.com/roboflow/supervision/pull/1643))
- Expanded [metrics documentation](https://supervision.roboflow.com/0.25.0/metrics/f1_score/) with example plots and printed results ([#1660](https://github.com/roboflow/supervision/pull/1660))
- Added usage example for polygon zone ([#1608](https://github.com/roboflow/supervision/pull/1608))
- Small improvements to error handling in polygons: ([#1602](https://github.com/roboflow/supervision/pull/1602))
- Updated [`ByteTrack`](https://supervision.roboflow.com/0.25.0/trackers/#supervision.tracker.byte_tracker.core.ByteTrack), removing shared variables. Previously, multiple instances of `ByteTrack` would share some date, requiring liberal use of `tracker.reset()`. ([#1603](https://github.com/roboflow/supervision/pull/1603)), ([#1528](https://github.com/roboflow/supervision/pull/1528))
- Fixed a bug where `class_agnostic` setting in `MeanAveragePrecision` would not work. ([#1577](https://github.com/roboflow/supervision/pull/1577)) hacktoberfest
- Removed welcome workflow from our CI system. ([#1596](https://github.com/roboflow/supervision/pull/1596))
- Large refactor of `ByteTrack`: STrack moved to separate class, removed superfluous `BaseTrack` class, removed unused variables ([#1603](https://github.com/roboflow/supervision/pull/1603))
- Large refactor of `RichLabelAnnotator`, matching its contents with `LabelAnnotator`. ([#1625](https://github.com/roboflow/supervision/pull/1625))
- Changed [#1434](https://github.com/roboflow/supervision/pull/1434): [`InferenceSlicer`](https://supervision.roboflow.com/0.23.0/detection/tools/inference_slicer/) now features an `overlap_wh` parameter, making it easier to compute slice sizes when handling overlapping slices.
- Fix [#1448](https://github.com/roboflow/supervision/pull/1448): Various annotator type issues have been resolved, supporting expanded error handling.
- Fixed [#1448](https://github.com/roboflow/supervision/pull/1448): Various annotator type issues have been resolved, supporting expanded error handling.
- Fix [#1348](https://github.com/roboflow/supervision/pull/1348): Introduced a new method for [seeking to a specific video frame](https://supervision.roboflow.com/0.23.0/utils/video/#supervision.utils.video.get_video_frames_generator), addressing cases where traditional seek methods were failing. It can be enabled with `iterative_seek=True`.
- Fixed [#1348](https://github.com/roboflow/supervision/pull/1348): Introduced a new method for [seeking to a specific video frame](https://supervision.roboflow.com/0.23.0/utils/video/#supervision.utils.video.get_video_frames_generator), addressing cases where traditional seek methods were failing. It can be enabled with `iterative_seek=True`.
```python
import supervision as sv
@@ -253,7 +584,7 @@ for frame in sv.get_video_frames_generator(
...
```
- Fix [#1424](https://github.com/roboflow/supervision/pull/1424): `plot_image` function now clearly indicates that the size is in inches.
- Fixed [#1424](https://github.com/roboflow/supervision/pull/1424): `plot_image` function now clearly indicates that the size is in inches.
!!! failure "Removed"
@@ -966,7 +1297,7 @@ array([
### 0.11.1 <small>June 29, 2023</small>
- Fix [#165](https://github.com/roboflow/supervision/pull/165): [`as_folder_structure`](/0.11.1/dataset/core/#supervision.dataset.core.ClassificationDataset.as_folder_structure) fails to save [`sv.ClassificationDataset`](/0.11.1/dataset/core/#classificationdataset) when it is result of inference.
- Fixed [#165](https://github.com/roboflow/supervision/pull/165): [`as_folder_structure`](/0.11.1/dataset/core/#supervision.dataset.core.ClassificationDataset.as_folder_structure) fails to save [`sv.ClassificationDataset`](/0.11.1/dataset/core/#classificationdataset) when it is result of inference.
### 0.11.0 <small>June 28, 2023</small>
@@ -1012,7 +1343,7 @@ array([
- Added [#162](https://github.com/roboflow/supervision/pull/162): additional `start` and `end` arguments to [`sv.get_video_frames_generator`](/0.11.0/utils/video/#get_video_frames_generator) allowing to generate frames only for a selected part of the video.
- Fix [#157](https://github.com/roboflow/supervision/pull/157): incorrect loading of YOLO dataset class names from `data.yaml`.
- Fixed [#157](https://github.com/roboflow/supervision/pull/157): incorrect loading of YOLO dataset class names from `data.yaml`.
These features are phased out due to better alternatives or potential issues in future versions. Deprecated functionalities are supported for **five subsequent releases**, providing time for users to transition to updated methods.
- Constructing [`DetectionDataset`](https://supervision.roboflow.com/latest/datasets/core/#supervision.dataset.core.DetectionDataset) and [`ClassificationDataset`](https://supervision.roboflow.com/latest/datasets/core/#supervision.dataset.core.ClassificationDataset) with parameter `images` as `Dict[str, np.ndarray]` will be removed in `supervision-0.26.0`. Please pass a list of paths `List[str]` instead.
- The `DetectionDataset.images` property will be removed in `supervision-0.26.0`. Please loop over images with `for path, image, annotation in dataset:`, as that does not require loading all images into memory.
-`BoundingBoxAnnotator` has been renamed to `BoxAnnotator` after the old implementation of [`BoxAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.BoxAnnotator) has been removed. `BoundingBoxAnnotator` will be removed in `supervision-0.26.0`.
-`overlap_filter_strategy` in [`InferenceSlicer.__init__`](https://supervision.roboflow.com/latest/detection/tools/inference_slicer/) is deprecated and will be removed in `supervision-0.27.0`. Use `overlap_strategy` instead.
-`overlap_ratio_wh` in [`InferenceSlicer.__init__`](https://supervision.roboflow.com/latest/detection/tools/inference_slicer/) is deprecated and will be removed in `supervision-0.27.0`. Use `overlap_wh` instead.
-`sv.LMM` enum is deprecated and will be removed in `supervision-0.31.0`. Use `sv.VLM` instead.
- [`sv.Detections.from_lmm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_lmm) property is deprecated and will be removed in `supervision-0.31.0`. Use [`sv.Detections.from_vlm`](https://supervision.roboflow.com/0.26.0/detection/core/#supervision.detection.core.Detections.from_vlm) instead.
# Removed
### 0.26.0
- The `sv.DetectionDataset.images` property has been removed in `supervision-0.26.0`. Please loop over images with `for path, image, annotation in dataset:`, as that does not require loading all images into memory. Also, constructing `sv.DetectionDataset` with parameter `images` as `Dict[str, np.ndarray]` is deprecated and has been removed in `supervision-0.26.0`. Please pass a list of paths `List[str]` instead.
- The name `sv.BoundingBoxAnnotator` is deprecated and has been removed in `supervision-0.26.0`. It has been renamed to [`sv.BoxAnnotator`](https://supervision.roboflow.com/0.22.0/detection/annotators/#supervision.annotators.core.BoxAnnotator).
### 0.24.0
- The `frame_resolution_wh ` parameter in [`sv.PolygonZone`](detection/tools/polygon_zone.md/#supervision.detection.tools.polygon_zone.PolygonZone) has been removed.
@@ -31,12 +33,12 @@ These features are phased out due to better alternatives or potential issues in
### 0.22.0
-`Detections.from_roboflow` is removed as of `supervision-0.22.0`. Use [`Detections.from_inference`](detection/core.md/#supervision.detection.core.Detections.from_inference) instead.
- The method `Color.white()` was removed as of `supervision-0.22.0`. Use the constant `Color.WHITE` instead.
- The method `Color.black()` was removed as of `supervision-0.22.0`. Use the constant `Color.BLACK` instead.
- The method `Color.red()` was removed as of `supervision-0.22.0`. Use the constant `Color.RED` instead.
- The method `Color.green()` was removed as of `supervision-0.22.0`. Use the constant `Color.GREEN` instead.
- The method `Color.blue()` was removed as of `supervision-0.22.0`. Use the constant `Color.BLUE` instead.
- The method `ColorPalette.default()` was removed as of `supervision-0.22.0`. Use the constant [`ColorPalette.DEFAULT`](/utils/draw/#supervision.draw.color.ColorPalette.DEFAULT) instead.
-`BoxAnnotator` was removed as of `supervision-0.22.0`, however `BoundingBoxAnnotator` was immediately renamed to `BoxAnnotator`. Use [`BoxAnnotator`](detection/annotators.md/#supervision.annotators.core.BoxAnnotator) and [`LabelAnnotator`](detection/annotators.md/#supervision.annotators.core.LabelAnnotator) instead of the old `BoxAnnotator`.
- The method `FPSMonitor.__call__` was removed as of `supervision-0.22.0`. Use the attribute [`FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
-`sv.Detections.from_roboflow` is removed as of `supervision-0.22.0`. Use [`Detections.from_inference`](detection/core.md/#supervision.detection.core.Detections.from_inference) instead.
- The method `sv.Color.white()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.WHITE` instead.
- The method `sv.Color.black()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.BLACK` instead.
- The method `sv.Color.red()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.RED` instead.
- The method `sv.Color.green()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.GREEN` instead.
- The method `sv.Color.blue()` was removed as of `supervision-0.22.0`. Use the constant `sv.Color.BLUE` instead.
- The method `sv.ColorPalette.default()` was removed as of `supervision-0.22.0`. Use the constant [`ColorPalette.DEFAULT`](/utils/draw/#supervision.draw.color.ColorPalette.DEFAULT) instead.
-`sv.BoxAnnotator` was removed as of `supervision-0.22.0`, however `sv.BoundingBoxAnnotator` was immediately renamed to `sv.BoxAnnotator`. Use [`BoxAnnotator`](detection/annotators.md/#supervision.annotators.core.BoxAnnotator) and [`LabelAnnotator`](detection/annotators.md/#supervision.annotators.core.LabelAnnotator) instead of the old `sv.BoxAnnotator`.
- The method `sv.FPSMonitor.__call__` was removed as of `supervision-0.22.0`. Use the attribute [`sv.FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
Have you ever trained multiple detection models and wondered which one performs best on your specific use case? Or maybe you've downloaded a pre-trained model and want to verify its performance on your dataset? Model benchmarking is essential for making informed decisions about which model to deploy in production.
This guide will show an easy way to benchmark your results using `supervision`. It will go over:
1. [Loading a dataset](#loading-a-dataset)
2. [Loading a model](#loading-a-model)
3. [Benchmarking Basics](#benchmarking-basics)
4. [Running a Model](#running-a-model)
5. [Remapping Classes](#remapping-classes)
6. [Visual Benchmarking](#visual-benchmarking)
7. [Benchmarking Metrics](#benchmarking-metrics)
8. [Mean Average Precision (mAP)](#mean-average-precision-map)
9. [F1 Score](#f1-score)
10. [Bonus: Model Leaderboard](#model-leaderboard)
This guide will use an instance segmentation model, but it applies to object detection, instance segmentation, and oriented bounding box models (OBB) too.
A condensed version of this guide is available as a [Colab Notebook](https://colab.research.google.com/drive/1HoOY9pZoVwGiRMmLHtir0qT6Uj45w6Ps?usp=sharing).
## Loading a Dataset
Suppose you start with a dataset. Perhaps you found it on [Universe](https://universe.roboflow.com/); perhaps you [labeled your own](https://roboflow.com/how-to-label/yolo11). In either case, this guide assumes you know of a labelled dataset at hand.
We'll use the following libraries:
-`roboflow` to manage the dataset and deploy models
If your dataset is from Universe, go to `Dataset` > `Download Dataset` > select the format (e.g. `YOLOv11`) > `Show download code`.
If labeling your own data, go to the [dashboard](https://app.roboflow.com/) and check this [guide](https://docs.roboflow.com/api-reference/workspace-and-project-ids) to find your workspace and project IDs.
In this guide, we shall use a small [Corgi v2](https://universe.roboflow.com/model-examples/segmented-animals-basic) dataset. It is well-labeled and comes with a test set.
This will create a folder called `Corgi-v2-4` with the dataset in the current working directory, with `train`, `test`, and `valid` folders and a `data.yaml` file.
## Loading a Model
Let's load a model.
=== "Inference, Local"
Roboflow supports a range of state-of-the-art [pre-trained models](https://inference.roboflow.com/quickstart/aliases/) for object detection, instance segmentation, and pose tracking. You don't even need an API key!
Let's load such a model with inference [`inference`](https://inference.roboflow.com/).
```python
from inference import get_model
model = get_model(model_id="yolov11s-seg-640")
```
=== "Inference, Deployed"
You can train and deploy a model without leaving the Roboflow platform. See this [guide](https://docs.roboflow.com/train/train/train-from-scratch) for more details.
To load a model, you can use inference:
```python
from inference import get_model
model_id = "<PROJECT_NAME>/<MODEL_VERSION>"
model = get_model(model_id=model_id)
```
=== "Ultralytics"
Similarly to Inference, Ultralytics allows you to run a variety of models.
```bash
pip install "ultralytics<=8.3.40"
```
```python
from ultralytics import YOLO
model = YOLO("yolo11s-seg.pt")
```
## Benchmarking Basics
Evaluating your model requires careful selection of the dataset. Which images should you use?Let's go over the different scenarios.
- **Unrelated Dataset**: If you have a dataset that was not used to train the model, this is the best choice.
- **Training Set**: This is the set of images used to train the model. This is fine if the model was not trained on this dataset. Otherwise, **never** use it for benchmarking - the results will seem unrealistically good.
- **Validation Set**: This is the set of images used to validate the model during training. Every Nth training epoch, the model is evaluated on the validation set. Often the training is stopped once the validation loss stops improving. Therefore, even while the images aren't used to train the model, it still indirectly influences the training outcome.
- **Test Set**: This is the set of images kept aside for model testing. It is exactly the set you should use for benchmarking. If the dataset was split correctly, none of these images would be shown to the model during training.
Therefore, an unrelated dataset or the `test` set is the best choice for benchmarking.
Several other problems may arise:
- **Extra Classes**: An unrelated dataset may contain additional classes which you may need to [filter out](https://supervision.roboflow.com/how_to/filter_detections/#by-set-of-classes) before computing metrics.
- **Class Mismatch**: In an unrelated dataset, the class names or IDs may be different to what your model produces, you'll need to remap them, which is [shown in this guide](#running-a-model).
- **Data Contamination**: The `test` set may not be split correctly, with images from the test set also present in `training` or `validation` set and used during training. In this case, the results will be overly optimistic. This also applies when **very similar** images are used for training and testing - e.g. those taken in the same environment, same lighting conditions, similar angle, etc.
- **Missing Test Set**: Some datasets do not come with a test set. In this case, you should collect and [label](https://roboflow.com/annotate) your own data. Alternatively, a validation set could be used, but the results could be overly optimistic. Make sure to test in the real world as soon as possible.
## Running a Model
At this stage, you should have:
- A dataset of labeled images to evaluate the model.
- A model prepared for benchmarking.
With these ready, we can now run the model and obtain predictions.
We'll use `supervision` to create a dataset iterator, and then run the model on each image.
Dataset class names and IDs can be found in the `data.yaml` file, or by printing `dataset.classes`.
Each model will have a different class mapping, so make sure to check the model's documentation. In this case, the model was trained on the COCO dataset, with a class
configuration found [here](https://github.com/ultralytics/ultralytics/blob/main/ultralytics/cfg/datasets/coco8.yaml).
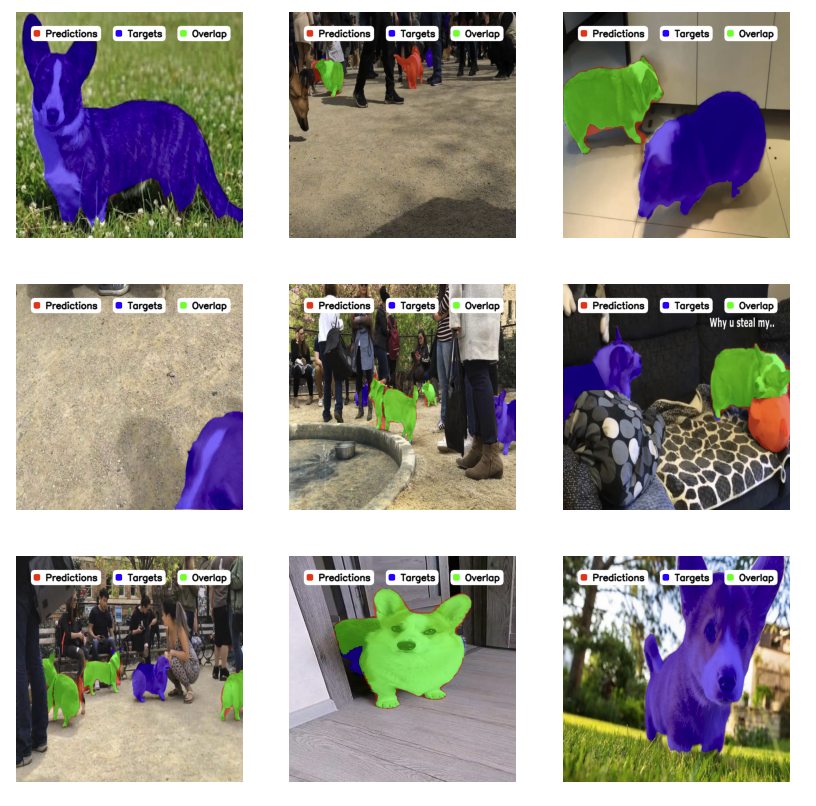
Here, predictions in purple are targets (ground truth), and predictions in teal are model predictions.
!!! tip
Use `sv.BoxAnnotator` for object detection and `sv.OrientedBoxAnnotator` for OBB.
See [annotator documentation](https://supervision.roboflow.com/latest/detection/annotators/) for even more options.
## Benchmarking Metrics
With multiple models, fine details matter. Visual inspection may not be enough. `supervision` provides a collection of metrics that help obtain precise numerical results of model performance.
### Mean Average Precision (mAP)
We'll start with [MeanAveragePrecision (mAP)](https://supervision.roboflow.com/latest/metrics/mean_average_precision/#supervision.metrics.mean_average_precision.MeanAveragePrecision), which is the most commonly used metric for object detection. It measures the average precision across all classes and IoU thresholds.
For a thorough explanation, check out our [blog](https://blog.roboflow.com/mean-average-precision/) and [Youtube video](https://www.youtube.com/watch?v=oqXDdxF_Wuw).
Here, the most popular value is `mAP 50:95`. It represents the average precision across all classes and IoU thresholds (`0.5` to `0.95`), whereas other values such as `mAP 50` or `mAP 75` only consider a single IoU threshold (`0.5` and `0.75` respectively).
Let's compute the mAP:
```python
from supervision.metrics import MeanAveragePrecision, MetricTarget
The metric also breaks down the results by detected object area. Small, medium and large are simply those with area less than 32², between 32² and 96², and greater than 96² pixels respectively.
### F1 Score
The [F1 Score](https://supervision.roboflow.com/latest/metrics/f1_score/) is another useful metric, especially when dealing with an imbalance between false positives and false negatives. It’s the harmonic mean of **precision** (how many predictions are correct) and **recall** (how many actual instances were detected).
Here's how you can compute the F1 score:
```python
from supervision.metrics import F1Score, MetricTarget
As with mAP, the metric also breaks down the results by detected object area. Small, medium and large are simply those with area less than 32², between 32² and 96², and greater than 96² pixels respectively.
## Model Leaderboard
Here to compare the basic models? We've got you covered. Check out our [Model Leaderboard](https://leaderboard.roboflow.com/) to see how different models perform and to get a sense of the state-of-the-art results. It's a great place to understand what the leading models can achieve and to compare your own results.
Even better, the repository is open source! You can see how the models were benchmarked, run the evaluation yourself, and even add your own models to the leaderboard. Check it out on [GitHub](https://github.com/roboflow/model-leaderboard)!
In this guide, you've learned how to set up your environment, train or use pre-trained models, visualize predictions, and evaluate model performance with metrics like [mAP](https://supervision.roboflow.com/latest/metrics/mean_average_precision/), [F1 score](https://supervision.roboflow.com/latest/metrics/f1_score/), and got to know our Model Leaderboard.
A condensed version of this guide is also available as a [Colab Notebook](https://colab.research.google.com/drive/1HoOY9pZoVwGiRMmLHtir0qT6Uj45w6Ps?usp=sharing).
For more details, be sure to check out our [documentation](https://supervision.roboflow.com/latest/) and join our community discussions. If you find any issues, please let us know on [GitHub](https://github.com/roboflow/supervision/issues).
This structured walkthrough should give a detailed pathway to annotate videos
effectively using Supervision’s various functionalities, including object tracking and
trace annotations.
## Keypoints
Models aren't limited to object detection and segmentation. Keypoint detection allows for detailed analysis of body joints and connections, especially valuable for applications like human pose estimation. This section introduces keypoint tracking. We'll walk through the steps of annotating keypoints, converting them into bounding box detections compatible with `ByteTrack`, and applying detection smoothing for enhanced stability.
To make it easier for you to follow our tutorial, let's download the video we will use as an
example. You can do this using [`supervision[assets]`](/latest/assets/) extension.
```python
from supervision.assets import download_assets, VideoAssets
First, you'll need to obtain predictions from your keypoint detection model. In this tutorial, we are using the YOLOv8 model as an example. However,
Supervision is versatile and compatible with various models. Check this [link](/latest/keypoint/core/) for guidance on how to plug in other models.
We will define a `callback` function, which will process each frame of the video by obtaining model predictions and then annotating the frame based on these predictions.
Let's immediately visualize the results with our [`EdgeAnnotator`](/latest/keypoint/annotators/#supervision.key_points.annotators.EdgeAnnotator) and [`VertexAnnotator`](https://supervision.roboflow.com/latest/keypoint/annotators/#supervision.key_points.annotators.VertexAnnotator).
Keypoint tracking is currently supported via the conversion of `KeyPoints` to `Detections`. This is achieved with the [`KeyPoints.as_detections()`](/latest/keypoint/core/#supervision.key_points.core.KeyPoints.as_detections) function.
Let's convert to detections and visualize the results with our [`BoxAnnotator`](/latest/detection/annotators/#supervision.annotators.core.BoxAnnotator).
!!! tip
You may use the `selected_keypoint_indices` argument to specify a subset of keypoints to convert. This is useful when some keypoints could be occluded. For example: a person might swing their arm, causing the elbow to be occluded by the torso sometimes.
Now that we have a `Detections` object, we can track it throughout the video. Utilizing Supervision’s [`sv.ByteTrack`](/latest/trackers/#supervision.tracker.byte_tracker.core.ByteTrack) functionality, each detected object is assigned a unique tracker ID, enabling the continuous following of the object's motion path across different frames. We shall visualize the result with `TraceAnnotator`.
We could stop here as we have successfully tracked the object detected by the keypoint model. However, we can further enhance the stability of the boxes by applying [`DetectionsSmoother`](/latest/detection/tools/smoother/). This tool helps in stabilizing the boxes by smoothing the bounding box coordinates across frames. It is very simple to use:
This structured walkthrough should give a detailed pathway to annotate videos effectively using Supervision’s various functionalities, including object tracking and trace annotations.
We write your reusable computer vision tools. Whether you need to load your dataset from your hard drive, draw detections on an image or video, or count how many detections are in a zone. You can count on us!
@@ -31,10 +37,11 @@ We write your reusable computer vision tools. Whether you need to load your data
!function(){vari="analytics",analytics=window[i]=window[i]||[];if(!analytics.initialize)if(analytics.invoked)window.console&&console.error&&console.error("Segment snippet included twice.");else{analytics.invoked=!0;analytics.methods=["trackSubmit","trackClick","trackLink","trackForm","pageview","identify","reset","group","track","ready","alias","debug","page","screen","once","off","on","addSourceMiddleware","addIntegrationMiddleware","setAnonymousId","addDestinationMiddleware","register"];analytics.factory=function(e){returnfunction(){if(window[i].initialized)returnwindow[i][e].apply(window[i],arguments);varn=Array.prototype.slice.call(arguments);if(["track","screen","alias","group","page","identify"].indexOf(e)>-1){varc=document.querySelector("link[rel='canonical']");n.push({__t:"bpc",c:c&&c.getAttribute("href")||void0,p:location.pathname,u:location.href,s:location.search,t:document.title,r:document.referrer})}n.unshift(e);analytics.push(n);returnanalytics}};for(varn=0;n<analytics.methods.length;n++){varkey=analytics.methods[n];analytics[key]=analytics.factory(key)}analytics.load=function(key,n){vart=document.createElement("script");t.type="text/javascript";t.async=!0;t.setAttribute("data-global-segment-analytics-key",i);t.src="https://cdn.segment.com/analytics.js/v1/"+key+"/analytics.min.js";varr=document.getElementsByTagName("script")[0];r.parentNode.insertBefore(t,r);analytics._loadOptions=n};analytics._writeKey="rMvrPeZBJYyOPJSGCNhMlnTJb8VhFiWU";;analytics.SNIPPET_VERSION="5.2.0";
"Finally, we can annotate the image with the predictions. Since we are working with an object detection model, we will use the [`sv.BoundingBoxAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.BoundingBoxAnnotator) and [`sv.LabelAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.LabelAnnotator) classes."
"Finally, we can annotate the image with the predictions. Since we are working with an object detection model, we will use the [`sv.BoxAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.BoxAnnotator) and [`sv.LabelAnnotator`](https://supervision.roboflow.com/latest/detection/annotators/#supervision.annotators.core.LabelAnnotator) classes."
"This cookbook shows how to use [Slicing Aided Hyper Inference (SAHI) ](https://arxiv.org/abs/2202.06934) for small object detection with `supervision`.\n",
"Click the Open in Colab button to run the cookbook on Google Colab.\n",
"\n",
@@ -70,7 +70,7 @@
"\n",
"Detecting people (or their heads) is a common problem that has been addressed by many researchers in the past. In this project, we\u2019ll use an open-source public dataset and a fine-tuned model to perform inference on images.\n",
"\n",
"\n",
"\n",
"\n",
"Some details about the project [\"people_counterv0 Computer Vision Project\"](https://universe.roboflow.com/sit-cx0ng/people_counterv0):\n",
@@ -118,3 +138,122 @@ from supervision.utils.video import (
get_video_frames_generator,
process_video,
)
__all__=[
"LMM",
"BackgroundOverlayAnnotator",
"BaseDataset",
"BlurAnnotator",
"BoxAnnotator",
"BoxCornerAnnotator",
"ByteTrack",
"CSVSink",
"CircleAnnotator",
"ClassificationDataset",
"Classifications",
"Color",
"ColorAnnotator",
"ColorLookup",
"ColorPalette",
"ComparisonAnnotator",
"ConfusionMatrix",
"CropAnnotator",
"DetectionDataset",
"Detections",
"DetectionsSmoother",
"DotAnnotator",
"EdgeAnnotator",
"EllipseAnnotator",
"FPSMonitor",
"HaloAnnotator",
"HeatMapAnnotator",
"IconAnnotator",
"ImageSink",
"InferenceSlicer",
"JSONSink",
"KeyPoints",
"LabelAnnotator",
"LineZone",
"LineZoneAnnotator",
"LineZoneAnnotatorMulticlass",
"MaskAnnotator",
"MeanAveragePrecision",
"OrientedBoxAnnotator",
"OverlapFilter",
"OverlapMetric",
"PercentageBarAnnotator",
"PixelateAnnotator",
"Point",
"PolygonAnnotator",
"PolygonZone",
"PolygonZoneAnnotator",
"Position",
"Rect",
"RichLabelAnnotator",
"RoundBoxAnnotator",
"TraceAnnotator",
"TriangleAnnotator",
"VertexAnnotator",
"VertexLabelAnnotator",
"VideoInfo",
"VideoSink",
"approximate_polygon",
"box_iou",
"box_iou_batch",
"box_iou_batch_with_jaccard",
"box_non_max_merge",
"box_non_max_suppression",
"calculate_masks_centroids",
"calculate_optimal_line_thickness",
"calculate_optimal_text_scale",
"clip_boxes",
"contains_holes",
"contains_multiple_segments",
"crop_image",
"cv2_to_pillow",
"draw_filled_polygon",
"draw_filled_rectangle",
"draw_image",
"draw_line",
"draw_polygon",
"draw_rectangle",
"draw_text",
"edit_distance",
"filter_polygons_by_area",
"filter_segments_by_distance",
"fuzzy_match_index",
"get_coco_class_index_mapping",
"get_polygon_center",
"get_video_frames_generator",
"grayscale_image",
"letterbox_image",
"list_files_with_extensions",
"mask_iou_batch",
"mask_non_max_merge",
"mask_non_max_suppression",
"mask_to_polygons",
"mask_to_rle",
"mask_to_xyxy",
"move_boxes",
"move_masks",
"oriented_box_iou_batch",
"overlay_image",
"pad_boxes",
"pillow_to_cv2",
"plot_image",
"plot_images_grid",
"polygon_to_mask",
"polygon_to_xyxy",
"process_video",
"resize_image",
"rle_to_mask",
"scale_boxes",
"scale_image",
"tint_image",
"xcycwh_to_xyxy",
"xywh_to_xyxy",
"xyxy_to_mask",
"xyxy_to_polygons",
"xyxy_to_xcycarh",
"xyxy_to_xywh",
]
Some files were not shown because too many files have changed in this diff
Show More
Reference in New Issue
Block a user
Blocking a user prevents them from interacting with repositories, such as opening or commenting on pull requests or issues. Learn more about blocking a user.
 SkalskiP