Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 SkalskiP |
19396771f1 | ||
|
Onuralp SEZER
|
f5324897a3 | ||
|
Piotr Skalski
|
cd8a2be04b | ||
|
Linas Kondrackis
|
8901192b92 | ||
|
Linas Kondrackis
|
a9044e4fed | ||
|
Linas Kondrackis
|
85e4c0ec65 | ||
|
Linas Kondrackis
|
93398108ee | ||
|
Piotr Skalski
|
f41adca384 | ||
|
SkalskiP
|
d64bb3879c | ||
|
SkalskiP
|
452e1f1ea4 | ||
|
Linas Kondrackis
|
45e5f49c5a | ||
|
LinasKo
|
4c36b39f94 | ||
|
pre-commit-ci[bot]
|
e13c7dc22c | ||
|
SkalskiP
|
713719a582 | ||
|
SkalskiP
|
051fe5178b | ||
|
pre-commit-ci[bot]
|
1ebccebf4c | ||
|
SkalskiP
|
f56d7a1733 | ||
|
LinasKo
|
82ab6c57cb | ||
|
Linas Kondrackis
|
816aecb51b | ||
|
dependabot[bot]
|
3c8995758d | ||
|
Onuralp SEZER
|
acfabc247f | ||
|
Onuralp SEZER
|
61a63c83d9 | ||
|
Linas Kondrackis
|
528c960587 | ||
|
Linas Kondrackis
|
6c6171b5d5 | ||
|
Linas Kondrackis
|
b8efa25e93 | ||
|
SkalskiP
|
17c8e41fb3 | ||
|
Piotr Skalski
|
0c3594432c | ||
|
SkalskiP
|
a8c44cfaff | ||
|
pre-commit-ci[bot]
|
3d0c3d9182 | ||
|
SkalskiP
|
2364abf481 | ||
|
dependabot[bot]
|
3b61ee674e | ||
|
Linas Kondrackis
|
01f7eb5be6 | ||
|
pre-commit-ci[bot]
|
4cd1fbcef9 | ||
|
Linas Kondrackis
|
b6a55694f2 | ||
|
Linas Kondrackis
|
8c58ebe30d | ||
|
Piotr Skalski
|
77034700dd | ||
|
Linas Kondrackis
|
1ebbe3a8d1 | ||
|
Onuralp SEZER
|
617bd30c5f | ||
|
Onuralp SEZER
|
2e8720f156 | ||
|
Linas Kondrackis
|
45563dfddf | ||
|
Linas Kondrackis
|
7bb94ce966 | ||
|
Linas Kondrackis
|
fb49be8197 | ||
|
Piotr Skalski
|
d7b6af84e6 | ||
|
Piotr Skalski
|
d3b845fea5 | ||
|
Piotr Skalski
|
330eae4411 | ||
|
dependabot[bot]
|
4d25437459 | ||
|
pre-commit-ci[bot]
|
478fbd5751 | ||
|
pre-commit-ci[bot]
|
7823e0de89 | ||
|
SkalskiP
|
ab0882dd55 | ||
|
SkalskiP
|
ec6864ff04 | ||
|
SkalskiP
|
81786ff9d3 | ||
|
SkalskiP
|
95c243c058 | ||
|
pre-commit-ci[bot]
|
5c539c3bda | ||
|
SkalskiP
|
5d38120743 | ||
|
Manzar Iqbal Malik
|
aaf5df2f6a | ||
|
Onuralp SEZER
|
447ef41fc4 | ||
|
dependabot[bot]
|
edd944fff8 | ||
|
Onuralp SEZER
|
a75efbbf73 | ||
|
Onuralp SEZER
|
e9c8a80823 | ||
|
Onuralp SEZER
|
0b92417948 | ||
|
dependabot[bot]
|
aebbd01830 | ||
|
Onuralp SEZER
|
c3ebccabe8 | ||
|
dependabot[bot]
|
ff52352b00 | ||
|
dependabot[bot]
|
f7d21acd3a | ||
|
dependabot[bot]
|
92d56eda15 | ||
|
tc360950
|
d37a5f90a4 | ||
|
Onuralp SEZER
|
34a5b34c88 | ||
|
dependabot[bot]
|
f72d06b05e | ||
|
Onuralp SEZER
|
044a8fac06 | ||
|
Onuralp SEZER
|
a88089ced7 | ||
|
dependabot[bot]
|
29b0c514cf | ||
|
dependabot[bot]
|
7d5a0bce45 | ||
|
Piotr Skalski
|
177ab6ad4d | ||
|
pre-commit-ci[bot]
|
7e79fa3d07 | ||
|
Linas Kondrackis
|
347b75935b | ||
|
Linas Kondrackis
|
079008cd17 | ||
|
pre-commit-ci[bot]
|
aab3ed2ba9 | ||
|
Linas Kondrackis
|
ba30244add | ||
|
Onuralp SEZER
|
55e8f16029 | ||
|
dependabot[bot]
|
33e69b2da3 | ||
|
Piotr Skalski
|
9fe3170ead | ||
|
SkalskiP
|
ffda94b1e5 | ||
|
SkalskiP
|
7fd5d80a3b | ||
|
Onuralp SEZER
|
b67d9b475f | ||
|
Onuralp SEZER
|
d859842fa3 | ||
|
Onuralp SEZER
|
131c6ffefb | ||
|
dependabot[bot]
|
71fd3178cc | ||
|
dependabot[bot]
|
71919f1d6f | ||
|
SkalskiP
|
4732b6f1d0 | ||
|
Piotr Skalski
|
c024b62020 | ||
|
SkalskiP
|
d4b1375db7 | ||
|
Piotr Skalski
|
71200a5942 | ||
|
SkalskiP
|
66f6a86bbf | ||
|
SkalskiP
|
a70588284a | ||
|
pre-commit-ci[bot]
|
67160c96b0 | ||
|
LinasKo
|
7331577e69 | ||
|
Onuralp SEZER
|
5f00d8b595 | ||
|
Onuralp SEZER
|
88209f233d | ||
|
Onuralp SEZER
|
d51067164a | ||
|
pre-commit-ci[bot]
|
0dd8d7dca8 | ||
|
Linas Kondrackis
|
7c39d9dc8d | ||
|
Linas Kondrackis
|
d2d69f986e | ||
|
dependabot[bot]
|
df0b2df2f6 | ||
|
dependabot[bot]
|
31844c165b | ||
|
dependabot[bot]
|
c5a2f87bb9 | ||
|
Piotr Skalski
|
6ef9ba7390 | ||
|
SkalskiP
|
a532670611 | ||
|
SkalskiP
|
ba2d30d110 | ||
|
Linas Kondrackis
|
619da9575a | ||
|
LinasKo
|
25bdb560eb | ||
|
Onuralp SEZER
|
9b447296bf | ||
|
Onuralp SEZER
|
4a16d66bfb | ||
|
dependabot[bot]
|
8436f52f8a | ||
|
dependabot[bot]
|
059583e2ba | ||
|
pre-commit-ci[bot]
|
4bd593fe3c | ||
|
Linas Kondrackis
|
399342513a | ||
|
Linas Kondrackis
|
c8c2ff5c45 | ||
|
Linas Kondrackis
|
18b3c17ed4 | ||
|
Linas Kondrackis
|
cab06f2c2b | ||
|
Onuralp SEZER
|
2b53216a0b | ||
|
dependabot[bot]
|
e253f86e8f | ||
|
Piotr Skalski
|
df4c546c10 | ||
|
Piotr Skalski
|
25fc1ab6fa | ||
|
SkalskiP
|
a45341ce63 | ||
|
Piotr Skalski
|
e93ef041d4 | ||
|
pre-commit-ci[bot]
|
d531c59f85 | ||
|
Jeslin P James
|
15b1473c2f | ||
|
Jeslin P James
|
26c2a7ef9c | ||
|
pre-commit-ci[bot]
|
361e444f53 | ||
|
Raif Olson
|
07756328db | ||
|
Raif Olson
|
f98ded49a2 | ||
|
pre-commit-ci[bot]
|
bcb31f8809 | ||
|
Raif Olson
|
b1d5d4faf0 | ||
|
Raif Olson
|
7924a13dc5 | ||
|
pre-commit-ci[bot]
|
755f292ed1 | ||
|
Raif Olson
|
6166d92458 | ||
|
pre-commit-ci[bot]
|
2c9a1f69c5 | ||
|
pre-commit-ci[bot]
|
a2ab113f21 | ||
|
Raif Olson
|
eaff97f902 | ||
|
Raif Olson
|
ad0e6c3b51 | ||
|
pre-commit-ci[bot]
|
27b61ab4a3 | ||
|
Seongjun Choi
|
bddb72fb28 | ||
|
Seongjun Choi
|
823dc56057 |
@@ -45,7 +45,7 @@ repos:
|
||||
|
||||
|
||||
- repo: https://github.com/astral-sh/ruff-pre-commit
|
||||
rev: v0.4.1
|
||||
rev: v0.4.3
|
||||
hooks:
|
||||
- id: ruff
|
||||
args: [--fix, --exit-non-zero-on-fix]
|
||||
|
||||
@@ -65,8 +65,26 @@ status: new
|
||||
|
||||
:::supervision.detection.utils.move_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.move_masks">move_masks</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.move_masks
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.scale_boxes">scale_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.scale_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.clip_boxes">clip_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.clip_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.pad_boxes">pad_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.pad_boxes
|
||||
|
||||
@@ -6,7 +6,7 @@ status: new
|
||||
# Detect Small Objects
|
||||
|
||||
This guide shows how to detect small objects
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
[Ultralytics](https://github.com/ultralytics/ultralytics) or
|
||||
[Transformers](https://github.com/huggingface/transformers) packages using
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer).
|
||||
@@ -68,10 +68,10 @@ size relative to the image resolution.
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
from transformers import DetrImageProcessor, DetrForSegmentation
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForSegmentation.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<SOURCE_IMAGE_PATH>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
@@ -79,8 +79,8 @@ size relative to the image resolution.
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
width, height = image_slice.size
|
||||
target_size = torch.tensor([[width, height]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
@@ -175,7 +175,7 @@ objects within each, and aggregating the results.
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
results = model.infer(image_slice)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
return sv.Detections.from_inference(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
@@ -239,8 +239,8 @@ objects within each, and aggregating the results.
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
width, height = image_slice.size
|
||||
target_size = torch.tensor([[width, height]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
return sv.Detections.from_transformers(results)
|
||||
@@ -264,3 +264,63 @@ objects within each, and aggregating the results.
|
||||
```
|
||||
|
||||
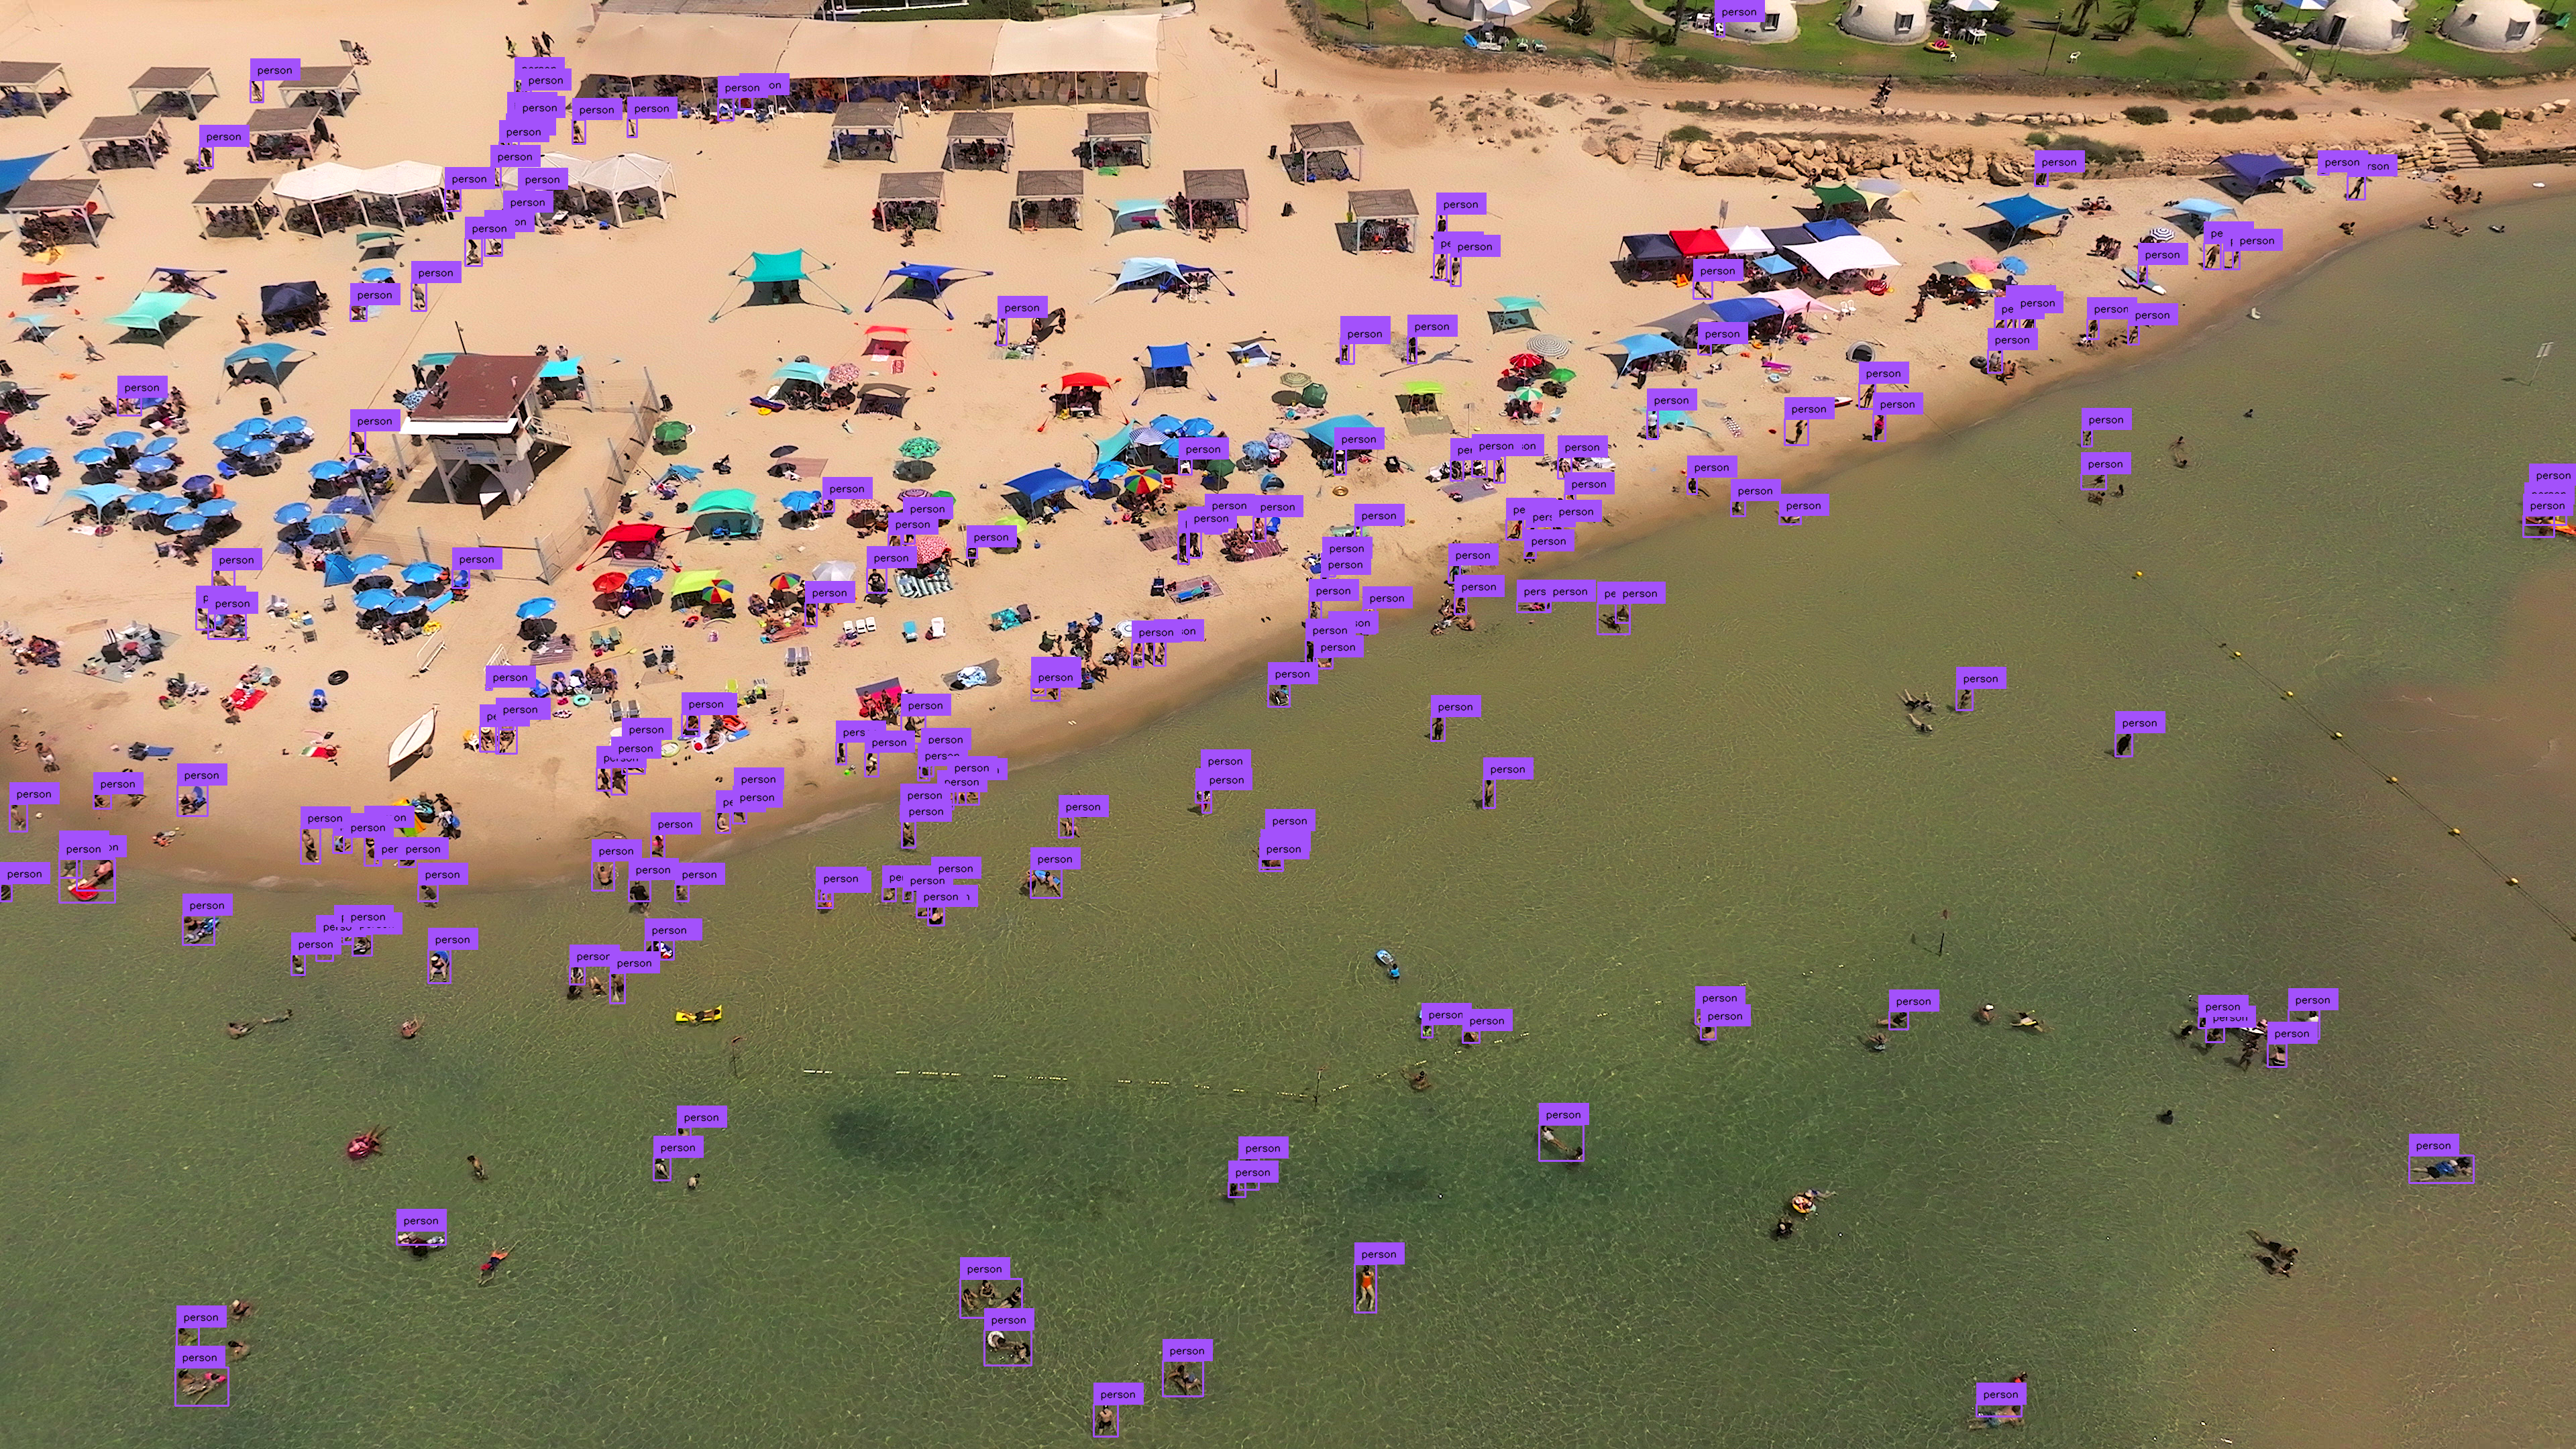
|
||||
|
||||
## Small Object Segmentation
|
||||
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer) can perform segmentation tasks too.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```{ .py hl_lines="6 16 19-20" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8x-seg-640")
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
results = model.infer(image_slice)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```{ .py hl_lines="6 16 19-20" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8x-seg.pt")
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
result = model(image_slice)[0]
|
||||
return sv.Detections.from_ultralytics(result)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
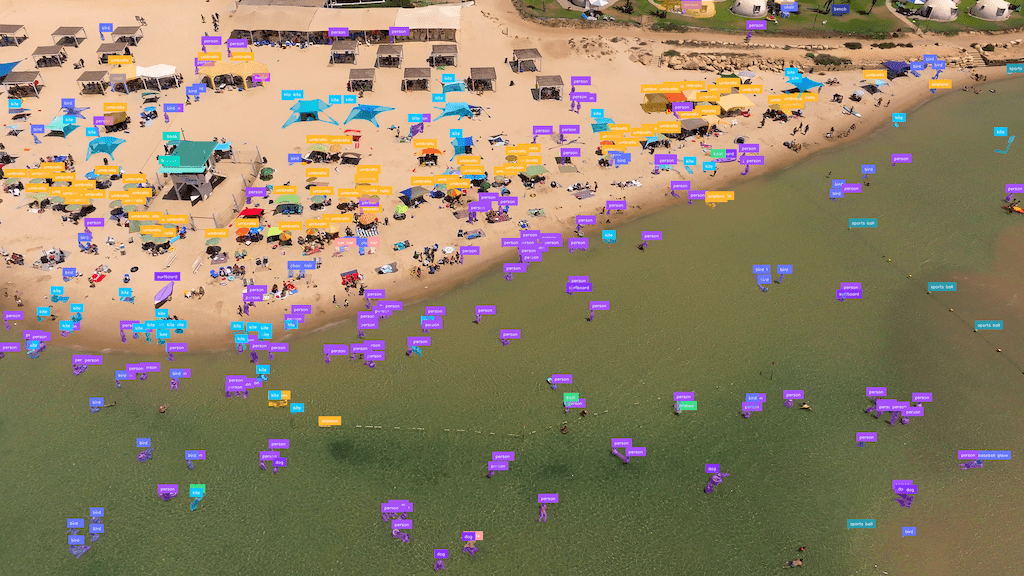
|
||||
|
||||
@@ -13,7 +13,10 @@ status: new
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_annotator = sv.VertexAnnotator(color=sv.Color.GREEN, radius=10)
|
||||
vertex_annotator = sv.VertexAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
radius=10
|
||||
)
|
||||
annotated_frame = vertex_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -34,7 +37,10 @@ status: new
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
edge_annotator = sv.EdgeAnnotator(color=sv.Color.GREEN, thickness=5)
|
||||
edge_annotator = sv.EdgeAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
thickness=5
|
||||
)
|
||||
annotated_frame = edge_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -47,6 +53,31 @@ status: new
|
||||
|
||||
</div>
|
||||
|
||||
=== "VertexLabelAnnotator"
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
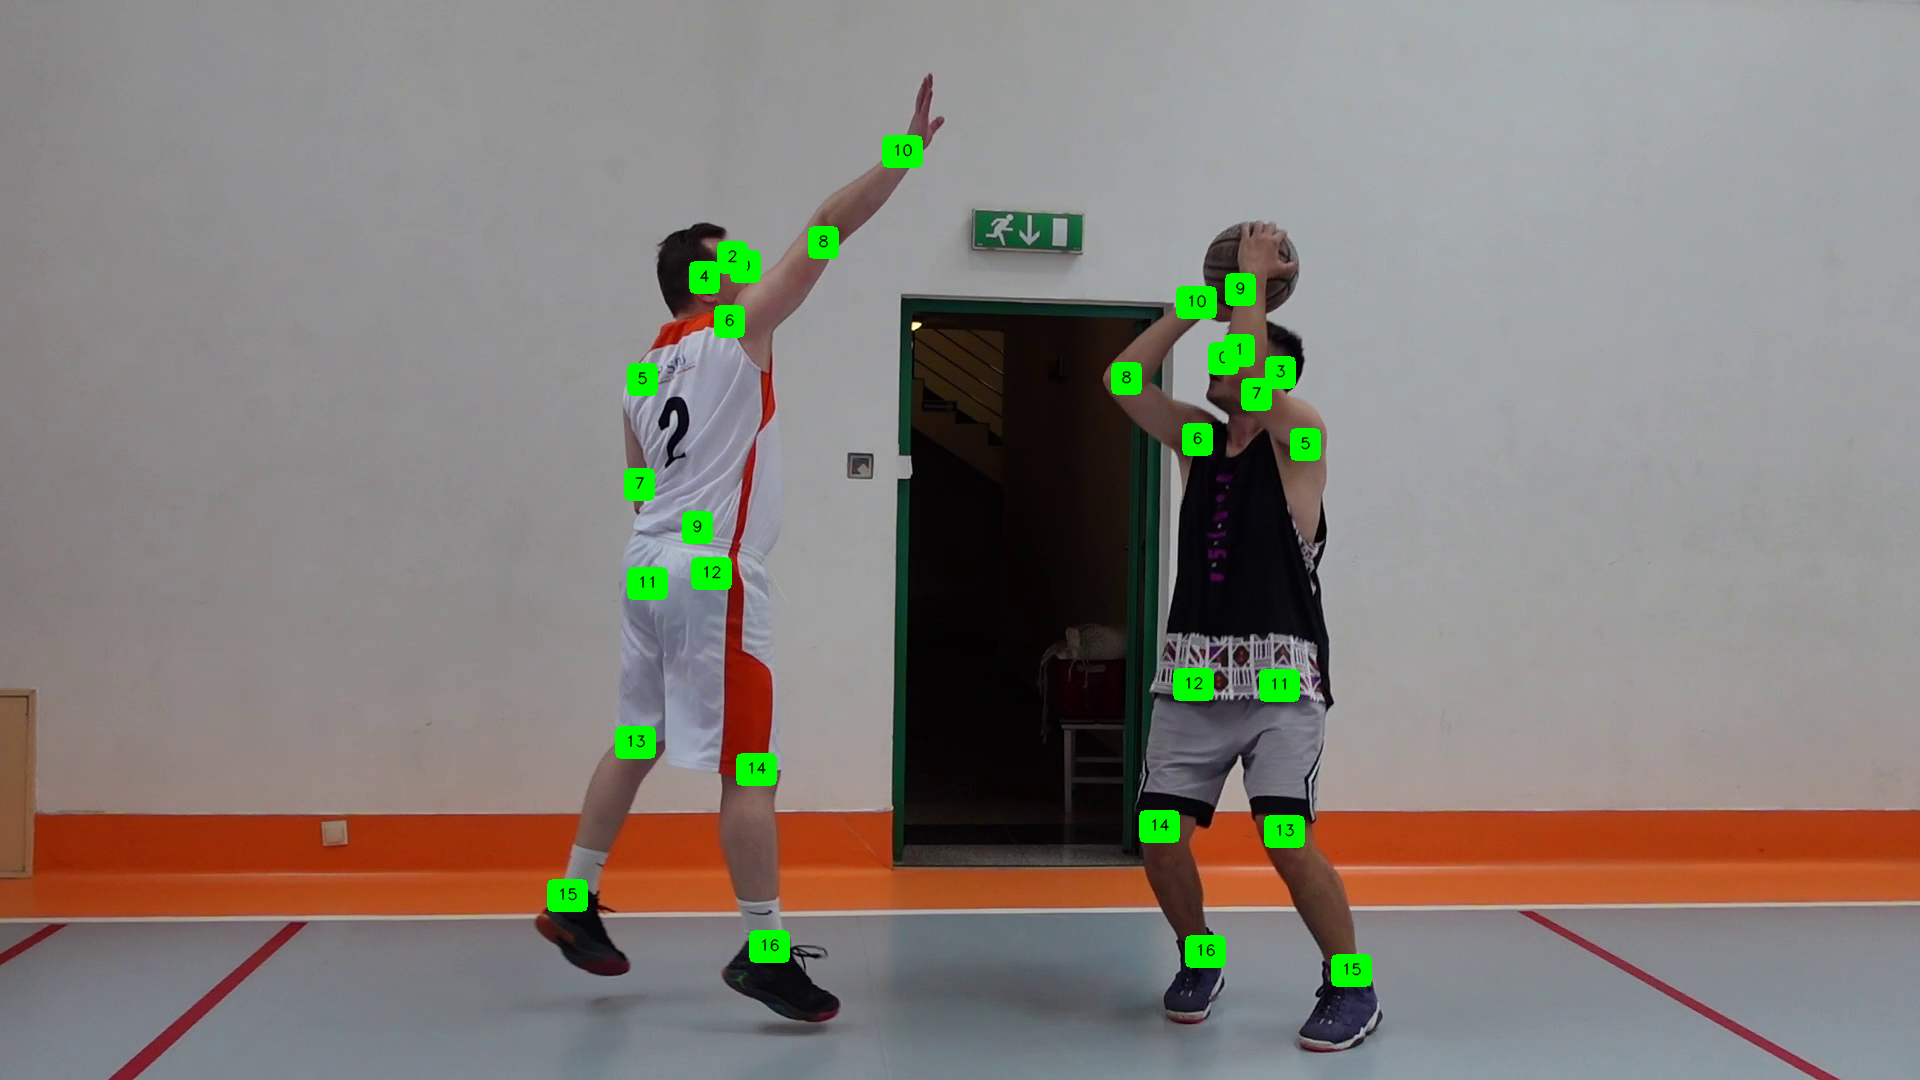{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.keypoint.annotators.VertexAnnotator">VertexAnnotator</a></h2>
|
||||
</div>
|
||||
@@ -58,3 +89,9 @@ status: new
|
||||
</div>
|
||||
|
||||
:::supervision.keypoint.annotators.EdgeAnnotator
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.keypoint.annotators.VertexLabelAnnotator">VertexLabelAnnotator</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.keypoint.annotators.VertexLabelAnnotator
|
||||
|
||||
@@ -38,15 +38,15 @@ def initiate_annotators(
|
||||
) -> Tuple[
|
||||
List[sv.PolygonZone], List[sv.PolygonZoneAnnotator], List[sv.BoundingBoxAnnotator]
|
||||
]:
|
||||
line_thickness = sv.calculate_dynamic_line_thickness(resolution_wh=resolution_wh)
|
||||
text_scale = sv.calculate_dynamic_text_scale(resolution_wh=resolution_wh)
|
||||
line_thickness = sv.calculate_optimal_line_thickness(resolution_wh=resolution_wh)
|
||||
text_scale = sv.calculate_optimal_text_scale(resolution_wh=resolution_wh)
|
||||
|
||||
zones = []
|
||||
zone_annotators = []
|
||||
box_annotators = []
|
||||
|
||||
for index, polygon in enumerate(polygons):
|
||||
zone = sv.PolygonZone(polygon=polygon, frame_resolution_wh=resolution_wh)
|
||||
zone = sv.PolygonZone(polygon=polygon)
|
||||
zone_annotator = sv.PolygonZoneAnnotator(
|
||||
zone=zone,
|
||||
color=COLORS.by_idx(index),
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
gdown
|
||||
inference
|
||||
supervision==0.19.0
|
||||
inference==0.9.17
|
||||
supervision>=0.20.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -36,15 +36,15 @@ def initiate_annotators(
|
||||
) -> Tuple[
|
||||
List[sv.PolygonZone], List[sv.PolygonZoneAnnotator], List[sv.BoundingBoxAnnotator]
|
||||
]:
|
||||
line_thickness = sv.calculate_dynamic_line_thickness(resolution_wh=resolution_wh)
|
||||
text_scale = sv.calculate_dynamic_text_scale(resolution_wh=resolution_wh)
|
||||
line_thickness = sv.calculate_optimal_line_thickness(resolution_wh=resolution_wh)
|
||||
text_scale = sv.calculate_optimal_text_scale(resolution_wh=resolution_wh)
|
||||
|
||||
zones = []
|
||||
zone_annotators = []
|
||||
box_annotators = []
|
||||
|
||||
for index, polygon in enumerate(polygons):
|
||||
zone = sv.PolygonZone(polygon=polygon, frame_resolution_wh=resolution_wh)
|
||||
zone = sv.PolygonZone(polygon=polygon)
|
||||
zone_annotator = sv.PolygonZoneAnnotator(
|
||||
zone=zone,
|
||||
color=COLORS.by_idx(index),
|
||||
|
||||
@@ -98,10 +98,10 @@ if __name__ == "__main__":
|
||||
frame_rate=video_info.fps, track_thresh=args.confidence_threshold
|
||||
)
|
||||
|
||||
thickness = sv.calculate_dynamic_line_thickness(
|
||||
thickness = sv.calculate_optimal_line_thickness(
|
||||
resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
text_scale = sv.calculate_dynamic_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
text_scale = sv.calculate_optimal_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator(thickness=thickness)
|
||||
label_annotator = sv.LabelAnnotator(
|
||||
text_scale=text_scale,
|
||||
@@ -116,9 +116,7 @@ if __name__ == "__main__":
|
||||
|
||||
frame_generator = sv.get_video_frames_generator(source_path=args.source_video_path)
|
||||
|
||||
polygon_zone = sv.PolygonZone(
|
||||
polygon=SOURCE, frame_resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
polygon_zone = sv.PolygonZone(polygon=SOURCE)
|
||||
view_transformer = ViewTransformer(source=SOURCE, target=TARGET)
|
||||
|
||||
coordinates = defaultdict(lambda: deque(maxlen=video_info.fps))
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
supervision==0.19.0
|
||||
tqdm==4.66.1
|
||||
supervision>=0.20.0
|
||||
tqdm==4.66.3
|
||||
requests
|
||||
ultralytics==8.0.237
|
||||
super-gradients==3.5.0
|
||||
inference==0.9.8
|
||||
inference==0.9.17
|
||||
|
||||
@@ -76,10 +76,10 @@ if __name__ == "__main__":
|
||||
frame_rate=video_info.fps, track_thresh=args.confidence_threshold
|
||||
)
|
||||
|
||||
thickness = sv.calculate_dynamic_line_thickness(
|
||||
thickness = sv.calculate_optimal_line_thickness(
|
||||
resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
text_scale = sv.calculate_dynamic_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
text_scale = sv.calculate_optimal_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator(thickness=thickness)
|
||||
label_annotator = sv.LabelAnnotator(
|
||||
text_scale=text_scale,
|
||||
@@ -94,9 +94,7 @@ if __name__ == "__main__":
|
||||
|
||||
frame_generator = sv.get_video_frames_generator(source_path=args.source_video_path)
|
||||
|
||||
polygon_zone = sv.PolygonZone(
|
||||
polygon=SOURCE, frame_resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
polygon_zone = sv.PolygonZone(polygon=SOURCE)
|
||||
view_transformer = ViewTransformer(source=SOURCE, target=TARGET)
|
||||
|
||||
coordinates = defaultdict(lambda: deque(maxlen=video_info.fps))
|
||||
|
||||
@@ -77,10 +77,10 @@ if __name__ == "__main__":
|
||||
frame_rate=video_info.fps, track_thresh=args.confidence_threshold
|
||||
)
|
||||
|
||||
thickness = sv.calculate_dynamic_line_thickness(
|
||||
thickness = sv.calculate_optimal_line_thickness(
|
||||
resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
text_scale = sv.calculate_dynamic_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
text_scale = sv.calculate_optimal_text_scale(resolution_wh=video_info.resolution_wh)
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator(thickness=thickness)
|
||||
label_annotator = sv.LabelAnnotator(
|
||||
text_scale=text_scale,
|
||||
@@ -95,9 +95,7 @@ if __name__ == "__main__":
|
||||
|
||||
frame_generator = sv.get_video_frames_generator(source_path=args.source_video_path)
|
||||
|
||||
polygon_zone = sv.PolygonZone(
|
||||
polygon=SOURCE, frame_resolution_wh=video_info.resolution_wh
|
||||
)
|
||||
polygon_zone = sv.PolygonZone(polygon=SOURCE)
|
||||
view_transformer = ViewTransformer(source=SOURCE, target=TARGET)
|
||||
|
||||
coordinates = defaultdict(lambda: deque(maxlen=video_info.fps))
|
||||
|
||||
@@ -103,7 +103,7 @@ python scripts/draw_zones.py \
|
||||
```bash
|
||||
python scripts/draw_zones.py \
|
||||
--source_path "data/traffic/video.mp4" \
|
||||
--zone_configuration_path "data/traffic/custom_config.json"
|
||||
--zone_configuration_path "data/traffic/config.json"
|
||||
```
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/9d514c9e-2a61-418b-ae49-6ac1ad6ae5ac
|
||||
@@ -157,7 +157,7 @@ Script to run object detection on a video stream using the Roboflow Inference mo
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python inference_stream_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--model_id "yolov8x-640" \
|
||||
@@ -167,7 +167,7 @@ python inference_file_example.py \
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python inference_stream_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--model_id "yolov8x-640" \
|
||||
@@ -192,7 +192,7 @@ Script to run object detection on a video file using the Ultralytics YOLOv8 mode
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python ultralytics_file_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--source_video_path "data/checkout/video.mp4" \
|
||||
--weights "yolov8x.pt" \
|
||||
@@ -203,7 +203,7 @@ python inference_file_example.py \
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python ultralytics_file_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--source_video_path "data/traffic/video.mp4" \
|
||||
--weights "yolov8x.pt" \
|
||||
@@ -226,7 +226,7 @@ Script to run object detection on a video stream using the Ultralytics YOLOv8 mo
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python ultralytics_stream_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--weights "yolov8x.pt" \
|
||||
@@ -237,7 +237,7 @@ python inference_file_example.py \
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
python ultralytics_stream_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--weights "yolov8x.pt" \
|
||||
|
||||
@@ -29,14 +29,10 @@ def main(
|
||||
video_info = sv.VideoInfo.from_video_path(video_path=source_video_path)
|
||||
frames_generator = sv.get_video_frames_generator(source_video_path)
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
|
||||
@@ -29,14 +29,10 @@ def main(
|
||||
frames_generator = get_stream_frames_generator(rtsp_url=rtsp_url)
|
||||
fps_monitor = sv.FPSMonitor()
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
|
||||
@@ -24,20 +24,15 @@ class CustomSink:
|
||||
self.fps_monitor = sv.FPSMonitor()
|
||||
self.polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
self.timers = [ClockBasedTimer() for _ in self.polygons]
|
||||
self.zones = None
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
def on_prediction(self, result: dict, frame: VideoFrame) -> None:
|
||||
if self.zones is None:
|
||||
resolution_wh = frame.image.shape[1], frame.image.shape[0]
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
self.fps_monitor.tick()
|
||||
fps = self.fps_monitor.fps
|
||||
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
opencv-python
|
||||
supervision
|
||||
supervision>=0.20.0
|
||||
ultralytics
|
||||
inference
|
||||
inference==0.9.17
|
||||
pytube
|
||||
|
||||
@@ -30,14 +30,10 @@ def main(
|
||||
video_info = sv.VideoInfo.from_video_path(video_path=source_video_path)
|
||||
frames_generator = sv.get_video_frames_generator(source_video_path)
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
|
||||
@@ -30,14 +30,10 @@ def main(
|
||||
frames_generator = get_stream_frames_generator(rtsp_url=rtsp_url)
|
||||
fps_monitor = sv.FPSMonitor()
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
|
||||
@@ -25,20 +25,15 @@ class CustomSink:
|
||||
self.fps_monitor = sv.FPSMonitor()
|
||||
self.polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
self.timers = [ClockBasedTimer() for _ in self.polygons]
|
||||
self.zones = None
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
def on_prediction(self, detections: sv.Detections, frame: VideoFrame) -> None:
|
||||
if self.zones is None:
|
||||
resolution_wh = frame.image.shape[1], frame.image.shape[0]
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
self.fps_monitor.tick()
|
||||
fps = self.fps_monitor.fps
|
||||
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
inference
|
||||
inference==0.9.17
|
||||
supervision==0.19.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
import argparse
|
||||
import os
|
||||
from typing import Dict, Iterable, List, Set, Tuple
|
||||
from typing import Dict, Iterable, List, Set
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
@@ -60,13 +60,11 @@ class DetectionsManager:
|
||||
|
||||
def initiate_polygon_zones(
|
||||
polygons: List[np.ndarray],
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
triggering_anchors: Iterable[sv.Position] = [sv.Position.CENTER],
|
||||
) -> List[sv.PolygonZone]:
|
||||
return [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=frame_resolution_wh,
|
||||
triggering_anchors=triggering_anchors,
|
||||
)
|
||||
for polygon in polygons
|
||||
@@ -92,12 +90,8 @@ class VideoProcessor:
|
||||
self.tracker = sv.ByteTrack()
|
||||
|
||||
self.video_info = sv.VideoInfo.from_video_path(source_video_path)
|
||||
self.zones_in = initiate_polygon_zones(
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_out = initiate_polygon_zones(
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_in = initiate_polygon_zones(ZONE_IN_POLYGONS, [sv.Position.CENTER])
|
||||
self.zones_out = initiate_polygon_zones(ZONE_OUT_POLYGONS, [sv.Position.CENTER])
|
||||
|
||||
self.bounding_box_annotator = sv.BoundingBoxAnnotator(color=COLORS)
|
||||
self.label_annotator = sv.LabelAnnotator(
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
gdown
|
||||
inference
|
||||
supervision>=0.19.0
|
||||
inference==0.9.17
|
||||
supervision>=0.20.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
import argparse
|
||||
from typing import Dict, Iterable, List, Set, Tuple
|
||||
from typing import Dict, Iterable, List, Set
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
@@ -58,13 +58,11 @@ class DetectionsManager:
|
||||
|
||||
def initiate_polygon_zones(
|
||||
polygons: List[np.ndarray],
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
triggering_anchors: Iterable[sv.Position] = [sv.Position.CENTER],
|
||||
) -> List[sv.PolygonZone]:
|
||||
return [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=frame_resolution_wh,
|
||||
triggering_anchors=triggering_anchors,
|
||||
)
|
||||
for polygon in polygons
|
||||
@@ -89,12 +87,8 @@ class VideoProcessor:
|
||||
self.tracker = sv.ByteTrack()
|
||||
|
||||
self.video_info = sv.VideoInfo.from_video_path(source_video_path)
|
||||
self.zones_in = initiate_polygon_zones(
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_out = initiate_polygon_zones(
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_in = initiate_polygon_zones(ZONE_IN_POLYGONS, [sv.Position.CENTER])
|
||||
self.zones_out = initiate_polygon_zones(ZONE_OUT_POLYGONS, [sv.Position.CENTER])
|
||||
|
||||
self.bounding_box_annotator = sv.BoundingBoxAnnotator(color=COLORS)
|
||||
self.label_annotator = sv.LabelAnnotator(
|
||||
|
||||
Generated
+117
-110
@@ -1340,13 +1340,13 @@ trio = ["async_generator", "trio"]
|
||||
|
||||
[[package]]
|
||||
name = "jinja2"
|
||||
version = "3.1.3"
|
||||
version = "3.1.4"
|
||||
description = "A very fast and expressive template engine."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "Jinja2-3.1.3-py3-none-any.whl", hash = "sha256:7d6d50dd97d52cbc355597bd845fabfbac3f551e1f99619e39a35ce8c370b5fa"},
|
||||
{file = "Jinja2-3.1.3.tar.gz", hash = "sha256:ac8bd6544d4bb2c9792bf3a159e80bba8fda7f07e81bc3aed565432d5925ba90"},
|
||||
{file = "jinja2-3.1.4-py3-none-any.whl", hash = "sha256:bc5dd2abb727a5319567b7a813e6a2e7318c39f4f487cfe6c89c6f9c7d25197d"},
|
||||
{file = "jinja2-3.1.4.tar.gz", hash = "sha256:4a3aee7acbbe7303aede8e9648d13b8bf88a429282aa6122a993f0ac800cb369"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -1648,13 +1648,13 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "jupytext"
|
||||
version = "1.16.1"
|
||||
version = "1.16.2"
|
||||
description = "Jupyter notebooks as Markdown documents, Julia, Python or R scripts"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "jupytext-1.16.1-py3-none-any.whl", hash = "sha256:796ec4f68ada663569e5d38d4ef03738a01284bfe21c943c485bc36433898bd0"},
|
||||
{file = "jupytext-1.16.1.tar.gz", hash = "sha256:68c7b68685e870e80e60fda8286fbd6269e9c74dc1df4316df6fe46eabc94c99"},
|
||||
{file = "jupytext-1.16.2-py3-none-any.whl", hash = "sha256:197a43fef31dca612b68b311e01b8abd54441c7e637810b16b6cb8f2ab66065e"},
|
||||
{file = "jupytext-1.16.2.tar.gz", hash = "sha256:8627dd9becbbebd79cc4a4ed4727d89d78e606b4b464eab72357b3b029023a14"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -1663,16 +1663,16 @@ mdit-py-plugins = "*"
|
||||
nbformat = "*"
|
||||
packaging = "*"
|
||||
pyyaml = "*"
|
||||
toml = "*"
|
||||
tomli = {version = "*", markers = "python_version < \"3.11\""}
|
||||
|
||||
[package.extras]
|
||||
dev = ["jupytext[test-cov,test-external]"]
|
||||
dev = ["autopep8", "black", "flake8", "gitpython", "ipykernel", "isort", "jupyter-fs (<0.4.0)", "jupyter-server (!=2.11)", "nbconvert", "pre-commit", "pytest", "pytest-cov (>=2.6.1)", "pytest-randomly", "pytest-xdist", "sphinx-gallery (<0.8)"]
|
||||
docs = ["myst-parser", "sphinx", "sphinx-copybutton", "sphinx-rtd-theme"]
|
||||
test = ["pytest", "pytest-randomly", "pytest-xdist"]
|
||||
test-cov = ["jupytext[test-integration]", "pytest-cov (>=2.6.1)"]
|
||||
test-external = ["autopep8", "black", "flake8", "gitpython", "isort", "jupyter-fs (<0.4.0)", "jupytext[test-integration]", "pre-commit", "sphinx-gallery (<0.8)"]
|
||||
test-functional = ["jupytext[test]"]
|
||||
test-integration = ["ipykernel", "jupyter-server (!=2.11)", "jupytext[test-functional]", "nbconvert"]
|
||||
test-cov = ["ipykernel", "jupyter-server (!=2.11)", "nbconvert", "pytest", "pytest-cov (>=2.6.1)", "pytest-randomly", "pytest-xdist"]
|
||||
test-external = ["autopep8", "black", "flake8", "gitpython", "ipykernel", "isort", "jupyter-fs (<0.4.0)", "jupyter-server (!=2.11)", "nbconvert", "pre-commit", "pytest", "pytest-randomly", "pytest-xdist", "sphinx-gallery (<0.8)"]
|
||||
test-functional = ["pytest", "pytest-randomly", "pytest-xdist"]
|
||||
test-integration = ["ipykernel", "jupyter-server (!=2.11)", "nbconvert", "pytest", "pytest-randomly", "pytest-xdist"]
|
||||
test-ui = ["calysto-bash"]
|
||||
|
||||
[[package]]
|
||||
@@ -2048,13 +2048,13 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "mike"
|
||||
version = "2.0.0"
|
||||
version = "2.1.1"
|
||||
description = "Manage multiple versions of your MkDocs-powered documentation"
|
||||
optional = false
|
||||
python-versions = "*"
|
||||
files = [
|
||||
{file = "mike-2.0.0-py3-none-any.whl", hash = "sha256:87f496a65900f93ba92d72940242b65c86f3f2f82871bc60ebdcffc91fad1d9e"},
|
||||
{file = "mike-2.0.0.tar.gz", hash = "sha256:566f1cab1a58cc50b106fb79ea2f1f56e7bfc8b25a051e95e6eaee9fba0922de"},
|
||||
{file = "mike-2.1.1-py3-none-any.whl", hash = "sha256:0b1d01a397a423284593eeb1b5f3194e37169488f929b860c9bfe95c0d5efb79"},
|
||||
{file = "mike-2.1.1.tar.gz", hash = "sha256:f39ed39f3737da83ad0adc33e9f885092ed27f8c9e7ff0523add0480352a2c22"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2064,6 +2064,7 @@ jinja2 = ">=2.7"
|
||||
mkdocs = ">=1.0"
|
||||
pyparsing = ">=3.0"
|
||||
pyyaml = ">=5.1"
|
||||
pyyaml-env-tag = "*"
|
||||
verspec = "*"
|
||||
|
||||
[package.extras]
|
||||
@@ -2083,34 +2084,34 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs"
|
||||
version = "1.5.3"
|
||||
version = "1.6.0"
|
||||
description = "Project documentation with Markdown."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs-1.5.3-py3-none-any.whl", hash = "sha256:3b3a78e736b31158d64dbb2f8ba29bd46a379d0c6e324c2246c3bc3d2189cfc1"},
|
||||
{file = "mkdocs-1.5.3.tar.gz", hash = "sha256:eb7c99214dcb945313ba30426c2451b735992c73c2e10838f76d09e39ff4d0e2"},
|
||||
{file = "mkdocs-1.6.0-py3-none-any.whl", hash = "sha256:1eb5cb7676b7d89323e62b56235010216319217d4af5ddc543a91beb8d125ea7"},
|
||||
{file = "mkdocs-1.6.0.tar.gz", hash = "sha256:a73f735824ef83a4f3bcb7a231dcab23f5a838f88b7efc54a0eef5fbdbc3c512"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
click = ">=7.0"
|
||||
colorama = {version = ">=0.4", markers = "platform_system == \"Windows\""}
|
||||
ghp-import = ">=1.0"
|
||||
importlib-metadata = {version = ">=4.3", markers = "python_version < \"3.10\""}
|
||||
importlib-metadata = {version = ">=4.4", markers = "python_version < \"3.10\""}
|
||||
jinja2 = ">=2.11.1"
|
||||
markdown = ">=3.2.1"
|
||||
markdown = ">=3.3.6"
|
||||
markupsafe = ">=2.0.1"
|
||||
mergedeep = ">=1.3.4"
|
||||
mkdocs-get-deps = ">=0.2.0"
|
||||
packaging = ">=20.5"
|
||||
pathspec = ">=0.11.1"
|
||||
platformdirs = ">=2.2.0"
|
||||
pyyaml = ">=5.1"
|
||||
pyyaml-env-tag = ">=0.1"
|
||||
watchdog = ">=2.0"
|
||||
|
||||
[package.extras]
|
||||
i18n = ["babel (>=2.9.0)"]
|
||||
min-versions = ["babel (==2.9.0)", "click (==7.0)", "colorama (==0.4)", "ghp-import (==1.0)", "importlib-metadata (==4.3)", "jinja2 (==2.11.1)", "markdown (==3.2.1)", "markupsafe (==2.0.1)", "mergedeep (==1.3.4)", "packaging (==20.5)", "pathspec (==0.11.1)", "platformdirs (==2.2.0)", "pyyaml (==5.1)", "pyyaml-env-tag (==0.1)", "typing-extensions (==3.10)", "watchdog (==2.0)"]
|
||||
min-versions = ["babel (==2.9.0)", "click (==7.0)", "colorama (==0.4)", "ghp-import (==1.0)", "importlib-metadata (==4.4)", "jinja2 (==2.11.1)", "markdown (==3.3.6)", "markupsafe (==2.0.1)", "mergedeep (==1.3.4)", "mkdocs-get-deps (==0.2.0)", "packaging (==20.5)", "pathspec (==0.11.1)", "pyyaml (==5.1)", "pyyaml-env-tag (==0.1)", "watchdog (==2.0)"]
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-autorefs"
|
||||
@@ -2127,6 +2128,23 @@ files = [
|
||||
Markdown = ">=3.3"
|
||||
mkdocs = ">=1.1"
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-get-deps"
|
||||
version = "0.2.0"
|
||||
description = "MkDocs extension that lists all dependencies according to a mkdocs.yml file"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs_get_deps-0.2.0-py3-none-any.whl", hash = "sha256:2bf11d0b133e77a0dd036abeeb06dec8775e46efa526dc70667d8863eefc6134"},
|
||||
{file = "mkdocs_get_deps-0.2.0.tar.gz", hash = "sha256:162b3d129c7fad9b19abfdcb9c1458a651628e4b1dea628ac68790fb3061c60c"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
importlib-metadata = {version = ">=4.3", markers = "python_version < \"3.10\""}
|
||||
mergedeep = ">=1.3.4"
|
||||
platformdirs = ">=2.2.0"
|
||||
pyyaml = ">=5.1"
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-git-committers-plugin-2"
|
||||
version = "2.3.0"
|
||||
@@ -2145,13 +2163,13 @@ requests = "*"
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-git-revision-date-localized-plugin"
|
||||
version = "1.2.4"
|
||||
version = "1.2.5"
|
||||
description = "Mkdocs plugin that enables displaying the localized date of the last git modification of a markdown file."
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs-git-revision-date-localized-plugin-1.2.4.tar.gz", hash = "sha256:08fd0c6f33c8da9e00daf40f7865943113b3879a1c621b2bbf0fa794ffe997d3"},
|
||||
{file = "mkdocs_git_revision_date_localized_plugin-1.2.4-py3-none-any.whl", hash = "sha256:1f94eb510862ef94e982a2910404fa17a1657ecf29f45a07b0f438c00767fc85"},
|
||||
{file = "mkdocs_git_revision_date_localized_plugin-1.2.5-py3-none-any.whl", hash = "sha256:d796a18b07cfcdb154c133e3ec099d2bb5f38389e4fd54d3eb516a8a736815b8"},
|
||||
{file = "mkdocs_git_revision_date_localized_plugin-1.2.5.tar.gz", hash = "sha256:0c439816d9d0dba48e027d9d074b2b9f1d7cd179f74ba46b51e4da7bb3dc4b9b"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2180,13 +2198,13 @@ pygments = ">2.12.0"
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-material"
|
||||
version = "9.5.18"
|
||||
version = "9.5.22"
|
||||
description = "Documentation that simply works"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs_material-9.5.18-py3-none-any.whl", hash = "sha256:1e0e27fc9fe239f9064318acf548771a4629d5fd5dfd45444fd80a953fe21eb4"},
|
||||
{file = "mkdocs_material-9.5.18.tar.gz", hash = "sha256:a43f470947053fa2405c33995f282d24992c752a50114f23f30da9d8d0c57e62"},
|
||||
{file = "mkdocs_material-9.5.22-py3-none-any.whl", hash = "sha256:8c7a377d323567934e6cd46915e64dc209efceaec0dec1cf2202184f5649862c"},
|
||||
{file = "mkdocs_material-9.5.22.tar.gz", hash = "sha256:22a853a456ae8c581c4628159574d6fc7c71b2c7569dc9c3a82cc70432219599"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2195,7 +2213,7 @@ cairosvg = {version = ">=2.6,<3.0", optional = true, markers = "extra == \"imagi
|
||||
colorama = ">=0.4,<1.0"
|
||||
jinja2 = ">=3.0,<4.0"
|
||||
markdown = ">=3.2,<4.0"
|
||||
mkdocs = ">=1.5.3,<1.6.0"
|
||||
mkdocs = ">=1.6,<2.0"
|
||||
mkdocs-material-extensions = ">=1.3,<2.0"
|
||||
paginate = ">=0.5,<1.0"
|
||||
pillow = {version = ">=10.2,<11.0", optional = true, markers = "extra == \"imaging\""}
|
||||
@@ -2222,13 +2240,13 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "mkdocstrings"
|
||||
version = "0.24.3"
|
||||
version = "0.25.1"
|
||||
description = "Automatic documentation from sources, for MkDocs."
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocstrings-0.24.3-py3-none-any.whl", hash = "sha256:5c9cf2a32958cd161d5428699b79c8b0988856b0d4a8c5baf8395fc1bf4087c3"},
|
||||
{file = "mkdocstrings-0.24.3.tar.gz", hash = "sha256:f327b234eb8d2551a306735436e157d0a22d45f79963c60a8b585d5f7a94c1d2"},
|
||||
{file = "mkdocstrings-0.25.1-py3-none-any.whl", hash = "sha256:da01fcc2670ad61888e8fe5b60afe9fee5781017d67431996832d63e887c2e51"},
|
||||
{file = "mkdocstrings-0.25.1.tar.gz", hash = "sha256:c3a2515f31577f311a9ee58d089e4c51fc6046dbd9e9b4c3de4c3194667fe9bf"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2277,38 +2295,38 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "mypy"
|
||||
version = "1.9.0"
|
||||
version = "1.10.0"
|
||||
description = "Optional static typing for Python"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mypy-1.9.0-cp310-cp310-macosx_10_9_x86_64.whl", hash = "sha256:f8a67616990062232ee4c3952f41c779afac41405806042a8126fe96e098419f"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-macosx_11_0_arm64.whl", hash = "sha256:d357423fa57a489e8c47b7c85dfb96698caba13d66e086b412298a1a0ea3b0ed"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:49c87c15aed320de9b438ae7b00c1ac91cd393c1b854c2ce538e2a72d55df150"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:48533cdd345c3c2e5ef48ba3b0d3880b257b423e7995dada04248725c6f77374"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-win_amd64.whl", hash = "sha256:4d3dbd346cfec7cb98e6cbb6e0f3c23618af826316188d587d1c1bc34f0ede03"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:653265f9a2784db65bfca694d1edd23093ce49740b2244cde583aeb134c008f3"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-macosx_11_0_arm64.whl", hash = "sha256:3a3c007ff3ee90f69cf0a15cbcdf0995749569b86b6d2f327af01fd1b8aee9dc"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:2418488264eb41f69cc64a69a745fad4a8f86649af4b1041a4c64ee61fc61129"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:68edad3dc7d70f2f17ae4c6c1b9471a56138ca22722487eebacfd1eb5321d612"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-win_amd64.whl", hash = "sha256:85ca5fcc24f0b4aeedc1d02f93707bccc04733f21d41c88334c5482219b1ccb3"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:aceb1db093b04db5cd390821464504111b8ec3e351eb85afd1433490163d60cd"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:0235391f1c6f6ce487b23b9dbd1327b4ec33bb93934aa986efe8a9563d9349e6"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d4d5ddc13421ba3e2e082a6c2d74c2ddb3979c39b582dacd53dd5d9431237185"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:190da1ee69b427d7efa8aa0d5e5ccd67a4fb04038c380237a0d96829cb157913"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-win_amd64.whl", hash = "sha256:fe28657de3bfec596bbeef01cb219833ad9d38dd5393fc649f4b366840baefe6"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-macosx_10_9_x86_64.whl", hash = "sha256:e54396d70be04b34f31d2edf3362c1edd023246c82f1730bbf8768c28db5361b"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-macosx_11_0_arm64.whl", hash = "sha256:5e6061f44f2313b94f920e91b204ec600982961e07a17e0f6cd83371cb23f5c2"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:81a10926e5473c5fc3da8abb04119a1f5811a236dc3a38d92015cb1e6ba4cb9e"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:b685154e22e4e9199fc95f298661deea28aaede5ae16ccc8cbb1045e716b3e04"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-win_amd64.whl", hash = "sha256:5d741d3fc7c4da608764073089e5f58ef6352bedc223ff58f2f038c2c4698a89"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:587ce887f75dd9700252a3abbc9c97bbe165a4a630597845c61279cf32dfbf02"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-macosx_11_0_arm64.whl", hash = "sha256:f88566144752999351725ac623471661c9d1cd8caa0134ff98cceeea181789f4"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:61758fabd58ce4b0720ae1e2fea5cfd4431591d6d590b197775329264f86311d"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:e49499be624dead83927e70c756970a0bc8240e9f769389cdf5714b0784ca6bf"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-win_amd64.whl", hash = "sha256:571741dc4194b4f82d344b15e8837e8c5fcc462d66d076748142327626a1b6e9"},
|
||||
{file = "mypy-1.9.0-py3-none-any.whl", hash = "sha256:a260627a570559181a9ea5de61ac6297aa5af202f06fd7ab093ce74e7181e43e"},
|
||||
{file = "mypy-1.9.0.tar.gz", hash = "sha256:3cc5da0127e6a478cddd906068496a97a7618a21ce9b54bde5bf7e539c7af974"},
|
||||
{file = "mypy-1.10.0-cp310-cp310-macosx_10_9_x86_64.whl", hash = "sha256:da1cbf08fb3b851ab3b9523a884c232774008267b1f83371ace57f412fe308c2"},
|
||||
{file = "mypy-1.10.0-cp310-cp310-macosx_11_0_arm64.whl", hash = "sha256:12b6bfc1b1a66095ab413160a6e520e1dc076a28f3e22f7fb25ba3b000b4ef99"},
|
||||
{file = "mypy-1.10.0-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:9e36fb078cce9904c7989b9693e41cb9711e0600139ce3970c6ef814b6ebc2b2"},
|
||||
{file = "mypy-1.10.0-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:2b0695d605ddcd3eb2f736cd8b4e388288c21e7de85001e9f85df9187f2b50f9"},
|
||||
{file = "mypy-1.10.0-cp310-cp310-win_amd64.whl", hash = "sha256:cd777b780312ddb135bceb9bc8722a73ec95e042f911cc279e2ec3c667076051"},
|
||||
{file = "mypy-1.10.0-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:3be66771aa5c97602f382230165b856c231d1277c511c9a8dd058be4784472e1"},
|
||||
{file = "mypy-1.10.0-cp311-cp311-macosx_11_0_arm64.whl", hash = "sha256:8b2cbaca148d0754a54d44121b5825ae71868c7592a53b7292eeb0f3fdae95ee"},
|
||||
{file = "mypy-1.10.0-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:1ec404a7cbe9fc0e92cb0e67f55ce0c025014e26d33e54d9e506a0f2d07fe5de"},
|
||||
{file = "mypy-1.10.0-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:e22e1527dc3d4aa94311d246b59e47f6455b8729f4968765ac1eacf9a4760bc7"},
|
||||
{file = "mypy-1.10.0-cp311-cp311-win_amd64.whl", hash = "sha256:a87dbfa85971e8d59c9cc1fcf534efe664d8949e4c0b6b44e8ca548e746a8d53"},
|
||||
{file = "mypy-1.10.0-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:a781f6ad4bab20eef8b65174a57e5203f4be627b46291f4589879bf4e257b97b"},
|
||||
{file = "mypy-1.10.0-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:b808e12113505b97d9023b0b5e0c0705a90571c6feefc6f215c1df9381256e30"},
|
||||
{file = "mypy-1.10.0-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:8f55583b12156c399dce2df7d16f8a5095291354f1e839c252ec6c0611e86e2e"},
|
||||
{file = "mypy-1.10.0-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:4cf18f9d0efa1b16478c4c129eabec36148032575391095f73cae2e722fcf9d5"},
|
||||
{file = "mypy-1.10.0-cp312-cp312-win_amd64.whl", hash = "sha256:bc6ac273b23c6b82da3bb25f4136c4fd42665f17f2cd850771cb600bdd2ebeda"},
|
||||
{file = "mypy-1.10.0-cp38-cp38-macosx_10_9_x86_64.whl", hash = "sha256:9fd50226364cd2737351c79807775136b0abe084433b55b2e29181a4c3c878c0"},
|
||||
{file = "mypy-1.10.0-cp38-cp38-macosx_11_0_arm64.whl", hash = "sha256:f90cff89eea89273727d8783fef5d4a934be2fdca11b47def50cf5d311aff727"},
|
||||
{file = "mypy-1.10.0-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:fcfc70599efde5c67862a07a1aaf50e55bce629ace26bb19dc17cece5dd31ca4"},
|
||||
{file = "mypy-1.10.0-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:075cbf81f3e134eadaf247de187bd604748171d6b79736fa9b6c9685b4083061"},
|
||||
{file = "mypy-1.10.0-cp38-cp38-win_amd64.whl", hash = "sha256:3f298531bca95ff615b6e9f2fc0333aae27fa48052903a0ac90215021cdcfa4f"},
|
||||
{file = "mypy-1.10.0-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:fa7ef5244615a2523b56c034becde4e9e3f9b034854c93639adb667ec9ec2976"},
|
||||
{file = "mypy-1.10.0-cp39-cp39-macosx_11_0_arm64.whl", hash = "sha256:3236a4c8f535a0631f85f5fcdffba71c7feeef76a6002fcba7c1a8e57c8be1ec"},
|
||||
{file = "mypy-1.10.0-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:4a2b5cdbb5dd35aa08ea9114436e0d79aceb2f38e32c21684dcf8e24e1e92821"},
|
||||
{file = "mypy-1.10.0-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:92f93b21c0fe73dc00abf91022234c79d793318b8a96faac147cd579c1671746"},
|
||||
{file = "mypy-1.10.0-cp39-cp39-win_amd64.whl", hash = "sha256:28d0e038361b45f099cc086d9dd99c15ff14d0188f44ac883010e172ce86c38a"},
|
||||
{file = "mypy-1.10.0-py3-none-any.whl", hash = "sha256:f8c083976eb530019175aabadb60921e73b4f45736760826aa1689dda8208aee"},
|
||||
{file = "mypy-1.10.0.tar.gz", hash = "sha256:3d087fcbec056c4ee34974da493a826ce316947485cef3901f511848e687c131"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2357,13 +2375,13 @@ test = ["flaky", "ipykernel (>=6.19.3)", "ipython", "ipywidgets", "nbconvert (>=
|
||||
|
||||
[[package]]
|
||||
name = "nbconvert"
|
||||
version = "7.16.3"
|
||||
version = "7.16.4"
|
||||
description = "Converting Jupyter Notebooks (.ipynb files) to other formats. Output formats include asciidoc, html, latex, markdown, pdf, py, rst, script. nbconvert can be used both as a Python library (`import nbconvert`) or as a command line tool (invoked as `jupyter nbconvert ...`)."
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "nbconvert-7.16.3-py3-none-any.whl", hash = "sha256:ddeff14beeeedf3dd0bc506623e41e4507e551736de59df69a91f86700292b3b"},
|
||||
{file = "nbconvert-7.16.3.tar.gz", hash = "sha256:a6733b78ce3d47c3f85e504998495b07e6ea9cf9bf6ec1c98dda63ec6ad19142"},
|
||||
{file = "nbconvert-7.16.4-py3-none-any.whl", hash = "sha256:05873c620fe520b6322bf8a5ad562692343fe3452abda5765c7a34b7d1aa3eb3"},
|
||||
{file = "nbconvert-7.16.4.tar.gz", hash = "sha256:86ca91ba266b0a448dc96fa6c5b9d98affabde2867b363258703536807f9f7f4"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2385,9 +2403,9 @@ tinycss2 = "*"
|
||||
traitlets = ">=5.1"
|
||||
|
||||
[package.extras]
|
||||
all = ["nbconvert[docs,qtpdf,serve,test,webpdf]"]
|
||||
all = ["flaky", "ipykernel", "ipython", "ipywidgets (>=7.5)", "myst-parser", "nbsphinx (>=0.2.12)", "playwright", "pydata-sphinx-theme", "pyqtwebengine (>=5.15)", "pytest (>=7)", "sphinx (==5.0.2)", "sphinxcontrib-spelling", "tornado (>=6.1)"]
|
||||
docs = ["ipykernel", "ipython", "myst-parser", "nbsphinx (>=0.2.12)", "pydata-sphinx-theme", "sphinx (==5.0.2)", "sphinxcontrib-spelling"]
|
||||
qtpdf = ["nbconvert[qtpng]"]
|
||||
qtpdf = ["pyqtwebengine (>=5.15)"]
|
||||
qtpng = ["pyqtwebengine (>=5.15)"]
|
||||
serve = ["tornado (>=6.1)"]
|
||||
test = ["flaky", "ipykernel", "ipywidgets (>=7.5)", "pytest (>=7)"]
|
||||
@@ -2815,13 +2833,13 @@ test = ["appdirs (==1.4.4)", "covdefaults (>=2.3)", "pytest (>=7.4.3)", "pytest-
|
||||
|
||||
[[package]]
|
||||
name = "pluggy"
|
||||
version = "1.4.0"
|
||||
version = "1.5.0"
|
||||
description = "plugin and hook calling mechanisms for python"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "pluggy-1.4.0-py3-none-any.whl", hash = "sha256:7db9f7b503d67d1c5b95f59773ebb58a8c1c288129a88665838012cfb07b8981"},
|
||||
{file = "pluggy-1.4.0.tar.gz", hash = "sha256:8c85c2876142a764e5b7548e7d9a0e0ddb46f5185161049a79b7e974454223be"},
|
||||
{file = "pluggy-1.5.0-py3-none-any.whl", hash = "sha256:44e1ad92c8ca002de6377e165f3e0f1be63266ab4d554740532335b9d75ea669"},
|
||||
{file = "pluggy-1.5.0.tar.gz", hash = "sha256:2cffa88e94fdc978c4c574f15f9e59b7f4201d439195c3715ca9e2486f1d0cf1"},
|
||||
]
|
||||
|
||||
[package.extras]
|
||||
@@ -3020,13 +3038,13 @@ tomli = {version = ">=1.1.0", markers = "python_version < \"3.11\""}
|
||||
|
||||
[[package]]
|
||||
name = "pytest"
|
||||
version = "8.1.1"
|
||||
version = "8.2.0"
|
||||
description = "pytest: simple powerful testing with Python"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "pytest-8.1.1-py3-none-any.whl", hash = "sha256:2a8386cfc11fa9d2c50ee7b2a57e7d898ef90470a7a34c4b949ff59662bb78b7"},
|
||||
{file = "pytest-8.1.1.tar.gz", hash = "sha256:ac978141a75948948817d360297b7aae0fcb9d6ff6bc9ec6d514b85d5a65c044"},
|
||||
{file = "pytest-8.2.0-py3-none-any.whl", hash = "sha256:1733f0620f6cda4095bbf0d9ff8022486e91892245bb9e7d5542c018f612f233"},
|
||||
{file = "pytest-8.2.0.tar.gz", hash = "sha256:d507d4482197eac0ba2bae2e9babf0672eb333017bcedaa5fb1a3d42c1174b3f"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -3034,11 +3052,11 @@ colorama = {version = "*", markers = "sys_platform == \"win32\""}
|
||||
exceptiongroup = {version = ">=1.0.0rc8", markers = "python_version < \"3.11\""}
|
||||
iniconfig = "*"
|
||||
packaging = "*"
|
||||
pluggy = ">=1.4,<2.0"
|
||||
pluggy = ">=1.5,<2.0"
|
||||
tomli = {version = ">=1", markers = "python_version < \"3.11\""}
|
||||
|
||||
[package.extras]
|
||||
testing = ["argcomplete", "attrs (>=19.2)", "hypothesis (>=3.56)", "mock", "pygments (>=2.7.2)", "requests", "setuptools", "xmlschema"]
|
||||
dev = ["argcomplete", "attrs (>=19.2)", "hypothesis (>=3.56)", "mock", "pygments (>=2.7.2)", "requests", "setuptools", "xmlschema"]
|
||||
|
||||
[[package]]
|
||||
name = "python-dateutil"
|
||||
@@ -3643,28 +3661,28 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "ruff"
|
||||
version = "0.4.1"
|
||||
version = "0.4.4"
|
||||
description = "An extremely fast Python linter and code formatter, written in Rust."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "ruff-0.4.1-py3-none-macosx_10_12_x86_64.macosx_11_0_arm64.macosx_10_12_universal2.whl", hash = "sha256:2d9ef6231e3fbdc0b8c72404a1a0c46fd0dcea84efca83beb4681c318ea6a953"},
|
||||
{file = "ruff-0.4.1-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:9485f54a7189e6f7433e0058cf8581bee45c31a25cd69009d2a040d1bd4bfaef"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:d2921ac03ce1383e360e8a95442ffb0d757a6a7ddd9a5be68561a671e0e5807e"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:eec8d185fe193ad053eda3a6be23069e0c8ba8c5d20bc5ace6e3b9e37d246d3f"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:baa27d9d72a94574d250f42b7640b3bd2edc4c58ac8ac2778a8c82374bb27984"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:f1ee41580bff1a651339eb3337c20c12f4037f6110a36ae4a2d864c52e5ef954"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:0926cefb57fc5fced629603fbd1a23d458b25418681d96823992ba975f050c2b"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:2c6e37f2e3cd74496a74af9a4fa67b547ab3ca137688c484749189bf3a686ceb"},
|
||||
{file = "ruff-0.4.1-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:efd703a5975ac1998c2cc5e9494e13b28f31e66c616b0a76e206de2562e0843c"},
|
||||
{file = "ruff-0.4.1-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:b92f03b4aa9fa23e1799b40f15f8b95cdc418782a567d6c43def65e1bbb7f1cf"},
|
||||
{file = "ruff-0.4.1-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:1c859f294f8633889e7d77de228b203eb0e9a03071b72b5989d89a0cf98ee262"},
|
||||
{file = "ruff-0.4.1-py3-none-musllinux_1_2_i686.whl", hash = "sha256:b34510141e393519a47f2d7b8216fec747ea1f2c81e85f076e9f2910588d4b64"},
|
||||
{file = "ruff-0.4.1-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:6e68d248ed688b9d69fd4d18737edcbb79c98b251bba5a2b031ce2470224bdf9"},
|
||||
{file = "ruff-0.4.1-py3-none-win32.whl", hash = "sha256:b90506f3d6d1f41f43f9b7b5ff845aeefabed6d2494307bc7b178360a8805252"},
|
||||
{file = "ruff-0.4.1-py3-none-win_amd64.whl", hash = "sha256:c7d391e5936af5c9e252743d767c564670dc3889aff460d35c518ee76e4b26d7"},
|
||||
{file = "ruff-0.4.1-py3-none-win_arm64.whl", hash = "sha256:a1eaf03d87e6a7cd5e661d36d8c6e874693cb9bc3049d110bc9a97b350680c43"},
|
||||
{file = "ruff-0.4.1.tar.gz", hash = "sha256:d592116cdbb65f8b1b7e2a2b48297eb865f6bdc20641879aa9d7b9c11d86db79"},
|
||||
{file = "ruff-0.4.4-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:29d44ef5bb6a08e235c8249294fa8d431adc1426bfda99ed493119e6f9ea1bf6"},
|
||||
{file = "ruff-0.4.4-py3-none-macosx_11_0_arm64.whl", hash = "sha256:c4efe62b5bbb24178c950732ddd40712b878a9b96b1d02b0ff0b08a090cbd891"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:4c8e2f1e8fc12d07ab521a9005d68a969e167b589cbcaee354cb61e9d9de9c15"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:60ed88b636a463214905c002fa3eaab19795679ed55529f91e488db3fe8976ab"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:b90fc5e170fc71c712cc4d9ab0e24ea505c6a9e4ebf346787a67e691dfb72e85"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:8e7e6ebc10ef16dcdc77fd5557ee60647512b400e4a60bdc4849468f076f6eef"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:b9ddb2c494fb79fc208cd15ffe08f32b7682519e067413dbaf5f4b01a6087bcd"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:c51c928a14f9f0a871082603e25a1588059b7e08a920f2f9fa7157b5bf08cfe9"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:b5eb0a4bfd6400b7d07c09a7725e1a98c3b838be557fee229ac0f84d9aa49c36"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:b1867ee9bf3acc21778dcb293db504692eda5f7a11a6e6cc40890182a9f9e595"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:1aecced1269481ef2894cc495647392a34b0bf3e28ff53ed95a385b13aa45768"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_i686.whl", hash = "sha256:9da73eb616b3241a307b837f32756dc20a0b07e2bcb694fec73699c93d04a69e"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:958b4ea5589706a81065e2a776237de2ecc3e763342e5cc8e02a4a4d8a5e6f95"},
|
||||
{file = "ruff-0.4.4-py3-none-win32.whl", hash = "sha256:cb53473849f011bca6e754f2cdf47cafc9c4f4ff4570003a0dad0b9b6890e876"},
|
||||
{file = "ruff-0.4.4-py3-none-win_amd64.whl", hash = "sha256:424e5b72597482543b684c11def82669cc6b395aa8cc69acc1858b5ef3e5daae"},
|
||||
{file = "ruff-0.4.4-py3-none-win_arm64.whl", hash = "sha256:39df0537b47d3b597293edbb95baf54ff5b49589eb7ff41926d8243caa995ea6"},
|
||||
{file = "ruff-0.4.4.tar.gz", hash = "sha256:f87ea42d5cdebdc6a69761a9d0bc83ae9b3b30d0ad78952005ba6568d6c022af"},
|
||||
]
|
||||
|
||||
[[package]]
|
||||
@@ -3896,17 +3914,6 @@ webencodings = ">=0.4"
|
||||
doc = ["sphinx", "sphinx_rtd_theme"]
|
||||
test = ["flake8", "isort", "pytest"]
|
||||
|
||||
[[package]]
|
||||
name = "toml"
|
||||
version = "0.10.2"
|
||||
description = "Python Library for Tom's Obvious, Minimal Language"
|
||||
optional = false
|
||||
python-versions = ">=2.6, !=3.0.*, !=3.1.*, !=3.2.*"
|
||||
files = [
|
||||
{file = "toml-0.10.2-py2.py3-none-any.whl", hash = "sha256:806143ae5bfb6a3c6e736a764057db0e6a0e05e338b5630894a5f779cabb4f9b"},
|
||||
{file = "toml-0.10.2.tar.gz", hash = "sha256:b3bda1d108d5dd99f4a20d24d9c348e91c4db7ab1b749200bded2f839ccbe68f"},
|
||||
]
|
||||
|
||||
[[package]]
|
||||
name = "tomli"
|
||||
version = "2.0.1"
|
||||
@@ -3940,13 +3947,13 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "tox"
|
||||
version = "4.14.2"
|
||||
version = "4.15.0"
|
||||
description = "tox is a generic virtualenv management and test command line tool"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "tox-4.14.2-py3-none-any.whl", hash = "sha256:2900c4eb7b716af4a928a7fdc2ed248ad6575294ed7cfae2ea41203937422847"},
|
||||
{file = "tox-4.14.2.tar.gz", hash = "sha256:0defb44f6dafd911b61788325741cc6b2e12ea71f987ac025ad4d649f1f1a104"},
|
||||
{file = "tox-4.15.0-py3-none-any.whl", hash = "sha256:300055f335d855b2ab1b12c5802de7f62a36d4fd53f30bd2835f6a201dda46ea"},
|
||||
{file = "tox-4.15.0.tar.gz", hash = "sha256:7a0beeef166fbe566f54f795b4906c31b428eddafc0102ac00d20998dd1933f6"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -3967,13 +3974,13 @@ testing = ["build[virtualenv] (>=1.0.3)", "covdefaults (>=2.3)", "detect-test-po
|
||||
|
||||
[[package]]
|
||||
name = "tqdm"
|
||||
version = "4.66.2"
|
||||
version = "4.66.4"
|
||||
description = "Fast, Extensible Progress Meter"
|
||||
optional = true
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "tqdm-4.66.2-py3-none-any.whl", hash = "sha256:1ee4f8a893eb9bef51c6e35730cebf234d5d0b6bd112b0271e10ed7c24a02bd9"},
|
||||
{file = "tqdm-4.66.2.tar.gz", hash = "sha256:6cd52cdf0fef0e0f543299cfc96fec90d7b8a7e88745f411ec33eb44d5ed3531"},
|
||||
{file = "tqdm-4.66.4-py3-none-any.whl", hash = "sha256:b75ca56b413b030bc3f00af51fd2c1a1a5eac6a0c1cca83cbb37a5c52abce644"},
|
||||
{file = "tqdm-4.66.4.tar.gz", hash = "sha256:e4d936c9de8727928f3be6079590e97d9abfe8d39a590be678eb5919ffc186bb"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -4250,4 +4257,4 @@ desktop = ["opencv-python"]
|
||||
[metadata]
|
||||
lock-version = "2.0"
|
||||
python-versions = "^3.8"
|
||||
content-hash = "56ddae6824a9f28c9954badd4c642c57f687b099c6169f97fa0372e294500c17"
|
||||
content-hash = "29af5aa06f97e77a2dba94c5a6d77d7d1903448724df07416026a378d3c6a64d"
|
||||
|
||||
+3
-3
@@ -1,6 +1,6 @@
|
||||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.20.0"
|
||||
version = "0.21.0rc5"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
@@ -43,7 +43,7 @@ defusedxml = "^0.7.1"
|
||||
opencv-python = { version = ">=4.5.5.64", optional = true }
|
||||
opencv-python-headless = ">=4.5.5.64"
|
||||
requests = { version = ">=2.26.0,<=2.31.0", optional = true }
|
||||
tqdm = { version = ">=4.62.3,<=4.66.2", optional = true }
|
||||
tqdm = { version = ">=4.62.3,<=4.66.4", optional = true }
|
||||
pillow = ">=9.4"
|
||||
|
||||
[tool.poetry.extras]
|
||||
@@ -67,7 +67,7 @@ nbconvert = "^7.14.2"
|
||||
|
||||
[tool.poetry.group.docs.dependencies]
|
||||
mkdocs-material = {extras = ["imaging"], version = "^9.5.5"}
|
||||
mkdocstrings = {extras = ["python"], version = ">=0.20,<0.25"}
|
||||
mkdocstrings = {extras = ["python"], version = ">=0.20,<0.26"}
|
||||
mike = "^2.0.0"
|
||||
# For Documentation Development use Python 3.10 or above
|
||||
# Use Latest mkdocs-jupyter min 0.24.6 for Jupyter Notebook Theme support
|
||||
|
||||
@@ -46,12 +46,15 @@ from supervision.detection.utils import (
|
||||
box_iou_batch,
|
||||
box_non_max_suppression,
|
||||
calculate_masks_centroids,
|
||||
clip_boxes,
|
||||
filter_polygons_by_area,
|
||||
mask_iou_batch,
|
||||
mask_non_max_suppression,
|
||||
mask_to_polygons,
|
||||
mask_to_xyxy,
|
||||
move_boxes,
|
||||
move_masks,
|
||||
pad_boxes,
|
||||
polygon_to_mask,
|
||||
polygon_to_xyxy,
|
||||
scale_boxes,
|
||||
@@ -69,7 +72,11 @@ from supervision.draw.utils import (
|
||||
)
|
||||
from supervision.geometry.core import Point, Position, Rect
|
||||
from supervision.geometry.utils import get_polygon_center
|
||||
from supervision.keypoint.annotators import EdgeAnnotator, VertexAnnotator
|
||||
from supervision.keypoint.annotators import (
|
||||
EdgeAnnotator,
|
||||
VertexAnnotator,
|
||||
VertexLabelAnnotator,
|
||||
)
|
||||
from supervision.keypoint.core import KeyPoints
|
||||
from supervision.metrics.detection import ConfusionMatrix, MeanAveragePrecision
|
||||
from supervision.tracker.byte_tracker.core import ByteTrack
|
||||
|
||||
@@ -418,6 +418,9 @@ class Detections:
|
||||
xyxy=mmdet_results.pred_instances.bboxes.cpu().numpy(),
|
||||
confidence=mmdet_results.pred_instances.scores.cpu().numpy(),
|
||||
class_id=mmdet_results.pred_instances.labels.cpu().numpy().astype(int),
|
||||
mask=mmdet_results.pred_instances.masks.cpu().numpy()
|
||||
if "masks" in mmdet_results.pred_instances
|
||||
else None,
|
||||
)
|
||||
|
||||
@classmethod
|
||||
@@ -831,9 +834,10 @@ class Detections:
|
||||
|
||||
This method takes a list of Detections objects and combines their
|
||||
respective fields (`xyxy`, `mask`, `confidence`, `class_id`, and `tracker_id`)
|
||||
into a single Detections object. If all elements in a field are not
|
||||
`None`, the corresponding field will be stacked.
|
||||
Otherwise, the field will be set to `None`.
|
||||
into a single Detections object.
|
||||
|
||||
For example, if merging Detections with 3 and 4 detected objects, this method
|
||||
will return a Detections with 7 objects (7 entries in `xyxy`, `mask`, etc).
|
||||
|
||||
Args:
|
||||
detections_list (List[Detections]): A list of Detections objects to merge.
|
||||
@@ -891,13 +895,12 @@ class Detections:
|
||||
def stack_or_none(name: str):
|
||||
if all(d.__getattribute__(name) is None for d in detections_list):
|
||||
return None
|
||||
if any(d.__getattribute__(name) is None for d in detections_list):
|
||||
raise ValueError(f"All or none of the '{name}' fields must be None")
|
||||
return (
|
||||
np.vstack([d.__getattribute__(name) for d in detections_list])
|
||||
if name == "mask"
|
||||
else np.hstack([d.__getattribute__(name) for d in detections_list])
|
||||
)
|
||||
stack_list = [
|
||||
d.__getattribute__(name)
|
||||
for d in detections_list
|
||||
if d.__getattribute__(name) is not None
|
||||
]
|
||||
return np.vstack(stack_list) if name == "mask" else np.hstack(stack_list)
|
||||
|
||||
mask = stack_or_none("mask")
|
||||
confidence = stack_or_none("confidence")
|
||||
|
||||
@@ -4,20 +4,36 @@ from typing import Callable, Optional, Tuple
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.detection.utils import move_boxes
|
||||
from supervision.detection.utils import move_boxes, move_masks
|
||||
from supervision.utils.image import crop_image
|
||||
|
||||
|
||||
def move_detections(detections: Detections, offset: np.array) -> Detections:
|
||||
def move_detections(
|
||||
detections: Detections,
|
||||
offset: np.ndarray,
|
||||
resolution_wh: Optional[Tuple[int, int]] = None,
|
||||
) -> Detections:
|
||||
"""
|
||||
Args:
|
||||
detections (sv.Detections): Detections object to be moved.
|
||||
offset (np.array): An array of shape `(2,)` containing offset values in format
|
||||
offset (np.ndarray): An array of shape `(2,)` containing offset values in format
|
||||
is `[dx, dy]`.
|
||||
resolution_wh (Tuple[int, int]): The width and height of the desired mask
|
||||
resolution. Required for segmentation detections.
|
||||
|
||||
Returns:
|
||||
(sv.Detections) repositioned Detections object.
|
||||
"""
|
||||
detections.xyxy = move_boxes(xyxy=detections.xyxy, offset=offset)
|
||||
if detections.mask is not None:
|
||||
if resolution_wh is None:
|
||||
raise ValueError(
|
||||
"Resolution width and height are required for moving segmentation "
|
||||
"detections. This should be the same as (width, height) of image shape."
|
||||
)
|
||||
detections.mask = move_masks(
|
||||
masks=detections.mask, offset=offset, resolution_wh=resolution_wh
|
||||
)
|
||||
return detections
|
||||
|
||||
|
||||
@@ -126,7 +142,10 @@ class InferenceSlicer:
|
||||
"""
|
||||
image_slice = crop_image(image=image, xyxy=offset)
|
||||
detections = self.callback(image_slice)
|
||||
detections = move_detections(detections=detections, offset=offset[:2])
|
||||
resolution_wh = (image.shape[1], image.shape[0])
|
||||
detections = move_detections(
|
||||
detections=detections, offset=offset[:2], resolution_wh=resolution_wh
|
||||
)
|
||||
|
||||
return detections
|
||||
|
||||
|
||||
@@ -297,6 +297,35 @@ def clip_boxes(xyxy: np.ndarray, resolution_wh: Tuple[int, int]) -> np.ndarray:
|
||||
return result
|
||||
|
||||
|
||||
def pad_boxes(xyxy: np.ndarray, px: int, py: Optional[int] = None) -> np.ndarray:
|
||||
"""
|
||||
Pads bounding boxes coordinates with a constant padding.
|
||||
|
||||
Args:
|
||||
xyxy (np.ndarray): A numpy array of shape `(N, 4)` where each
|
||||
row corresponds to a bounding box in the format
|
||||
`(x_min, y_min, x_max, y_max)`.
|
||||
px (int): The padding value to be added to both the left and right sides of
|
||||
each bounding box.
|
||||
py (Optional[int]): The padding value to be added to both the top and bottom
|
||||
sides of each bounding box. If not provided, `px` will be used for both
|
||||
dimensions.
|
||||
|
||||
Returns:
|
||||
np.ndarray: A numpy array of shape `(N, 4)` where each row corresponds to a
|
||||
bounding box with coordinates padded according to the provided padding
|
||||
values.
|
||||
"""
|
||||
if py is None:
|
||||
py = px
|
||||
|
||||
result = xyxy.copy()
|
||||
result[:, [0, 1]] -= [px, py]
|
||||
result[:, [2, 3]] += [px, py]
|
||||
|
||||
return result
|
||||
|
||||
|
||||
def xywh_to_xyxy(boxes_xywh: np.ndarray) -> np.ndarray:
|
||||
xyxy = boxes_xywh.copy()
|
||||
xyxy[:, 2] = boxes_xywh[:, 0] + boxes_xywh[:, 2]
|
||||
@@ -500,7 +529,7 @@ def process_roboflow_result(
|
||||
np.ndarray,
|
||||
Optional[np.ndarray],
|
||||
Optional[np.ndarray],
|
||||
Dict[str, List[np.ndarray]],
|
||||
Dict[str, Union[List[np.ndarray], np.ndarray]],
|
||||
]:
|
||||
if not roboflow_result["predictions"]:
|
||||
return (
|
||||
@@ -592,6 +621,40 @@ def move_boxes(xyxy: np.ndarray, offset: np.ndarray) -> np.ndarray:
|
||||
return xyxy + np.hstack([offset, offset])
|
||||
|
||||
|
||||
def move_masks(
|
||||
masks: np.ndarray,
|
||||
offset: np.ndarray,
|
||||
resolution_wh: Tuple[int, int] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Offset the masks in an array by the specified (x, y) amount.
|
||||
|
||||
Args:
|
||||
masks (np.ndarray): A 3D array of binary masks corresponding to the predictions.
|
||||
Shape: `(N, H, W)`, where N is the number of predictions, and H, W are the
|
||||
dimensions of each mask.
|
||||
offset (np.ndarray): An array of shape `(2,)` containing non-negative int values
|
||||
`[dx, dy]`.
|
||||
resolution_wh (Tuple[int, int]): The width and height of the desired mask
|
||||
resolution.
|
||||
|
||||
Returns:
|
||||
(np.ndarray) repositioned masks, optionally padded to the specified shape.
|
||||
"""
|
||||
|
||||
if offset[0] < 0 or offset[1] < 0:
|
||||
raise ValueError(f"Offset values must be non-negative integers. Got: {offset}")
|
||||
|
||||
mask_array = np.full((masks.shape[0], resolution_wh[1], resolution_wh[0]), False)
|
||||
mask_array[
|
||||
:,
|
||||
offset[1] : masks.shape[1] + offset[1],
|
||||
offset[0] : masks.shape[2] + offset[0],
|
||||
] = masks
|
||||
|
||||
return mask_array
|
||||
|
||||
|
||||
def scale_boxes(xyxy: np.ndarray, factor: float) -> np.ndarray:
|
||||
"""
|
||||
Scale the dimensions of bounding boxes.
|
||||
@@ -678,7 +741,9 @@ def merge_data(
|
||||
Merges the data payloads of a list of Detections instances.
|
||||
|
||||
Args:
|
||||
data_list: The data payloads of the instances.
|
||||
data_list: The data payloads of the Detections instances. Each data payload
|
||||
is a dictionary with the same keys, and the values are either lists or
|
||||
np.ndarray.
|
||||
|
||||
Returns:
|
||||
A single data payload containing the merged data, preserving the original data
|
||||
@@ -691,10 +756,6 @@ def merge_data(
|
||||
if not data_list:
|
||||
return {}
|
||||
|
||||
all_keys_sets = [set(data.keys()) for data in data_list]
|
||||
if not all(keys_set == all_keys_sets[0] for keys_set in all_keys_sets):
|
||||
raise ValueError("All data dictionaries must have the same keys to merge.")
|
||||
|
||||
for data in data_list:
|
||||
lengths = [len(value) for value in data.values()]
|
||||
if len(set(lengths)) > 1:
|
||||
@@ -702,10 +763,23 @@ def merge_data(
|
||||
"All data values within a single object must have equal length."
|
||||
)
|
||||
|
||||
merged_data = {key: [] for key in all_keys_sets[0]}
|
||||
keys_by_data = [set(data.keys()) for data in data_list]
|
||||
keys_by_data = [keys for keys in keys_by_data if len(keys) > 0]
|
||||
if not keys_by_data:
|
||||
return {}
|
||||
|
||||
common_keys = set.intersection(*keys_by_data)
|
||||
all_keys = set.union(*keys_by_data)
|
||||
if common_keys != all_keys:
|
||||
raise ValueError(
|
||||
f"All sv.Detections.data dictionaries must have the same keys. Common "
|
||||
f"keys: {common_keys}, but some dictionaries have additional keys: "
|
||||
f"{all_keys.difference(common_keys)}."
|
||||
)
|
||||
|
||||
merged_data = {key: [] for key in all_keys}
|
||||
for data in data_list:
|
||||
for key in merged_data:
|
||||
for key in data:
|
||||
merged_data[key].append(data[key])
|
||||
|
||||
for key in merged_data:
|
||||
|
||||
@@ -81,6 +81,58 @@ def draw_filled_rectangle(scene: np.ndarray, rect: Rect, color: Color) -> np.nda
|
||||
return scene
|
||||
|
||||
|
||||
def draw_rounded_rectangle(
|
||||
scene: np.ndarray,
|
||||
rect: Rect,
|
||||
color: Color,
|
||||
border_radius: int,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Draws a rounded rectangle on an image.
|
||||
|
||||
Parameters:
|
||||
scene (np.ndarray): The image on which the rounded rectangle will be drawn.
|
||||
rect (Rect): The rectangle to be drawn.
|
||||
color (Color): The color of the rounded rectangle.
|
||||
border_radius (int): The radius of the corner rounding.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The image with the rounded rectangle drawn on it.
|
||||
"""
|
||||
x1, y1, x2, y2 = rect.as_xyxy_int_tuple()
|
||||
width, height = x2 - x1, y2 - y1
|
||||
border_radius = min(border_radius, min(width, height) // 2)
|
||||
|
||||
rectangle_coordinates = [
|
||||
((x1 + border_radius, y1), (x2 - border_radius, y2)),
|
||||
((x1, y1 + border_radius), (x2, y2 - border_radius)),
|
||||
]
|
||||
circle_centers = [
|
||||
(x1 + border_radius, y1 + border_radius),
|
||||
(x2 - border_radius, y1 + border_radius),
|
||||
(x1 + border_radius, y2 - border_radius),
|
||||
(x2 - border_radius, y2 - border_radius),
|
||||
]
|
||||
|
||||
for coordinates in rectangle_coordinates:
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=coordinates[0],
|
||||
pt2=coordinates[1],
|
||||
color=color.as_bgr(),
|
||||
thickness=-1,
|
||||
)
|
||||
for center in circle_centers:
|
||||
cv2.circle(
|
||||
img=scene,
|
||||
center=center,
|
||||
radius=border_radius,
|
||||
color=color.as_bgr(),
|
||||
thickness=-1,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
def draw_polygon(
|
||||
scene: np.ndarray, polygon: np.ndarray, color: Color, thickness: int = 2
|
||||
) -> np.ndarray:
|
||||
|
||||
@@ -98,6 +98,11 @@ class Rect:
|
||||
width: float
|
||||
height: float
|
||||
|
||||
@classmethod
|
||||
def from_xyxy(cls, xyxy: Tuple[float, float, float, float]) -> Rect:
|
||||
x1, y1, x2, y2 = xyxy
|
||||
return cls(x=x1, y=y1, width=x2 - x1, height=y2 - y1)
|
||||
|
||||
@property
|
||||
def top_left(self) -> Point:
|
||||
return Point(x=self.x, y=self.y)
|
||||
@@ -113,3 +118,11 @@ class Rect:
|
||||
width=self.width + 2 * padding,
|
||||
height=self.height + 2 * padding,
|
||||
)
|
||||
|
||||
def as_xyxy_int_tuple(self) -> Tuple[int, int, int, int]:
|
||||
return (
|
||||
int(self.x),
|
||||
int(self.y),
|
||||
int(self.x + self.width),
|
||||
int(self.y + self.height),
|
||||
)
|
||||
|
||||
@@ -1,12 +1,14 @@
|
||||
from abc import ABC, abstractmethod
|
||||
from logging import warn
|
||||
from typing import List, Optional, Tuple
|
||||
from typing import List, Optional, Tuple, Union
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
from supervision import Rect, pad_boxes
|
||||
from supervision.annotators.base import ImageType
|
||||
from supervision.draw.color import Color
|
||||
from supervision.draw.utils import draw_rounded_rectangle
|
||||
from supervision.keypoint.core import KeyPoints
|
||||
from supervision.keypoint.skeletons import SKELETONS_BY_VERTEX_COUNT
|
||||
from supervision.utils.conversion import convert_for_annotation_method
|
||||
@@ -46,8 +48,8 @@ class VertexAnnotator(BaseKeyPointAnnotator):
|
||||
points. It draws circles at each key point location.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where bounding boxes will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
scene (ImageType): The image where skeleton vertices will be drawn.
|
||||
`ImageType` is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
consists of x and y coordinates.
|
||||
@@ -63,7 +65,10 @@ class VertexAnnotator(BaseKeyPointAnnotator):
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_annotator = sv.VertexAnnotator(color=sv.Color.GREEN, radius=10)
|
||||
vertex_annotator = sv.VertexAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
radius=10
|
||||
)
|
||||
annotated_frame = vertex_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -119,7 +124,7 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
edges.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where bounding boxes will be drawn. `ImageType`
|
||||
scene (ImageType): The image where skeleton edges will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
@@ -137,7 +142,10 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
edge_annotator = sv.EdgeAnnotator(color=sv.Color.GREEN, thickness=5)
|
||||
edge_annotator = sv.EdgeAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
thickness=5
|
||||
)
|
||||
annotated_frame = edge_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -175,3 +183,236 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
|
||||
class VertexLabelAnnotator:
|
||||
"""
|
||||
A class that draws labels of skeleton vertices on images. It uses specified key
|
||||
points to determine the locations where the vertices should be drawn.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, List[Color]] = Color.ROBOFLOW,
|
||||
text_color: Color = Color.WHITE,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
border_radius: int = 0,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, List[Color]], optional): The color to use for each
|
||||
keypoint label. If a list is provided, the colors will be used in order
|
||||
for each keypoint.
|
||||
text_color (Color, optional): The color to use for the labels.
|
||||
text_scale (float, optional): The scale of the text.
|
||||
text_thickness (int, optional): The thickness of the text.
|
||||
text_padding (int, optional): The padding around the text.
|
||||
border_radius (int, optional): The radius of the rounded corners of the
|
||||
boxes. Set to a high value to produce circles.
|
||||
"""
|
||||
self.border_radius: int = border_radius
|
||||
self.color: Union[Color, List[Color]] = color
|
||||
self.text_color: Color = text_color
|
||||
self.text_scale: float = text_scale
|
||||
self.text_thickness: int = text_thickness
|
||||
self.text_padding: int = text_padding
|
||||
|
||||
def annotate(
|
||||
self, scene: ImageType, key_points: KeyPoints, labels: List[str] = None
|
||||
) -> ImageType:
|
||||
"""
|
||||
A class that draws labels of skeleton vertices on images. It uses specified key
|
||||
points to determine the locations where the vertices should be drawn.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where vertex labels will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
consists of x and y coordinates.
|
||||
labels (List[str], optional): A list of labels to be displayed on the
|
||||
annotated image. If not provided, keypoint indices will be used.
|
||||
|
||||
Returns:
|
||||
The annotated image, matching the type of `scene` (`numpy.ndarray`
|
||||
or `PIL.Image.Image`)
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
)
|
||||
```
|
||||
|
||||

|
||||
|
||||
!!! tip
|
||||
|
||||
`VertexLabelAnnotator` allows to customize the color of each keypoint label
|
||||
values.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
LABELS = [
|
||||
"nose", "left eye", "right eye", "left ear",
|
||||
"right ear", "left shoulder", "right shoulder", "left elbow",
|
||||
"right elbow", "left wrist", "right wrist", "left hip",
|
||||
"right hip", "left knee", "right knee", "left ankle",
|
||||
"right ankle"
|
||||
]
|
||||
|
||||
COLORS = [
|
||||
"#FF6347", "#FF6347", "#FF6347", "#FF6347",
|
||||
"#FF6347", "#FF1493", "#00FF00", "#FF1493",
|
||||
"#00FF00", "#FF1493", "#00FF00", "#FFD700",
|
||||
"#00BFFF", "#FFD700", "#00BFFF", "#FFD700",
|
||||
"#00BFFF"
|
||||
]
|
||||
COLORS = [sv.Color.from_hex(color_hex=c) for c in COLORS]
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=COLORS,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points,
|
||||
labels=labels
|
||||
)
|
||||
```
|
||||

|
||||
"""
|
||||
font = cv2.FONT_HERSHEY_SIMPLEX
|
||||
|
||||
skeletons_count, points_count, _ = key_points.xy.shape
|
||||
if skeletons_count == 0:
|
||||
return scene
|
||||
|
||||
anchors = key_points.xy.reshape(points_count * skeletons_count, 2).astype(int)
|
||||
mask = np.all(anchors != 0, axis=1)
|
||||
|
||||
if not np.any(mask):
|
||||
return scene
|
||||
|
||||
colors = self.preprocess_and_validate_colors(
|
||||
colors=self.color,
|
||||
points_count=points_count,
|
||||
skeletons_count=skeletons_count,
|
||||
)
|
||||
|
||||
labels = self.preprocess_and_validate_labels(
|
||||
labels=labels, points_count=points_count, skeletons_count=skeletons_count
|
||||
)
|
||||
|
||||
anchors = anchors[mask]
|
||||
colors = colors[mask]
|
||||
labels = labels[mask]
|
||||
|
||||
xyxy = np.array(
|
||||
[
|
||||
self.get_text_bounding_box(
|
||||
text=label,
|
||||
font=font,
|
||||
text_scale=self.text_scale,
|
||||
text_thickness=self.text_thickness,
|
||||
center_coordinates=tuple(anchor),
|
||||
)
|
||||
for anchor, label in zip(anchors, labels)
|
||||
]
|
||||
)
|
||||
|
||||
xyxy_padded = pad_boxes(xyxy=xyxy, px=self.text_padding)
|
||||
|
||||
for text, color, box, box_padded in zip(labels, colors, xyxy, xyxy_padded):
|
||||
draw_rounded_rectangle(
|
||||
scene=scene,
|
||||
rect=Rect.from_xyxy(box_padded),
|
||||
color=color,
|
||||
border_radius=self.border_radius,
|
||||
)
|
||||
cv2.putText(
|
||||
img=scene,
|
||||
text=text,
|
||||
org=(box[0], box[1] + self.text_padding),
|
||||
fontFace=font,
|
||||
fontScale=self.text_scale,
|
||||
color=self.text_color.as_rgb(),
|
||||
thickness=self.text_thickness,
|
||||
lineType=cv2.LINE_AA,
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
@staticmethod
|
||||
def get_text_bounding_box(
|
||||
text: str,
|
||||
font: int,
|
||||
text_scale: float,
|
||||
text_thickness: int,
|
||||
center_coordinates: Tuple[int, int],
|
||||
) -> Tuple[int, int, int, int]:
|
||||
text_w, text_h = cv2.getTextSize(
|
||||
text=text,
|
||||
fontFace=font,
|
||||
fontScale=text_scale,
|
||||
thickness=text_thickness,
|
||||
)[0]
|
||||
center_x, center_y = center_coordinates
|
||||
return (
|
||||
center_x - text_w // 2,
|
||||
center_y - text_h // 2,
|
||||
center_x + text_w // 2,
|
||||
center_y + text_h // 2,
|
||||
)
|
||||
|
||||
@staticmethod
|
||||
def preprocess_and_validate_labels(
|
||||
labels: Optional[List[str]], points_count: int, skeletons_count: int
|
||||
) -> np.array:
|
||||
if labels and len(labels) != points_count:
|
||||
raise ValueError(
|
||||
f"Number of labels ({len(labels)}) must match number of key points "
|
||||
f"({points_count})."
|
||||
)
|
||||
if labels is None:
|
||||
labels = [str(i) for i in range(points_count)]
|
||||
|
||||
return np.array(labels * skeletons_count)
|
||||
|
||||
@staticmethod
|
||||
def preprocess_and_validate_colors(
|
||||
colors: Optional[Union[Color, List[Color]]],
|
||||
points_count: int,
|
||||
skeletons_count: int,
|
||||
) -> np.array:
|
||||
if isinstance(colors, list) and len(colors) != points_count:
|
||||
raise ValueError(
|
||||
f"Number of colors ({len(colors)}) must match number of key points "
|
||||
f"({points_count})."
|
||||
)
|
||||
return (
|
||||
np.array(colors * skeletons_count)
|
||||
if isinstance(colors, list)
|
||||
else np.array([colors] * points_count * skeletons_count)
|
||||
)
|
||||
|
||||
@@ -1,5 +1,6 @@
|
||||
from __future__ import annotations
|
||||
|
||||
from contextlib import suppress
|
||||
from dataclasses import dataclass, field
|
||||
from typing import Any, Dict, Iterator, List, Optional, Tuple, Union
|
||||
|
||||
@@ -100,10 +101,94 @@ class KeyPoints:
|
||||
]
|
||||
)
|
||||
|
||||
@classmethod
|
||||
def from_inference(cls, inference_result: Union[dict, Any]) -> KeyPoints:
|
||||
"""
|
||||
Create a `sv.KeyPoints` object from the [Roboflow](https://roboflow.com/)
|
||||
API inference result or the [Inference](https://inference.roboflow.com/)
|
||||
package results. When a keypoint detection model is used, this method
|
||||
extracts the keypoint coordinates, class IDs, confidences, and class names.
|
||||
|
||||
Args:
|
||||
inference_result (dict, any): The result from the
|
||||
Roboflow API or Inference package containing predictions with keypoints.
|
||||
|
||||
Returns:
|
||||
(KeyPoints): A KeyPoints object containing the keypoint coordinates,
|
||||
class IDs, and confidences of each keypoint.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
model = get_model(model_id=<POSE_MODEL_ID>, api_key=<ROBOFLOW_API_KEY>)
|
||||
|
||||
result = model.infer(image)[0]
|
||||
key_points = sv.KeyPoints.from_inference(result)
|
||||
```
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference_sdk import InferenceHTTPClient
|
||||
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
client = InferenceHTTPClient(
|
||||
api_url="https://detect.roboflow.com",
|
||||
api_key=<ROBOFLOW_API_KEY>
|
||||
)
|
||||
|
||||
result = client.infer(image, model_id=<POSE_MODEL_ID>)
|
||||
key_points = sv.KeyPoints.from_inference(result)
|
||||
```
|
||||
"""
|
||||
if isinstance(inference_result, list):
|
||||
raise ValueError(
|
||||
"from_inference() operates on a single result at a time."
|
||||
"You can retrieve it like so: inference_result = model.infer(image)[0]"
|
||||
)
|
||||
|
||||
# Unpack the result if received from inference.get_model,
|
||||
# rather than inference_sdk.InferenceHTTPClient
|
||||
with suppress(AttributeError):
|
||||
inference_result = inference_result.dict(exclude_none=True, by_alias=True)
|
||||
|
||||
if not inference_result.get("predictions"):
|
||||
return cls.empty()
|
||||
|
||||
xy = []
|
||||
confidence = []
|
||||
class_id = []
|
||||
class_names = []
|
||||
|
||||
for prediction in inference_result["predictions"]:
|
||||
prediction_xy = []
|
||||
prediction_confidence = []
|
||||
for keypoint in prediction["keypoints"]:
|
||||
prediction_xy.append([keypoint["x"], keypoint["y"]])
|
||||
prediction_confidence.append(keypoint["confidence"])
|
||||
xy.append(prediction_xy)
|
||||
confidence.append(prediction_confidence)
|
||||
|
||||
class_id.append(prediction["class_id"])
|
||||
class_names.append(prediction["class"])
|
||||
|
||||
data = {CLASS_NAME_DATA_FIELD: np.array(class_names)}
|
||||
|
||||
return cls(
|
||||
xy=np.array(xy, dtype=np.float32),
|
||||
confidence=np.array(confidence, dtype=np.float32),
|
||||
class_id=np.array(class_id, dtype=int),
|
||||
data=data,
|
||||
)
|
||||
|
||||
@classmethod
|
||||
def from_ultralytics(cls, ultralytics_results) -> KeyPoints:
|
||||
"""
|
||||
Creates a Keypoints instance from a
|
||||
Creates a KeyPoints instance from a
|
||||
[YOLOv8](https://github.com/ultralytics/ultralytics) inference result.
|
||||
|
||||
Args:
|
||||
@@ -111,7 +196,7 @@ class KeyPoints:
|
||||
The output Results instance from YOLOv8
|
||||
|
||||
Returns:
|
||||
KeyPoints: A new Keypoints object.
|
||||
KeyPoints: A new KeyPoints object.
|
||||
|
||||
Example:
|
||||
```python
|
||||
@@ -136,9 +221,66 @@ class KeyPoints:
|
||||
data = {CLASS_NAME_DATA_FIELD: class_names}
|
||||
return cls(xy, class_id, confidence, data)
|
||||
|
||||
@classmethod
|
||||
def from_yolo_nas(cls, yolo_nas_results) -> KeyPoints:
|
||||
"""
|
||||
Create a KeyPoints instance from a YOLO NAS results.
|
||||
|
||||
Args:
|
||||
yolo_nas_results (ImagePoseEstimationPrediction):
|
||||
The output object from YOLO NAS.
|
||||
|
||||
Returns:
|
||||
KeyPoints: A new KeyPoints object.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import cv2
|
||||
import torch
|
||||
import supervision as sv
|
||||
import super_gradients
|
||||
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
|
||||
device = "cuda" if torch.cuda.is_available() else "cpu"
|
||||
yolo_nas = super_gradients.training.models.get(
|
||||
"yolo_nas_pose_s", pretrained_weights="coco_pose").to(device)
|
||||
|
||||
results = yolo_nas.predict(image, conf=0.1)
|
||||
keypoints = sv.KeyPoints.from_yolo_nas(results)
|
||||
```
|
||||
"""
|
||||
if len(yolo_nas_results.prediction.poses) == 0:
|
||||
return cls.empty()
|
||||
|
||||
xy = yolo_nas_results.prediction.poses[:, :, :2]
|
||||
confidence = yolo_nas_results.prediction.poses[:, :, 2]
|
||||
|
||||
# yolo_nas_results treats params differently.
|
||||
# prediction.labels may not exist, whereas class_names might be None
|
||||
if hasattr(yolo_nas_results.prediction, "labels"):
|
||||
class_id = yolo_nas_results.prediction.labels # np.array[int]
|
||||
else:
|
||||
class_id = None
|
||||
|
||||
data = {}
|
||||
if class_id is not None and yolo_nas_results.class_names is not None:
|
||||
class_names = []
|
||||
for c_id in class_id:
|
||||
name = yolo_nas_results.class_names[c_id] # tuple[str]
|
||||
class_names.append(name)
|
||||
data[CLASS_NAME_DATA_FIELD] = class_names
|
||||
|
||||
return cls(
|
||||
xy=xy,
|
||||
confidence=confidence,
|
||||
class_id=class_id,
|
||||
data=data,
|
||||
)
|
||||
|
||||
def __getitem__(
|
||||
self, index: Union[int, slice, List[int], np.ndarray, str]
|
||||
) -> Union["KeyPoints", List, np.ndarray, None]:
|
||||
) -> Union[KeyPoints, List, np.ndarray, None]:
|
||||
"""
|
||||
Get a subset of the KeyPoints object or access an item from its data field.
|
||||
|
||||
|
||||
@@ -12,8 +12,9 @@ from supervision.utils.internal import deprecated_parameter
|
||||
|
||||
class STrack(BaseTrack):
|
||||
shared_kalman = KalmanFilter()
|
||||
_external_count = 0
|
||||
|
||||
def __init__(self, tlwh, score, class_ids):
|
||||
def __init__(self, tlwh, score, class_ids, minimum_consecutive_frames):
|
||||
# wait activate
|
||||
self._tlwh = np.asarray(tlwh, dtype=np.float32)
|
||||
self.kalman_filter = None
|
||||
@@ -24,6 +25,10 @@ class STrack(BaseTrack):
|
||||
self.class_ids = class_ids
|
||||
self.tracklet_len = 0
|
||||
|
||||
self.external_track_id = -1
|
||||
|
||||
self.minimum_consecutive_frames = minimum_consecutive_frames
|
||||
|
||||
def predict(self):
|
||||
mean_state = self.mean.copy()
|
||||
if self.state != TrackState.Tracked:
|
||||
@@ -53,7 +58,7 @@ class STrack(BaseTrack):
|
||||
def activate(self, kalman_filter, frame_id):
|
||||
"""Start a new tracklet"""
|
||||
self.kalman_filter = kalman_filter
|
||||
self.track_id = self.next_id()
|
||||
self.internal_track_id = self.next_id()
|
||||
self.mean, self.covariance = self.kalman_filter.initiate(
|
||||
self.tlwh_to_xyah(self._tlwh)
|
||||
)
|
||||
@@ -62,6 +67,10 @@ class STrack(BaseTrack):
|
||||
self.state = TrackState.Tracked
|
||||
if frame_id == 1:
|
||||
self.is_activated = True
|
||||
|
||||
if self.minimum_consecutive_frames == 1:
|
||||
self.external_track_id = self.next_external_id()
|
||||
|
||||
self.frame_id = frame_id
|
||||
self.start_frame = frame_id
|
||||
|
||||
@@ -71,10 +80,10 @@ class STrack(BaseTrack):
|
||||
)
|
||||
self.tracklet_len = 0
|
||||
self.state = TrackState.Tracked
|
||||
self.is_activated = True
|
||||
|
||||
self.frame_id = frame_id
|
||||
if new_id:
|
||||
self.track_id = self.next_id()
|
||||
self.internal_track_id = self.next_id()
|
||||
self.score = new_track.score
|
||||
|
||||
def update(self, new_track, frame_id):
|
||||
@@ -93,7 +102,10 @@ class STrack(BaseTrack):
|
||||
self.mean, self.covariance, self.tlwh_to_xyah(new_tlwh)
|
||||
)
|
||||
self.state = TrackState.Tracked
|
||||
self.is_activated = True
|
||||
if self.tracklet_len == self.minimum_consecutive_frames:
|
||||
self.is_activated = True
|
||||
if self.external_track_id == -1:
|
||||
self.external_track_id = self.next_external_id()
|
||||
|
||||
self.score = new_track.score
|
||||
|
||||
@@ -131,6 +143,15 @@ class STrack(BaseTrack):
|
||||
def to_xyah(self):
|
||||
return self.tlwh_to_xyah(self.tlwh)
|
||||
|
||||
@staticmethod
|
||||
def next_external_id():
|
||||
STrack._external_count += 1
|
||||
return STrack._external_count
|
||||
|
||||
@staticmethod
|
||||
def reset_external_counter():
|
||||
STrack._external_count = 0
|
||||
|
||||
@staticmethod
|
||||
def tlbr_to_tlwh(tlbr):
|
||||
ret = np.asarray(tlbr).copy()
|
||||
@@ -144,7 +165,9 @@ class STrack(BaseTrack):
|
||||
return ret
|
||||
|
||||
def __repr__(self):
|
||||
return "OT_{}_({}-{})".format(self.track_id, self.start_frame, self.end_frame)
|
||||
return "OT_{}_({}-{})".format(
|
||||
self.internal_track_id, self.start_frame, self.end_frame
|
||||
)
|
||||
|
||||
|
||||
def detections2boxes(detections: Detections) -> np.ndarray:
|
||||
@@ -186,6 +209,10 @@ class ByteTrack:
|
||||
Increasing minimum_matching_threshold improves accuracy but risks fragmentation.
|
||||
Decreasing it improves completeness but risks false positives and drift.
|
||||
frame_rate (int, optional): The frame rate of the video.
|
||||
minimum_consecutive_frames (int, optional): Number of consecutive frames that an object must
|
||||
be tracked before it is considered a 'valid' track.
|
||||
Increasing minimum_consecutive_frames prevents the creation of accidental tracks from
|
||||
false detection or double detection, but risks missing shorter tracks.
|
||||
""" # noqa: E501 // docs
|
||||
|
||||
@deprecated_parameter(
|
||||
@@ -218,6 +245,7 @@ class ByteTrack:
|
||||
lost_track_buffer: int = 30,
|
||||
minimum_matching_threshold: float = 0.8,
|
||||
frame_rate: int = 30,
|
||||
minimum_consecutive_frames: int = 1,
|
||||
):
|
||||
self.track_activation_threshold = track_activation_threshold
|
||||
self.minimum_matching_threshold = minimum_matching_threshold
|
||||
@@ -225,6 +253,7 @@ class ByteTrack:
|
||||
self.frame_id = 0
|
||||
self.det_thresh = self.track_activation_threshold + 0.1
|
||||
self.max_time_lost = int(frame_rate / 30.0 * lost_track_buffer)
|
||||
self.minimum_consecutive_frames = minimum_consecutive_frames
|
||||
self.kalman_filter = KalmanFilter()
|
||||
|
||||
self.tracked_tracks: List[STrack] = []
|
||||
@@ -285,11 +314,14 @@ class ByteTrack:
|
||||
matches, _, _ = matching.linear_assignment(iou_costs, 0.5)
|
||||
detections.tracker_id = np.full(len(detections), -1, dtype=int)
|
||||
for i_detection, i_track in matches:
|
||||
detections.tracker_id[i_detection] = int(tracks[i_track].track_id)
|
||||
detections.tracker_id[i_detection] = int(
|
||||
tracks[i_track].external_track_id
|
||||
)
|
||||
|
||||
return detections[detections.tracker_id != -1]
|
||||
|
||||
else:
|
||||
detections = Detections.empty()
|
||||
detections.tracker_id = np.array([], dtype=int)
|
||||
|
||||
return detections
|
||||
@@ -308,6 +340,7 @@ class ByteTrack:
|
||||
self.lost_tracks: List[STrack] = []
|
||||
self.removed_tracks: List[STrack] = []
|
||||
BaseTrack.reset_counter()
|
||||
STrack.reset_external_counter()
|
||||
|
||||
def update_with_tensors(self, tensors: np.ndarray) -> List[STrack]:
|
||||
"""
|
||||
@@ -345,7 +378,7 @@ class ByteTrack:
|
||||
if len(dets) > 0:
|
||||
"""Detections"""
|
||||
detections = [
|
||||
STrack(STrack.tlbr_to_tlwh(tlbr), s, c)
|
||||
STrack(STrack.tlbr_to_tlwh(tlbr), s, c, self.minimum_consecutive_frames)
|
||||
for (tlbr, s, c) in zip(dets, scores_keep, class_ids_keep)
|
||||
]
|
||||
else:
|
||||
@@ -387,7 +420,7 @@ class ByteTrack:
|
||||
if len(dets_second) > 0:
|
||||
"""Detections"""
|
||||
detections_second = [
|
||||
STrack(STrack.tlbr_to_tlwh(tlbr), s, c)
|
||||
STrack(STrack.tlbr_to_tlwh(tlbr), s, c, self.minimum_consecutive_frames)
|
||||
for (tlbr, s, c) in zip(dets_second, scores_second, class_ids_second)
|
||||
]
|
||||
else:
|
||||
@@ -454,7 +487,7 @@ class ByteTrack:
|
||||
self.lost_tracks = sub_tracks(self.lost_tracks, self.tracked_tracks)
|
||||
self.lost_tracks.extend(lost_stracks)
|
||||
self.lost_tracks = sub_tracks(self.lost_tracks, self.removed_tracks)
|
||||
self.removed_tracks.extend(removed_stracks)
|
||||
self.removed_tracks = removed_stracks
|
||||
self.tracked_tracks, self.lost_tracks = remove_duplicate_tracks(
|
||||
self.tracked_tracks, self.lost_tracks
|
||||
)
|
||||
@@ -468,22 +501,22 @@ def joint_tracks(
|
||||
) -> List[STrack]:
|
||||
"""
|
||||
Joins two lists of tracks, ensuring that the resulting list does not
|
||||
contain tracks with duplicate track_id values.
|
||||
contain tracks with duplicate internal_track_id values.
|
||||
|
||||
Parameters:
|
||||
track_list_a: First list of tracks (with track_id attribute).
|
||||
track_list_b: Second list of tracks (with track_id attribute).
|
||||
track_list_a: First list of tracks (with internal_track_id attribute).
|
||||
track_list_b: Second list of tracks (with internal_track_id attribute).
|
||||
|
||||
Returns:
|
||||
Combined list of tracks from track_list_a and track_list_b
|
||||
without duplicate track_id values.
|
||||
without duplicate internal_track_id values.
|
||||
"""
|
||||
seen_track_ids = set()
|
||||
result = []
|
||||
|
||||
for track in track_list_a + track_list_b:
|
||||
if track.track_id not in seen_track_ids:
|
||||
seen_track_ids.add(track.track_id)
|
||||
if track.internal_track_id not in seen_track_ids:
|
||||
seen_track_ids.add(track.internal_track_id)
|
||||
result.append(track)
|
||||
|
||||
return result
|
||||
@@ -492,17 +525,17 @@ def joint_tracks(
|
||||
def sub_tracks(track_list_a: List, track_list_b: List) -> List[int]:
|
||||
"""
|
||||
Returns a list of tracks from track_list_a after removing any tracks
|
||||
that share the same track_id with tracks in track_list_b.
|
||||
that share the same internal_track_id with tracks in track_list_b.
|
||||
|
||||
Parameters:
|
||||
track_list_a: List of tracks (with track_id attribute).
|
||||
track_list_b: List of tracks (with track_id attribute) to
|
||||
track_list_a: List of tracks (with internal_track_id attribute).
|
||||
track_list_b: List of tracks (with internal_track_id attribute) to
|
||||
be subtracted from track_list_a.
|
||||
Returns:
|
||||
List of remaining tracks from track_list_a after subtraction.
|
||||
"""
|
||||
tracks = {track.track_id: track for track in track_list_a}
|
||||
track_ids_b = {track.track_id for track in track_list_b}
|
||||
tracks = {track.internal_track_id: track for track in track_list_a}
|
||||
track_ids_b = {track.internal_track_id for track in track_list_b}
|
||||
|
||||
for track_id in track_ids_b:
|
||||
tracks.pop(track_id, None)
|
||||
|
||||
+118
-34
@@ -30,6 +30,84 @@ DETECTIONS = Detections(
|
||||
)
|
||||
|
||||
|
||||
# Merge test
|
||||
TEST_MASK = np.zeros((1000, 1000), dtype=bool)
|
||||
TEST_MASK[300:351, 200:251] = True
|
||||
TEST_DET_1 = Detections(
|
||||
xyxy=np.array([[10, 10, 20, 20], [30, 30, 40, 40], [50, 50, 60, 60]]),
|
||||
mask=np.array([TEST_MASK, TEST_MASK, TEST_MASK]),
|
||||
confidence=np.array([0.1, 0.2, 0.3]),
|
||||
class_id=np.array([1, 2, 3]),
|
||||
tracker_id=np.array([1, 2, 3]),
|
||||
data={
|
||||
"some_key": [1, 2, 3],
|
||||
"other_key": [["1", "2"], ["3", "4"], ["5", "6"]],
|
||||
},
|
||||
)
|
||||
TEST_DET_2 = Detections(
|
||||
xyxy=np.array([[70, 70, 80, 80], [90, 90, 100, 100]]),
|
||||
mask=np.array([TEST_MASK, TEST_MASK]),
|
||||
confidence=np.array([0.4, 0.5]),
|
||||
class_id=np.array([4, 5]),
|
||||
tracker_id=np.array([4, 5]),
|
||||
data={
|
||||
"some_key": [4, 5],
|
||||
"other_key": [["7", "8"], ["9", "10"]],
|
||||
},
|
||||
)
|
||||
TEST_DET_1_2 = Detections(
|
||||
xyxy=np.array(
|
||||
[
|
||||
[10, 10, 20, 20],
|
||||
[30, 30, 40, 40],
|
||||
[50, 50, 60, 60],
|
||||
[70, 70, 80, 80],
|
||||
[90, 90, 100, 100],
|
||||
]
|
||||
),
|
||||
mask=np.array([TEST_MASK, TEST_MASK, TEST_MASK, TEST_MASK, TEST_MASK]),
|
||||
confidence=np.array([0.1, 0.2, 0.3, 0.4, 0.5]),
|
||||
class_id=np.array([1, 2, 3, 4, 5]),
|
||||
tracker_id=np.array([1, 2, 3, 4, 5]),
|
||||
data={
|
||||
"some_key": [1, 2, 3, 4, 5],
|
||||
"other_key": [["1", "2"], ["3", "4"], ["5", "6"], ["7", "8"], ["9", "10"]],
|
||||
},
|
||||
)
|
||||
TEST_DET_ZERO_LENGTH = Detections(
|
||||
xyxy=np.empty((0, 4), dtype=np.float32),
|
||||
mask=np.empty((0, *TEST_MASK.shape), dtype=bool),
|
||||
confidence=np.empty((0,)),
|
||||
class_id=np.empty((0,)),
|
||||
tracker_id=np.empty((0,)),
|
||||
data={
|
||||
"some_key": [],
|
||||
"other_key": [],
|
||||
},
|
||||
)
|
||||
TEST_DET_NONE = Detections(
|
||||
xyxy=np.empty((0, 4), dtype=np.float32),
|
||||
)
|
||||
TEST_DET_DIFFERENT_FIELDS = Detections(
|
||||
xyxy=np.array([[88, 88, 99, 99]]),
|
||||
mask=np.array([np.logical_not(TEST_MASK)]),
|
||||
confidence=None,
|
||||
class_id=None,
|
||||
tracker_id=np.array([9]),
|
||||
data={"some_key": [9], "other_key": [["11", "12"]]},
|
||||
)
|
||||
TEST_DET_DIFFERENT_DATA = Detections(
|
||||
xyxy=np.array([[88, 88, 99, 99]]),
|
||||
mask=np.array([np.logical_not(TEST_MASK)]),
|
||||
confidence=np.array([0.9]),
|
||||
class_id=np.array([9]),
|
||||
tracker_id=np.array([9]),
|
||||
data={
|
||||
"never_seen_key": [9],
|
||||
},
|
||||
)
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"detections, index, expected_result, exception",
|
||||
[
|
||||
@@ -148,52 +226,58 @@ def test_getitem(
|
||||
DoesNotRaise(),
|
||||
), # single empty detections
|
||||
(
|
||||
[mock_detections(xyxy=[[10, 10, 20, 20]])],
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]]),
|
||||
[Detections.empty(), Detections.empty()],
|
||||
Detections.empty(),
|
||||
DoesNotRaise(),
|
||||
), # single detection with xyxy field
|
||||
), # two empty detections
|
||||
(
|
||||
[TEST_DET_1],
|
||||
TEST_DET_1,
|
||||
DoesNotRaise(),
|
||||
), # single detection with fields
|
||||
(
|
||||
[TEST_DET_NONE],
|
||||
TEST_DET_NONE,
|
||||
DoesNotRaise(),
|
||||
), # Single weakly-defined detection
|
||||
(
|
||||
[TEST_DET_1, TEST_DET_2],
|
||||
TEST_DET_1_2,
|
||||
DoesNotRaise(),
|
||||
), # Fields with same keys
|
||||
# Fields and empty
|
||||
(
|
||||
[TEST_DET_1, Detections.empty()],
|
||||
TEST_DET_1,
|
||||
DoesNotRaise(),
|
||||
), # single detection with fields
|
||||
(
|
||||
[
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]]),
|
||||
mock_detections(xyxy=np.empty((0, 4), dtype=np.float32)),
|
||||
TEST_DET_1,
|
||||
TEST_DET_ZERO_LENGTH,
|
||||
],
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]]),
|
||||
TEST_DET_1,
|
||||
DoesNotRaise(),
|
||||
), # single detection with xyxy field + empty detection
|
||||
), # Single detection and empty-array fields
|
||||
(
|
||||
[
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]]),
|
||||
mock_detections(xyxy=[[20, 20, 30, 30]]),
|
||||
TEST_DET_1,
|
||||
TEST_DET_NONE,
|
||||
],
|
||||
mock_detections(xyxy=[[10, 10, 20, 20], [20, 20, 30, 30]]),
|
||||
TEST_DET_1,
|
||||
DoesNotRaise(),
|
||||
), # two detections with xyxy field
|
||||
), # Single detection and None fields (+ missing Dict keys)
|
||||
# Errors: Non-zero-length differently defined keys & data
|
||||
(
|
||||
[
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]], class_id=[0]),
|
||||
mock_detections(xyxy=[[20, 20, 30, 30]]),
|
||||
],
|
||||
mock_detections(xyxy=[[10, 10, 20, 20], [20, 20, 30, 30]]),
|
||||
[TEST_DET_1, TEST_DET_DIFFERENT_FIELDS],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # detection with xyxy, class_id fields + detection with xyxy field
|
||||
), # Non-empty detections with different fields
|
||||
(
|
||||
[
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]], class_id=[0]),
|
||||
mock_detections(xyxy=[[20, 20, 30, 30]], class_id=[1]),
|
||||
],
|
||||
mock_detections(xyxy=[[10, 10, 20, 20], [20, 20, 30, 30]], class_id=[0, 1]),
|
||||
DoesNotRaise(),
|
||||
), # two detections with xyxy, class_id fields
|
||||
(
|
||||
[
|
||||
mock_detections(xyxy=[[10, 10, 20, 20]], data={"test": [1]}),
|
||||
mock_detections(xyxy=[[20, 20, 30, 30]], data={"test": [2]}),
|
||||
],
|
||||
mock_detections(
|
||||
xyxy=[[10, 10, 20, 20], [20, 20, 30, 30]], data={"test": [1, 2]}
|
||||
),
|
||||
DoesNotRaise(),
|
||||
), # two detections with xyxy, data fields
|
||||
[TEST_DET_1, TEST_DET_DIFFERENT_DATA],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # Non-empty detections with different data keys
|
||||
],
|
||||
)
|
||||
def test_merge(
|
||||
|
||||
@@ -911,6 +911,14 @@ def test_calculate_masks_centroids(
|
||||
{"test_1": []},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and empty list values
|
||||
(
|
||||
[
|
||||
{"test_1": []},
|
||||
{"test_1": []},
|
||||
],
|
||||
{"test_1": []},
|
||||
DoesNotRaise(),
|
||||
), # two data dicts with the same field name and empty list values
|
||||
(
|
||||
[
|
||||
{"test_1": np.array([])},
|
||||
@@ -918,6 +926,14 @@ def test_calculate_masks_centroids(
|
||||
{"test_1": np.array([])},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and empty np.array values
|
||||
(
|
||||
[
|
||||
{"test_1": np.array([])},
|
||||
{"test_1": np.array([])},
|
||||
],
|
||||
{"test_1": np.array([])},
|
||||
DoesNotRaise(),
|
||||
), # two data dicts with the same field name and empty np.array values
|
||||
(
|
||||
[
|
||||
{"test_1": [1, 2, 3]},
|
||||
@@ -932,7 +948,7 @@ def test_calculate_masks_centroids(
|
||||
],
|
||||
{"test_1": [3, 2, 1]},
|
||||
DoesNotRaise(),
|
||||
), # two data dicts with the same field name and empty and list values
|
||||
), # two data dicts with the same field name; one of with empty list as value
|
||||
(
|
||||
[
|
||||
{"test_1": [1, 2, 3]},
|
||||
@@ -1012,6 +1028,49 @@ def test_calculate_masks_centroids(
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # two data dicts with the same field name and different length arrays values
|
||||
(
|
||||
[{}, {"test_1": [1, 2, 3]}],
|
||||
{"test_1": [1, 2, 3]},
|
||||
DoesNotRaise(),
|
||||
), # two data dicts; one empty and one non-empty dict
|
||||
(
|
||||
[{"test_1": [], "test_2": []}, {"test_1": [1, 2, 3], "test_2": [1, 2, 3]}],
|
||||
{"test_1": [1, 2, 3], "test_2": [1, 2, 3]},
|
||||
DoesNotRaise(),
|
||||
), # two data dicts; one empty and one non-empty dict; same keys
|
||||
(
|
||||
[{"test_1": []}, {"test_1": [1, 2, 3], "test_2": [4, 5, 6]}],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # two data dicts; one empty and one non-empty dict; different keys
|
||||
(
|
||||
[
|
||||
{
|
||||
"test_1": [1, 2, 3],
|
||||
"test_2": [4, 5, 6],
|
||||
"test_3": [7, 8, 9],
|
||||
},
|
||||
{"test_1": [1, 2, 3], "test_2": [4, 5, 6]},
|
||||
],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # two data dicts; one with three keys, one with two keys
|
||||
(
|
||||
[
|
||||
{"test_1": [1, 2, 3]},
|
||||
{"test_1": [1, 2, 3], "test_2": [1, 2, 3]},
|
||||
],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # some keys missing in one dict
|
||||
(
|
||||
[
|
||||
{"test_1": [1, 2, 3], "test_2": ["a", "b"]},
|
||||
{"test_1": [4, 5], "test_2": ["c", "d", "e"]},
|
||||
],
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
), # different value lengths for the same key
|
||||
],
|
||||
)
|
||||
def test_merge_data(
|
||||
@@ -1021,6 +1080,9 @@ def test_merge_data(
|
||||
):
|
||||
with exception:
|
||||
result = merge_data(data_list=data_list)
|
||||
if expected_result is None:
|
||||
assert False, f"Expected an error, but got result {result}"
|
||||
|
||||
for key in result:
|
||||
if isinstance(result[key], np.ndarray):
|
||||
assert np.array_equal(
|
||||
|
||||
Reference in New Issue
Block a user