Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 SkalskiP |
19396771f1 | ||
|
Onuralp SEZER
|
f5324897a3 | ||
|
Piotr Skalski
|
cd8a2be04b | ||
|
Linas Kondrackis
|
8901192b92 | ||
|
Linas Kondrackis
|
a9044e4fed | ||
|
Linas Kondrackis
|
85e4c0ec65 | ||
|
Linas Kondrackis
|
93398108ee | ||
|
Piotr Skalski
|
f41adca384 | ||
|
SkalskiP
|
d64bb3879c | ||
|
SkalskiP
|
452e1f1ea4 | ||
|
Linas Kondrackis
|
45e5f49c5a | ||
|
LinasKo
|
4c36b39f94 | ||
|
pre-commit-ci[bot]
|
e13c7dc22c | ||
|
SkalskiP
|
713719a582 | ||
|
SkalskiP
|
051fe5178b | ||
|
pre-commit-ci[bot]
|
1ebccebf4c | ||
|
SkalskiP
|
f56d7a1733 | ||
|
LinasKo
|
82ab6c57cb | ||
|
Linas Kondrackis
|
816aecb51b | ||
|
dependabot[bot]
|
3c8995758d | ||
|
Onuralp SEZER
|
acfabc247f | ||
|
Onuralp SEZER
|
61a63c83d9 | ||
|
Linas Kondrackis
|
528c960587 | ||
|
Linas Kondrackis
|
6c6171b5d5 | ||
|
Linas Kondrackis
|
b8efa25e93 | ||
|
dependabot[bot]
|
3b61ee674e | ||
|
Linas Kondrackis
|
45563dfddf | ||
|
pre-commit-ci[bot]
|
7823e0de89 | ||
|
SkalskiP
|
ab0882dd55 | ||
|
SkalskiP
|
ec6864ff04 | ||
|
SkalskiP
|
81786ff9d3 | ||
|
SkalskiP
|
95c243c058 | ||
|
pre-commit-ci[bot]
|
5c539c3bda | ||
|
SkalskiP
|
5d38120743 |
@@ -65,8 +65,26 @@ status: new
|
||||
|
||||
:::supervision.detection.utils.move_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.move_masks">move_masks</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.move_masks
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.scale_boxes">scale_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.scale_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.clip_boxes">clip_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.clip_boxes
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.detection.utils.pad_boxes">pad_boxes</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.utils.pad_boxes
|
||||
|
||||
@@ -6,7 +6,7 @@ status: new
|
||||
# Detect Small Objects
|
||||
|
||||
This guide shows how to detect small objects
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
[Ultralytics](https://github.com/ultralytics/ultralytics) or
|
||||
[Transformers](https://github.com/huggingface/transformers) packages using
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer).
|
||||
@@ -68,10 +68,10 @@ size relative to the image resolution.
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
from transformers import DetrImageProcessor, DetrForSegmentation
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForSegmentation.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<SOURCE_IMAGE_PATH>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
@@ -79,8 +79,8 @@ size relative to the image resolution.
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
width, height = image_slice.size
|
||||
target_size = torch.tensor([[width, height]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
@@ -175,7 +175,7 @@ objects within each, and aggregating the results.
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
results = model.infer(image_slice)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
return sv.Detections.from_inference(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
@@ -239,8 +239,8 @@ objects within each, and aggregating the results.
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
width, height = image_slice.size
|
||||
target_size = torch.tensor([[width, height]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
return sv.Detections.from_transformers(results)
|
||||
@@ -264,3 +264,63 @@ objects within each, and aggregating the results.
|
||||
```
|
||||
|
||||
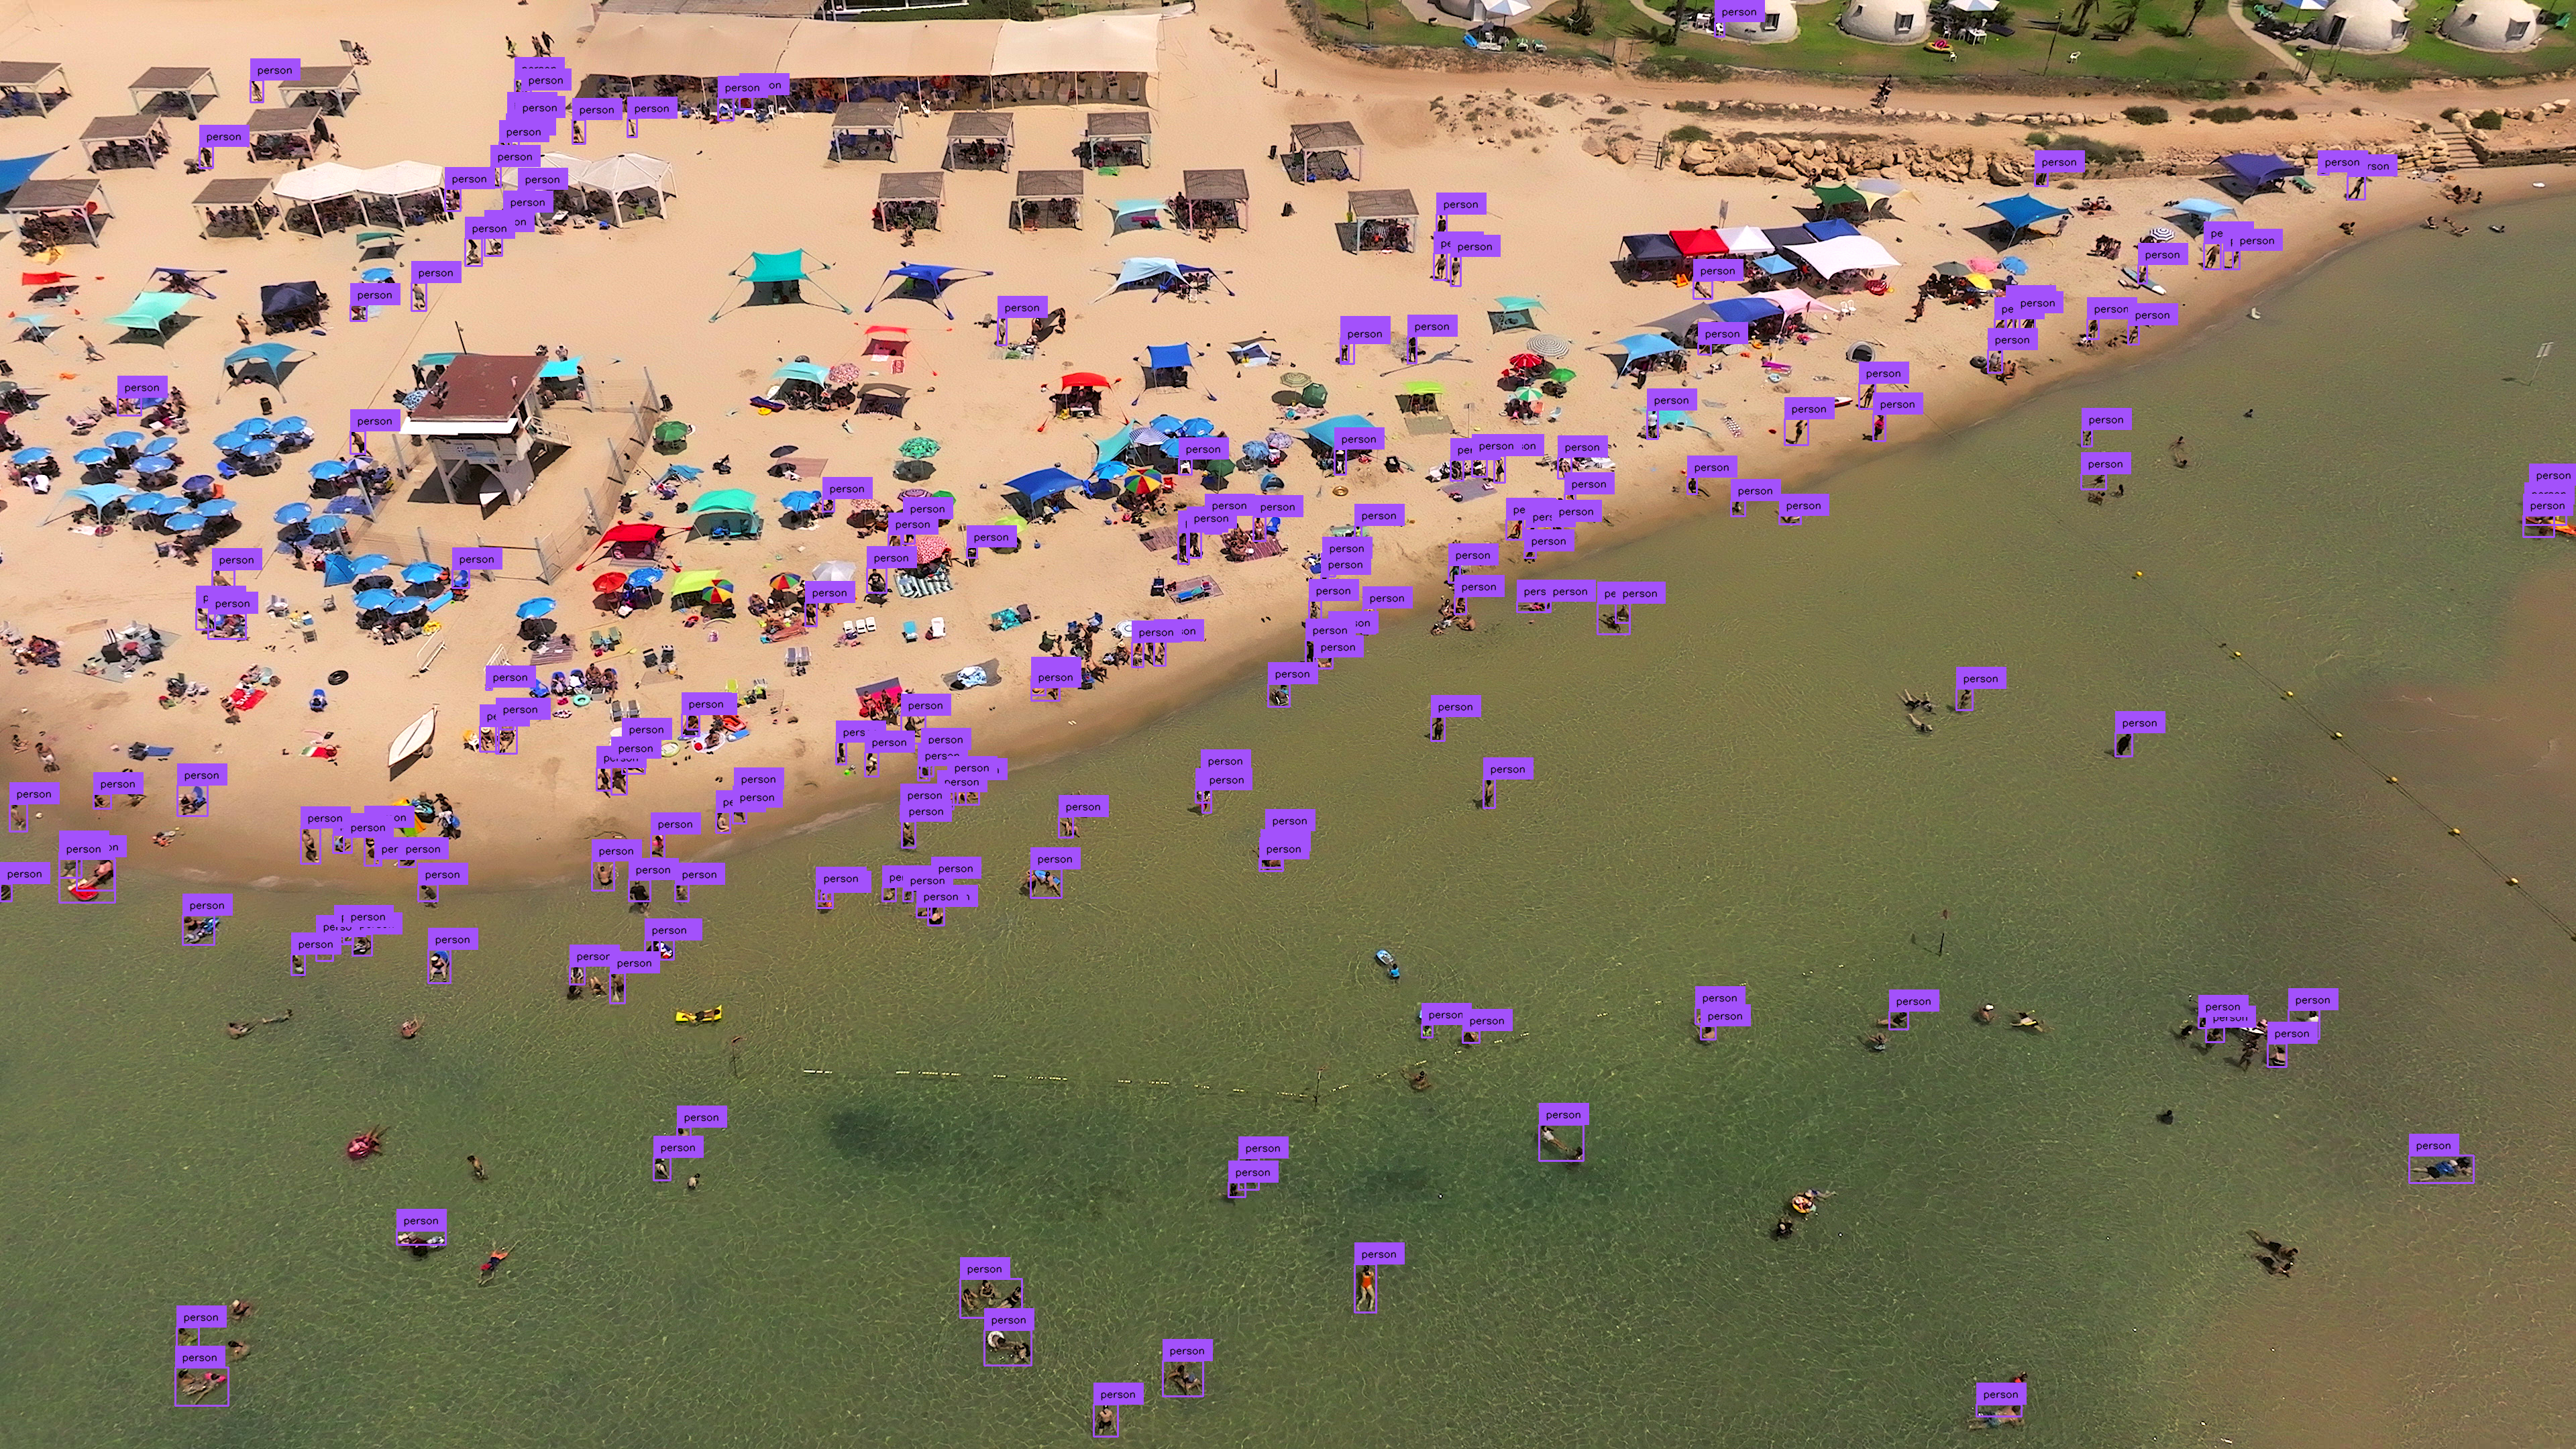
|
||||
|
||||
## Small Object Segmentation
|
||||
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer) can perform segmentation tasks too.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```{ .py hl_lines="6 16 19-20" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8x-seg-640")
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
results = model.infer(image_slice)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```{ .py hl_lines="6 16 19-20" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8x-seg.pt")
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
result = model(image_slice)[0]
|
||||
return sv.Detections.from_ultralytics(result)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
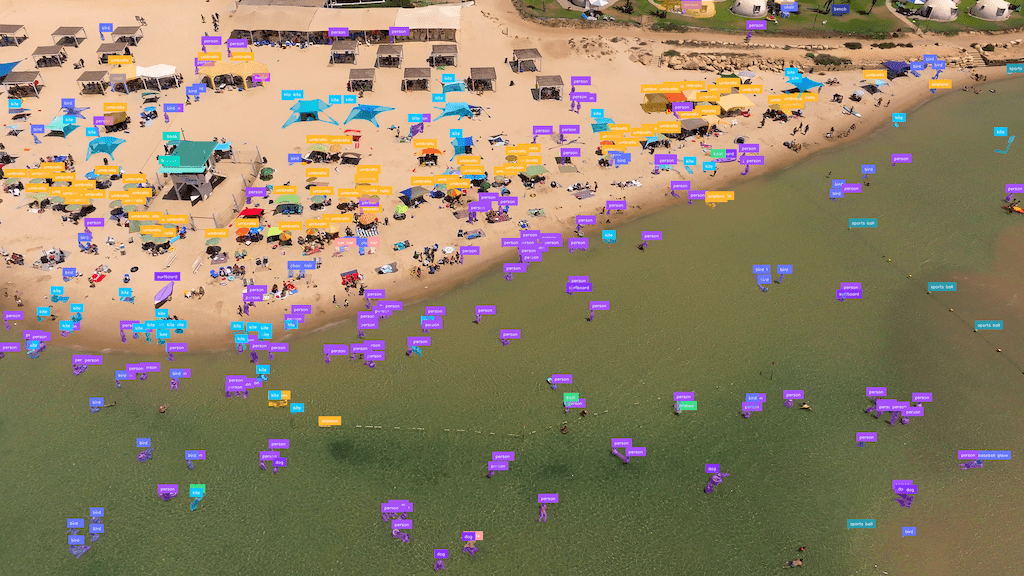
|
||||
|
||||
@@ -13,7 +13,10 @@ status: new
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_annotator = sv.VertexAnnotator(color=sv.Color.GREEN, radius=10)
|
||||
vertex_annotator = sv.VertexAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
radius=10
|
||||
)
|
||||
annotated_frame = vertex_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -34,7 +37,10 @@ status: new
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
edge_annotator = sv.EdgeAnnotator(color=sv.Color.GREEN, thickness=5)
|
||||
edge_annotator = sv.EdgeAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
thickness=5
|
||||
)
|
||||
annotated_frame = edge_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -47,6 +53,31 @@ status: new
|
||||
|
||||
</div>
|
||||
|
||||
=== "VertexLabelAnnotator"
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
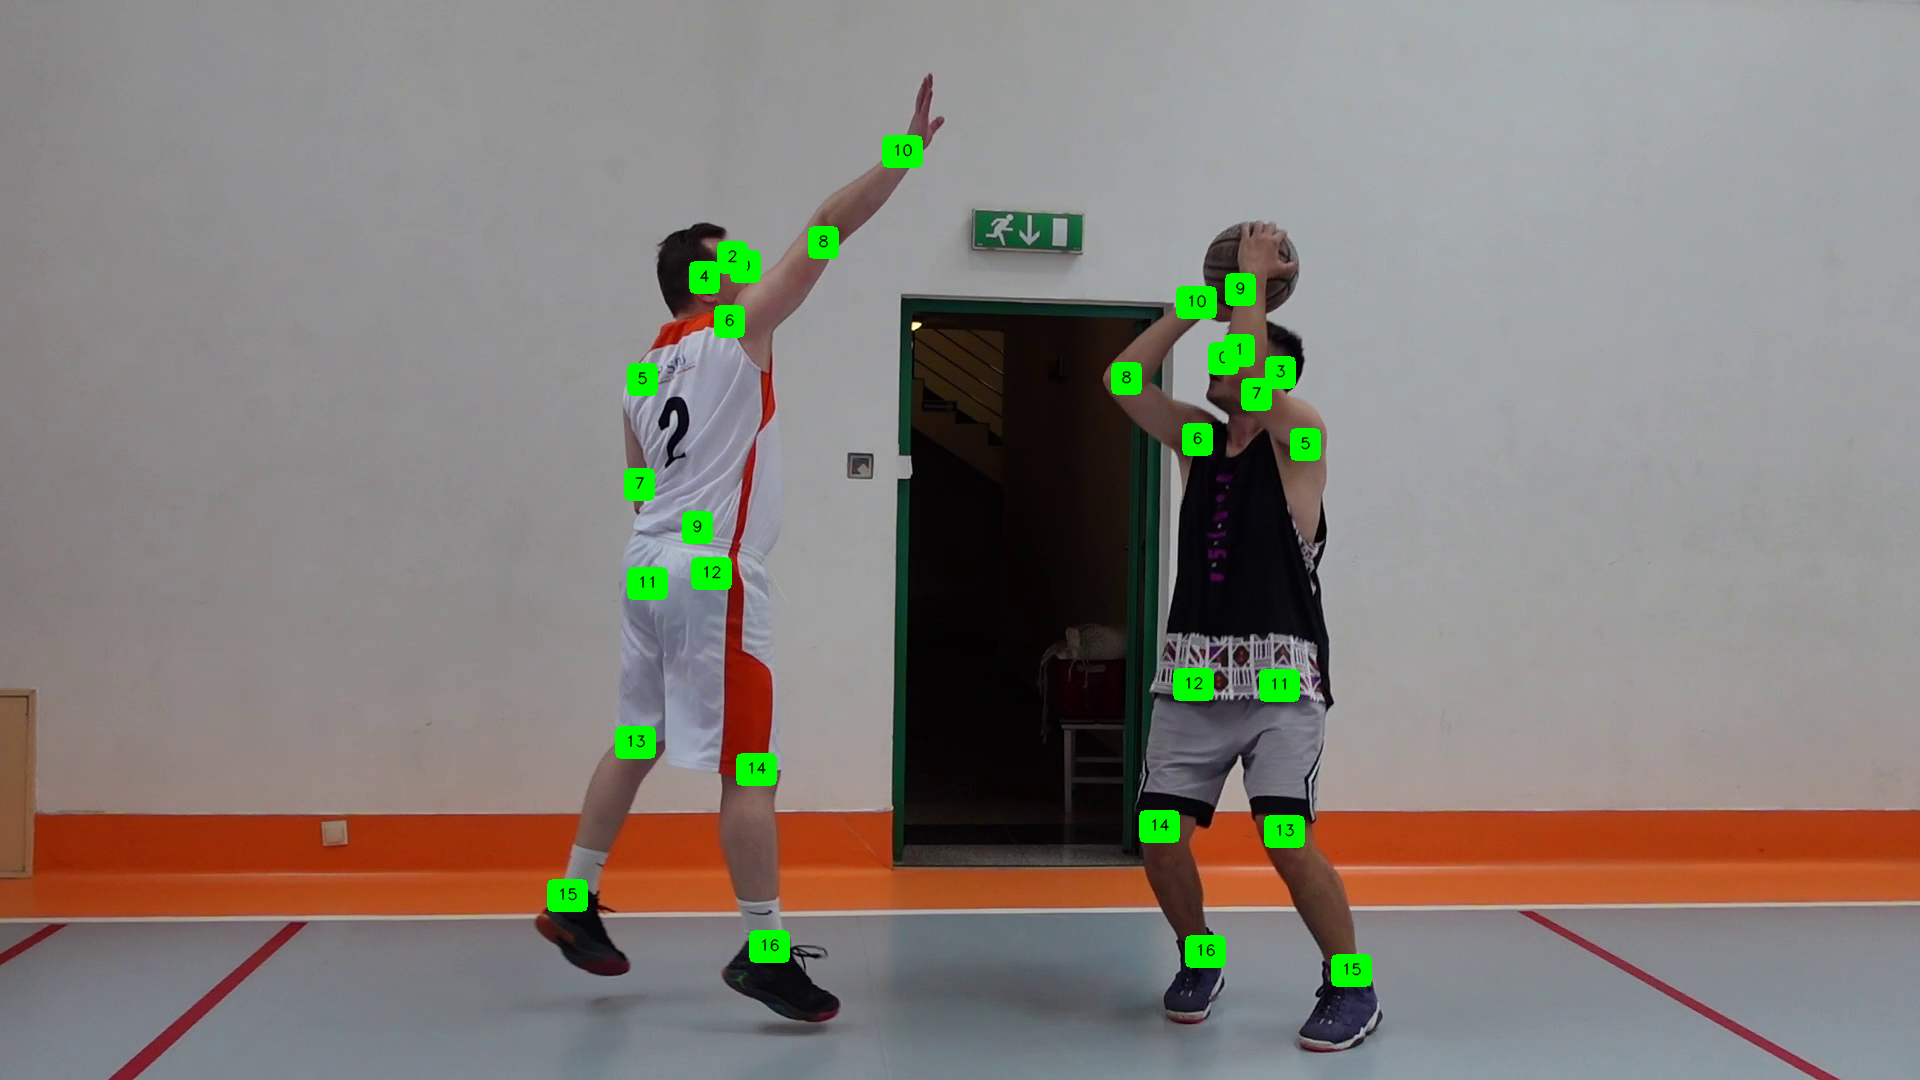{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.keypoint.annotators.VertexAnnotator">VertexAnnotator</a></h2>
|
||||
</div>
|
||||
@@ -58,3 +89,9 @@ status: new
|
||||
</div>
|
||||
|
||||
:::supervision.keypoint.annotators.EdgeAnnotator
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.keypoint.annotators.VertexLabelAnnotator">VertexLabelAnnotator</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.keypoint.annotators.VertexLabelAnnotator
|
||||
|
||||
Generated
+21
-21
@@ -2198,13 +2198,13 @@ pygments = ">2.12.0"
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-material"
|
||||
version = "9.5.21"
|
||||
version = "9.5.22"
|
||||
description = "Documentation that simply works"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs_material-9.5.21-py3-none-any.whl", hash = "sha256:210e1f179682cd4be17d5c641b2f4559574b9dea2f589c3f0e7c17c5bd1959bc"},
|
||||
{file = "mkdocs_material-9.5.21.tar.gz", hash = "sha256:049f82770f40559d3c2aa2259c562ea7257dbb4aaa9624323b5ef27b2d95a450"},
|
||||
{file = "mkdocs_material-9.5.22-py3-none-any.whl", hash = "sha256:8c7a377d323567934e6cd46915e64dc209efceaec0dec1cf2202184f5649862c"},
|
||||
{file = "mkdocs_material-9.5.22.tar.gz", hash = "sha256:22a853a456ae8c581c4628159574d6fc7c71b2c7569dc9c3a82cc70432219599"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -3661,28 +3661,28 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "ruff"
|
||||
version = "0.4.3"
|
||||
version = "0.4.4"
|
||||
description = "An extremely fast Python linter and code formatter, written in Rust."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "ruff-0.4.3-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:b70800c290f14ae6fcbb41bbe201cf62dfca024d124a1f373e76371a007454ce"},
|
||||
{file = "ruff-0.4.3-py3-none-macosx_11_0_arm64.whl", hash = "sha256:08a0d6a22918ab2552ace96adeaca308833873a4d7d1d587bb1d37bae8728eb3"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:eba1f14df3c758dd7de5b55fbae7e1c8af238597961e5fb628f3de446c3c40c5"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:819fb06d535cc76dfddbfe8d3068ff602ddeb40e3eacbc90e0d1272bb8d97113"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:0bfc9e955e6dc6359eb6f82ea150c4f4e82b660e5b58d9a20a0e42ec3bb6342b"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:510a67d232d2ebe983fddea324dbf9d69b71c4d2dfeb8a862f4a127536dd4cfb"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:dc9ff11cd9a092ee7680a56d21f302bdda14327772cd870d806610a3503d001f"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:29efff25bf9ee685c2c8390563a5b5c006a3fee5230d28ea39f4f75f9d0b6f2f"},
|
||||
{file = "ruff-0.4.3-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:18b00e0bcccf0fc8d7186ed21e311dffd19761cb632241a6e4fe4477cc80ef6e"},
|
||||
{file = "ruff-0.4.3-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:262f5635e2c74d80b7507fbc2fac28fe0d4fef26373bbc62039526f7722bca1b"},
|
||||
{file = "ruff-0.4.3-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:7363691198719c26459e08cc17c6a3dac6f592e9ea3d2fa772f4e561b5fe82a3"},
|
||||
{file = "ruff-0.4.3-py3-none-musllinux_1_2_i686.whl", hash = "sha256:eeb039f8428fcb6725bb63cbae92ad67b0559e68b5d80f840f11914afd8ddf7f"},
|
||||
{file = "ruff-0.4.3-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:927b11c1e4d0727ce1a729eace61cee88a334623ec424c0b1c8fe3e5f9d3c865"},
|
||||
{file = "ruff-0.4.3-py3-none-win32.whl", hash = "sha256:25cacda2155778beb0d064e0ec5a3944dcca9c12715f7c4634fd9d93ac33fd30"},
|
||||
{file = "ruff-0.4.3-py3-none-win_amd64.whl", hash = "sha256:7a1c3a450bc6539ef00da6c819fb1b76b6b065dec585f91456e7c0d6a0bbc725"},
|
||||
{file = "ruff-0.4.3-py3-none-win_arm64.whl", hash = "sha256:71ca5f8ccf1121b95a59649482470c5601c60a416bf189d553955b0338e34614"},
|
||||
{file = "ruff-0.4.3.tar.gz", hash = "sha256:ff0a3ef2e3c4b6d133fbedcf9586abfbe38d076041f2dc18ffb2c7e0485d5a07"},
|
||||
{file = "ruff-0.4.4-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:29d44ef5bb6a08e235c8249294fa8d431adc1426bfda99ed493119e6f9ea1bf6"},
|
||||
{file = "ruff-0.4.4-py3-none-macosx_11_0_arm64.whl", hash = "sha256:c4efe62b5bbb24178c950732ddd40712b878a9b96b1d02b0ff0b08a090cbd891"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:4c8e2f1e8fc12d07ab521a9005d68a969e167b589cbcaee354cb61e9d9de9c15"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:60ed88b636a463214905c002fa3eaab19795679ed55529f91e488db3fe8976ab"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:b90fc5e170fc71c712cc4d9ab0e24ea505c6a9e4ebf346787a67e691dfb72e85"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:8e7e6ebc10ef16dcdc77fd5557ee60647512b400e4a60bdc4849468f076f6eef"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:b9ddb2c494fb79fc208cd15ffe08f32b7682519e067413dbaf5f4b01a6087bcd"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:c51c928a14f9f0a871082603e25a1588059b7e08a920f2f9fa7157b5bf08cfe9"},
|
||||
{file = "ruff-0.4.4-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:b5eb0a4bfd6400b7d07c09a7725e1a98c3b838be557fee229ac0f84d9aa49c36"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:b1867ee9bf3acc21778dcb293db504692eda5f7a11a6e6cc40890182a9f9e595"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:1aecced1269481ef2894cc495647392a34b0bf3e28ff53ed95a385b13aa45768"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_i686.whl", hash = "sha256:9da73eb616b3241a307b837f32756dc20a0b07e2bcb694fec73699c93d04a69e"},
|
||||
{file = "ruff-0.4.4-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:958b4ea5589706a81065e2a776237de2ecc3e763342e5cc8e02a4a4d8a5e6f95"},
|
||||
{file = "ruff-0.4.4-py3-none-win32.whl", hash = "sha256:cb53473849f011bca6e754f2cdf47cafc9c4f4ff4570003a0dad0b9b6890e876"},
|
||||
{file = "ruff-0.4.4-py3-none-win_amd64.whl", hash = "sha256:424e5b72597482543b684c11def82669cc6b395aa8cc69acc1858b5ef3e5daae"},
|
||||
{file = "ruff-0.4.4-py3-none-win_arm64.whl", hash = "sha256:39df0537b47d3b597293edbb95baf54ff5b49589eb7ff41926d8243caa995ea6"},
|
||||
{file = "ruff-0.4.4.tar.gz", hash = "sha256:f87ea42d5cdebdc6a69761a9d0bc83ae9b3b30d0ad78952005ba6568d6c022af"},
|
||||
]
|
||||
|
||||
[[package]]
|
||||
|
||||
+1
-1
@@ -1,6 +1,6 @@
|
||||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.21.0rc4"
|
||||
version = "0.21.0rc5"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
|
||||
@@ -46,12 +46,15 @@ from supervision.detection.utils import (
|
||||
box_iou_batch,
|
||||
box_non_max_suppression,
|
||||
calculate_masks_centroids,
|
||||
clip_boxes,
|
||||
filter_polygons_by_area,
|
||||
mask_iou_batch,
|
||||
mask_non_max_suppression,
|
||||
mask_to_polygons,
|
||||
mask_to_xyxy,
|
||||
move_boxes,
|
||||
move_masks,
|
||||
pad_boxes,
|
||||
polygon_to_mask,
|
||||
polygon_to_xyxy,
|
||||
scale_boxes,
|
||||
@@ -69,7 +72,11 @@ from supervision.draw.utils import (
|
||||
)
|
||||
from supervision.geometry.core import Point, Position, Rect
|
||||
from supervision.geometry.utils import get_polygon_center
|
||||
from supervision.keypoint.annotators import EdgeAnnotator, VertexAnnotator
|
||||
from supervision.keypoint.annotators import (
|
||||
EdgeAnnotator,
|
||||
VertexAnnotator,
|
||||
VertexLabelAnnotator,
|
||||
)
|
||||
from supervision.keypoint.core import KeyPoints
|
||||
from supervision.metrics.detection import ConfusionMatrix, MeanAveragePrecision
|
||||
from supervision.tracker.byte_tracker.core import ByteTrack
|
||||
|
||||
@@ -4,20 +4,36 @@ from typing import Callable, Optional, Tuple
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.detection.utils import move_boxes
|
||||
from supervision.detection.utils import move_boxes, move_masks
|
||||
from supervision.utils.image import crop_image
|
||||
|
||||
|
||||
def move_detections(detections: Detections, offset: np.array) -> Detections:
|
||||
def move_detections(
|
||||
detections: Detections,
|
||||
offset: np.ndarray,
|
||||
resolution_wh: Optional[Tuple[int, int]] = None,
|
||||
) -> Detections:
|
||||
"""
|
||||
Args:
|
||||
detections (sv.Detections): Detections object to be moved.
|
||||
offset (np.array): An array of shape `(2,)` containing offset values in format
|
||||
offset (np.ndarray): An array of shape `(2,)` containing offset values in format
|
||||
is `[dx, dy]`.
|
||||
resolution_wh (Tuple[int, int]): The width and height of the desired mask
|
||||
resolution. Required for segmentation detections.
|
||||
|
||||
Returns:
|
||||
(sv.Detections) repositioned Detections object.
|
||||
"""
|
||||
detections.xyxy = move_boxes(xyxy=detections.xyxy, offset=offset)
|
||||
if detections.mask is not None:
|
||||
if resolution_wh is None:
|
||||
raise ValueError(
|
||||
"Resolution width and height are required for moving segmentation "
|
||||
"detections. This should be the same as (width, height) of image shape."
|
||||
)
|
||||
detections.mask = move_masks(
|
||||
masks=detections.mask, offset=offset, resolution_wh=resolution_wh
|
||||
)
|
||||
return detections
|
||||
|
||||
|
||||
@@ -126,7 +142,10 @@ class InferenceSlicer:
|
||||
"""
|
||||
image_slice = crop_image(image=image, xyxy=offset)
|
||||
detections = self.callback(image_slice)
|
||||
detections = move_detections(detections=detections, offset=offset[:2])
|
||||
resolution_wh = (image.shape[1], image.shape[0])
|
||||
detections = move_detections(
|
||||
detections=detections, offset=offset[:2], resolution_wh=resolution_wh
|
||||
)
|
||||
|
||||
return detections
|
||||
|
||||
|
||||
@@ -297,6 +297,35 @@ def clip_boxes(xyxy: np.ndarray, resolution_wh: Tuple[int, int]) -> np.ndarray:
|
||||
return result
|
||||
|
||||
|
||||
def pad_boxes(xyxy: np.ndarray, px: int, py: Optional[int] = None) -> np.ndarray:
|
||||
"""
|
||||
Pads bounding boxes coordinates with a constant padding.
|
||||
|
||||
Args:
|
||||
xyxy (np.ndarray): A numpy array of shape `(N, 4)` where each
|
||||
row corresponds to a bounding box in the format
|
||||
`(x_min, y_min, x_max, y_max)`.
|
||||
px (int): The padding value to be added to both the left and right sides of
|
||||
each bounding box.
|
||||
py (Optional[int]): The padding value to be added to both the top and bottom
|
||||
sides of each bounding box. If not provided, `px` will be used for both
|
||||
dimensions.
|
||||
|
||||
Returns:
|
||||
np.ndarray: A numpy array of shape `(N, 4)` where each row corresponds to a
|
||||
bounding box with coordinates padded according to the provided padding
|
||||
values.
|
||||
"""
|
||||
if py is None:
|
||||
py = px
|
||||
|
||||
result = xyxy.copy()
|
||||
result[:, [0, 1]] -= [px, py]
|
||||
result[:, [2, 3]] += [px, py]
|
||||
|
||||
return result
|
||||
|
||||
|
||||
def xywh_to_xyxy(boxes_xywh: np.ndarray) -> np.ndarray:
|
||||
xyxy = boxes_xywh.copy()
|
||||
xyxy[:, 2] = boxes_xywh[:, 0] + boxes_xywh[:, 2]
|
||||
@@ -500,7 +529,7 @@ def process_roboflow_result(
|
||||
np.ndarray,
|
||||
Optional[np.ndarray],
|
||||
Optional[np.ndarray],
|
||||
Dict[str, List[np.ndarray]],
|
||||
Dict[str, Union[List[np.ndarray], np.ndarray]],
|
||||
]:
|
||||
if not roboflow_result["predictions"]:
|
||||
return (
|
||||
@@ -592,6 +621,40 @@ def move_boxes(xyxy: np.ndarray, offset: np.ndarray) -> np.ndarray:
|
||||
return xyxy + np.hstack([offset, offset])
|
||||
|
||||
|
||||
def move_masks(
|
||||
masks: np.ndarray,
|
||||
offset: np.ndarray,
|
||||
resolution_wh: Tuple[int, int] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Offset the masks in an array by the specified (x, y) amount.
|
||||
|
||||
Args:
|
||||
masks (np.ndarray): A 3D array of binary masks corresponding to the predictions.
|
||||
Shape: `(N, H, W)`, where N is the number of predictions, and H, W are the
|
||||
dimensions of each mask.
|
||||
offset (np.ndarray): An array of shape `(2,)` containing non-negative int values
|
||||
`[dx, dy]`.
|
||||
resolution_wh (Tuple[int, int]): The width and height of the desired mask
|
||||
resolution.
|
||||
|
||||
Returns:
|
||||
(np.ndarray) repositioned masks, optionally padded to the specified shape.
|
||||
"""
|
||||
|
||||
if offset[0] < 0 or offset[1] < 0:
|
||||
raise ValueError(f"Offset values must be non-negative integers. Got: {offset}")
|
||||
|
||||
mask_array = np.full((masks.shape[0], resolution_wh[1], resolution_wh[0]), False)
|
||||
mask_array[
|
||||
:,
|
||||
offset[1] : masks.shape[1] + offset[1],
|
||||
offset[0] : masks.shape[2] + offset[0],
|
||||
] = masks
|
||||
|
||||
return mask_array
|
||||
|
||||
|
||||
def scale_boxes(xyxy: np.ndarray, factor: float) -> np.ndarray:
|
||||
"""
|
||||
Scale the dimensions of bounding boxes.
|
||||
|
||||
@@ -81,6 +81,58 @@ def draw_filled_rectangle(scene: np.ndarray, rect: Rect, color: Color) -> np.nda
|
||||
return scene
|
||||
|
||||
|
||||
def draw_rounded_rectangle(
|
||||
scene: np.ndarray,
|
||||
rect: Rect,
|
||||
color: Color,
|
||||
border_radius: int,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Draws a rounded rectangle on an image.
|
||||
|
||||
Parameters:
|
||||
scene (np.ndarray): The image on which the rounded rectangle will be drawn.
|
||||
rect (Rect): The rectangle to be drawn.
|
||||
color (Color): The color of the rounded rectangle.
|
||||
border_radius (int): The radius of the corner rounding.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The image with the rounded rectangle drawn on it.
|
||||
"""
|
||||
x1, y1, x2, y2 = rect.as_xyxy_int_tuple()
|
||||
width, height = x2 - x1, y2 - y1
|
||||
border_radius = min(border_radius, min(width, height) // 2)
|
||||
|
||||
rectangle_coordinates = [
|
||||
((x1 + border_radius, y1), (x2 - border_radius, y2)),
|
||||
((x1, y1 + border_radius), (x2, y2 - border_radius)),
|
||||
]
|
||||
circle_centers = [
|
||||
(x1 + border_radius, y1 + border_radius),
|
||||
(x2 - border_radius, y1 + border_radius),
|
||||
(x1 + border_radius, y2 - border_radius),
|
||||
(x2 - border_radius, y2 - border_radius),
|
||||
]
|
||||
|
||||
for coordinates in rectangle_coordinates:
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=coordinates[0],
|
||||
pt2=coordinates[1],
|
||||
color=color.as_bgr(),
|
||||
thickness=-1,
|
||||
)
|
||||
for center in circle_centers:
|
||||
cv2.circle(
|
||||
img=scene,
|
||||
center=center,
|
||||
radius=border_radius,
|
||||
color=color.as_bgr(),
|
||||
thickness=-1,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
def draw_polygon(
|
||||
scene: np.ndarray, polygon: np.ndarray, color: Color, thickness: int = 2
|
||||
) -> np.ndarray:
|
||||
|
||||
@@ -98,6 +98,11 @@ class Rect:
|
||||
width: float
|
||||
height: float
|
||||
|
||||
@classmethod
|
||||
def from_xyxy(cls, xyxy: Tuple[float, float, float, float]) -> Rect:
|
||||
x1, y1, x2, y2 = xyxy
|
||||
return cls(x=x1, y=y1, width=x2 - x1, height=y2 - y1)
|
||||
|
||||
@property
|
||||
def top_left(self) -> Point:
|
||||
return Point(x=self.x, y=self.y)
|
||||
@@ -113,3 +118,11 @@ class Rect:
|
||||
width=self.width + 2 * padding,
|
||||
height=self.height + 2 * padding,
|
||||
)
|
||||
|
||||
def as_xyxy_int_tuple(self) -> Tuple[int, int, int, int]:
|
||||
return (
|
||||
int(self.x),
|
||||
int(self.y),
|
||||
int(self.x + self.width),
|
||||
int(self.y + self.height),
|
||||
)
|
||||
|
||||
@@ -1,12 +1,14 @@
|
||||
from abc import ABC, abstractmethod
|
||||
from logging import warn
|
||||
from typing import List, Optional, Tuple
|
||||
from typing import List, Optional, Tuple, Union
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
from supervision import Rect, pad_boxes
|
||||
from supervision.annotators.base import ImageType
|
||||
from supervision.draw.color import Color
|
||||
from supervision.draw.utils import draw_rounded_rectangle
|
||||
from supervision.keypoint.core import KeyPoints
|
||||
from supervision.keypoint.skeletons import SKELETONS_BY_VERTEX_COUNT
|
||||
from supervision.utils.conversion import convert_for_annotation_method
|
||||
@@ -46,8 +48,8 @@ class VertexAnnotator(BaseKeyPointAnnotator):
|
||||
points. It draws circles at each key point location.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where bounding boxes will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
scene (ImageType): The image where skeleton vertices will be drawn.
|
||||
`ImageType` is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
consists of x and y coordinates.
|
||||
@@ -63,7 +65,10 @@ class VertexAnnotator(BaseKeyPointAnnotator):
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_annotator = sv.VertexAnnotator(color=sv.Color.GREEN, radius=10)
|
||||
vertex_annotator = sv.VertexAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
radius=10
|
||||
)
|
||||
annotated_frame = vertex_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -119,7 +124,7 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
edges.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where bounding boxes will be drawn. `ImageType`
|
||||
scene (ImageType): The image where skeleton edges will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
@@ -137,7 +142,10 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
edge_annotator = sv.EdgeAnnotator(color=sv.Color.GREEN, thickness=5)
|
||||
edge_annotator = sv.EdgeAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
thickness=5
|
||||
)
|
||||
annotated_frame = edge_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
@@ -175,3 +183,236 @@ class EdgeAnnotator(BaseKeyPointAnnotator):
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
|
||||
class VertexLabelAnnotator:
|
||||
"""
|
||||
A class that draws labels of skeleton vertices on images. It uses specified key
|
||||
points to determine the locations where the vertices should be drawn.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, List[Color]] = Color.ROBOFLOW,
|
||||
text_color: Color = Color.WHITE,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
border_radius: int = 0,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, List[Color]], optional): The color to use for each
|
||||
keypoint label. If a list is provided, the colors will be used in order
|
||||
for each keypoint.
|
||||
text_color (Color, optional): The color to use for the labels.
|
||||
text_scale (float, optional): The scale of the text.
|
||||
text_thickness (int, optional): The thickness of the text.
|
||||
text_padding (int, optional): The padding around the text.
|
||||
border_radius (int, optional): The radius of the rounded corners of the
|
||||
boxes. Set to a high value to produce circles.
|
||||
"""
|
||||
self.border_radius: int = border_radius
|
||||
self.color: Union[Color, List[Color]] = color
|
||||
self.text_color: Color = text_color
|
||||
self.text_scale: float = text_scale
|
||||
self.text_thickness: int = text_thickness
|
||||
self.text_padding: int = text_padding
|
||||
|
||||
def annotate(
|
||||
self, scene: ImageType, key_points: KeyPoints, labels: List[str] = None
|
||||
) -> ImageType:
|
||||
"""
|
||||
A class that draws labels of skeleton vertices on images. It uses specified key
|
||||
points to determine the locations where the vertices should be drawn.
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where vertex labels will be drawn. `ImageType`
|
||||
is a flexible type, accepting either `numpy.ndarray` or
|
||||
`PIL.Image.Image`.
|
||||
key_points (KeyPoints): A collection of key points where each key point
|
||||
consists of x and y coordinates.
|
||||
labels (List[str], optional): A list of labels to be displayed on the
|
||||
annotated image. If not provided, keypoint indices will be used.
|
||||
|
||||
Returns:
|
||||
The annotated image, matching the type of `scene` (`numpy.ndarray`
|
||||
or `PIL.Image.Image`)
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=sv.Color.GREEN,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points
|
||||
)
|
||||
```
|
||||
|
||||

|
||||
|
||||
!!! tip
|
||||
|
||||
`VertexLabelAnnotator` allows to customize the color of each keypoint label
|
||||
values.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
key_points = sv.KeyPoints(...)
|
||||
|
||||
LABELS = [
|
||||
"nose", "left eye", "right eye", "left ear",
|
||||
"right ear", "left shoulder", "right shoulder", "left elbow",
|
||||
"right elbow", "left wrist", "right wrist", "left hip",
|
||||
"right hip", "left knee", "right knee", "left ankle",
|
||||
"right ankle"
|
||||
]
|
||||
|
||||
COLORS = [
|
||||
"#FF6347", "#FF6347", "#FF6347", "#FF6347",
|
||||
"#FF6347", "#FF1493", "#00FF00", "#FF1493",
|
||||
"#00FF00", "#FF1493", "#00FF00", "#FFD700",
|
||||
"#00BFFF", "#FFD700", "#00BFFF", "#FFD700",
|
||||
"#00BFFF"
|
||||
]
|
||||
COLORS = [sv.Color.from_hex(color_hex=c) for c in COLORS]
|
||||
|
||||
vertex_label_annotator = sv.VertexLabelAnnotator(
|
||||
color=COLORS,
|
||||
text_color=sv.Color.BLACK,
|
||||
border_radius=5
|
||||
)
|
||||
annotated_frame = vertex_label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
key_points=key_points,
|
||||
labels=labels
|
||||
)
|
||||
```
|
||||

|
||||
"""
|
||||
font = cv2.FONT_HERSHEY_SIMPLEX
|
||||
|
||||
skeletons_count, points_count, _ = key_points.xy.shape
|
||||
if skeletons_count == 0:
|
||||
return scene
|
||||
|
||||
anchors = key_points.xy.reshape(points_count * skeletons_count, 2).astype(int)
|
||||
mask = np.all(anchors != 0, axis=1)
|
||||
|
||||
if not np.any(mask):
|
||||
return scene
|
||||
|
||||
colors = self.preprocess_and_validate_colors(
|
||||
colors=self.color,
|
||||
points_count=points_count,
|
||||
skeletons_count=skeletons_count,
|
||||
)
|
||||
|
||||
labels = self.preprocess_and_validate_labels(
|
||||
labels=labels, points_count=points_count, skeletons_count=skeletons_count
|
||||
)
|
||||
|
||||
anchors = anchors[mask]
|
||||
colors = colors[mask]
|
||||
labels = labels[mask]
|
||||
|
||||
xyxy = np.array(
|
||||
[
|
||||
self.get_text_bounding_box(
|
||||
text=label,
|
||||
font=font,
|
||||
text_scale=self.text_scale,
|
||||
text_thickness=self.text_thickness,
|
||||
center_coordinates=tuple(anchor),
|
||||
)
|
||||
for anchor, label in zip(anchors, labels)
|
||||
]
|
||||
)
|
||||
|
||||
xyxy_padded = pad_boxes(xyxy=xyxy, px=self.text_padding)
|
||||
|
||||
for text, color, box, box_padded in zip(labels, colors, xyxy, xyxy_padded):
|
||||
draw_rounded_rectangle(
|
||||
scene=scene,
|
||||
rect=Rect.from_xyxy(box_padded),
|
||||
color=color,
|
||||
border_radius=self.border_radius,
|
||||
)
|
||||
cv2.putText(
|
||||
img=scene,
|
||||
text=text,
|
||||
org=(box[0], box[1] + self.text_padding),
|
||||
fontFace=font,
|
||||
fontScale=self.text_scale,
|
||||
color=self.text_color.as_rgb(),
|
||||
thickness=self.text_thickness,
|
||||
lineType=cv2.LINE_AA,
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
@staticmethod
|
||||
def get_text_bounding_box(
|
||||
text: str,
|
||||
font: int,
|
||||
text_scale: float,
|
||||
text_thickness: int,
|
||||
center_coordinates: Tuple[int, int],
|
||||
) -> Tuple[int, int, int, int]:
|
||||
text_w, text_h = cv2.getTextSize(
|
||||
text=text,
|
||||
fontFace=font,
|
||||
fontScale=text_scale,
|
||||
thickness=text_thickness,
|
||||
)[0]
|
||||
center_x, center_y = center_coordinates
|
||||
return (
|
||||
center_x - text_w // 2,
|
||||
center_y - text_h // 2,
|
||||
center_x + text_w // 2,
|
||||
center_y + text_h // 2,
|
||||
)
|
||||
|
||||
@staticmethod
|
||||
def preprocess_and_validate_labels(
|
||||
labels: Optional[List[str]], points_count: int, skeletons_count: int
|
||||
) -> np.array:
|
||||
if labels and len(labels) != points_count:
|
||||
raise ValueError(
|
||||
f"Number of labels ({len(labels)}) must match number of key points "
|
||||
f"({points_count})."
|
||||
)
|
||||
if labels is None:
|
||||
labels = [str(i) for i in range(points_count)]
|
||||
|
||||
return np.array(labels * skeletons_count)
|
||||
|
||||
@staticmethod
|
||||
def preprocess_and_validate_colors(
|
||||
colors: Optional[Union[Color, List[Color]]],
|
||||
points_count: int,
|
||||
skeletons_count: int,
|
||||
) -> np.array:
|
||||
if isinstance(colors, list) and len(colors) != points_count:
|
||||
raise ValueError(
|
||||
f"Number of colors ({len(colors)}) must match number of key points "
|
||||
f"({points_count})."
|
||||
)
|
||||
return (
|
||||
np.array(colors * skeletons_count)
|
||||
if isinstance(colors, list)
|
||||
else np.array([colors] * points_count * skeletons_count)
|
||||
)
|
||||
|
||||
Reference in New Issue
Block a user