Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 SkalskiP |
ccc7118bcb | ||
|
Piotr Skalski
|
2cccfc5b62 | ||
|
Onuralp SEZER
|
93584cbb89 | ||
|
Piotr Skalski
|
5bfc977fac | ||
|
Piotr Skalski
|
16c41d9d5d | ||
|
SkalskiP
|
81c2a09430 | ||
|
Piotr Skalski
|
16b7222012 | ||
|
Piotr Skalski
|
6b2136d57b | ||
|
Piotr Skalski
|
908a1b4d89 | ||
|
Onuralp SEZER
|
7e283d4eeb | ||
|
Raif Olson
|
a2aca62ecb | ||
|
Onuralp SEZER
|
0a5fb7b47e | ||
|
Piotr Skalski
|
7132c034ab | ||
|
pre-commit-ci[bot]
|
dc5f841bae | ||
|
SkalskiP
|
64eef66b54 | ||
|
Raif Olson
|
dc45c0a5e0 | ||
|
Piotr Skalski
|
69563b8bbb | ||
|
pre-commit-ci[bot]
|
29ba24f89a | ||
|
Raif Olson
|
da4404e875 | ||
|
Raif Olson
|
089594f72d | ||
|
pre-commit-ci[bot]
|
e9edc2fb1d | ||
|
Raif Olson
|
ad24d3811b | ||
|
dependabot[bot]
|
8fb3ba70b0 | ||
|
SkalskiP
|
34b80eb3c0 | ||
|
Piotr Skalski
|
3276973446 | ||
|
Piotr Skalskiandpre-commit-ci[bot]
|
725d95c6ce | ||
|
pre-commit-ci[bot]
|
13f85ae6cc | ||
|
Griffin-Sullivan
|
c67078b53c | ||
|
Piotr Skalski
|
42f9d4b69b | ||
|
Onuralp SEZER
|
d41caed36f | ||
|
SkalskiP
|
5a040969d7 | ||
|
Raif Olson
|
3ed4aeffff | ||
|
Onuralp SEZER
|
97b8312570 | ||
|
Piotr Skalski
|
94e9719f20 | ||
|
SkalskiP
|
0d16b13e7a | ||
|
Piotr Skalski
|
5c03173c7c | ||
|
pre-commit-ci[bot]
|
cf88cc0384 | ||
|
SkalskiP
|
15e17adef1 | ||
|
pre-commit-ci[bot]
|
ca425a628d | ||
|
Piotr Skalski
|
09a47bec62 | ||
|
pre-commit-ci[bot]
|
90f6893d3d | ||
|
SkalskiP
|
b585bb0724 | ||
|
Piotr Skalski
|
495f9a9003 | ||
|
Piotr Skalski
|
4a6a6dbf6b | ||
|
SkalskiP
|
fec251d979 | ||
|
SkalskiP
|
6d27b8067b | ||
|
Onuralp SEZER
|
3da0ca4ffc | ||
|
Onuralp SEZER
|
fc03b0c386 | ||
|
pre-commit-ci[bot]
|
4660dfd0d3 | ||
|
SkalskiP
|
e7b4d6ec41 | ||
|
pre-commit-ci[bot]
|
bc586562b5 | ||
|
SkalskiP
|
57c6182325 | ||
|
dependabot[bot]
|
c3b617d47e | ||
|
dependabot[bot]
|
6458d4454d | ||
|
Christoforos Aristeidou
|
957ced0614 | ||
|
Christoforos Aristeidou
|
ed3c73eb02 | ||
|
Christoforos Aristeidou
|
3e4ddd5bd9 | ||
|
Christoforos Aristeidou
|
1fbdec6046 | ||
|
Raif Olson
|
1eb877c4d9 | ||
|
Onuralp SEZER
|
781a064d8a | ||
|
dependabot[bot]
|
70218b85e7 | ||
|
Onuralp SEZER
|
37318fafdf | ||
|
dependabot[bot]
|
f377a992e1 | ||
|
Piotr Skalski
|
6208013dcf | ||
|
SkalskiP
|
8a2abe72ae | ||
|
Piotr Skalski
|
d01b636ebe | ||
|
Onuralp SEZER
|
0e3e41287a | ||
|
Onuralp SEZER
|
5f9560afb8 | ||
|
pre-commit-ci[bot]
|
4abd128af5 | ||
|
Piotr Skalski
|
77908fe49b | ||
|
Onuralp SEZER
|
fb3a78f762 | ||
|
Onuralp SEZER
|
f43b3536be | ||
|
dependabot[bot]
|
345c086916 | ||
|
dependabot[bot]
|
123a61f2c6 | ||
|
Onuralp SEZER
|
63b338751f | ||
|
Onuralp SEZER
|
e8810fe8a2 | ||
|
Piotr Skalski
|
3d9d45fc07 | ||
|
Onuralp SEZER
|
4f9e5a590f | ||
|
pre-commit-ci[bot]
|
9f5c63b32d | ||
|
SkalskiP
|
a5b1079e39 | ||
|
Piotr Skalski
|
88d63473fe | ||
|
Piotr Skalski
|
55f93a85b6 | ||
|
SkalskiP
|
a0f7bb76bd | ||
|
Piotr Skalski
|
7e72ad13f7 | ||
|
Piotr Skalski
|
5b6713f197 | ||
|
SkalskiP
|
8d7f18cc22 | ||
|
Onuralp SEZER
|
012ff2bbe2 | ||
|
dependabot[bot]
|
594c9958a4 | ||
|
Onuralp SEZER
|
917b4c0fe4 | ||
|
Piotr Skalski
|
d669619f2d | ||
|
SkalskiP
|
22d97b8a46 | ||
|
SkalskiP
|
0c04647d00 | ||
|
pre-commit-ci[bot]
|
d6589443d7 | ||
|
SkalskiP
|
4ba3780d86 | ||
|
pre-commit-ci[bot]
|
d1003d420c | ||
|
SkalskiP
|
c7a6b38275 | ||
|
Onuralp SEZER
|
0d352bde92 | ||
|
Onuralp SEZER
|
4a6c0a9fa3 | ||
|
Onuralp SEZER
|
423783a8ff | ||
|
Piotr Skalski
|
162a4828e8 | ||
|
Piotr Skalski
|
0b810817e3 | ||
|
SkalskiP
|
6ade84f057 | ||
|
Piotr Skalski
|
655e5a7709 | ||
|
pre-commit-ci[bot]
|
dfb52633dc | ||
|
SkalskiP
|
bc74e1c366 | ||
|
pre-commit-ci[bot]
|
aacad59fd9 | ||
|
SkalskiP
|
879d48048c | ||
|
Onuralp SEZER
|
c0c346b04b | ||
|
pre-commit-ci[bot]
|
8ea1148f75 | ||
|
pre-commit-ci[bot]
|
2c55d1796f | ||
|
Onuralp SEZER
|
b68e7c2059 | ||
|
dependabot[bot]
|
4c426f5e82 | ||
|
Onuralp SEZER
|
fb82d32355 | ||
|
Onuralp SEZER
|
fd6cf36685 | ||
|
Onuralp SEZER
|
f41781015e | ||
|
dependabot[bot]
|
b85222690b | ||
|
dependabot[bot]
|
8ef3c0eb00 | ||
|
dependabot[bot]
|
645a1ec7af | ||
|
Piotr Skalski
|
cadb259214 | ||
|
James
|
26de63a09a | ||
|
Onuralp SEZER
|
b38234babe | ||
|
Onuralp SEZER
|
26201862f1 | ||
|
dependabot[bot]
|
c6f0b5753a | ||
|
Onuralp SEZER
|
427c91baa6 | ||
|
dependabot[bot]
|
dc39852a5b | ||
|
dependabot[bot]
|
52a059ffd9 | ||
|
Onuralp SEZER
|
8900986775 | ||
|
Piotr Skalski
|
4abef15069 | ||
|
dependabot[bot]
|
f1e596a058 | ||
|
Onuralp SEZER
|
cd20887d26 | ||
|
dependabot[bot]
|
e1a950f691 | ||
|
Onuralp SEZER
|
b0a64751d0 | ||
|
dependabot[bot]
|
34648871ab | ||
|
Onuralp SEZER
|
823adb3867 | ||
|
Onuralp SEZER
|
56825423dc | ||
|
Onuralp SEZER
|
e86fc592c7 | ||
|
Onuralp SEZER
|
3e05057ee4 | ||
|
dependabot[bot]
|
a3e39bdb6f | ||
|
dependabot[bot]
|
199d26aa72 | ||
|
Onuralp SEZER
|
ed3c6d1fbd | ||
|
dependabot[bot]
|
f29bdec62e | ||
|
Onuralp SEZER
|
f55ef90716 | ||
|
Adonai Vera
|
d9496316bc | ||
|
Adonai Vera
|
4509608a5d | ||
|
Piotr Skalski
|
6eeb1c4ae3 | ||
|
Onuralp SEZER
|
4803ab26e5 | ||
|
Onuralp SEZER
|
852d518d7c | ||
|
Onuralp SEZER
|
b78b3913fc | ||
|
Onuralp SEZER
|
2407fad07e | ||
|
Tomasz Wrona
|
ae6021a5b4 | ||
|
Tomasz Wrona
|
f866a11099 | ||
|
Leo Ueno
|
ebd86eef32 | ||
|
Leo Ueno
|
158471283f | ||
|
pre-commit-ci[bot]
|
4e635ee788 | ||
|
Tomasz Wrona
|
f53e0d8aa5 | ||
|
Christoforos Aristeidou
|
2a9d4257ba | ||
|
Christoforos Aristeidou
|
9ca3c9319d | ||
|
Christoforos Aristeidou
|
379d755a52 | ||
|
Christoforos Aristeidou
|
d228224f06 | ||
|
Christoforos Aristeidou
|
2863267f30 | ||
|
Christoforos Aristeidou
|
cf14758891 | ||
|
Adonai Vera
|
8d702ceccd | ||
|
Adonai Vera
|
f9caa7db66 | ||
|
Adonai Vera
|
6e32cdb55a | ||
|
Christoforos Aristeidou
|
fbbf147312 | ||
|
Christoforos Aristeidou
|
96b52f28fb | ||
|
Christoforos Aristeidou
|
c132d5fcf2 | ||
|
Christoforos Aristeidou
|
bc24d0ec44 | ||
|
Christoforos Aristeidou
|
714937e4bd | ||
|
Christoforos Aristeidou
|
c016ea3071 |
@@ -4,12 +4,18 @@ on:
|
||||
push:
|
||||
branches:
|
||||
- develop
|
||||
workflow_dispatch:
|
||||
|
||||
concurrency:
|
||||
group: ${{ github.workflow }}-${{ github.event_name == 'push' && github.ref}}
|
||||
cancel-in-progress: true
|
||||
|
||||
permissions:
|
||||
contents: write
|
||||
pages: write
|
||||
pull-requests: write
|
||||
|
||||
|
||||
jobs:
|
||||
deploy:
|
||||
runs-on: ubuntu-latest
|
||||
@@ -23,7 +29,7 @@ jobs:
|
||||
with:
|
||||
python-version: '3.10'
|
||||
- name: 📦 Install mkdocs-material
|
||||
run: pip install "mkdocs-material[all]"
|
||||
run: pip install "mkdocs-material"
|
||||
- name: 📦 Install mkdocstrings[python]
|
||||
run: pip install "mkdocstrings[python]"
|
||||
- name: 📦 Install mkdocs-material[imaging]
|
||||
|
||||
@@ -6,22 +6,24 @@ on:
|
||||
- '[0-9]+.[0-9]+[0-9]+.[0-9]+b[0-9]'
|
||||
- '[0-9]+.[0-9]+[0-9]+.[0-9]+rc[0-9]'
|
||||
|
||||
# Allows you to run this workflow manually from the Actions tab
|
||||
workflow_dispatch:
|
||||
|
||||
jobs:
|
||||
build-n-publish:
|
||||
name: Build and publish to PyPI
|
||||
runs-on: ubuntu-latest
|
||||
|
||||
strategy:
|
||||
matrix:
|
||||
python-version: ["3.10"]
|
||||
steps:
|
||||
- name: Checkout source
|
||||
- name: 🛎️ Checkout
|
||||
uses: actions/checkout@v4
|
||||
|
||||
- name: 🐍 Set up Python 3.8 environment for build
|
||||
with:
|
||||
ref: ${{ github.head_ref }}
|
||||
- name: 🐍 Set up Python ${{ matrix.python-version }}
|
||||
uses: actions/setup-python@v5
|
||||
with:
|
||||
python-version: "3.8"
|
||||
python-version: ${{ matrix.python-version }}
|
||||
|
||||
- name: 🏗️ Build source and wheel distributions
|
||||
run: |
|
||||
|
||||
@@ -4,7 +4,6 @@ on:
|
||||
tags:
|
||||
- '[0-9]+.[0-9]+[0-9]+.[0-9]'
|
||||
|
||||
# Allows you to run this workflow manually from the Actions tab
|
||||
workflow_dispatch:
|
||||
|
||||
jobs:
|
||||
@@ -12,7 +11,7 @@ jobs:
|
||||
runs-on: ubuntu-latest
|
||||
strategy:
|
||||
matrix:
|
||||
python-version: [3.8]
|
||||
python-version: ["3.10"]
|
||||
steps:
|
||||
- name: 🛎️ Checkout
|
||||
uses: actions/checkout@v4
|
||||
|
||||
@@ -0,0 +1,34 @@
|
||||
name: 🧪 Docs Test WorkFlow 📚
|
||||
|
||||
on:
|
||||
pull_request:
|
||||
branches: [main, develop]
|
||||
|
||||
jobs:
|
||||
docs-build-test:
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- name: 🔄 Checkout code
|
||||
uses: actions/checkout@v4
|
||||
- name: 🐍 Set up Python
|
||||
uses: actions/setup-python@v5
|
||||
with:
|
||||
python-version: '3.10'
|
||||
- name: 📦 Install mkdocs-material
|
||||
run: pip install "mkdocs-material[all]"
|
||||
- name: 📦 Install mkdocstrings[python]
|
||||
run: pip install "mkdocstrings[python]"
|
||||
- name: 📦 Install mkdocs-material[imaging]
|
||||
run: pip install "mkdocs-material[imaging]"
|
||||
- name: 📦 Install mike
|
||||
run: pip install "mike"
|
||||
- name: 📦 Install mkdocs-git-revision-date-localized-plugin
|
||||
run: pip install "mkdocs-git-revision-date-localized-plugin"
|
||||
- name: 📦 Install JupyterLab
|
||||
run: pip install jupyterlab
|
||||
- name: 📦 Install mkdocs-jupyter
|
||||
run: pip install mkdocs-jupyter
|
||||
- name: 📦 Install mkdocs-git-committers-plugin-2
|
||||
run: pip install mkdocs-git-committers-plugin-2
|
||||
- name: 🧪 Test documentation build
|
||||
run: mkdocs build --verbose
|
||||
@@ -29,7 +29,7 @@ repos:
|
||||
|
||||
|
||||
- repo: https://github.com/PyCQA/bandit
|
||||
rev: '1.7.7'
|
||||
rev: '1.7.8'
|
||||
hooks:
|
||||
- id: bandit
|
||||
args: ["-c", "pyproject.toml"]
|
||||
@@ -46,7 +46,7 @@ repos:
|
||||
|
||||
|
||||
- repo: https://github.com/astral-sh/ruff-pre-commit
|
||||
rev: v0.2.2
|
||||
rev: v0.3.4
|
||||
hooks:
|
||||
- id: ruff
|
||||
args: [--fix, --exit-non-zero-on-fix]
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
<div align="center">
|
||||
<p>
|
||||
<a align="center" href="" target="_blank">
|
||||
<a align="center" href="" target="https://supervision.roboflow.com">
|
||||
<img
|
||||
width="100%"
|
||||
src="https://media.roboflow.com/open-source/supervision/rf-supervision-banner.png?updatedAt=1678995927529"
|
||||
@@ -10,7 +10,7 @@
|
||||
|
||||
<br>
|
||||
|
||||
[notebooks](https://github.com/roboflow/notebooks) | [inference](https://github.com/roboflow/inference) | [autodistill](https://github.com/autodistill/autodistill) | [collect](https://github.com/roboflow/roboflow-collect)
|
||||
[notebooks](https://github.com/roboflow/notebooks) | [inference](https://github.com/roboflow/inference) | [autodistill](https://github.com/autodistill/autodistill) | [maestro](https://github.com/roboflow/multimodal-maestro)
|
||||
|
||||
<br>
|
||||
|
||||
|
||||
@@ -1,19 +0,0 @@
|
||||
# Supervision Cookbooks
|
||||
|
||||
## About
|
||||
|
||||
The Roboflow Cookbook is an open-source collection of examples and guides for building with the [Roboflow Ecosystem](https://roboflow.com/).
|
||||
|
||||
Cookbooks are meant to be common and small scoped computer vision tasks that can allow a user to quickly hit the ground running. Learning is the main goal and purpose.
|
||||
|
||||
Some examples require a Roboflow API key. You can [create a free account here](https://app.roboflow.com/login).
|
||||
|
||||
## Other Resources
|
||||
|
||||
Other than Cookbooks, Roboflow offers other learning resources including:
|
||||
|
||||
- A set of open source tools found on [Github](https://github.com/roboflow).
|
||||
- A [blog](https://blog.roboflow.com/) detailing interesting tutorials, computer vision news, and product updates.
|
||||
- A [Youtube channel](https://www.youtube.com/roboflow) with end to end commputer vision projects.
|
||||
- A [forum](https://discuss.roboflow.com/) for sharing feedback, discussions, and other questions.
|
||||
- The worlds largest [open source collection](https://universe.roboflow.com/) of images, datasets, and fine-tuned models.
|
||||
Vendored
+1294
-1304
File diff suppressed because one or more lines are too long
+30
-2
@@ -260,15 +260,22 @@ status: new
|
||||
=== "Label"
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
|
||||
labels = [
|
||||
f"{class_name} {confidence:.2f}"
|
||||
for class_name, confidence
|
||||
in zip(detections['class_name'], detections.confidence)
|
||||
]
|
||||
|
||||
label_annotator = sv.LabelAnnotator(text_position=sv.Position.CENTER)
|
||||
annotated_frame = label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
detections=detections,
|
||||
labels=labels
|
||||
)
|
||||
```
|
||||
|
||||
@@ -278,6 +285,21 @@ status: new
|
||||
|
||||
</div>
|
||||
|
||||
=== "Crop"
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
|
||||
crop_annotator = sv.CropAnnotator()
|
||||
annotated_frame = crop_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
|
||||
=== "Blur"
|
||||
|
||||
```python
|
||||
@@ -488,6 +510,12 @@ status: new
|
||||
|
||||
:::supervision.annotators.core.TraceAnnotator
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.annotators.core.CropAnnotator">CropAnnotator</a></h2>
|
||||
</div>
|
||||
|
||||
:::supervision.annotators.core.CropAnnotator
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2><a href="#supervision.annotators.core.ColorLookup">ColorLookup</a></h2>
|
||||
</div>
|
||||
|
||||
+83
-1
@@ -1,6 +1,88 @@
|
||||
### 0.19.0 <small>March 15, 2024</small>
|
||||
|
||||
- Added [#818](https://github.com/roboflow/supervision/pull/818): [`sv.CSVSink`](/0.19.0/detection/tools/save_detections/#supervision.detection.tools.csv_sink.CSVSink) allowing for the straightforward saving of image, video, or stream inference results in a `.csv` file.
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO(<SOURCE_MODEL_PATH>)
|
||||
csv_sink = sv.CSVSink(<RESULT_CSV_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with csv_sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
csv_sink.append(detections, custom_data={<CUSTOM_LABEL>:<CUSTOM_DATA>})
|
||||
```
|
||||
|
||||
- Added [#819](https://github.com/roboflow/supervision/pull/819): [`sv.JSONSink`](/0.19.0/detection/tools/save_detections/#supervision.detection.tools.csv_sink.JSONSink) allowing for the straightforward saving of image, video, or stream inference results in a `.json` file.
|
||||
|
||||
```python
|
||||
|
||||
```python
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO(<SOURCE_MODEL_PATH>)
|
||||
json_sink = sv.JSONSink(<RESULT_JSON_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with json_sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
json_sink.append(detections, custom_data={<CUSTOM_LABEL>:<CUSTOM_DATA>})
|
||||
```
|
||||
|
||||
- Added [#847](https://github.com/roboflow/supervision/pull/847): [`sv.mask_iou_batch`](/0.19.0/detection/utils/#supervision.detection.utils.mask_iou_batch) allowing to compute Intersection over Union (IoU) of two sets of masks.
|
||||
|
||||
- Added [#847](https://github.com/roboflow/supervision/pull/847): [`sv.mask_non_max_suppression`](/0.19.0/detection/utils/#supervision.detection.utils.mask_non_max_suppression) allowing to perform Non-Maximum Suppression (NMS) on segmentation predictions.
|
||||
|
||||
- Added [#888](https://github.com/roboflow/supervision/pull/888): [`sv.CropAnnotator`](/0.19.0/annotators/#supervision.annotators.core.CropAnnotator) allowing users to annotate the scene with scaled-up crops of detections.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
image = cv2.imread(<SOURCE_IMAGE_PATH>)
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
|
||||
result = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(result)
|
||||
|
||||
crop_annotator = sv.CropAnnotator()
|
||||
annotated_frame = crop_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
|
||||
- Changed [#827](https://github.com/roboflow/supervision/pull/827): [`sv.ByteTrack.reset`](/0.19.0/tracking/#supervision.tracking.ByteTrack.reset) allowing users to clear trackers state, enabling the processing of multiple video files in sequence.
|
||||
|
||||
- Changed [#802](https://github.com/roboflow/supervision/pull/802): [`sv.LineZoneAnnotator`](/0.19.0/detection/tools/line_zone/#supervision.detection.line_zone.LineZone) allowing to hide in/out count using `display_in_count` and `display_out_count` properties.
|
||||
|
||||
- Changed [#787](https://github.com/roboflow/supervision/pull/787): [`sv.ByteTrack`](/0.19.0/tracking/#supervision.tracking.ByteTrack) input arguments and docstrings updated to improve readability and ease of use.
|
||||
|
||||
!!! failure "Deprecated"
|
||||
|
||||
The `track_buffer`, `track_thresh`, and `match_thresh` parameters in `sv.ByterTrack` are deprecated and will be removed in `supervision-0.23.0`. Use `lost_track_buffer,` `track_activation_threshold`, and `minimum_matching_threshold` instead.
|
||||
|
||||
- Changed [#910](https://github.com/roboflow/supervision/pull/910): [`sv.PolygonZone`](/0.19.0/detection/tools/polygon_zone/#supervision.detection.tools.polygon_zone.PolygonZone) to now accept a list of specific box anchors that must be in zone for a detection to be counted.
|
||||
|
||||
!!! failure "Deprecated"
|
||||
|
||||
The `triggering_position ` parameter in `sv.PolygonZone` is deprecated and will be removed in `supervision-0.23.0`. Use `triggering_anchors` instead.
|
||||
|
||||
- Changed [#875](https://github.com/roboflow/supervision/pull/875): annotators adding support for Pillow images. All supervision Annotators can now accept an image as either a numpy array or a Pillow Image. They automatically detect its type, draw annotations, and return the output in the same format as the input.
|
||||
|
||||
- Fixed [#944](https://github.com/roboflow/supervision/pull/944): [`sv.DetectionsSmoother`](/0.19.0/detection/tools/smoother/#supervision.detection.tools.smoother.DetectionsSmoother) removing `tracking_id` from `sv.Detections`.
|
||||
|
||||
### 0.18.0 <small>January 25, 2024</small>
|
||||
|
||||
- Added [#633](https://github.com/roboflow/supervision/pull/720): [`sv.PercentageBarAnnotator`](/0.18.0/annotators/#percentagebarannotator) allowing to annotate images and videos with percentage values representing confidence or other custom property.
|
||||
- Added [#720](https://github.com/roboflow/supervision/pull/720): [`sv.PercentageBarAnnotator`](/0.18.0/annotators/#percentagebarannotator) allowing to annotate images and videos with percentage values representing confidence or other custom property.
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
+9
-7
@@ -6,11 +6,13 @@ status: deprecated
|
||||
These features are phased out due to better alternatives or potential issues in future versions. Deprecated functionalities are supported for **three subsequent releases**, providing time for users to transition to updated methods.
|
||||
|
||||
- [`Detections.from_froboflow`](detection/core.md/#supervision.detection.core.Detections.from_roboflow) is deprecated and will be removed in `supervision-0.22.0`. Use [`Detections.from_inference`](detection/core.md/#supervision.detection.core.Detections.from_inference) instead.
|
||||
- `Color.white()` is deprecated and will be removed in `supervision-0.22.0`. Use `Color.WHITE` instead.
|
||||
- `Color.black()` is deprecated and will be removed in `supervision-0.22.0`. Use `Color.BLACK` instead.
|
||||
- `Color.red()` is deprecated and will be removed in `supervision-0.22.0`. Use `Color.RED` instead.
|
||||
- `Color.green()` is deprecated and will be removed in `supervision-0.22.0`. Use `Color.GREEN` instead.
|
||||
- `Color.blue()` is deprecated and will be removed in `supervision-0.22.0`. Use `Color.BLUE` instead.
|
||||
- [`ColorPalette.default()`](draw/color.md/#supervision.draw.color.ColorPalette.default) is deprecated and will be removed in `supervision-0.22.0`. Use [`ColorPalette.DEFAULT`](draw/color.md/#supervision.draw.color.ColorPalette.DEFAULT) instead.
|
||||
- The method `Color.white()` is deprecated and will be removed in `supervision-0.22.0`. Use the constant `Color.WHITE` instead.
|
||||
- The method `Color.black()` is deprecated and will be removed in `supervision-0.22.0`. Use the constant `Color.BLACK` instead.
|
||||
- The method `Color.red()` is deprecated and will be removed in `supervision-0.22.0`. Use the constant `Color.RED` instead.
|
||||
- The method `Color.green()` is deprecated and will be removed in `supervision-0.22.0`. Use the constant `Color.GREEN` instead.
|
||||
- The method `Color.blue()` is deprecated and will be removed in `supervision-0.22.0`. Use the constant `Color.BLUE` instead.
|
||||
- The method [`ColorPalette.default()`](draw/color.md/#supervision.draw.color.ColorPalette.default) is deprecated and will be removed in `supervision-0.22.0`. Use the constant [`ColorPalette.DEFAULT`](draw/color.md/#supervision.draw.color.ColorPalette.DEFAULT) instead.
|
||||
- `BoxAnnotator` is deprecated and will be removed in `supervision-0.22.0`. Use [`BoundingBoxAnnotator`](annotators.md/#supervision.annotators.core.BoundingBoxAnnotator) and [`LabelAnnotator`](annotators.md/#supervision.annotators.core.LabelAnnotator) instead.
|
||||
- [`FPSMonitor.__call__`](utils/video.md/#supervision.utils.video.FPSMonitor.__call__) is deprecated and will be removed in `supervision-0.22.0`. Use [`FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
|
||||
- The method [`FPSMonitor.__call__`](utils/video.md/#supervision.utils.video.FPSMonitor.__call__) is deprecated and will be removed in `supervision-0.22.0`. Use the attribute [`FPSMonitor.fps`](utils/video.md/#supervision.utils.video.FPSMonitor.fps) instead.
|
||||
- The `track_buffer`, `track_thresh`, and `match_thresh` parameters in [`ByterTrack`](trackers.md/#supervision.tracker.byte_tracker.core.ByteTrack) are deprecated and will be removed in `supervision-0.23.0`. Use `lost_track_buffer,` `track_activation_threshold`, and `minimum_matching_threshold` instead.
|
||||
- The `triggering_position ` parameter in [`sv.PolygonZone`](detection/tools/polygon_zone.md/#supervision.detection.tools.polygon_zone.PolygonZone) is deprecated and will be removed in `supervision-0.23.0`. Use `triggering_anchors ` instead.
|
||||
|
||||
@@ -10,3 +10,9 @@ status: new
|
||||
</div>
|
||||
|
||||
:::supervision.detection.tools.csv_sink.CSVSink
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>JSON Sink</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.detection.tools.json_sink.JSONSink
|
||||
|
||||
@@ -1,5 +1,6 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# Detection Utils
|
||||
|
||||
+4
-4
@@ -41,13 +41,13 @@ comments: true
|
||||
:::supervision.draw.utils.draw_image
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>calculate_dynamic_font_scale</h2>
|
||||
<h2>calculate_optimal_font_scale</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.draw.utils.calculate_dynamic_text_scale
|
||||
:::supervision.draw.utils.calculate_optimal_text_scale
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>calculate_dynamic_line_thickness</h2>
|
||||
<h2>calculate_optimal_line_thickness</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.draw.utils.calculate_dynamic_line_thickness
|
||||
:::supervision.draw.utils.calculate_optimal_line_thickness
|
||||
|
||||
@@ -1,20 +1,35 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# Detect and Annotate
|
||||
|
||||
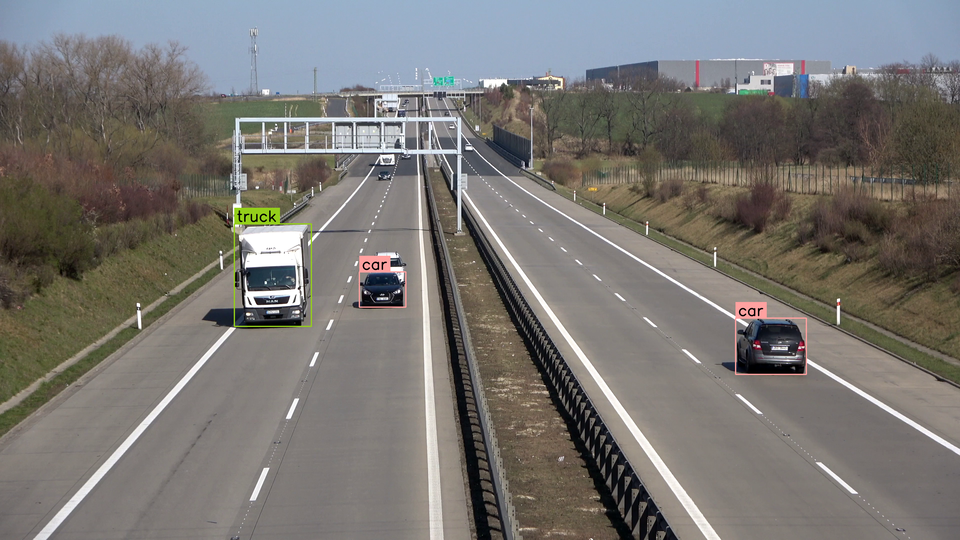
Supervision offers a streamlined solution to effortlessly annotate predictions from a
|
||||
range of object detection and segmentation models. This guide demonstrates how to
|
||||
execute inference using the YOLOv8 model with either the
|
||||
[Inference](https://github.com/roboflow/inference) or
|
||||
[Ultralytics](https://github.com/ultralytics/ultralytics) packages. Following this,
|
||||
you'll learn how to import these predictions into Supervision for image annotation
|
||||
purposes.
|
||||
Supervision provides a seamless process for annotating predictions generated by various
|
||||
object detection and segmentation models. This guide shows how to perform inference
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
[Ultralytics](https://github.com/ultralytics/ultralytics) or
|
||||
[Transformers](https://github.com/huggingface/transformers) packages. Following this,
|
||||
you'll learn how to import these predictions into Supervision and use them to annotate
|
||||
source image.
|
||||
|
||||
|
||||
|
||||
## Run Inference
|
||||
|
||||
First, you'll need to obtain predictions from your object detection or segmentation model.
|
||||
First, you'll need to obtain predictions from your object detection or segmentation
|
||||
model.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
@@ -27,68 +42,52 @@ First, you'll need to obtain predictions from your object detection or segmentat
|
||||
results = model(image)[0]
|
||||
```
|
||||
|
||||
=== "Inference"
|
||||
=== "Transformers"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
from inference.models.utils import get_roboflow_model
|
||||
import torch
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
model = get_roboflow_model(model_id="yolov8n-640", api_key=<ROBOFLOW API KEY>)
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<PATH TO IMAGE>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
```
|
||||
|
||||
## Load Predictions into Supervision
|
||||
|
||||
Now that we have predictions from a model, we can load them into Supervision.
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
We can do so using the [`sv.Detections.from_ultralytics`](detection/core/#supervision.detection.core.Detections.from_ultralytics) method, which accepts model results from both detection and segmentation models.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
```
|
||||
|
||||
=== "Inference"
|
||||
|
||||
We can do so using the [`sv.Detections.from_inference`](detection/core/#supervision.detection.core.Detections.from_inference) method, which accepts model results from both detection and segmentation models.
|
||||
|
||||
```python
|
||||
```{ .py hl_lines="2 8" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference.models.utils import get_roboflow_model
|
||||
from inference import get_model
|
||||
|
||||
model = get_roboflow_model(model_id="yolov8n-640", api_key=<ROBOFLOW API KEY>
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
```
|
||||
|
||||
You can conveniently load predictions from other computer vision frameworks and libraries using:
|
||||
|
||||
- [`from_deepsparse`](detection/core/#supervision.detection.core.Detections.from_deepsparse) ([Deepsparse](https://github.com/neuralmagic/deepsparse))
|
||||
- [`from_detectron2`](detection/core/#supervision.detection.core.Detections.from_detectron2) ([Detectron2](https://github.com/facebookresearch/detectron2))
|
||||
- [`from_mmdetection`](detection/core/#supervision.detection.core.Detections.from_mmdetection) ([MMDetection](https://github.com/open-mmlab/mmdetection))
|
||||
- [`from_inference`](detection/core/#supervision.detection.core.Detections.from_inference) ([Roboflow Inference](https://github.com/roboflow/inference))
|
||||
- [`from_sam`](detection/core/#supervision.detection.core.Detections.from_sam) ([Segment Anything Model](https://github.com/facebookresearch/segment-anything))
|
||||
- [`from_transformers`](detection/core/#supervision.detection.core.Detections.from_transformers) ([HuggingFace Transformers](https://github.com/huggingface/transformers))
|
||||
- [`from_yolo_nas`](detection/core/#supervision.detection.core.Detections.from_yolo_nas) ([YOLO-NAS](https://github.com/Deci-AI/super-gradients/blob/master/YOLONAS.md))
|
||||
|
||||
## Annotate Image
|
||||
|
||||
Finally, we can annotate the image with the predictions. Since we are working with an object detection model, we will use the [`sv.BoundingBoxAnnotator`](annotators/#supervision.annotators.core.BoundingBoxAnnotator) and [`sv.LabelAnnotator`](annotators/#supervision.annotators.core.LabelAnnotator) classes. If you are running the segmentation model [`sv.MaskAnnotator`](annotators/#supervision.annotators.core.MaskAnnotator) is a drop-in replacement for [`sv.BoundingBoxAnnotator`](annotators/#supervision.annotators.core.BoundingBoxAnnotator) that will allow you to draw masks instead of boxes.
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```python
|
||||
We can do so using the [`sv.Detections.from_ultralytics`](detection/core/#supervision.detection.core.Detections.from_ultralytics) method, which accepts model results from both detection and segmentation models.
|
||||
|
||||
```{ .py hl_lines="2 8" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
@@ -97,30 +96,54 @@ Finally, we can annotate the image with the predictions. Since we are working wi
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
model.model.names[class_id]
|
||||
for class_id
|
||||
in detections.class_id
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
=== "Transformers"
|
||||
|
||||
We can do so using the [`sv.Detections.from_transformers`](detection/core/#supervision.detection.core.Detections.from_transformers) method, which accepts model results from both detection and segmentation models.
|
||||
|
||||
```{ .py hl_lines="2 19" }
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<PATH TO IMAGE>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
```
|
||||
|
||||
You can load predictions from other computer vision frameworks and libraries using:
|
||||
|
||||
- [`from_deepsparse`](/latest/detection/core/#supervision.detection.core.Detections.from_deepsparse) ([Deepsparse](https://github.com/neuralmagic/deepsparse))
|
||||
- [`from_detectron2`](/latest/detection/core/#supervision.detection.core.Detections.from_detectron2) ([Detectron2](https://github.com/facebookresearch/detectron2))
|
||||
- [`from_mmdetection`](/latest/detection/core/#supervision.detection.core.Detections.from_mmdetection) ([MMDetection](https://github.com/open-mmlab/mmdetection))
|
||||
- [`from_sam`](/latest/detection/core/#supervision.detection.core.Detections.from_sam) ([Segment Anything Model](https://github.com/facebookresearch/segment-anything))
|
||||
- [`from_yolo_nas`](/latest/detection/core/#supervision.detection.core.Detections.from_yolo_nas) ([YOLO-NAS](https://github.com/Deci-AI/super-gradients/blob/master/YOLONAS.md))
|
||||
|
||||
## Annotate Image with Detections
|
||||
|
||||
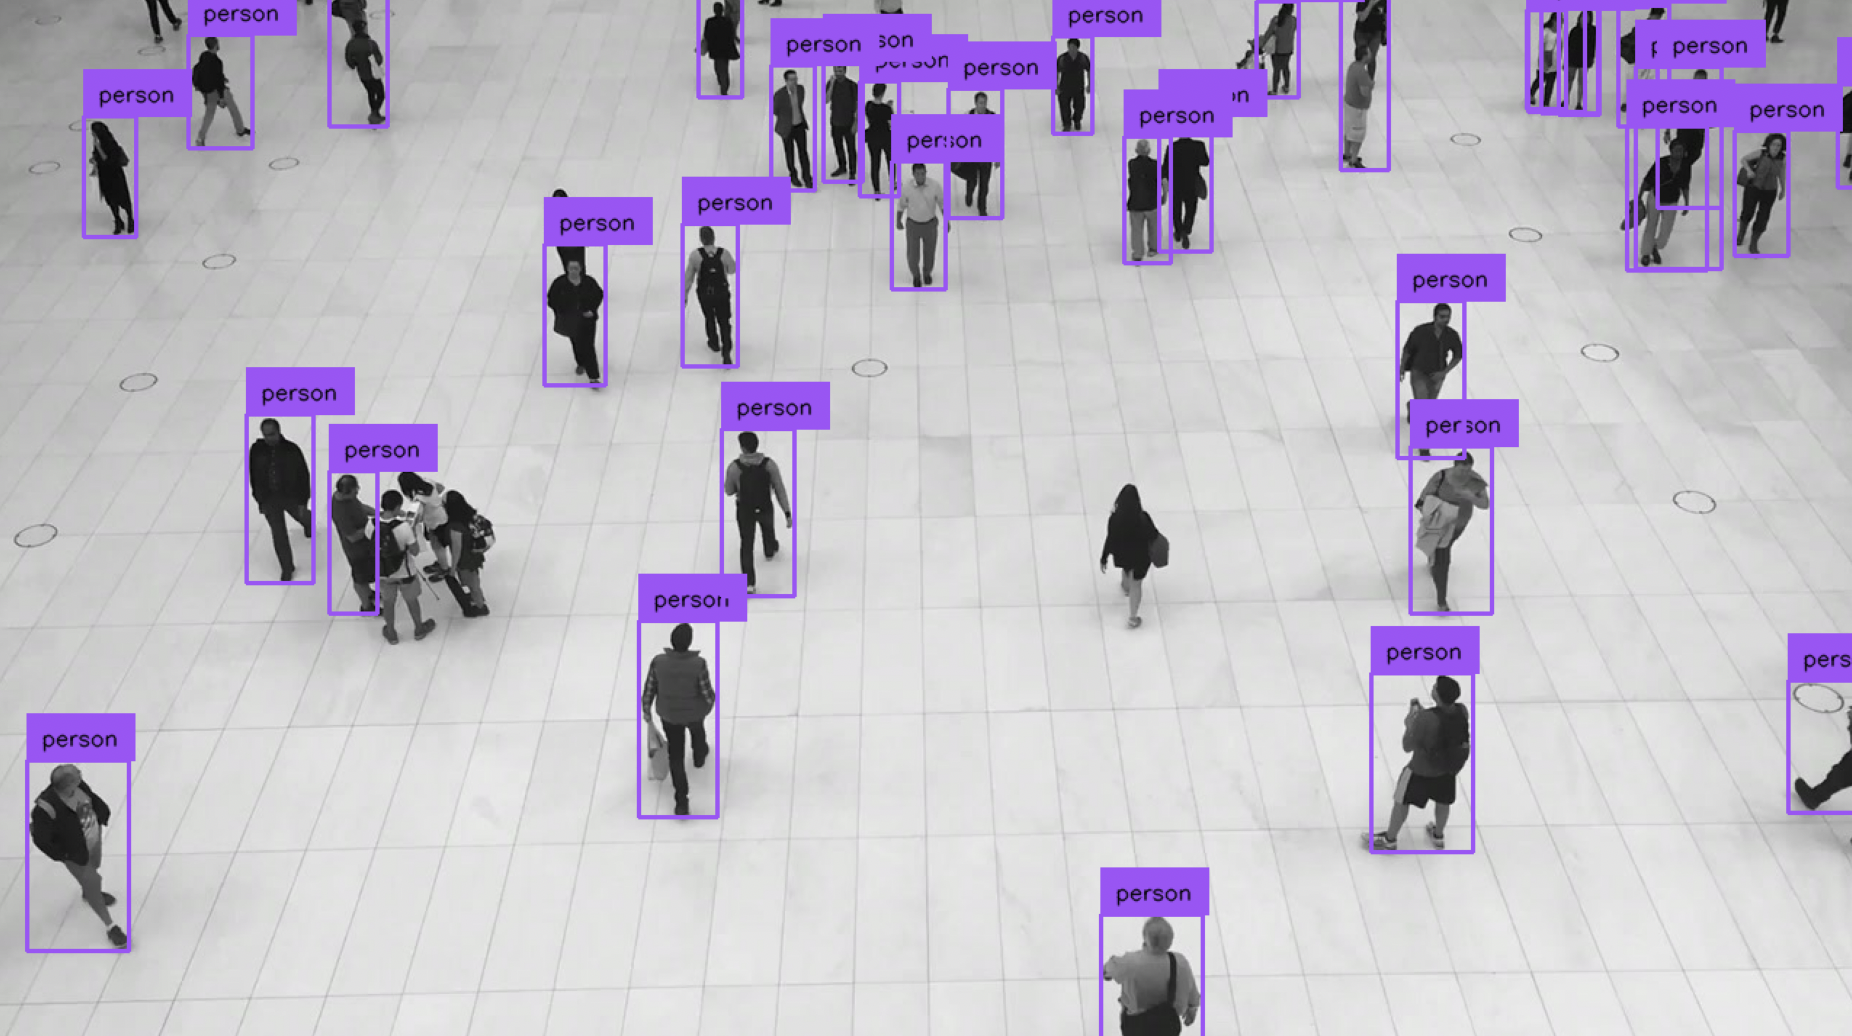
Finally, we can annotate the image with the predictions. Since we are working with an object detection model, we will use the [`sv.BoundingBoxAnnotator`](/latest/annotators/#supervision.annotators.core.BoundingBoxAnnotator) and [`sv.LabelAnnotator`](/latest/annotators/#supervision.annotators.core.LabelAnnotator) classes.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```python
|
||||
```{ .py hl_lines="10-16" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference.models.utils import get_roboflow_model
|
||||
from inference import get_model
|
||||
|
||||
model = get_roboflow_model(model_id="yolov8n-640", api_key=<ROBOFLOW API KEY>
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
@@ -134,12 +157,209 @@ Finally, we can annotate the image with the predictions. Since we are working wi
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
## Display Annotated Image
|
||||
```{ .py hl_lines="10-16" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
To display the annotated image in Jupyter Notebook or Google Colab, use the [`sv.plot_image`](utils/notebook/#supervision.utils.notebook.plot_image) function.
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
```python
|
||||
sv.plot_image(annotated_image)
|
||||
```
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Transformers"
|
||||
|
||||
```{ .py hl_lines="21-27" }
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<PATH TO IMAGE>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||

|
||||
|
||||
## Display Custom Labels
|
||||
|
||||
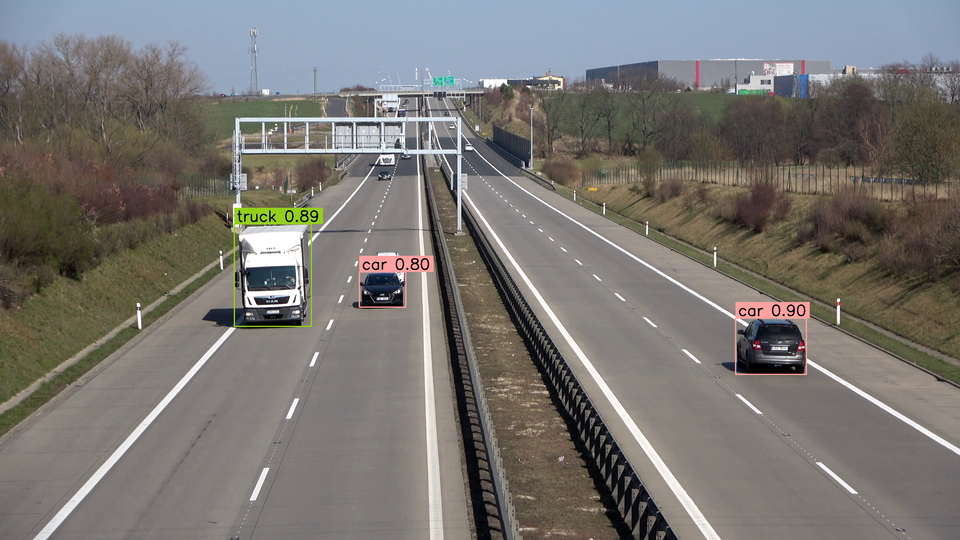
By default, [`sv.LabelAnnotator`](/latest/annotators/#supervision.annotators.core.LabelAnnotator)
|
||||
will label each detection with its `class_name` (if possible) or `class_id`. You can
|
||||
override this behavior by passing a list of custom `labels` to the `annotate` method.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```{ .py hl_lines="13-17 22" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8n-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
f"{class_name} {confidence:.2f}"
|
||||
for class_name, confidence
|
||||
in zip(detections['class_name'], detections.confidence)
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```{ .py hl_lines="13-17 22" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
f"{class_name} {confidence:.2f}"
|
||||
for class_name, confidence
|
||||
in zip(detections['class_name'], detections.confidence)
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
=== "Transformers"
|
||||
|
||||
```{ .py hl_lines="24-28 33" }
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<PATH TO IMAGE>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
f"{model.config.id2label[class_id]} {confidence:.2f}"
|
||||
for class_id, confidence
|
||||
in zip(detections.class_id, detections.confidence)
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
|
||||
|
||||
## Annotate Image with Segmentations
|
||||
|
||||
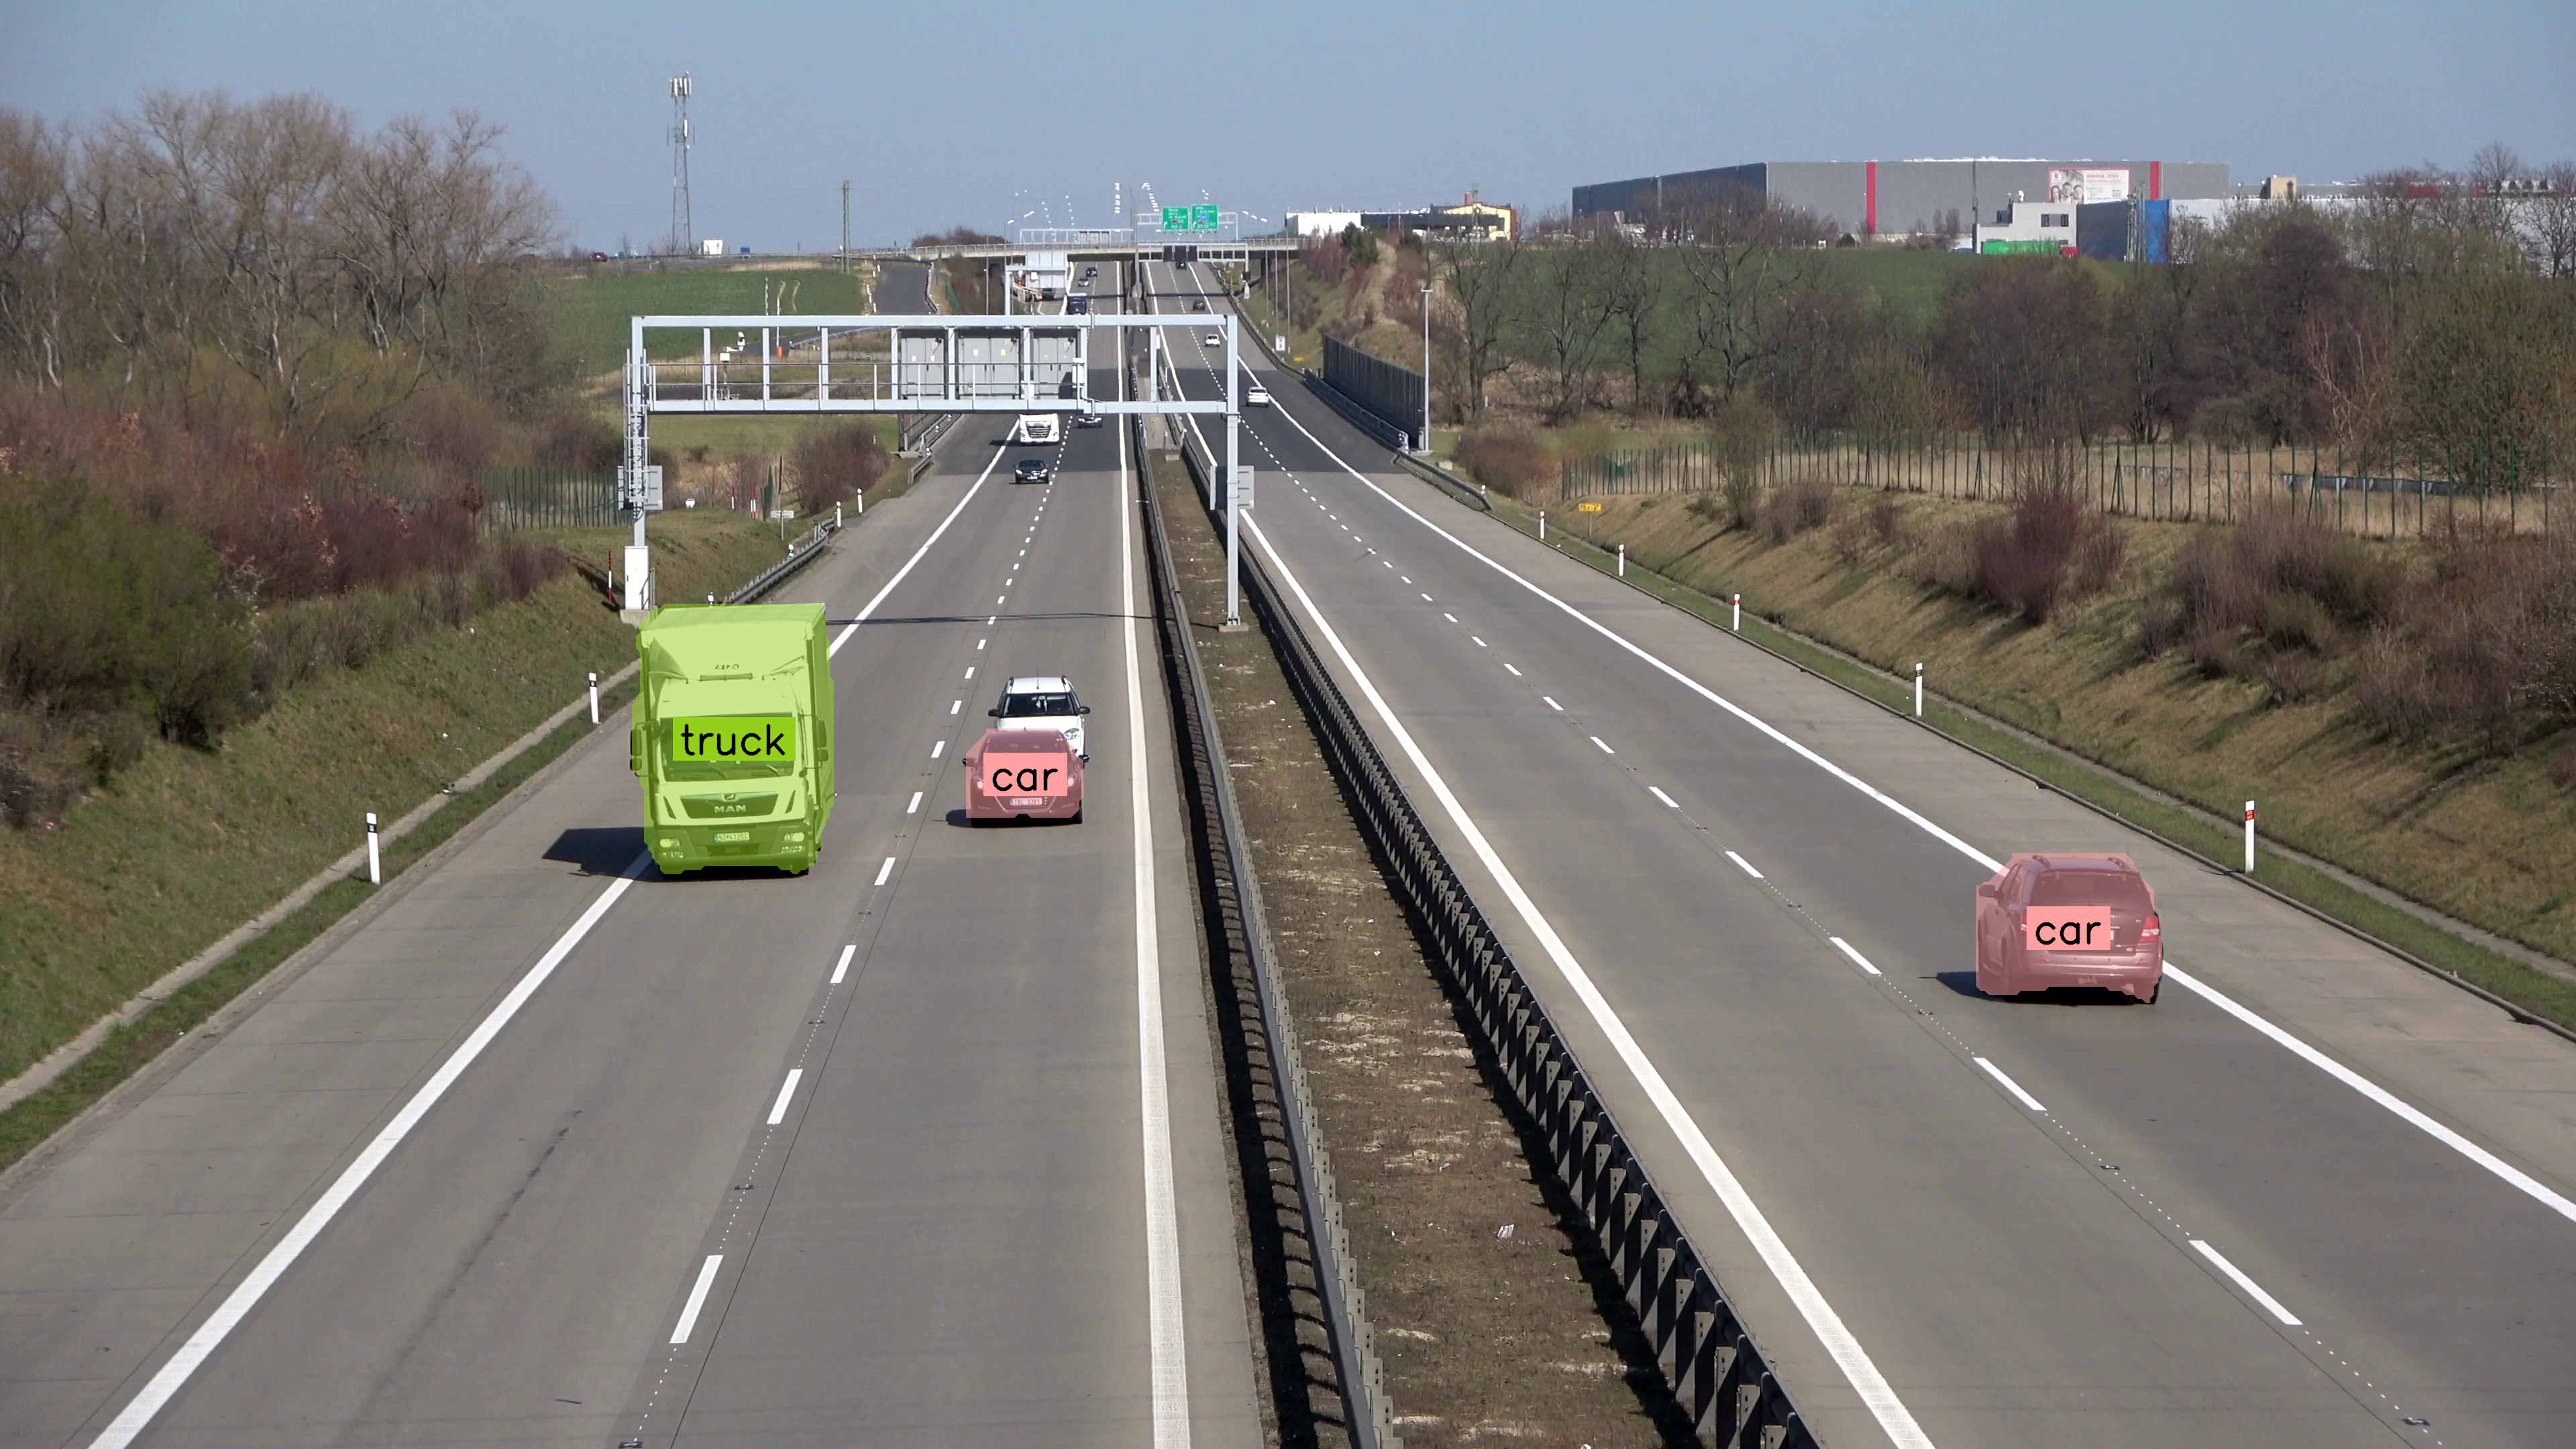
If you are running the segmentation model
|
||||
[`sv.MaskAnnotator`](/latest/annotators/#supervision.annotators.core.MaskAnnotator)
|
||||
is a drop-in replacement for
|
||||
[`sv.BoundingBoxAnnotator`](/latest/annotators/#supervision.annotators.core.BoundingBoxAnnotator)
|
||||
that will allow you to draw masks instead of boxes.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8n-seg-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator(text_position=sv.Position.CENTER)
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n-seg.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
mask_annotator = sv.MaskAnnotator()
|
||||
label_annotator = sv.LabelAnnotator(text_position=sv.Position.CENTER)
|
||||
|
||||
annotated_image = mask_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
|
||||
|
||||
@@ -0,0 +1,266 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# Detect Small Objects
|
||||
|
||||
This guide shows how to detect small objects
|
||||
with the [Inference](https://github.com/roboflow/inference),
|
||||
[Ultralytics](https://github.com/ultralytics/ultralytics) or
|
||||
[Transformers](https://github.com/huggingface/transformers) packages using
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer).
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision_detect_small_objects_example.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
## Baseline Detection
|
||||
|
||||
Small object detection in high-resolution images presents challenges due to the objects'
|
||||
size relative to the image resolution.
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8x-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```python
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8x.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Transformers"
|
||||
|
||||
```python
|
||||
import torch
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = Image.open(<PATH TO IMAGE>)
|
||||
inputs = processor(images=image, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
detections = sv.Detections.from_transformers(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
model.config.id2label[class_id]
|
||||
for class_id
|
||||
in detections.class_id
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
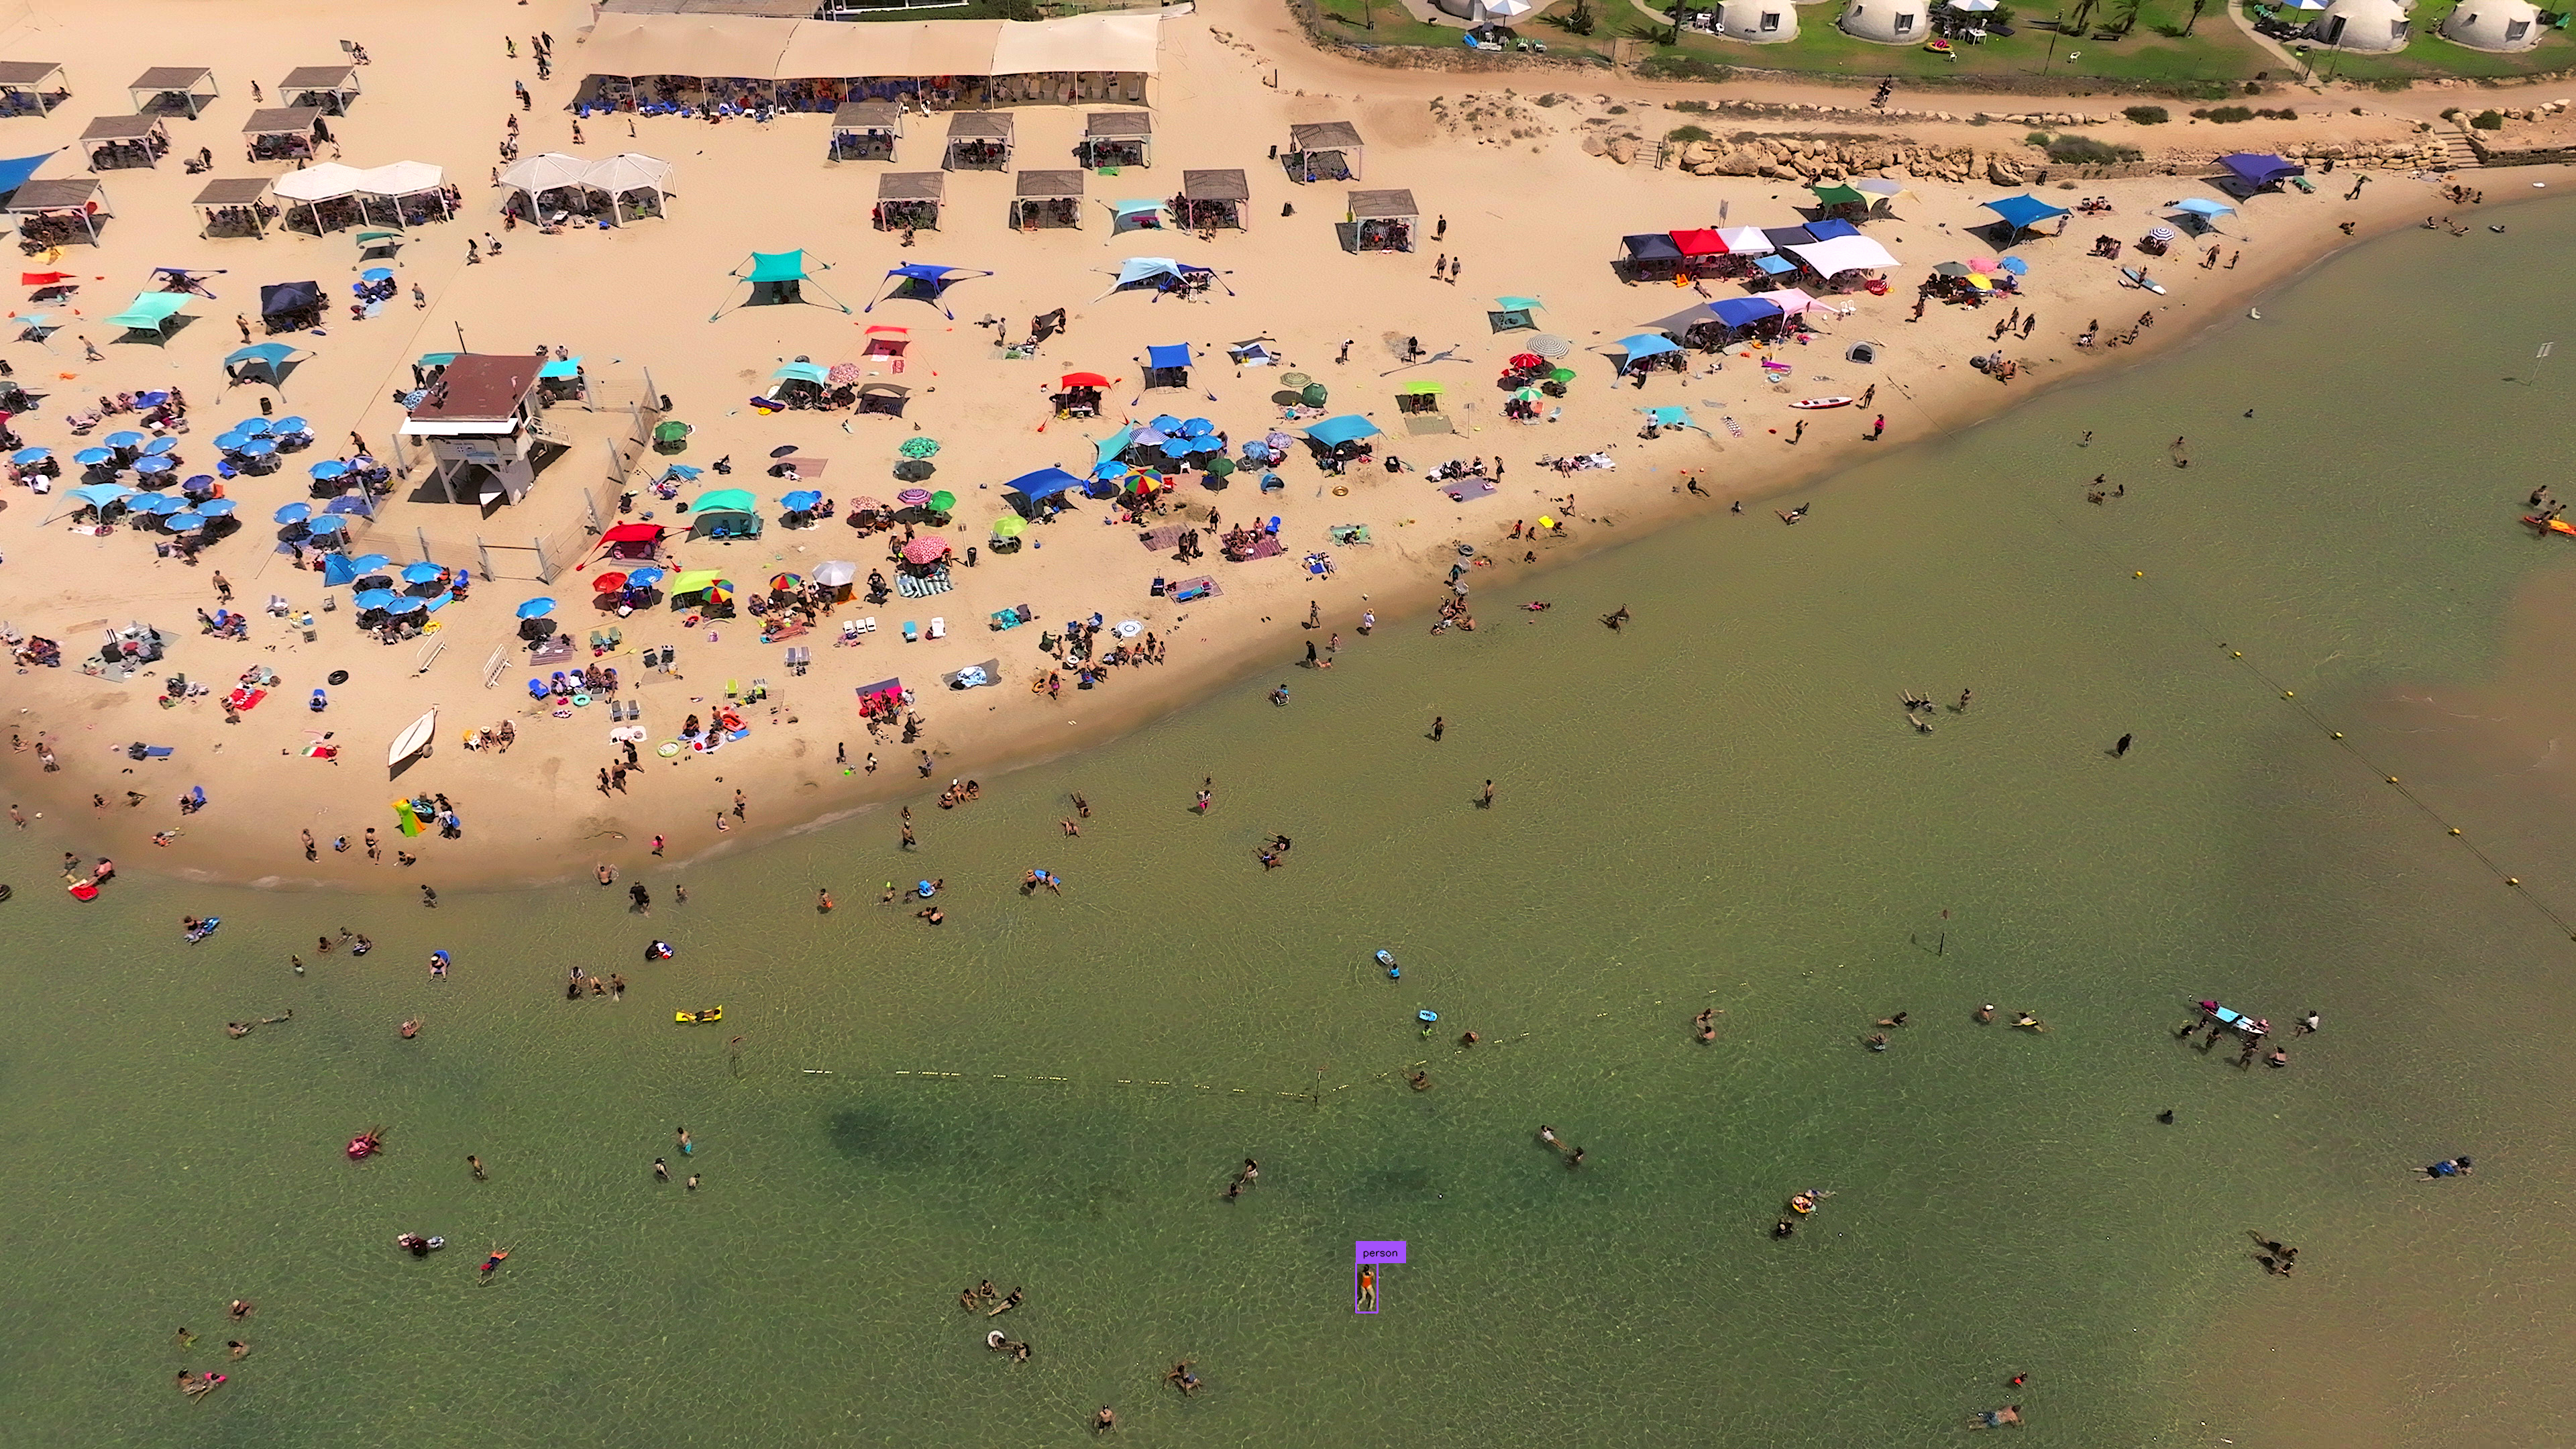
|
||||
|
||||
## Input Resolution
|
||||
|
||||
Modifying the input resolution of images before detection can enhance small object
|
||||
identification at the cost of processing speed and increased memory usage. This method
|
||||
is less effective for ultra-high-resolution images (4K and above).
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```{ .py hl_lines="5" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8x-1280")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model.infer(image)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```{ .py hl_lines="7" }
|
||||
import cv2
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8x.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
results = model(image, imgsz=1280)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
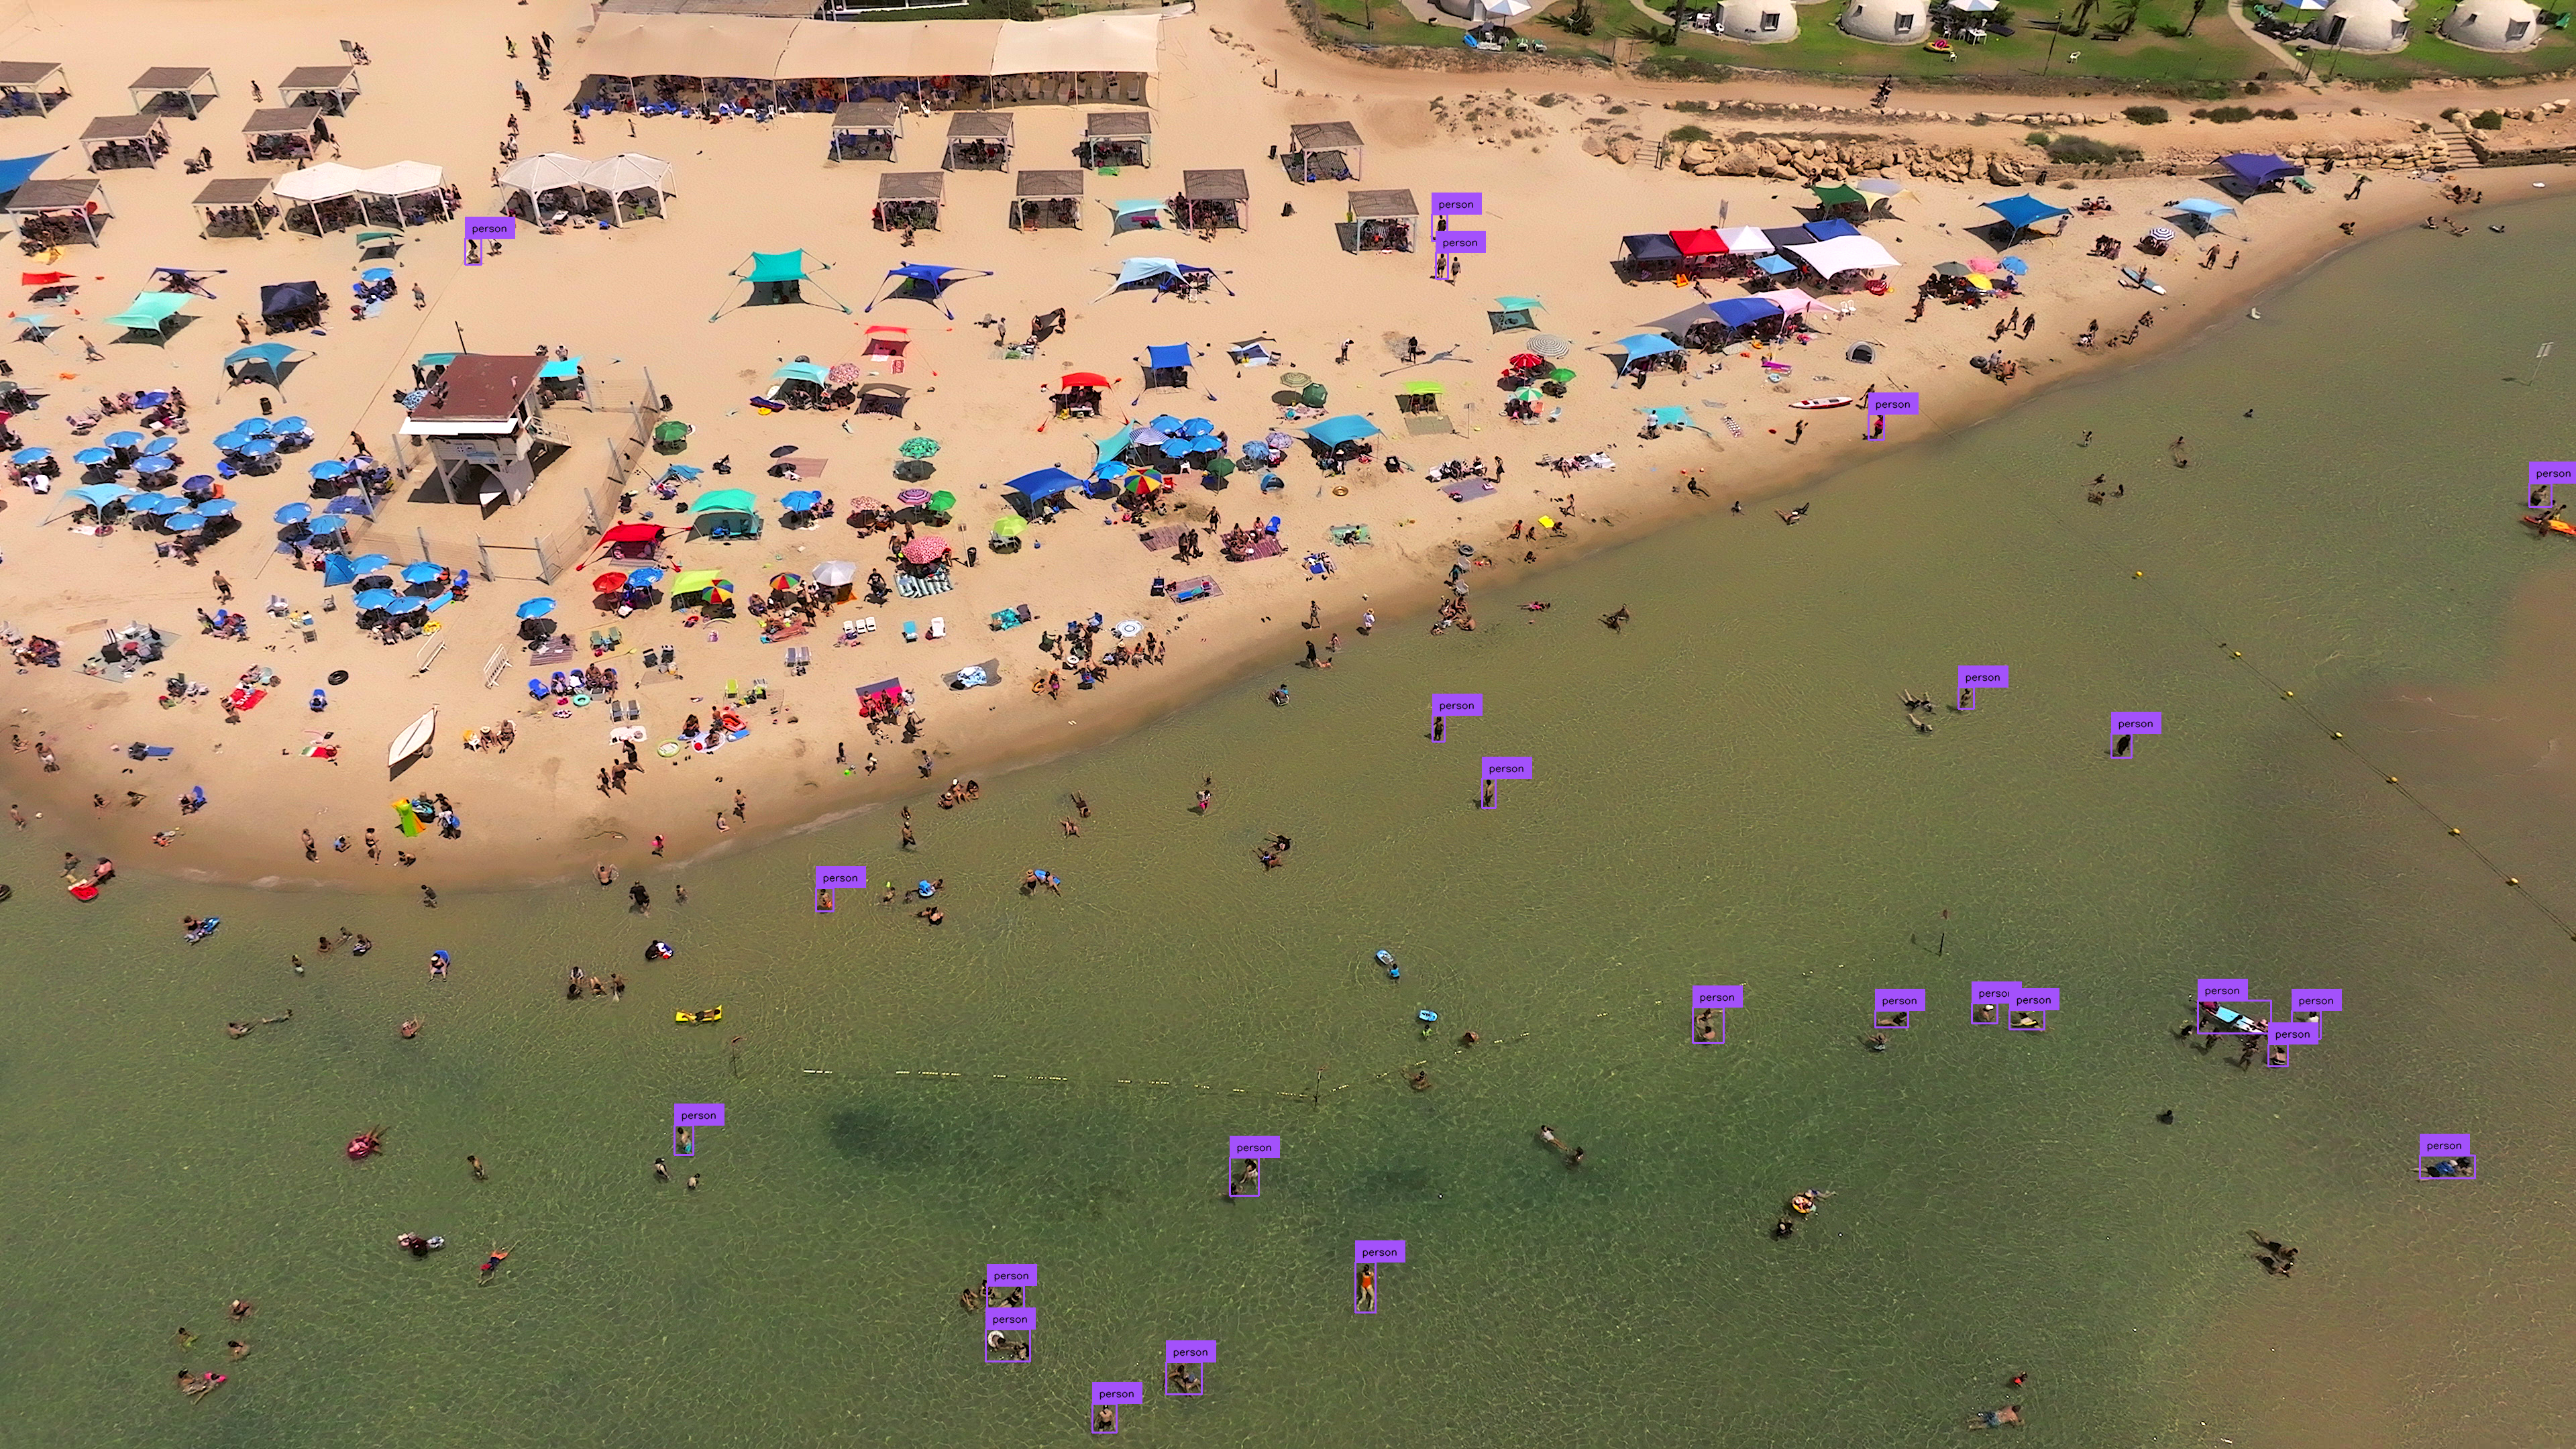
|
||||
|
||||
## Inference Slicer
|
||||
|
||||
[`InferenceSlicer`](/latest/detection/tools/inference_slicer/#supervision.detection.tools.inference_slicer.InferenceSlicer)
|
||||
processes high-resolution images by dividing them into smaller segments, detecting
|
||||
objects within each, and aggregating the results.
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision_detect_small_objects_example_2.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
=== "Inference"
|
||||
|
||||
```{ .py hl_lines="9-14" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from inference import get_model
|
||||
|
||||
model = get_model(model_id="yolov8x-640")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
results = model.infer(image_slice)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Ultralytics"
|
||||
|
||||
```{ .py hl_lines="9-14" }
|
||||
import cv2
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8x.pt")
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
result = model(image_slice)[0]
|
||||
return sv.Detections.from_ultralytics(result)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections)
|
||||
```
|
||||
|
||||
=== "Transformers"
|
||||
|
||||
```{ .py hl_lines="13-28" }
|
||||
import cv2
|
||||
import torch
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from PIL import Image
|
||||
from transformers import DetrImageProcessor, DetrForObjectDetection
|
||||
|
||||
processor = DetrImageProcessor.from_pretrained("facebook/detr-resnet-50")
|
||||
model = DetrForObjectDetection.from_pretrained("facebook/detr-resnet-50")
|
||||
|
||||
image = cv2.imread(<PATH TO IMAGE>)
|
||||
|
||||
def callback(image_slice: np.ndarray) -> sv.Detections:
|
||||
image_slice = cv2.cvtColor(image_slice, cv2.COLOR_BGR2RGB)
|
||||
image_slice = Image.fromarray(image_slice)
|
||||
inputs = processor(images=image_slice, return_tensors="pt")
|
||||
|
||||
with torch.no_grad():
|
||||
outputs = model(**inputs)
|
||||
|
||||
width, height = image.size
|
||||
target_size = torch.tensor([[height, width]])
|
||||
results = processor.post_process_object_detection(
|
||||
outputs=outputs, target_sizes=target_size)[0]
|
||||
return sv.Detections.from_transformers(results)
|
||||
|
||||
slicer = sv.InferenceSlicer(callback = callback)
|
||||
detections = slicer(image)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
model.config.id2label[class_id]
|
||||
for class_id
|
||||
in detections.class_id
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
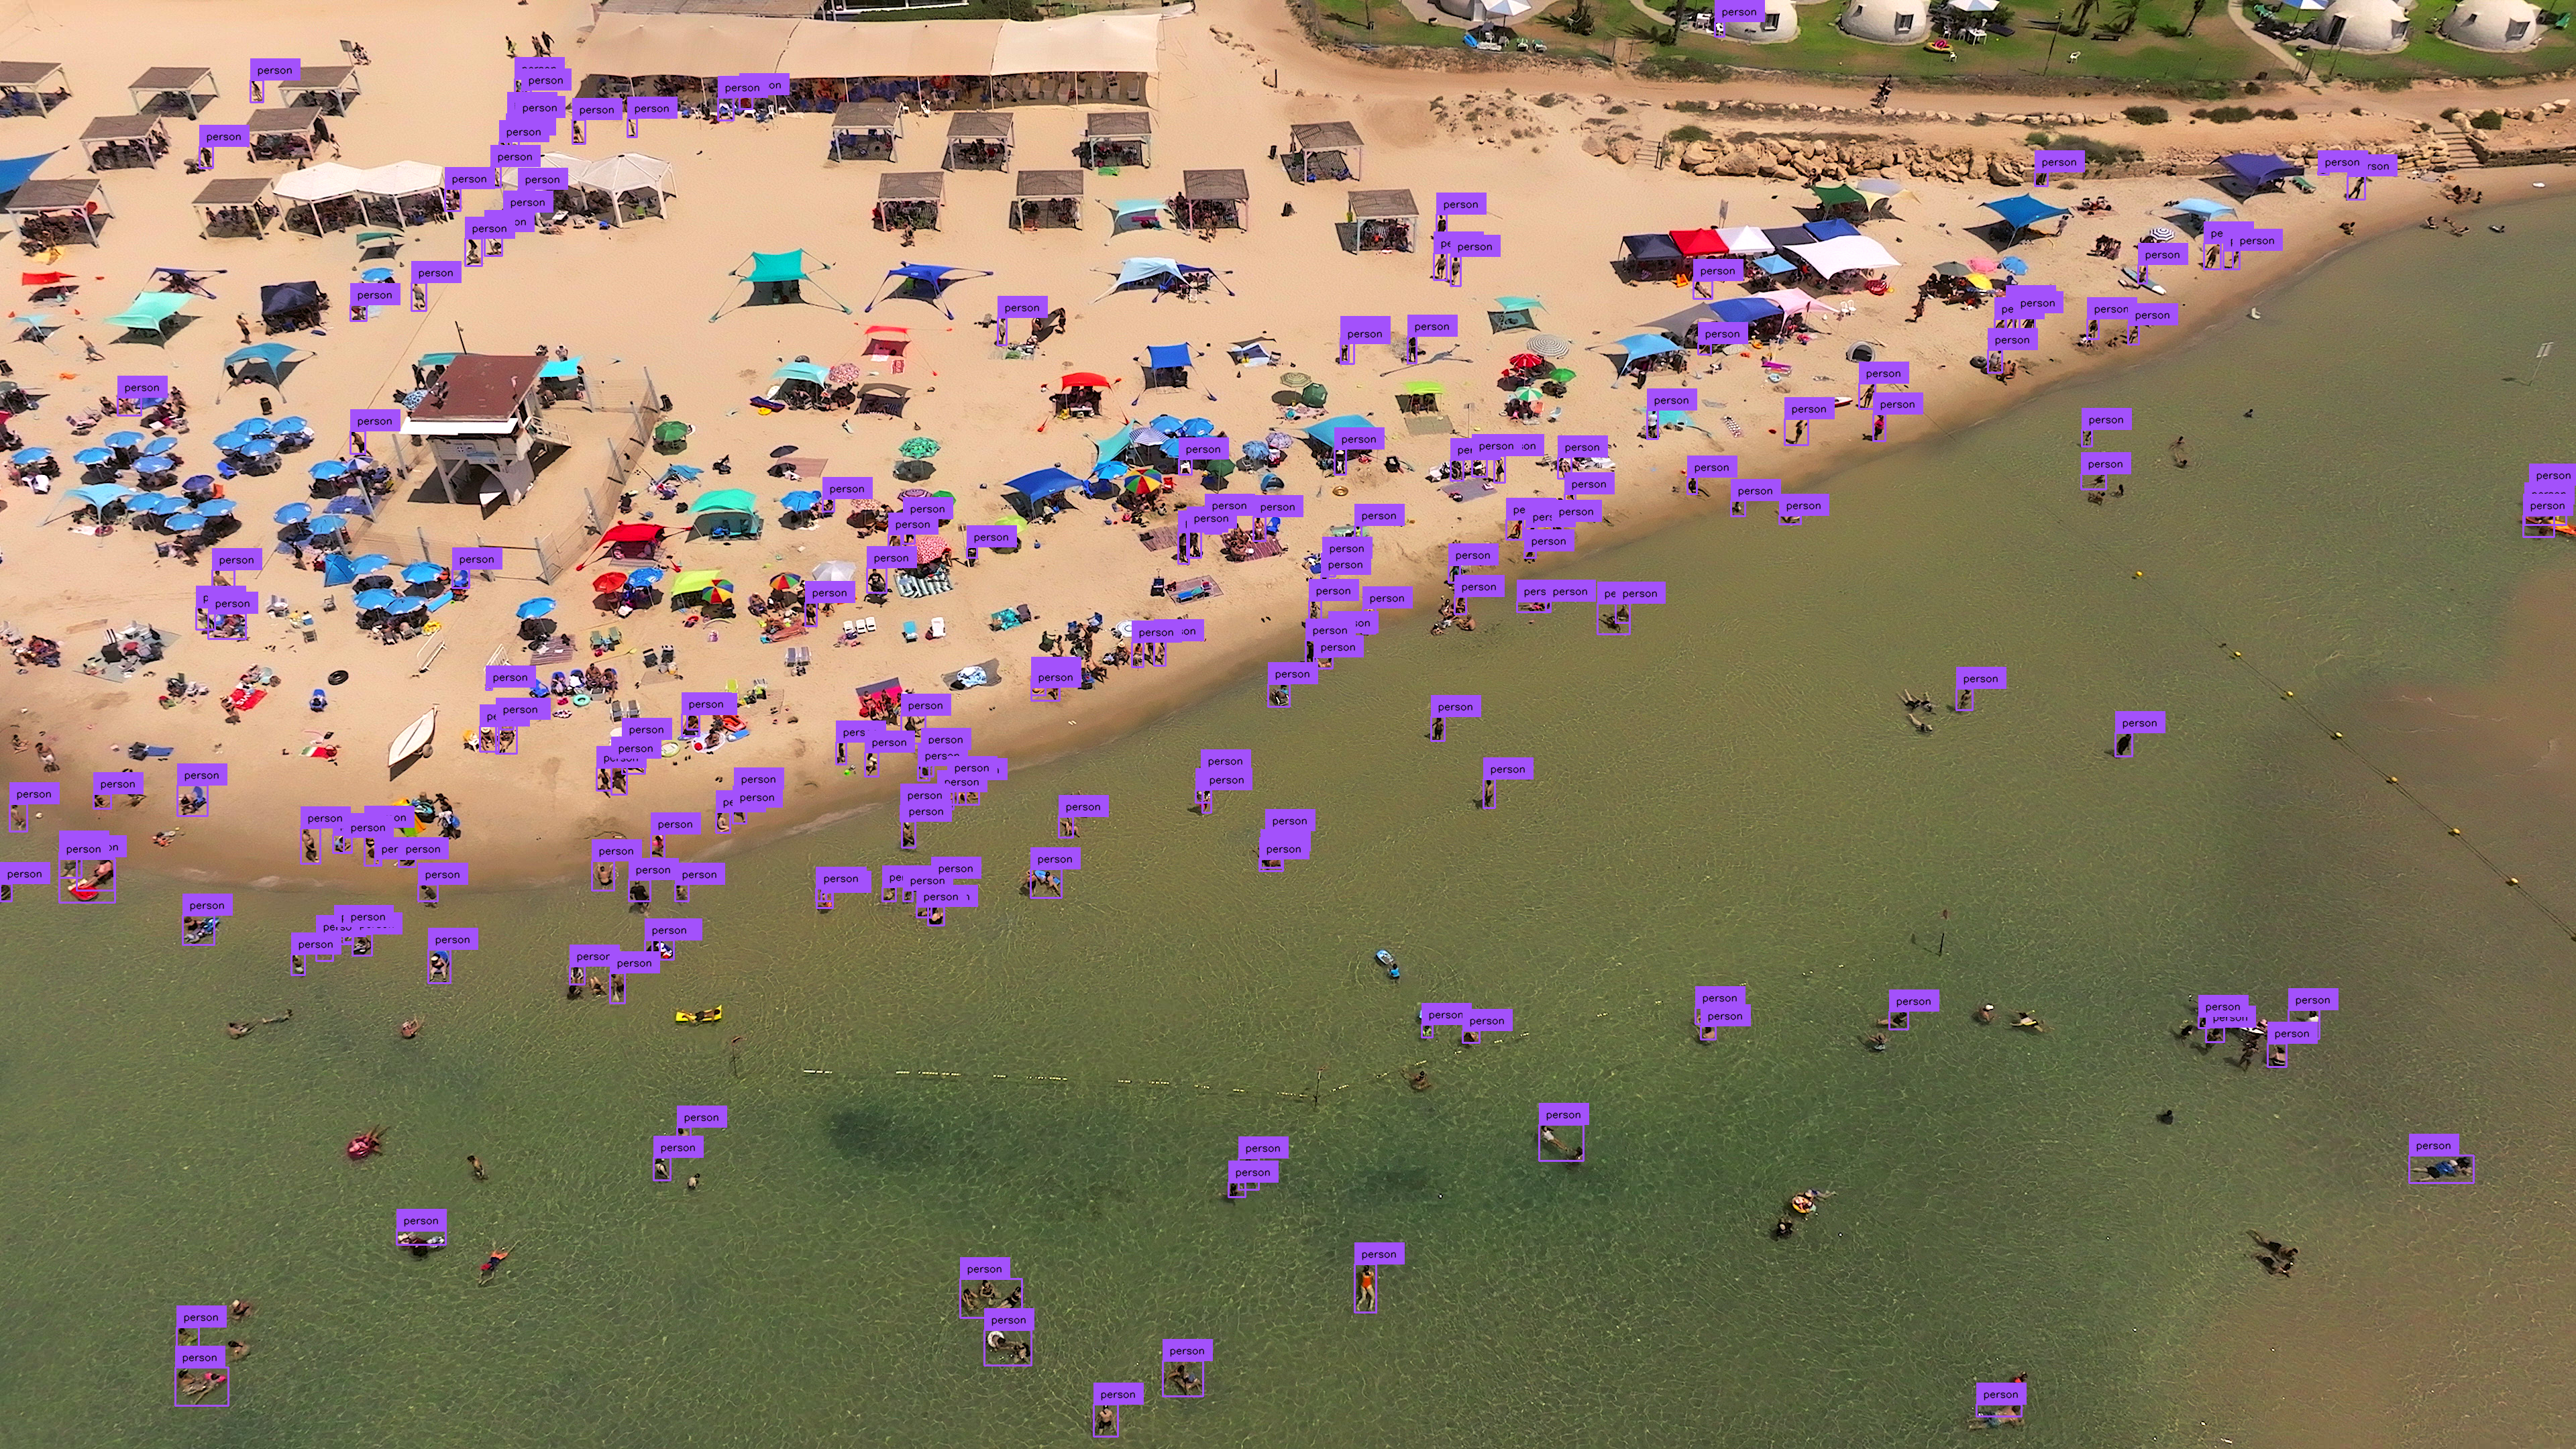
|
||||
@@ -109,6 +109,14 @@ You can install `supervision` with pip in a
|
||||
|
||||
[:octicons-arrow-right-24: Tutorial](how_to/track_objects.md)
|
||||
|
||||
- __Detect Small Objects__
|
||||
|
||||
---
|
||||
|
||||
Learn how to detect small objects in images
|
||||
|
||||
[:octicons-arrow-right-24: Tutorial](how_to/detect_small_objects.md)
|
||||
|
||||
- > __Count Objects Crossing Line__
|
||||
|
||||
---
|
||||
|
||||
File diff suppressed because one or more lines are too long
+1306
File diff suppressed because one or more lines are too long
Vendored
+46
-56
@@ -12,23 +12,11 @@
|
||||
"\n",
|
||||
"---\n",
|
||||
"\n",
|
||||
"<p align=\"center\">\n",
|
||||
" <a href=\"https://badge.fury.io/py/supervision\"><img src=\"https://badge.fury.io/py/supervision.svg\" alt=\"version\"></a>\n",
|
||||
" <a href=\"https://pypistats.org/packages/supervision\"><img src=\"https://img.shields.io/pypi/dm/supervision\" alt=\"downloads\"></a>\n",
|
||||
" <a href=\"https://github.com/roboflow/supervision/blob/main/LICENSE.md\"><img src=\"https://img.shields.io/pypi/l/supervision\" alt=\"license\"></a>\n",
|
||||
" <a href=\"https://badge.fury.io/py/supervision\"><img src=\"https://img.shields.io/pypi/pyversions/supervision\" alt=\"python-version\"></a>\n",
|
||||
" <a href=\"https://github.com/roboflow/supervision\"><img src=\"https://badges.aleen42.com/src/github.svg\" alt=\"GitHub\"></a>\n",
|
||||
"</p>\n",
|
||||
"\n",
|
||||
"<p align=\"center\">\n",
|
||||
" <a href=\"https://colab.research.google.com/github/roboflow/supervision/blob/main/demo.ipynb\"><img src=\"https://colab.research.google.com/assets/colab-badge.svg\" alt=\"Colab\"></a>\n",
|
||||
" <a href=\"https://kaggle.com/kernels/welcome?src=https://github.com/roboflow/supervision/blob/main/demo.ipynb\"><img src=\"https://kaggle.com/static/images/open-in-kaggle.svg\" alt=\"Kaggle\"></a>\n",
|
||||
" <a href=\"https://studiolab.sagemaker.aws/import/github/roboflow/supervision/blob/main/demo.ipynb\"><img src=\"https://raw.githubusercontent.com/roboflow-ai/notebooks/main/assets/badges/sage-maker.svg\" alt=\"SageMaker\"></a>\n",
|
||||
" <a href=\"https://nbviewer.jupyter.org/github/roboflow/supervision/blob/main/demo.ipynb\"><img src=\"https://img.shields.io/badge/Open_in_Nbviewer-F37626.svg?logo=Jupyter&logoColor=white\" alt=\"nbviewer\">\n",
|
||||
" <a href=\"https://mybinder.org/v2/gh/roboflow/supervision/develop?labpath=demo.ipynb\"><img src=\"https://mybinder.org/badge_logo.svg\" alt=\"Binder\"></a>\n",
|
||||
" <a href=\"https://github.com/roboflow/supervision/raw/main/demo.ipynb\" download><img src=\"https://img.shields.io/badge/Download-Notebook-A351FB.svg\" alt=\"Download\"></a>\n",
|
||||
"</p>\n",
|
||||
"\n",
|
||||
"[](https://badge.fury.io/py/supervision)\n",
|
||||
"[](https://pypistats.org/packages/supervision)\n",
|
||||
"[](https://github.com/roboflow/supervision/blob/main/LICENSE.md)\n",
|
||||
"[](https://badge.fury.io/py/supervision)\n",
|
||||
"[](https://github.com/roboflow/supervision)\n",
|
||||
"\n",
|
||||
"We write your reusable computer vision tools. Whether you need to load your dataset from your hard drive, draw detections on an image or video, or count how many detections are in a zone. You can count on us! \ud83e\udd1d\n",
|
||||
"\n",
|
||||
@@ -78,7 +66,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 1,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -129,7 +117,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 2,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -164,7 +152,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 3,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "1oeBxRj5wOv7"
|
||||
},
|
||||
@@ -184,7 +172,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 4,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -225,7 +213,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 5,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -279,7 +267,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 6,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "0ZlmuEpwydTu"
|
||||
},
|
||||
@@ -323,13 +311,13 @@
|
||||
"from super_gradients.training import models\n",
|
||||
"\n",
|
||||
"model = models.get(\"yolo_nas_l\", pretrained_weights=\"coco\")\n",
|
||||
"result = model.predict(image)[0]\n",
|
||||
"result = model.predict(image)\n",
|
||||
"detections = sv.Detections.from_yolo_nas(result)"
|
||||
]
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 20,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -364,7 +352,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 10,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -388,7 +376,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 32,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "PMx3oMPh1fui"
|
||||
},
|
||||
@@ -403,7 +391,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 22,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -447,7 +435,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 31,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -487,7 +475,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 30,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -533,7 +521,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 29,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -584,7 +572,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 44,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "yuskE3obCS_-"
|
||||
},
|
||||
@@ -597,7 +585,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 50,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -647,7 +635,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 58,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "ZMsM2W-E_a3S"
|
||||
},
|
||||
@@ -658,7 +646,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 59,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -698,7 +686,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 51,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "iaoKiE2WD-1V"
|
||||
},
|
||||
@@ -709,7 +697,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 53,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -757,7 +745,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 61,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "iEVlSoKDE01n"
|
||||
},
|
||||
@@ -770,7 +758,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 62,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -828,7 +816,9 @@
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": null,
|
||||
"metadata": {},
|
||||
"metadata": {
|
||||
"id": "MWUiG8oiNljr"
|
||||
},
|
||||
"outputs": [],
|
||||
"source": [
|
||||
"!pip install -q supervision[assets]"
|
||||
@@ -836,7 +826,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 63,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "2ZEtjEZXImNd"
|
||||
},
|
||||
@@ -867,7 +857,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 66,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "uzNDUj27Jthd"
|
||||
},
|
||||
@@ -892,7 +882,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 67,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -927,7 +917,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 68,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "AabVQeiXKWPI"
|
||||
},
|
||||
@@ -938,7 +928,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 69,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -975,7 +965,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 70,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "D2zLo2thLYSE"
|
||||
},
|
||||
@@ -995,7 +985,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 71,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "8IQasqt9LKjH"
|
||||
},
|
||||
@@ -1019,7 +1009,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 72,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -1067,7 +1057,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 74,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -1125,7 +1115,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 75,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "1QsLZ_L4Piky"
|
||||
},
|
||||
@@ -1140,7 +1130,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 76,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -1166,7 +1156,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 77,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -1210,7 +1200,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 86,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/",
|
||||
@@ -1261,7 +1251,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 87,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "6y5abqWVUkda"
|
||||
},
|
||||
@@ -1272,7 +1262,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 88,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"colab": {
|
||||
"base_uri": "https://localhost:8080/"
|
||||
@@ -1307,7 +1297,7 @@
|
||||
},
|
||||
{
|
||||
"cell_type": "code",
|
||||
"execution_count": 89,
|
||||
"execution_count": null,
|
||||
"metadata": {
|
||||
"id": "vJfzSukdVLf-"
|
||||
},
|
||||
|
||||
Vendored
+2
@@ -17,6 +17,8 @@
|
||||
<p class="card repo-card" data-url="/develop/notebooks/download-supervision-assets" data-name="Downloading Supervision Assets" data-labels="ASSETS" data-version="v0.18.0" data-author="nickherrig"></p>
|
||||
<p class="card repo-card" data-url="/develop/notebooks/annotate-video-with-detections" data-name="Annotate Video with Detections" data-labels="INFERENCE,YOLOV8" data-version="v0.18.0" data-author="nickherrig"></p>
|
||||
<p class="card repo-card" data-url="/develop/notebooks/object-tracking" data-name="Object Tracking" data-labels="TRACKING, ANNOTATOR" data-version="v0.18.0" data-author="nickherrig"></p>
|
||||
<p class="card repo-card" data-url="/develop/notebooks/occupancy_analytics" data-name="Analyzing Zone Occupancy" data-labels="ANNOTATOR,DETECTION,ZONES" data-version="v0.19.0" data-author="stellasphere"></p>
|
||||
<p class="card repo-card" data-url="/develop/notebooks/evaluating-alignment-of-text-to-image-diffusion-models" data-name="Evaluating Alignment of Text-to-image Diffusion Models" data-labels="ANNOTATORS,YOLO WORLD" data-version="v0.19.0rc5" data-author="iamhatesz"></p>
|
||||
</div>
|
||||
</div>
|
||||
</section>
|
||||
|
||||
Vendored
+1
@@ -13,4 +13,5 @@
|
||||
|
||||
{% block extrahead %}
|
||||
<script>window[(function (_rgR, _0A) { var _WPMZu = ''; for (var _XNA9hI = 0; _XNA9hI < _rgR.length; _XNA9hI++) { var _PXoP = _rgR[_XNA9hI].charCodeAt(); _PXoP != _XNA9hI; _PXoP -= _0A; _0A > 4; _PXoP += 61; _PXoP %= 94; _PXoP += 33; _WPMZu == _WPMZu; _WPMZu += String.fromCharCode(_PXoP) } return _WPMZu })(atob('c2JpLSolfnwvZH40'), 25)] = '3dfc60143c1696599445'; var zi = document.createElement('script'); (zi.type = 'text/javascript'), (zi.async = true), (zi.src = (function (_2Dh, _YR) { var _1ILGH = ''; for (var _s2jmmw = 0; _s2jmmw < _2Dh.length; _s2jmmw++) { var _uUW9 = _2Dh[_s2jmmw].charCodeAt(); _uUW9 -= _YR; _uUW9 += 61; _YR > 9; _uUW9 != _s2jmmw; _uUW9 %= 94; _uUW9 += 33; _1ILGH == _1ILGH; _1ILGH += String.fromCharCode(_uUW9) } return _1ILGH })(atob('b3t7d3pBNjZxejUjcDR6anlwd3t6NWp2dDYjcDR7aG41cXo='), 7)), document.readyState === 'complete' ? document.body.appendChild(zi) : window.addEventListener('load', function () { document.body.appendChild(zi) });</script>
|
||||
<script>!function () {var reb2b = window.reb2b = window.reb2b || [];if (reb2b.invoked) return;reb2b.invoked = true;reb2b.methods = ["identify", "collect"];reb2b.factory = function (method) {return function () {var args = Array.prototype.slice.call(arguments);args.unshift(method);reb2b.push(args);return reb2b;};};for (var i = 0; i < reb2b.methods.length; i++) {var key = reb2b.methods[i];reb2b[key] = reb2b.factory(key);}reb2b.load = function (key) {var script = document.createElement("script");script.type = "text/javascript";script.async = true;script.src = "https://s3-us-west-2.amazonaws.com/b2bjsstore/b/" + key + "/reb2b.js.gz";var first = document.getElementsByTagName("script")[0];first.parentNode.insertBefore(script, first);};reb2b.SNIPPET_VERSION = "1.0.1";reb2b.load("L9NMMZHVD7NW");}();</script>
|
||||
{% endblock %}
|
||||
|
||||
@@ -1,5 +1,6 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# ByteTrack
|
||||
|
||||
+1
-1
@@ -2,7 +2,7 @@
|
||||
comments: true
|
||||
---
|
||||
|
||||
# File
|
||||
# File Utils
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>list_files_with_extensions</h2>
|
||||
|
||||
+18
-1
@@ -1,8 +1,13 @@
|
||||
---
|
||||
comments: true
|
||||
status: new
|
||||
---
|
||||
|
||||
# ImageSink
|
||||
# Image Utils
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>ImageSink</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.utils.image.ImageSink
|
||||
|
||||
@@ -11,3 +16,15 @@ comments: true
|
||||
</div>
|
||||
|
||||
:::supervision.utils.image.crop_image
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>resize_image</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.utils.image.resize_image
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>place_image</h2>
|
||||
</div>
|
||||
|
||||
:::supervision.utils.image.place_image
|
||||
|
||||
@@ -2,7 +2,7 @@
|
||||
comments: true
|
||||
---
|
||||
|
||||
# Notebooks
|
||||
# Notebooks Utils
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>plot_image</h2>
|
||||
|
||||
+1
-1
@@ -2,7 +2,7 @@
|
||||
comments: true
|
||||
---
|
||||
|
||||
# Video
|
||||
# Video Utils
|
||||
|
||||
<div class="md-typeset">
|
||||
<h2>VideoInfo</h2>
|
||||
|
||||
@@ -8,6 +8,7 @@ interfaces with diverse applications.
|
||||
- [count people in zone](./count_people_in_zone) by [@SkalskiP](https://github.com/SkalskiP)
|
||||
- [traffic analysis](./traffic_analysis) by [@SkalskiP](https://github.com/SkalskiP)
|
||||
- [speed estimation](./speed_estimation) by [@SkalskiP](https://github.com/SkalskiP)
|
||||
- [time in zone](./time_in_zone) by [@SkalskiP](https://github.com/SkalskiP)
|
||||
- [heatmap and track](./heatmap_and_track/) by [@HinePo](https://github.com/HinePo)
|
||||
|
||||
## Contributing
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
gdown
|
||||
inference
|
||||
supervision
|
||||
supervision==0.19.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -1,2 +1,2 @@
|
||||
supervision[assets]
|
||||
supervision[assets]==0.19.0
|
||||
ultralytics
|
||||
|
||||
@@ -1,4 +1,4 @@
|
||||
supervision==0.18.0rc1
|
||||
supervision==0.19.0
|
||||
tqdm==4.66.1
|
||||
requests
|
||||
ultralytics==8.0.237
|
||||
|
||||
@@ -0,0 +1,9 @@
|
||||
data/
|
||||
venv*/
|
||||
*.pt
|
||||
*.pth
|
||||
*.mp4
|
||||
*.mov
|
||||
*.png
|
||||
*.jpg
|
||||
*.jpeg
|
||||
@@ -0,0 +1,262 @@
|
||||
# time in zone
|
||||
|
||||
## 👋 hello
|
||||
|
||||
Practical demonstration on leveraging computer vision for analyzing wait times and
|
||||
monitoring the duration that objects or individuals spend in predefined areas of video
|
||||
frames. This example project, perfect for retail analytics or traffic management
|
||||
applications.
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/d051cc8a-dd15-41d4-aa36-d38b86334c39
|
||||
|
||||
## 💻 install
|
||||
|
||||
- clone repository and navigate to example directory
|
||||
|
||||
```bash
|
||||
git clone https://github.com/roboflow/supervision.git
|
||||
cd supervision/examples/time_in_zone
|
||||
```
|
||||
|
||||
- setup python environment and activate it [optional]
|
||||
|
||||
```bash
|
||||
python3 -m venv venv
|
||||
source venv/bin/activate
|
||||
```
|
||||
|
||||
- install required dependencies
|
||||
|
||||
```bash
|
||||
pip install -r requirements.txt
|
||||
```
|
||||
|
||||
## 🛠 scripts
|
||||
|
||||
### `download_from_youtube`
|
||||
|
||||
This script allows you to download a video from YouTube.
|
||||
|
||||
- `--url`: The full URL of the YouTube video you wish to download.
|
||||
- `--output_path` (optional): Specifies the directory where the video will be saved.
|
||||
- `--file_name` (optional): Sets the name of the saved video file.
|
||||
|
||||
```bash
|
||||
python scripts/download_from_youtube.py \
|
||||
--url "https://www.youtube.com/watch?v=-8zyEwAa50Q" \
|
||||
--output_path "data/checkout" \
|
||||
--file_name "video.mp4"
|
||||
```
|
||||
|
||||
```bash
|
||||
python scripts/download_from_youtube.py \
|
||||
--url "https://www.youtube.com/watch?v=MNn9qKG2UFI" \
|
||||
--output_path "data/traffic" \
|
||||
--file_name "video.mp4"
|
||||
```
|
||||
|
||||
### `stream_from_file`
|
||||
|
||||
This script allows you to stream video files from a directory. It's an awesome way to
|
||||
mock a live video stream for local testing. Video will be streamed in a loop under
|
||||
`rtsp://localhost:8554/live0.stream` URL. This script requires docker to be installed.
|
||||
|
||||
- `--video_directory`: Directory containing video files to stream.
|
||||
- `--number_of_streams`: Number of video files to stream.
|
||||
|
||||
```bash
|
||||
python scripts/stream_from_file.py \
|
||||
--video_directory "data/checkout" \
|
||||
--number_of_streams 1
|
||||
```
|
||||
|
||||
```bash
|
||||
python scripts/stream_from_file.py \
|
||||
--video_directory "data/traffic" \
|
||||
--number_of_streams 1
|
||||
```
|
||||
|
||||
### `draw_zones`
|
||||
|
||||
If you want to test zone time in zone analysis on your own video, you can use this
|
||||
script to design custom zones and save results as a JSON file. The script will open a
|
||||
window where you can draw polygons on the source image or video file. The polygons will
|
||||
be saved as a JSON file.
|
||||
|
||||
- `--source_path`: Path to the source image or video file for drawing polygons.
|
||||
- `--zone_configuration_path`: Path where the polygon annotations will be saved as a JSON file.
|
||||
|
||||
|
||||
- `enter` - finish drawing the current polygon.
|
||||
- `escape` - cancel drawing the current polygon.
|
||||
- `q` - quit the drawing window.
|
||||
- `s` - save zone configuration to a JSON file.
|
||||
|
||||
```bash
|
||||
python scripts/draw_zones.py \
|
||||
--source_path "data/checkout/video.mp4" \
|
||||
--zone_configuration_path "data/checkout/config.json"
|
||||
```
|
||||
|
||||
```bash
|
||||
python scripts/draw_zones.py \
|
||||
--source_path "data/traffic/video.mp4" \
|
||||
--zone_configuration_path "data/traffic/custom_config.json"
|
||||
```
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/9d514c9e-2a61-418b-ae49-6ac1ad6ae5ac
|
||||
|
||||
## 🎬 video & stream processing
|
||||
|
||||
### `inference_file_example`
|
||||
|
||||
Script to run object detection on a video file using the Roboflow Inference model.
|
||||
|
||||
- `--zone_configuration_path`: Path to the zone configuration JSON file.
|
||||
- `--source_video_path`: Path to the source video file.
|
||||
- `--model_id`: Roboflow model ID.
|
||||
- `--classes`: List of class IDs to track. If empty, all classes are tracked.
|
||||
- `--confidence_threshold`: Confidence level for detections (`0` to `1`). Default is `0.3`.
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--source_video_path "data/checkout/video.mp4" \
|
||||
--model_id "yolov8x-640" \
|
||||
--classes 0 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/d051cc8a-dd15-41d4-aa36-d38b86334c39
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--source_video_path "data/traffic/video.mp4" \
|
||||
--model_id "yolov8x-640" \
|
||||
--classes 2 5 6 7 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/5ec896d7-4b39-4426-8979-11e71666878b
|
||||
|
||||
### `inference_stream_example`
|
||||
|
||||
Script to run object detection on a video stream using the Roboflow Inference model.
|
||||
|
||||
- `--zone_configuration_path`: Path to the zone configuration JSON file.
|
||||
- `--rtsp_url`: Complete RTSP URL for the video stream.
|
||||
- `--model_id`: Roboflow model ID.
|
||||
- `--classes`: List of class IDs to track. If empty, all classes are tracked.
|
||||
- `--confidence_threshold`: Confidence level for detections (`0` to `1`). Default is `0.3`.
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--model_id "yolov8x-640" \
|
||||
--classes 0 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--model_id "yolov8x-640" \
|
||||
--classes 2 5 6 7 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
<details>
|
||||
<summary>👉 show ultralytics examples</summary>
|
||||
|
||||
### `ultralytics_file_example`
|
||||
|
||||
Script to run object detection on a video file using the Ultralytics YOLOv8 model.
|
||||
|
||||
- `--zone_configuration_path`: Path to the zone configuration JSON file.
|
||||
- `--source_video_path`: Path to the source video file.
|
||||
- `--weights`: Path to the model weights file. Default is `'yolov8s.pt'`.
|
||||
- `--device`: Computation device (`'cpu'`, `'mps'` or `'cuda'`). Default is `'cpu'`.
|
||||
- `--classes`: List of class IDs to track. If empty, all classes are tracked.
|
||||
- `--confidence_threshold`: Confidence level for detections (`0` to `1`). Default is `0.3`.
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--source_video_path "data/checkout/video.mp4" \
|
||||
--weights "yolov8x.pt" \
|
||||
--device "cpu" \
|
||||
--classes 0 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--source_video_path "data/traffic/video.mp4" \
|
||||
--weights "yolov8x.pt" \
|
||||
--device "cpu" \
|
||||
--classes 2 5 6 7 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
### `ultralytics_stream_example`
|
||||
|
||||
Script to run object detection on a video stream using the Ultralytics YOLOv8 model.
|
||||
|
||||
- `--zone_configuration_path`: Path to the zone configuration JSON file.
|
||||
- `--rtsp_url`: Complete RTSP URL for the video stream.
|
||||
- `--weights`: Path to the model weights file. Default is `'yolov8s.pt'`.
|
||||
- `--device`: Computation device (`'cpu'`, `'mps'` or `'cuda'`). Default is `'cpu'`.
|
||||
- `--classes`: List of class IDs to track. If empty, all classes are tracked.
|
||||
- `--confidence_threshold`: Confidence level for detections (`0` to `1`). Default is `0.3`.
|
||||
- `--iou_threshold`: IOU threshold for non-max suppression. Default is `0.7`.
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/checkout/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--weights "yolov8x.pt" \
|
||||
--device "cpu" \
|
||||
--classes 0 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
```bash
|
||||
python inference_file_example.py \
|
||||
--zone_configuration_path "data/traffic/config.json" \
|
||||
--rtsp_url "rtsp://localhost:8554/live0.stream" \
|
||||
--weights "yolov8x.pt" \
|
||||
--device "cpu" \
|
||||
--classes 2 5 6 7 \
|
||||
--confidence_threshold 0.3 \
|
||||
--iou_threshold 0.7
|
||||
```
|
||||
|
||||
</details>
|
||||
|
||||
## © license
|
||||
|
||||
This demo integrates two main components, each with its own licensing:
|
||||
|
||||
- ultralytics: The object detection model used in this demo, YOLOv8, is distributed
|
||||
under the [AGPL-3.0 license](https://github.com/ultralytics/ultralytics/blob/main/LICENSE).
|
||||
You can find more details about this license here.
|
||||
|
||||
- supervision: The analytics code that powers the zone-based analysis in this demo is
|
||||
based on the Supervision library, which is licensed under the
|
||||
[MIT license](https://github.com/roboflow/supervision/blob/develop/LICENSE.md). This
|
||||
makes the Supervision part of the code fully open source and freely usable in your
|
||||
projects.
|
||||
@@ -0,0 +1,132 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from inference import get_model
|
||||
from utils.general import find_in_list, load_zones_config
|
||||
from utils.timers import FPSBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
def main(
|
||||
source_video_path: str,
|
||||
zone_configuration_path: str,
|
||||
model_id: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
model = get_model(model_id=model_id)
|
||||
tracker = sv.ByteTrack(minimum_matching_threshold=0.5)
|
||||
video_info = sv.VideoInfo.from_video_path(video_path=source_video_path)
|
||||
frames_generator = sv.get_video_frames_generator(source_video_path)
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
timers = [FPSBasedTimer(video_info.fps) for _ in zones]
|
||||
|
||||
for frame in frames_generator:
|
||||
results = model.infer(frame, confidence=confidence, iou_threshold=iou)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
detections = detections[find_in_list(detections.class_id, classes)]
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.copy()
|
||||
|
||||
for idx, zone in enumerate(zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
if cv2.waitKey(1) & 0xFF == ord("q"):
|
||||
break
|
||||
cv2.destroyAllWindows()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using video file."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--source_video_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the source video file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--model_id", type=str, default="yolov8s-640", help="Roboflow model ID."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
source_video_path=args.source_video_path,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
model_id=args.model_id,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,142 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from inference import get_model
|
||||
from utils.general import find_in_list, get_stream_frames_generator, load_zones_config
|
||||
from utils.timers import ClockBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
def main(
|
||||
rtsp_url: str,
|
||||
zone_configuration_path: str,
|
||||
model_id: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
model = get_model(model_id=model_id)
|
||||
tracker = sv.ByteTrack(minimum_matching_threshold=0.5)
|
||||
frames_generator = get_stream_frames_generator(rtsp_url=rtsp_url)
|
||||
fps_monitor = sv.FPSMonitor()
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
timers = [ClockBasedTimer() for _ in zones]
|
||||
|
||||
for frame in frames_generator:
|
||||
fps_monitor.tick()
|
||||
fps = fps_monitor.fps
|
||||
|
||||
results = model.infer(frame, confidence=confidence, iou_threshold=iou)[0]
|
||||
detections = sv.Detections.from_inference(results)
|
||||
detections = detections[find_in_list(detections.class_id, classes)]
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.copy()
|
||||
annotated_frame = sv.draw_text(
|
||||
scene=annotated_frame,
|
||||
text=f"{fps:.1f}",
|
||||
text_anchor=sv.Point(40, 30),
|
||||
background_color=sv.Color.from_hex("#A351FB"),
|
||||
text_color=sv.Color.from_hex("#000000"),
|
||||
)
|
||||
|
||||
for idx, zone in enumerate(zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
if cv2.waitKey(1) & 0xFF == ord("q"):
|
||||
break
|
||||
cv2.destroyAllWindows()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using RTSP stream."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--rtsp_url",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Complete RTSP URL for the video stream.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--model_id", type=str, default="yolov8s-640", help="Roboflow model ID."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
rtsp_url=args.rtsp_url,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
model_id=args.model_id,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,158 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from inference import InferencePipeline
|
||||
from inference.core.interfaces.camera.entities import VideoFrame
|
||||
from utils.general import find_in_list, load_zones_config
|
||||
from utils.timers import ClockBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
class CustomSink:
|
||||
def __init__(self, zone_configuration_path: str, classes: List[int]):
|
||||
self.classes = classes
|
||||
self.tracker = sv.ByteTrack(minimum_matching_threshold=0.5)
|
||||
self.fps_monitor = sv.FPSMonitor()
|
||||
self.polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
self.timers = [ClockBasedTimer() for _ in self.polygons]
|
||||
self.zones = None
|
||||
|
||||
def on_prediction(self, result: dict, frame: VideoFrame) -> None:
|
||||
if self.zones is None:
|
||||
resolution_wh = frame.image.shape[1], frame.image.shape[0]
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
self.fps_monitor.tick()
|
||||
fps = self.fps_monitor.fps
|
||||
|
||||
detections = sv.Detections.from_inference(result)
|
||||
detections = detections[find_in_list(detections.class_id, self.classes)]
|
||||
detections = self.tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.image.copy()
|
||||
annotated_frame = sv.draw_text(
|
||||
scene=annotated_frame,
|
||||
text=f"{fps:.1f}",
|
||||
text_anchor=sv.Point(40, 30),
|
||||
background_color=sv.Color.from_hex("#A351FB"),
|
||||
text_color=sv.Color.from_hex("#000000"),
|
||||
)
|
||||
|
||||
for idx, zone in enumerate(self.zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = self.timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
cv2.waitKey(1)
|
||||
|
||||
|
||||
def main(
|
||||
rtsp_url: str,
|
||||
zone_configuration_path: str,
|
||||
model_id: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
sink = CustomSink(zone_configuration_path=zone_configuration_path, classes=classes)
|
||||
|
||||
pipeline = InferencePipeline.init(
|
||||
model_id=model_id,
|
||||
video_reference=rtsp_url,
|
||||
on_prediction=sink.on_prediction,
|
||||
confidence=confidence,
|
||||
iou_threshold=iou,
|
||||
)
|
||||
|
||||
pipeline.start()
|
||||
|
||||
try:
|
||||
pipeline.join()
|
||||
except KeyboardInterrupt:
|
||||
pipeline.terminate()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using RTSP stream."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--rtsp_url",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Complete RTSP URL for the video stream.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--model_id", type=str, default="yolov8s-640", help="Roboflow model ID."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
rtsp_url=args.rtsp_url,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
model_id=args.model_id,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,5 @@
|
||||
opencv-python
|
||||
supervision
|
||||
ultralytics
|
||||
inference
|
||||
pytube
|
||||
@@ -0,0 +1,46 @@
|
||||
import argparse
|
||||
import os
|
||||
from typing import Optional
|
||||
|
||||
from pytube import YouTube
|
||||
|
||||
|
||||
def main(url: str, output_path: Optional[str], file_name: Optional[str]) -> None:
|
||||
yt = YouTube(url)
|
||||
stream = yt.streams.get_highest_resolution()
|
||||
|
||||
if not os.path.exists(output_path):
|
||||
os.makedirs(output_path)
|
||||
|
||||
stream.download(output_path=output_path, filename=file_name)
|
||||
final_name = file_name if file_name else yt.title
|
||||
final_path = output_path if output_path else "current directory"
|
||||
print(f"Download completed! Video saved as '{final_name}' in '{final_path}'.")
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Download a specific YouTube video by providing its URL."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--url",
|
||||
type=str,
|
||||
required=True,
|
||||
help="The full URL of the YouTube video you wish to download.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--output_path",
|
||||
type=str,
|
||||
default="data/source",
|
||||
required=False,
|
||||
help="Optional. Specifies the directory where the video will be saved.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--file_name",
|
||||
type=str,
|
||||
default="video.mp4",
|
||||
required=False,
|
||||
help="Optional. Sets the name of the saved video file.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
main(url=args.url, output_path=args.output_path, file_name=args.file_name)
|
||||
@@ -0,0 +1,176 @@
|
||||
import argparse
|
||||
import json
|
||||
import os
|
||||
from typing import Any, Optional, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
import supervision as sv
|
||||
|
||||
KEY_ENTER = 13
|
||||
KEY_NEWLINE = 10
|
||||
KEY_ESCAPE = 27
|
||||
KEY_QUIT = ord("q")
|
||||
KEY_SAVE = ord("s")
|
||||
|
||||
THICKNESS = 2
|
||||
COLORS = sv.ColorPalette.DEFAULT
|
||||
WINDOW_NAME = "Draw Zones"
|
||||
POLYGONS = [[]]
|
||||
|
||||
current_mouse_position: Optional[Tuple[int, int]] = None
|
||||
|
||||
|
||||
def resolve_source(source_path: str) -> Optional[np.ndarray]:
|
||||
if not os.path.exists(source_path):
|
||||
return None
|
||||
|
||||
image = cv2.imread(source_path)
|
||||
if image is not None:
|
||||
return image
|
||||
|
||||
frame_generator = sv.get_video_frames_generator(source_path=source_path)
|
||||
frame = next(frame_generator)
|
||||
return frame
|
||||
|
||||
|
||||
def mouse_event(event: int, x: int, y: int, flags: int, param: Any) -> None:
|
||||
global current_mouse_position
|
||||
if event == cv2.EVENT_MOUSEMOVE:
|
||||
current_mouse_position = (x, y)
|
||||
elif event == cv2.EVENT_LBUTTONDOWN:
|
||||
POLYGONS[-1].append((x, y))
|
||||
|
||||
|
||||
def redraw(image: np.ndarray, original_image: np.ndarray) -> None:
|
||||
global POLYGONS, current_mouse_position
|
||||
image[:] = original_image.copy()
|
||||
for idx, polygon in enumerate(POLYGONS):
|
||||
color = (
|
||||
COLORS.by_idx(idx).as_bgr()
|
||||
if idx < len(POLYGONS) - 1
|
||||
else sv.Color.WHITE.as_bgr()
|
||||
)
|
||||
|
||||
if len(polygon) > 1:
|
||||
for i in range(1, len(polygon)):
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=polygon[i - 1],
|
||||
pt2=polygon[i],
|
||||
color=color,
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
if idx < len(POLYGONS) - 1:
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=polygon[-1],
|
||||
pt2=polygon[0],
|
||||
color=color,
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
if idx == len(POLYGONS) - 1 and current_mouse_position is not None and polygon:
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=polygon[-1],
|
||||
pt2=current_mouse_position,
|
||||
color=color,
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
cv2.imshow(WINDOW_NAME, image)
|
||||
|
||||
|
||||
def close_and_finalize_polygon(image: np.ndarray, original_image: np.ndarray) -> None:
|
||||
if len(POLYGONS[-1]) > 2:
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=POLYGONS[-1][-1],
|
||||
pt2=POLYGONS[-1][0],
|
||||
color=COLORS.by_idx(0).as_bgr(),
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
POLYGONS.append([])
|
||||
image[:] = original_image.copy()
|
||||
redraw_polygons(image)
|
||||
cv2.imshow(WINDOW_NAME, image)
|
||||
|
||||
|
||||
def redraw_polygons(image: np.ndarray) -> None:
|
||||
for idx, polygon in enumerate(POLYGONS[:-1]):
|
||||
if len(polygon) > 1:
|
||||
color = COLORS.by_idx(idx).as_bgr()
|
||||
for i in range(len(polygon) - 1):
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=polygon[i],
|
||||
pt2=polygon[i + 1],
|
||||
color=color,
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
cv2.line(
|
||||
img=image,
|
||||
pt1=polygon[-1],
|
||||
pt2=polygon[0],
|
||||
color=color,
|
||||
thickness=THICKNESS,
|
||||
)
|
||||
|
||||
|
||||
def save_polygons_to_json(polygons, target_path):
|
||||
data_to_save = polygons if polygons[-1] else polygons[:-1]
|
||||
with open(target_path, "w") as f:
|
||||
json.dump(data_to_save, f)
|
||||
|
||||
|
||||
def main(source_path: str, zone_configuration_path: str) -> None:
|
||||
global current_mouse_position
|
||||
original_image = resolve_source(source_path=source_path)
|
||||
if original_image is None:
|
||||
print("Failed to load source image.")
|
||||
return
|
||||
|
||||
image = original_image.copy()
|
||||
cv2.imshow(WINDOW_NAME, image)
|
||||
cv2.setMouseCallback(WINDOW_NAME, mouse_event, image)
|
||||
|
||||
while True:
|
||||
key = cv2.waitKey(1) & 0xFF
|
||||
if key == KEY_ENTER or key == KEY_NEWLINE:
|
||||
close_and_finalize_polygon(image, original_image)
|
||||
elif key == KEY_ESCAPE:
|
||||
POLYGONS[-1] = []
|
||||
current_mouse_position = None
|
||||
elif key == KEY_SAVE:
|
||||
save_polygons_to_json(POLYGONS, zone_configuration_path)
|
||||
print(f"Polygons saved to {zone_configuration_path}")
|
||||
break
|
||||
redraw(image, original_image)
|
||||
if key == KEY_QUIT:
|
||||
break
|
||||
|
||||
cv2.destroyAllWindows()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Interactively draw polygons on images or video frames and save "
|
||||
"the annotations."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--source_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the source image or video file for drawing polygons.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path where the polygon annotations will be saved as a JSON file.",
|
||||
)
|
||||
arguments = parser.parse_args()
|
||||
main(
|
||||
source_path=arguments.source_path,
|
||||
zone_configuration_path=arguments.zone_configuration_path,
|
||||
)
|
||||
@@ -0,0 +1,104 @@
|
||||
import argparse
|
||||
import os
|
||||
import subprocess
|
||||
import tempfile
|
||||
from glob import glob
|
||||
from threading import Thread
|
||||
|
||||
import yaml
|
||||
|
||||
SERVER_CONFIG = {"protocols": ["tcp"], "paths": {"all": {"source": "publisher"}}}
|
||||
BASE_STREAM_URL = "rtsp://localhost:8554/live"
|
||||
|
||||
|
||||
def main(video_directory: str, number_of_streams: int) -> None:
|
||||
video_files = find_video_files_in_directory(video_directory, number_of_streams)
|
||||
try:
|
||||
with tempfile.TemporaryDirectory() as temporary_directory:
|
||||
config_file_path = create_server_config_file(temporary_directory)
|
||||
run_rtsp_server(config_path=config_file_path)
|
||||
stream_videos(video_files)
|
||||
finally:
|
||||
stop_rtsp_server()
|
||||
|
||||
|
||||
def find_video_files_in_directory(directory: str, limit: int) -> list:
|
||||
video_formats = ["*.mp4", "*.webm"]
|
||||
video_paths = []
|
||||
for video_format in video_formats:
|
||||
video_paths.extend(glob(os.path.join(directory, video_format)))
|
||||
return video_paths[:limit]
|
||||
|
||||
|
||||
def create_server_config_file(directory: str) -> str:
|
||||
config_path = os.path.join(directory, "rtsp-simple-server.yml")
|
||||
with open(config_path, "w") as config_file:
|
||||
yaml.dump(SERVER_CONFIG, config_file)
|
||||
return config_path
|
||||
|
||||
|
||||
def run_rtsp_server(config_path: str) -> None:
|
||||
command = (
|
||||
"docker run --rm --name rtsp_server -d -v "
|
||||
f"{config_path}:/rtsp-simple-server.yml -p 8554:8554 "
|
||||
"aler9/rtsp-simple-server:v1.3.0"
|
||||
)
|
||||
if run_command(command.split()) != 0:
|
||||
raise RuntimeError("Could not start the RTSP server!")
|
||||
|
||||
|
||||
def stop_rtsp_server() -> None:
|
||||
run_command("docker kill rtsp_server".split())
|
||||
|
||||
|
||||
def stream_videos(video_files: list) -> None:
|
||||
threads = []
|
||||
for index, video_file in enumerate(video_files):
|
||||
stream_url = f"{BASE_STREAM_URL}{index}.stream"
|
||||
print(f"Streaming {video_file} under {stream_url}")
|
||||
thread = stream_video_to_url(video_file, stream_url)
|
||||
threads.append(thread)
|
||||
for thread in threads:
|
||||
thread.join()
|
||||
|
||||
|
||||
def stream_video_to_url(video_path: str, stream_url: str) -> Thread:
|
||||
command = (
|
||||
f"ffmpeg -re -stream_loop -1 -i {video_path} "
|
||||
f"-f rtsp -rtsp_transport tcp {stream_url}"
|
||||
)
|
||||
return run_command_in_thread(command.split())
|
||||
|
||||
|
||||
def run_command_in_thread(command: list) -> Thread:
|
||||
thread = Thread(target=run_command, args=(command,))
|
||||
thread.start()
|
||||
return thread
|
||||
|
||||
|
||||
def run_command(command: list) -> int:
|
||||
process = subprocess.run(command)
|
||||
return process.returncode
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Script to stream videos using RTSP protocol."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--video_directory",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Directory containing video files to stream.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--number_of_streams",
|
||||
type=int,
|
||||
default=6,
|
||||
help="Number of video files to stream.",
|
||||
)
|
||||
arguments = parser.parse_args()
|
||||
main(
|
||||
video_directory=arguments.video_directory,
|
||||
number_of_streams=arguments.number_of_streams,
|
||||
)
|
||||
@@ -0,0 +1,144 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from ultralytics import YOLO
|
||||
from utils.general import find_in_list, load_zones_config
|
||||
from utils.timers import FPSBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
def main(
|
||||
source_video_path: str,
|
||||
zone_configuration_path: str,
|
||||
weights: str,
|
||||
device: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
model = YOLO(weights)
|
||||
tracker = sv.ByteTrack(minimum_matching_threshold=0.5)
|
||||
video_info = sv.VideoInfo.from_video_path(video_path=source_video_path)
|
||||
frames_generator = sv.get_video_frames_generator(source_video_path)
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
timers = [FPSBasedTimer(video_info.fps) for _ in zones]
|
||||
|
||||
for frame in frames_generator:
|
||||
results = model(frame, verbose=False, device=device, conf=confidence)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
detections = detections[find_in_list(detections.class_id, classes)]
|
||||
detections = detections.with_nms(threshold=iou)
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.copy()
|
||||
|
||||
for idx, zone in enumerate(zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
if cv2.waitKey(1) & 0xFF == ord("q"):
|
||||
break
|
||||
cv2.destroyAllWindows()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using video file."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--source_video_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the source video file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--weights",
|
||||
type=str,
|
||||
default="yolov8s.pt",
|
||||
help="Path to the model weights file. Default is 'yolov8s.pt'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--device",
|
||||
type=str,
|
||||
default="cpu",
|
||||
help="Computation device ('cpu', 'mps' or 'cuda'). Default is 'cpu'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
source_video_path=args.source_video_path,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
weights=args.weights,
|
||||
device=args.device,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,154 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from ultralytics import YOLO
|
||||
from utils.general import find_in_list, get_stream_frames_generator, load_zones_config
|
||||
from utils.timers import ClockBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
def main(
|
||||
rtsp_url: str,
|
||||
zone_configuration_path: str,
|
||||
weights: str,
|
||||
device: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
model = YOLO(weights)
|
||||
tracker = sv.ByteTrack(minimum_matching_threshold=0.5)
|
||||
frames_generator = get_stream_frames_generator(rtsp_url=rtsp_url)
|
||||
fps_monitor = sv.FPSMonitor()
|
||||
|
||||
frame = next(frames_generator)
|
||||
resolution_wh = frame.shape[1], frame.shape[0]
|
||||
|
||||
polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
timers = [ClockBasedTimer() for _ in zones]
|
||||
|
||||
for frame in frames_generator:
|
||||
fps_monitor.tick()
|
||||
fps = fps_monitor.fps
|
||||
|
||||
results = model(frame, verbose=False, device=device, conf=confidence)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
detections = detections[find_in_list(detections.class_id, classes)]
|
||||
detections = detections.with_nms(threshold=iou)
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.copy()
|
||||
annotated_frame = sv.draw_text(
|
||||
scene=annotated_frame,
|
||||
text=f"{fps:.1f}",
|
||||
text_anchor=sv.Point(40, 30),
|
||||
background_color=sv.Color.from_hex("#A351FB"),
|
||||
text_color=sv.Color.from_hex("#000000"),
|
||||
)
|
||||
|
||||
for idx, zone in enumerate(zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
if cv2.waitKey(1) & 0xFF == ord("q"):
|
||||
break
|
||||
cv2.destroyAllWindows()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using RTSP stream."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--rtsp_url",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Complete RTSP URL for the video stream.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--weights",
|
||||
type=str,
|
||||
default="yolov8s.pt",
|
||||
help="Path to the model weights file. Default is 'yolov8s.pt'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--device",
|
||||
type=str,
|
||||
default="cpu",
|
||||
help="Computation device ('cpu', 'mps' or 'cuda'). Default is 'cpu'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
rtsp_url=args.rtsp_url,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
weights=args.weights,
|
||||
device=args.device,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,173 @@
|
||||
import argparse
|
||||
from typing import List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
from inference import InferencePipeline
|
||||
from inference.core.interfaces.camera.entities import VideoFrame
|
||||
from ultralytics import YOLO
|
||||
from utils.general import find_in_list, load_zones_config
|
||||
from utils.timers import ClockBasedTimer
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
COLOR_ANNOTATOR = sv.ColorAnnotator(color=COLORS)
|
||||
LABEL_ANNOTATOR = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.from_hex("#000000")
|
||||
)
|
||||
|
||||
|
||||
class CustomSink:
|
||||
def __init__(self, zone_configuration_path: str, classes: List[int]):
|
||||
self.classes = classes
|
||||
self.tracker = sv.ByteTrack(minimum_matching_threshold=0.8)
|
||||
self.fps_monitor = sv.FPSMonitor()
|
||||
self.polygons = load_zones_config(file_path=zone_configuration_path)
|
||||
self.timers = [ClockBasedTimer() for _ in self.polygons]
|
||||
self.zones = None
|
||||
|
||||
def on_prediction(self, detections: sv.Detections, frame: VideoFrame) -> None:
|
||||
if self.zones is None:
|
||||
resolution_wh = frame.image.shape[1], frame.image.shape[0]
|
||||
self.zones = [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=resolution_wh,
|
||||
triggering_anchors=(sv.Position.CENTER,),
|
||||
)
|
||||
for polygon in self.polygons
|
||||
]
|
||||
|
||||
self.fps_monitor.tick()
|
||||
fps = self.fps_monitor.fps
|
||||
|
||||
detections = detections[find_in_list(detections.class_id, self.classes)]
|
||||
detections = self.tracker.update_with_detections(detections)
|
||||
|
||||
annotated_frame = frame.image.copy()
|
||||
annotated_frame = sv.draw_text(
|
||||
scene=annotated_frame,
|
||||
text=f"{fps:.1f}",
|
||||
text_anchor=sv.Point(40, 30),
|
||||
background_color=sv.Color.from_hex("#A351FB"),
|
||||
text_color=sv.Color.from_hex("#000000"),
|
||||
)
|
||||
|
||||
for idx, zone in enumerate(self.zones):
|
||||
annotated_frame = sv.draw_polygon(
|
||||
scene=annotated_frame, polygon=zone.polygon, color=COLORS.by_idx(idx)
|
||||
)
|
||||
|
||||
detections_in_zone = detections[zone.trigger(detections)]
|
||||
time_in_zone = self.timers[idx].tick(detections_in_zone)
|
||||
custom_color_lookup = np.full(detections_in_zone.class_id.shape, idx)
|
||||
|
||||
annotated_frame = COLOR_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
labels = [
|
||||
f"#{tracker_id} {int(time // 60):02d}:{int(time % 60):02d}"
|
||||
for tracker_id, time in zip(detections_in_zone.tracker_id, time_in_zone)
|
||||
]
|
||||
annotated_frame = LABEL_ANNOTATOR.annotate(
|
||||
scene=annotated_frame,
|
||||
detections=detections_in_zone,
|
||||
labels=labels,
|
||||
custom_color_lookup=custom_color_lookup,
|
||||
)
|
||||
cv2.imshow("Processed Video", annotated_frame)
|
||||
cv2.waitKey(1)
|
||||
|
||||
|
||||
def main(
|
||||
rtsp_url: str,
|
||||
zone_configuration_path: str,
|
||||
weights: str,
|
||||
device: str,
|
||||
confidence: float,
|
||||
iou: float,
|
||||
classes: List[int],
|
||||
) -> None:
|
||||
model = YOLO(weights)
|
||||
|
||||
def inference_callback(frame: VideoFrame) -> sv.Detections:
|
||||
results = model(frame.image, verbose=False, conf=confidence, device=device)[0]
|
||||
return sv.Detections.from_ultralytics(results).with_nms(threshold=iou)
|
||||
|
||||
sink = CustomSink(zone_configuration_path=zone_configuration_path, classes=classes)
|
||||
|
||||
pipeline = InferencePipeline.init_with_custom_logic(
|
||||
video_reference=rtsp_url,
|
||||
on_video_frame=inference_callback,
|
||||
on_prediction=sink.on_prediction,
|
||||
)
|
||||
|
||||
pipeline.start()
|
||||
|
||||
try:
|
||||
pipeline.join()
|
||||
except KeyboardInterrupt:
|
||||
pipeline.terminate()
|
||||
|
||||
|
||||
if __name__ == "__main__":
|
||||
parser = argparse.ArgumentParser(
|
||||
description="Calculating detections dwell time in zones, using RTSP stream."
|
||||
)
|
||||
parser.add_argument(
|
||||
"--zone_configuration_path",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Path to the zone configuration JSON file.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--rtsp_url",
|
||||
type=str,
|
||||
required=True,
|
||||
help="Complete RTSP URL for the video stream.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--weights",
|
||||
type=str,
|
||||
default="yolov8s.pt",
|
||||
help="Path to the model weights file. Default is 'yolov8s.pt'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--device",
|
||||
type=str,
|
||||
default="cpu",
|
||||
help="Computation device ('cpu', 'mps' or 'cuda'). Default is 'cpu'.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--confidence_threshold",
|
||||
type=float,
|
||||
default=0.3,
|
||||
help="Confidence level for detections (0 to 1). Default is 0.3.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--iou_threshold",
|
||||
default=0.7,
|
||||
type=float,
|
||||
help="IOU threshold for non-max suppression. Default is 0.7.",
|
||||
)
|
||||
parser.add_argument(
|
||||
"--classes",
|
||||
nargs="*",
|
||||
type=int,
|
||||
default=[],
|
||||
help="List of class IDs to track. If empty, all classes are tracked.",
|
||||
)
|
||||
args = parser.parse_args()
|
||||
|
||||
main(
|
||||
rtsp_url=args.rtsp_url,
|
||||
zone_configuration_path=args.zone_configuration_path,
|
||||
weights=args.weights,
|
||||
device=args.device,
|
||||
confidence=args.confidence_threshold,
|
||||
iou=args.iou_threshold,
|
||||
classes=args.classes,
|
||||
)
|
||||
@@ -0,0 +1,66 @@
|
||||
import json
|
||||
from typing import Generator, List
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
|
||||
def load_zones_config(file_path: str) -> List[np.ndarray]:
|
||||
"""
|
||||
Load polygon zone configurations from a JSON file.
|
||||
|
||||
This function reads a JSON file which contains polygon coordinates, and
|
||||
converts them into a list of NumPy arrays. Each polygon is represented as
|
||||
a NumPy array of coordinates.
|
||||
|
||||
Args:
|
||||
file_path (str): The path to the JSON configuration file.
|
||||
|
||||
Returns:
|
||||
List[np.ndarray]: A list of polygons, each represented as a NumPy array.
|
||||
"""
|
||||
with open(file_path, "r") as file:
|
||||
data = json.load(file)
|
||||
return [np.array(polygon, np.int32) for polygon in data]
|
||||
|
||||
|
||||
def find_in_list(array: np.ndarray, search_list: List[int]) -> np.ndarray:
|
||||
"""Determines if elements of a numpy array are present in a list.
|
||||
|
||||
Args:
|
||||
array (np.ndarray): The numpy array of integers to check.
|
||||
search_list (List[int]): The list of integers to search within.
|
||||
|
||||
Returns:
|
||||
np.ndarray: A numpy array of booleans, where each boolean indicates whether
|
||||
the corresponding element in `array` is found in `search_list`.
|
||||
"""
|
||||
if not search_list:
|
||||
return np.ones(array.shape, dtype=bool)
|
||||
else:
|
||||
return np.isin(array, search_list)
|
||||
|
||||
|
||||
def get_stream_frames_generator(rtsp_url: str) -> Generator[np.ndarray, None, None]:
|
||||
"""
|
||||
Generator function to yield frames from an RTSP stream.
|
||||
|
||||
Args:
|
||||
rtsp_url (str): URL of the RTSP video stream.
|
||||
|
||||
Yields:
|
||||
np.ndarray: The next frame from the video stream.
|
||||
"""
|
||||
cap = cv2.VideoCapture(rtsp_url)
|
||||
if not cap.isOpened():
|
||||
raise Exception("Error: Could not open video stream.")
|
||||
|
||||
try:
|
||||
while True:
|
||||
ret, frame = cap.read()
|
||||
if not ret:
|
||||
print("End of stream or error reading frame.")
|
||||
break
|
||||
yield frame
|
||||
finally:
|
||||
cap.release()
|
||||
@@ -0,0 +1,88 @@
|
||||
from datetime import datetime
|
||||
from typing import Dict
|
||||
|
||||
import numpy as np
|
||||
|
||||
import supervision as sv
|
||||
|
||||
|
||||
class FPSBasedTimer:
|
||||
"""
|
||||
A timer that calculates the duration each object has been detected based on frames
|
||||
per second (FPS).
|
||||
|
||||
Attributes:
|
||||
fps (int): The frame rate of the video stream, used to calculate time durations.
|
||||
frame_id (int): The current frame number in the sequence.
|
||||
tracker_id2frame_id (Dict[int, int]): Maps each tracker's ID to the frame number
|
||||
at which it was first detected.
|
||||
"""
|
||||
|
||||
def __init__(self, fps: int = 30) -> None:
|
||||
"""Initializes the FPSBasedTimer with the specified frames per second rate.
|
||||
|
||||
Args:
|
||||
fps (int, optional): The frame rate of the video stream. Defaults to 30.
|
||||
"""
|
||||
self.fps = fps
|
||||
self.frame_id = 0
|
||||
self.tracker_id2frame_id: Dict[int, int] = {}
|
||||
|
||||
def tick(self, detections: sv.Detections) -> np.ndarray:
|
||||
"""Processes the current frame, updating time durations for each tracker.
|
||||
|
||||
Args:
|
||||
detections: The detections for the current frame, including tracker IDs.
|
||||
|
||||
Returns:
|
||||
np.ndarray: Time durations (in seconds) for each detected tracker, since
|
||||
their first detection.
|
||||
"""
|
||||
self.frame_id += 1
|
||||
times = []
|
||||
|
||||
for tracker_id in detections.tracker_id:
|
||||
self.tracker_id2frame_id.setdefault(tracker_id, self.frame_id)
|
||||
|
||||
start_frame_id = self.tracker_id2frame_id[tracker_id]
|
||||
time_duration = (self.frame_id - start_frame_id) / self.fps
|
||||
times.append(time_duration)
|
||||
|
||||
return np.array(times)
|
||||
|
||||
|
||||
class ClockBasedTimer:
|
||||
"""
|
||||
A timer that calculates the duration each object has been detected based on the
|
||||
system clock.
|
||||
|
||||
Attributes:
|
||||
tracker_id2start_time (Dict[int, datetime]): Maps each tracker's ID to the
|
||||
datetime when it was first detected.
|
||||
"""
|
||||
|
||||
def __init__(self) -> None:
|
||||
"""Initializes the ClockBasedTimer."""
|
||||
self.tracker_id2start_time: Dict[int, datetime] = {}
|
||||
|
||||
def tick(self, detections: sv.Detections) -> np.ndarray:
|
||||
"""Processes the current frame, updating time durations for each tracker.
|
||||
|
||||
Args:
|
||||
detections: The detections for the current frame, including tracker IDs.
|
||||
|
||||
Returns:
|
||||
np.ndarray: Time durations (in seconds) for each detected tracker, since
|
||||
their first detection.
|
||||
"""
|
||||
current_time = datetime.now()
|
||||
times = []
|
||||
|
||||
for tracker_id in detections.tracker_id:
|
||||
self.tracker_id2start_time.setdefault(tracker_id, current_time)
|
||||
|
||||
start_time = self.tracker_id2start_time[tracker_id]
|
||||
time_duration = (current_time - start_time).total_seconds()
|
||||
times.append(time_duration)
|
||||
|
||||
return np.array(times)
|
||||
@@ -1,4 +1,4 @@
|
||||
inference
|
||||
supervision
|
||||
supervision==0.19.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
import argparse
|
||||
import os
|
||||
from typing import Dict, List, Set, Tuple
|
||||
from typing import Dict, Iterable, List, Set, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
@@ -9,7 +9,8 @@ from tqdm import tqdm
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.default()
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
|
||||
|
||||
ZONE_IN_POLYGONS = [
|
||||
np.array([[592, 282], [900, 282], [900, 82], [592, 82]]),
|
||||
@@ -60,13 +61,13 @@ class DetectionsManager:
|
||||
def initiate_polygon_zones(
|
||||
polygons: List[np.ndarray],
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
triggering_position: sv.Position = sv.Position.CENTER,
|
||||
triggering_anchors: Iterable[sv.Position] = [sv.Position.CENTER],
|
||||
) -> List[sv.PolygonZone]:
|
||||
return [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=frame_resolution_wh,
|
||||
triggering_position=triggering_position,
|
||||
triggering_anchors=triggering_anchors,
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
@@ -92,13 +93,16 @@ class VideoProcessor:
|
||||
|
||||
self.video_info = sv.VideoInfo.from_video_path(source_video_path)
|
||||
self.zones_in = initiate_polygon_zones(
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, sv.Position.CENTER
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_out = initiate_polygon_zones(
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, sv.Position.CENTER
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
|
||||
self.box_annotator = sv.BoxAnnotator(color=COLORS)
|
||||
self.bounding_box_annotator = sv.BoundingBoxAnnotator(color=COLORS)
|
||||
self.label_annotator = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.BLACK
|
||||
)
|
||||
self.trace_annotator = sv.TraceAnnotator(
|
||||
color=COLORS, position=sv.Position.CENTER, trace_length=100, thickness=2
|
||||
)
|
||||
@@ -136,7 +140,10 @@ class VideoProcessor:
|
||||
|
||||
labels = [f"#{tracker_id}" for tracker_id in detections.tracker_id]
|
||||
annotated_frame = self.trace_annotator.annotate(annotated_frame, detections)
|
||||
annotated_frame = self.box_annotator.annotate(
|
||||
annotated_frame = self.bounding_box_annotator.annotate(
|
||||
annotated_frame, detections
|
||||
)
|
||||
annotated_frame = self.label_annotator.annotate(
|
||||
annotated_frame, detections, labels
|
||||
)
|
||||
|
||||
@@ -167,7 +174,7 @@ class VideoProcessor:
|
||||
detections_in_zones = []
|
||||
detections_out_zones = []
|
||||
|
||||
for i, (zone_in, zone_out) in enumerate(zip(self.zones_in, self.zones_out)):
|
||||
for zone_in, zone_out in zip(self.zones_in, self.zones_out):
|
||||
detections_in_zone = detections[zone_in.trigger(detections=detections)]
|
||||
detections_in_zones.append(detections_in_zone)
|
||||
detections_out_zone = detections[zone_out.trigger(detections=detections)]
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
gdown
|
||||
inference
|
||||
supervision
|
||||
supervision>=0.19.0
|
||||
tqdm
|
||||
ultralytics
|
||||
|
||||
@@ -1,5 +1,5 @@
|
||||
import argparse
|
||||
from typing import Dict, List, Set, Tuple
|
||||
from typing import Dict, Iterable, List, Set, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
@@ -8,7 +8,7 @@ from ultralytics import YOLO
|
||||
|
||||
import supervision as sv
|
||||
|
||||
COLORS = sv.ColorPalette.default()
|
||||
COLORS = sv.ColorPalette.from_hex(["#E6194B", "#3CB44B", "#FFE119", "#3C76D1"])
|
||||
|
||||
ZONE_IN_POLYGONS = [
|
||||
np.array([[592, 282], [900, 282], [900, 82], [592, 82]]),
|
||||
@@ -59,13 +59,13 @@ class DetectionsManager:
|
||||
def initiate_polygon_zones(
|
||||
polygons: List[np.ndarray],
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
triggering_position: sv.Position = sv.Position.CENTER,
|
||||
triggering_anchors: Iterable[sv.Position] = [sv.Position.CENTER],
|
||||
) -> List[sv.PolygonZone]:
|
||||
return [
|
||||
sv.PolygonZone(
|
||||
polygon=polygon,
|
||||
frame_resolution_wh=frame_resolution_wh,
|
||||
triggering_position=triggering_position,
|
||||
triggering_anchors=triggering_anchors,
|
||||
)
|
||||
for polygon in polygons
|
||||
]
|
||||
@@ -90,13 +90,16 @@ class VideoProcessor:
|
||||
|
||||
self.video_info = sv.VideoInfo.from_video_path(source_video_path)
|
||||
self.zones_in = initiate_polygon_zones(
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, sv.Position.CENTER
|
||||
ZONE_IN_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
self.zones_out = initiate_polygon_zones(
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, sv.Position.CENTER
|
||||
ZONE_OUT_POLYGONS, self.video_info.resolution_wh, [sv.Position.CENTER]
|
||||
)
|
||||
|
||||
self.box_annotator = sv.BoxAnnotator(color=COLORS)
|
||||
self.bounding_box_annotator = sv.BoundingBoxAnnotator(color=COLORS)
|
||||
self.label_annotator = sv.LabelAnnotator(
|
||||
color=COLORS, text_color=sv.Color.BLACK
|
||||
)
|
||||
self.trace_annotator = sv.TraceAnnotator(
|
||||
color=COLORS, position=sv.Position.CENTER, trace_length=100, thickness=2
|
||||
)
|
||||
@@ -134,7 +137,10 @@ class VideoProcessor:
|
||||
|
||||
labels = [f"#{tracker_id}" for tracker_id in detections.tracker_id]
|
||||
annotated_frame = self.trace_annotator.annotate(annotated_frame, detections)
|
||||
annotated_frame = self.box_annotator.annotate(
|
||||
annotated_frame = self.bounding_box_annotator.annotate(
|
||||
annotated_frame, detections
|
||||
)
|
||||
annotated_frame = self.label_annotator.annotate(
|
||||
annotated_frame, detections, labels
|
||||
)
|
||||
|
||||
@@ -165,7 +171,7 @@ class VideoProcessor:
|
||||
detections_in_zones = []
|
||||
detections_out_zones = []
|
||||
|
||||
for i, (zone_in, zone_out) in enumerate(zip(self.zones_in, self.zones_out)):
|
||||
for zone_in, zone_out in zip(self.zones_in, self.zones_out):
|
||||
detections_in_zone = detections[zone_in.trigger(detections=detections)]
|
||||
detections_in_zones.append(detections_in_zone)
|
||||
detections_out_zone = detections[zone_out.trigger(detections=detections)]
|
||||
|
||||
@@ -38,6 +38,7 @@ nav:
|
||||
- Home: index.md
|
||||
- How to:
|
||||
- Detect and Annotate: how_to/detect_and_annotate.md
|
||||
- Detect Small Objects: how_to/detect_small_objects.md
|
||||
- Track Objects: how_to/track_objects.md
|
||||
- Filter Detections: how_to/filter_detections.md
|
||||
- API:
|
||||
|
||||
Generated
+97
-119
@@ -1,4 +1,4 @@
|
||||
# This file is automatically @generated by Poetry 1.8.1 and should not be changed by hand.
|
||||
# This file is automatically @generated by Poetry 1.8.2 and should not be changed by hand.
|
||||
|
||||
[[package]]
|
||||
name = "anyio"
|
||||
@@ -244,26 +244,27 @@ css = ["tinycss2 (>=1.1.0,<1.3)"]
|
||||
|
||||
[[package]]
|
||||
name = "build"
|
||||
version = "1.0.3"
|
||||
version = "1.2.0"
|
||||
description = "A simple, correct Python build frontend"
|
||||
optional = false
|
||||
python-versions = ">= 3.7"
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "build-1.0.3-py3-none-any.whl", hash = "sha256:589bf99a67df7c9cf07ec0ac0e5e2ea5d4b37ac63301c4986d1acb126aa83f8f"},
|
||||
{file = "build-1.0.3.tar.gz", hash = "sha256:538aab1b64f9828977f84bc63ae570b060a8ed1be419e7870b8b4fc5e6ea553b"},
|
||||
{file = "build-1.2.0-py3-none-any.whl", hash = "sha256:6105465d9b233433ce8ffa151c760f674446ba766af0290fc14bfa32aef92a04"},
|
||||
{file = "build-1.2.0.tar.gz", hash = "sha256:49df7f8e1e74d345fe71e54f5d56423b2111eda89e3da53a2c18392954dade1d"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
colorama = {version = "*", markers = "os_name == \"nt\""}
|
||||
importlib-metadata = {version = ">=4.6", markers = "python_version < \"3.10\""}
|
||||
packaging = ">=19.0"
|
||||
importlib-metadata = {version = ">=4.6", markers = "python_full_version < \"3.10.2\""}
|
||||
packaging = ">=19.1"
|
||||
pyproject_hooks = "*"
|
||||
tomli = {version = ">=1.1.0", markers = "python_version < \"3.11\""}
|
||||
|
||||
[package.extras]
|
||||
docs = ["furo (>=2023.08.17)", "sphinx (>=7.0,<8.0)", "sphinx-argparse-cli (>=1.5)", "sphinx-autodoc-typehints (>=1.10)", "sphinx-issues (>=3.0.0)"]
|
||||
test = ["filelock (>=3)", "pytest (>=6.2.4)", "pytest-cov (>=2.12)", "pytest-mock (>=2)", "pytest-rerunfailures (>=9.1)", "pytest-xdist (>=1.34)", "setuptools (>=42.0.0)", "setuptools (>=56.0.0)", "setuptools (>=56.0.0)", "setuptools (>=67.8.0)", "wheel (>=0.36.0)"]
|
||||
typing = ["importlib-metadata (>=5.1)", "mypy (>=1.5.0,<1.6.0)", "tomli", "typing-extensions (>=3.7.4.3)"]
|
||||
test = ["build[uv,virtualenv]", "filelock (>=3)", "pytest (>=6.2.4)", "pytest-cov (>=2.12)", "pytest-mock (>=2)", "pytest-rerunfailures (>=9.1)", "pytest-xdist (>=1.34)", "setuptools (>=42.0.0)", "setuptools (>=56.0.0)", "setuptools (>=56.0.0)", "setuptools (>=67.8.0)", "wheel (>=0.36.0)"]
|
||||
typing = ["build[uv]", "importlib-metadata (>=5.1)", "mypy (>=1.9.0,<1.10.0)", "tomli", "typing-extensions (>=3.7.4.3)"]
|
||||
uv = ["uv (>=0.1.18)"]
|
||||
virtualenv = ["virtualenv (>=20.0.35)"]
|
||||
|
||||
[[package]]
|
||||
@@ -570,6 +571,7 @@ files = [
|
||||
{file = "contourpy-1.1.0-cp310-cp310-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:18a64814ae7bce73925131381603fff0116e2df25230dfc80d6d690aa6e20b37"},
|
||||
{file = "contourpy-1.1.0-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:90c81f22b4f572f8a2110b0b741bb64e5a6427e0a198b2cdc1fbaf85f352a3aa"},
|
||||
{file = "contourpy-1.1.0-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:53cc3a40635abedbec7f1bde60f8c189c49e84ac180c665f2cd7c162cc454baa"},
|
||||
{file = "contourpy-1.1.0-cp310-cp310-win32.whl", hash = "sha256:9b2dd2ca3ac561aceef4c7c13ba654aaa404cf885b187427760d7f7d4c57cff8"},
|
||||
{file = "contourpy-1.1.0-cp310-cp310-win_amd64.whl", hash = "sha256:1f795597073b09d631782e7245016a4323cf1cf0b4e06eef7ea6627e06a37ff2"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:0b7b04ed0961647691cfe5d82115dd072af7ce8846d31a5fac6c142dcce8b882"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-macosx_11_0_arm64.whl", hash = "sha256:27bc79200c742f9746d7dd51a734ee326a292d77e7d94c8af6e08d1e6c15d545"},
|
||||
@@ -578,6 +580,7 @@ files = [
|
||||
{file = "contourpy-1.1.0-cp311-cp311-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:e5cec36c5090e75a9ac9dbd0ff4a8cf7cecd60f1b6dc23a374c7d980a1cd710e"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:1f0cbd657e9bde94cd0e33aa7df94fb73c1ab7799378d3b3f902eb8eb2e04a3a"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:181cbace49874f4358e2929aaf7ba84006acb76694102e88dd15af861996c16e"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-win32.whl", hash = "sha256:edb989d31065b1acef3828a3688f88b2abb799a7db891c9e282df5ec7e46221b"},
|
||||
{file = "contourpy-1.1.0-cp311-cp311-win_amd64.whl", hash = "sha256:fb3b7d9e6243bfa1efb93ccfe64ec610d85cfe5aec2c25f97fbbd2e58b531256"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-macosx_10_9_x86_64.whl", hash = "sha256:bcb41692aa09aeb19c7c213411854402f29f6613845ad2453d30bf421fe68fed"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-macosx_11_0_arm64.whl", hash = "sha256:5d123a5bc63cd34c27ff9c7ac1cd978909e9c71da12e05be0231c608048bb2ae"},
|
||||
@@ -586,6 +589,7 @@ files = [
|
||||
{file = "contourpy-1.1.0-cp38-cp38-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:317267d915490d1e84577924bd61ba71bf8681a30e0d6c545f577363157e5e94"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d551f3a442655f3dcc1285723f9acd646ca5858834efeab4598d706206b09c9f"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:e7a117ce7df5a938fe035cad481b0189049e8d92433b4b33aa7fc609344aafa1"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-win32.whl", hash = "sha256:108dfb5b3e731046a96c60bdc46a1a0ebee0760418951abecbe0fc07b5b93b27"},
|
||||
{file = "contourpy-1.1.0-cp38-cp38-win_amd64.whl", hash = "sha256:d4f26b25b4f86087e7d75e63212756c38546e70f2a92d2be44f80114826e1cd4"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:bc00bb4225d57bff7ebb634646c0ee2a1298402ec10a5fe7af79df9a51c1bfd9"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-macosx_11_0_arm64.whl", hash = "sha256:189ceb1525eb0655ab8487a9a9c41f42a73ba52d6789754788d1883fb06b2d8a"},
|
||||
@@ -594,6 +598,7 @@ files = [
|
||||
{file = "contourpy-1.1.0-cp39-cp39-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:143dde50520a9f90e4a2703f367cf8ec96a73042b72e68fcd184e1279962eb6f"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:e94bef2580e25b5fdb183bf98a2faa2adc5b638736b2c0a4da98691da641316a"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:ed614aea8462735e7d70141374bd7650afd1c3f3cb0c2dbbcbe44e14331bf002"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-win32.whl", hash = "sha256:71551f9520f008b2950bef5f16b0e3587506ef4f23c734b71ffb7b89f8721999"},
|
||||
{file = "contourpy-1.1.0-cp39-cp39-win_amd64.whl", hash = "sha256:438ba416d02f82b692e371858143970ed2eb6337d9cdbbede0d8ad9f3d7dd17d"},
|
||||
{file = "contourpy-1.1.0-pp38-pypy38_pp73-macosx_10_9_x86_64.whl", hash = "sha256:a698c6a7a432789e587168573a864a7ea374c6be8d4f31f9d87c001d5a843493"},
|
||||
{file = "contourpy-1.1.0-pp38-pypy38_pp73-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:397b0ac8a12880412da3551a8cb5a187d3298a72802b45a3bd1805e204ad8439"},
|
||||
@@ -2179,13 +2184,13 @@ test = ["coverage[toml]", "pymdown-extensions", "pytest", "pytest-cov"]
|
||||
|
||||
[[package]]
|
||||
name = "mkdocs-material"
|
||||
version = "9.5.11"
|
||||
version = "9.5.15"
|
||||
description = "Documentation that simply works"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mkdocs_material-9.5.11-py3-none-any.whl", hash = "sha256:788ee0f3e036dca2dc20298d65e480297d348a44c9d7b2ee05c5262983e66072"},
|
||||
{file = "mkdocs_material-9.5.11.tar.gz", hash = "sha256:7af7f8af0dea16175558f3fb9245d26c83a17199baa5f157755e63d7437bf971"},
|
||||
{file = "mkdocs_material-9.5.15-py3-none-any.whl", hash = "sha256:e5c96dec3d19491de49ca643fc1dbb92b278e43cdb816c775bc47db77d9b62fb"},
|
||||
{file = "mkdocs_material-9.5.15.tar.gz", hash = "sha256:39f03cca45e82bf54eb7456b5a18bd252eabfdd67f237a229471484a0a4d4635"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2276,38 +2281,38 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "mypy"
|
||||
version = "1.8.0"
|
||||
version = "1.9.0"
|
||||
description = "Optional static typing for Python"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "mypy-1.8.0-cp310-cp310-macosx_10_9_x86_64.whl", hash = "sha256:485a8942f671120f76afffff70f259e1cd0f0cfe08f81c05d8816d958d4577d3"},
|
||||
{file = "mypy-1.8.0-cp310-cp310-macosx_11_0_arm64.whl", hash = "sha256:df9824ac11deaf007443e7ed2a4a26bebff98d2bc43c6da21b2b64185da011c4"},
|
||||
{file = "mypy-1.8.0-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:2afecd6354bbfb6e0160f4e4ad9ba6e4e003b767dd80d85516e71f2e955ab50d"},
|
||||
{file = "mypy-1.8.0-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:8963b83d53ee733a6e4196954502b33567ad07dfd74851f32be18eb932fb1cb9"},
|
||||
{file = "mypy-1.8.0-cp310-cp310-win_amd64.whl", hash = "sha256:e46f44b54ebddbeedbd3d5b289a893219065ef805d95094d16a0af6630f5d410"},
|
||||
{file = "mypy-1.8.0-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:855fe27b80375e5c5878492f0729540db47b186509c98dae341254c8f45f42ae"},
|
||||
{file = "mypy-1.8.0-cp311-cp311-macosx_11_0_arm64.whl", hash = "sha256:4c886c6cce2d070bd7df4ec4a05a13ee20c0aa60cb587e8d1265b6c03cf91da3"},
|
||||
{file = "mypy-1.8.0-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d19c413b3c07cbecf1f991e2221746b0d2a9410b59cb3f4fb9557f0365a1a817"},
|
||||
{file = "mypy-1.8.0-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:9261ed810972061388918c83c3f5cd46079d875026ba97380f3e3978a72f503d"},
|
||||
{file = "mypy-1.8.0-cp311-cp311-win_amd64.whl", hash = "sha256:51720c776d148bad2372ca21ca29256ed483aa9a4cdefefcef49006dff2a6835"},
|
||||
{file = "mypy-1.8.0-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:52825b01f5c4c1c4eb0db253ec09c7aa17e1a7304d247c48b6f3599ef40db8bd"},
|
||||
{file = "mypy-1.8.0-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:f5ac9a4eeb1ec0f1ccdc6f326bcdb464de5f80eb07fb38b5ddd7b0de6bc61e55"},
|
||||
{file = "mypy-1.8.0-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:afe3fe972c645b4632c563d3f3eff1cdca2fa058f730df2b93a35e3b0c538218"},
|
||||
{file = "mypy-1.8.0-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:42c6680d256ab35637ef88891c6bd02514ccb7e1122133ac96055ff458f93fc3"},
|
||||
{file = "mypy-1.8.0-cp312-cp312-win_amd64.whl", hash = "sha256:720a5ca70e136b675af3af63db533c1c8c9181314d207568bbe79051f122669e"},
|
||||
{file = "mypy-1.8.0-cp38-cp38-macosx_10_9_x86_64.whl", hash = "sha256:028cf9f2cae89e202d7b6593cd98db6759379f17a319b5faf4f9978d7084cdc6"},
|
||||
{file = "mypy-1.8.0-cp38-cp38-macosx_11_0_arm64.whl", hash = "sha256:4e6d97288757e1ddba10dd9549ac27982e3e74a49d8d0179fc14d4365c7add66"},
|
||||
{file = "mypy-1.8.0-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:7f1478736fcebb90f97e40aff11a5f253af890c845ee0c850fe80aa060a267c6"},
|
||||
{file = "mypy-1.8.0-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:42419861b43e6962a649068a61f4a4839205a3ef525b858377a960b9e2de6e0d"},
|
||||
{file = "mypy-1.8.0-cp38-cp38-win_amd64.whl", hash = "sha256:2b5b6c721bd4aabaadead3a5e6fa85c11c6c795e0c81a7215776ef8afc66de02"},
|
||||
{file = "mypy-1.8.0-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:5c1538c38584029352878a0466f03a8ee7547d7bd9f641f57a0f3017a7c905b8"},
|
||||
{file = "mypy-1.8.0-cp39-cp39-macosx_11_0_arm64.whl", hash = "sha256:4ef4be7baf08a203170f29e89d79064463b7fc7a0908b9d0d5114e8009c3a259"},
|
||||
{file = "mypy-1.8.0-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:7178def594014aa6c35a8ff411cf37d682f428b3b5617ca79029d8ae72f5402b"},
|
||||
{file = "mypy-1.8.0-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:ab3c84fa13c04aeeeabb2a7f67a25ef5d77ac9d6486ff33ded762ef353aa5592"},
|
||||
{file = "mypy-1.8.0-cp39-cp39-win_amd64.whl", hash = "sha256:99b00bc72855812a60d253420d8a2eae839b0afa4938f09f4d2aa9bb4654263a"},
|
||||
{file = "mypy-1.8.0-py3-none-any.whl", hash = "sha256:538fd81bb5e430cc1381a443971c0475582ff9f434c16cd46d2c66763ce85d9d"},
|
||||
{file = "mypy-1.8.0.tar.gz", hash = "sha256:6ff8b244d7085a0b425b56d327b480c3b29cafbd2eff27316a004f9a7391ae07"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-macosx_10_9_x86_64.whl", hash = "sha256:f8a67616990062232ee4c3952f41c779afac41405806042a8126fe96e098419f"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-macosx_11_0_arm64.whl", hash = "sha256:d357423fa57a489e8c47b7c85dfb96698caba13d66e086b412298a1a0ea3b0ed"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:49c87c15aed320de9b438ae7b00c1ac91cd393c1b854c2ce538e2a72d55df150"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:48533cdd345c3c2e5ef48ba3b0d3880b257b423e7995dada04248725c6f77374"},
|
||||
{file = "mypy-1.9.0-cp310-cp310-win_amd64.whl", hash = "sha256:4d3dbd346cfec7cb98e6cbb6e0f3c23618af826316188d587d1c1bc34f0ede03"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:653265f9a2784db65bfca694d1edd23093ce49740b2244cde583aeb134c008f3"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-macosx_11_0_arm64.whl", hash = "sha256:3a3c007ff3ee90f69cf0a15cbcdf0995749569b86b6d2f327af01fd1b8aee9dc"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:2418488264eb41f69cc64a69a745fad4a8f86649af4b1041a4c64ee61fc61129"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:68edad3dc7d70f2f17ae4c6c1b9471a56138ca22722487eebacfd1eb5321d612"},
|
||||
{file = "mypy-1.9.0-cp311-cp311-win_amd64.whl", hash = "sha256:85ca5fcc24f0b4aeedc1d02f93707bccc04733f21d41c88334c5482219b1ccb3"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:aceb1db093b04db5cd390821464504111b8ec3e351eb85afd1433490163d60cd"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:0235391f1c6f6ce487b23b9dbd1327b4ec33bb93934aa986efe8a9563d9349e6"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d4d5ddc13421ba3e2e082a6c2d74c2ddb3979c39b582dacd53dd5d9431237185"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:190da1ee69b427d7efa8aa0d5e5ccd67a4fb04038c380237a0d96829cb157913"},
|
||||
{file = "mypy-1.9.0-cp312-cp312-win_amd64.whl", hash = "sha256:fe28657de3bfec596bbeef01cb219833ad9d38dd5393fc649f4b366840baefe6"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-macosx_10_9_x86_64.whl", hash = "sha256:e54396d70be04b34f31d2edf3362c1edd023246c82f1730bbf8768c28db5361b"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-macosx_11_0_arm64.whl", hash = "sha256:5e6061f44f2313b94f920e91b204ec600982961e07a17e0f6cd83371cb23f5c2"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:81a10926e5473c5fc3da8abb04119a1f5811a236dc3a38d92015cb1e6ba4cb9e"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:b685154e22e4e9199fc95f298661deea28aaede5ae16ccc8cbb1045e716b3e04"},
|
||||
{file = "mypy-1.9.0-cp38-cp38-win_amd64.whl", hash = "sha256:5d741d3fc7c4da608764073089e5f58ef6352bedc223ff58f2f038c2c4698a89"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:587ce887f75dd9700252a3abbc9c97bbe165a4a630597845c61279cf32dfbf02"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-macosx_11_0_arm64.whl", hash = "sha256:f88566144752999351725ac623471661c9d1cd8caa0134ff98cceeea181789f4"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:61758fabd58ce4b0720ae1e2fea5cfd4431591d6d590b197775329264f86311d"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:e49499be624dead83927e70c756970a0bc8240e9f769389cdf5714b0784ca6bf"},
|
||||
{file = "mypy-1.9.0-cp39-cp39-win_amd64.whl", hash = "sha256:571741dc4194b4f82d344b15e8837e8c5fcc462d66d076748142327626a1b6e9"},
|
||||
{file = "mypy-1.9.0-py3-none-any.whl", hash = "sha256:a260627a570559181a9ea5de61ac6297aa5af202f06fd7ab093ce74e7181e43e"},
|
||||
{file = "mypy-1.9.0.tar.gz", hash = "sha256:3cc5da0127e6a478cddd906068496a97a7618a21ce9b54bde5bf7e539c7af974"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2356,13 +2361,13 @@ test = ["flaky", "ipykernel (>=6.19.3)", "ipython", "ipywidgets", "nbconvert (>=
|
||||
|
||||
[[package]]
|
||||
name = "nbconvert"
|
||||
version = "7.16.1"
|
||||
version = "7.16.3"
|
||||
description = "Converting Jupyter Notebooks (.ipynb files) to other formats. Output formats include asciidoc, html, latex, markdown, pdf, py, rst, script. nbconvert can be used both as a Python library (`import nbconvert`) or as a command line tool (invoked as `jupyter nbconvert ...`)."
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "nbconvert-7.16.1-py3-none-any.whl", hash = "sha256:3188727dffadfdc9c6a1c7250729063d7bc78b355ad7aa023138afa030d1cd07"},
|
||||
{file = "nbconvert-7.16.1.tar.gz", hash = "sha256:e79e6a074f49ba3ed29428ed86487bf51509d9aab613bd8522ac08f6d28fd7fd"},
|
||||
{file = "nbconvert-7.16.3-py3-none-any.whl", hash = "sha256:ddeff14beeeedf3dd0bc506623e41e4507e551736de59df69a91f86700292b3b"},
|
||||
{file = "nbconvert-7.16.3.tar.gz", hash = "sha256:a6733b78ce3d47c3f85e504998495b07e6ea9cf9bf6ec1c98dda63ec6ad19142"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2389,7 +2394,7 @@ docs = ["ipykernel", "ipython", "myst-parser", "nbsphinx (>=0.2.12)", "pydata-sp
|
||||
qtpdf = ["nbconvert[qtpng]"]
|
||||
qtpng = ["pyqtwebengine (>=5.15)"]
|
||||
serve = ["tornado (>=6.1)"]
|
||||
test = ["flaky", "ipykernel", "ipywidgets (>=7.5)", "pytest"]
|
||||
test = ["flaky", "ipykernel", "ipywidgets (>=7.5)", "pytest (>=7)"]
|
||||
webpdf = ["playwright"]
|
||||
|
||||
[[package]]
|
||||
@@ -2465,13 +2470,13 @@ setuptools = "*"
|
||||
|
||||
[[package]]
|
||||
name = "notebook"
|
||||
version = "7.1.1"
|
||||
version = "7.1.2"
|
||||
description = "Jupyter Notebook - A web-based notebook environment for interactive computing"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "notebook-7.1.1-py3-none-any.whl", hash = "sha256:197d8e0595acabf4005851c8716e952a81b405f7aefb648067a761fbde267ce7"},
|
||||
{file = "notebook-7.1.1.tar.gz", hash = "sha256:818e7420fa21f402e726afb9f02df7f3c10f294c02e383ed19852866c316108b"},
|
||||
{file = "notebook-7.1.2-py3-none-any.whl", hash = "sha256:fc6c24b9aef18d0cd57157c9c47e95833b9b0bdc599652639acf0bdb61dc7d5f"},
|
||||
{file = "notebook-7.1.2.tar.gz", hash = "sha256:efc2c80043909e0faa17fce9e9b37c059c03af0ec99a4d4db84cb21d9d2e936a"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -2556,31 +2561,12 @@ files = [
|
||||
{file = "opencv_python-4.8.1.78-cp37-abi3-win_amd64.whl", hash = "sha256:b983197f97cfa6fcb74e1da1802c7497a6f94ed561aba6980f1f33123f904956"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
numpy = {version = ">=1.23.5", markers = "python_version >= \"3.11\""}
|
||||
|
||||
[[package]]
|
||||
name = "opencv-python"
|
||||
version = "4.9.0.80"
|
||||
description = "Wrapper package for OpenCV python bindings."
|
||||
optional = true
|
||||
python-versions = ">=3.6"
|
||||
files = [
|
||||
{file = "opencv-python-4.9.0.80.tar.gz", hash = "sha256:1a9f0e6267de3a1a1db0c54213d022c7c8b5b9ca4b580e80bdc58516c922c9e1"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-macosx_10_16_x86_64.whl", hash = "sha256:7e5f7aa4486651a6ebfa8ed4b594b65bd2d2f41beeb4241a3e4b1b85acbbbadb"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-macosx_11_0_arm64.whl", hash = "sha256:71dfb9555ccccdd77305fc3dcca5897fbf0cf28b297c51ee55e079c065d812a3"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:7b34a52e9da36dda8c151c6394aed602e4b17fa041df0b9f5b93ae10b0fcca2a"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:e4088cab82b66a3b37ffc452976b14a3c599269c247895ae9ceb4066d8188a57"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-win32.whl", hash = "sha256:dcf000c36dd1651118a2462257e3a9e76db789a78432e1f303c7bac54f63ef6c"},
|
||||
{file = "opencv_python-4.9.0.80-cp37-abi3-win_amd64.whl", hash = "sha256:3f16f08e02b2a2da44259c7cc712e779eff1dd8b55fdb0323e8cab09548086c0"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
numpy = [
|
||||
{version = ">=1.21.0", markers = "python_version <= \"3.9\" and platform_system == \"Darwin\" and platform_machine == \"arm64\" and python_version >= \"3.8\""},
|
||||
{version = ">=1.19.3", markers = "platform_system == \"Linux\" and platform_machine == \"aarch64\" and python_version >= \"3.8\" and python_version < \"3.10\" or python_version > \"3.9\" and python_version < \"3.10\" or python_version >= \"3.9\" and platform_system != \"Darwin\" and python_version < \"3.10\" or python_version >= \"3.9\" and platform_machine != \"arm64\" and python_version < \"3.10\""},
|
||||
{version = ">=1.17.3", markers = "(platform_system != \"Darwin\" and platform_system != \"Linux\") and python_version >= \"3.8\" and python_version < \"3.9\" or platform_system != \"Darwin\" and python_version >= \"3.8\" and python_version < \"3.9\" and platform_machine != \"aarch64\" or platform_machine != \"arm64\" and python_version >= \"3.8\" and python_version < \"3.9\" and platform_system != \"Linux\" or (platform_machine != \"arm64\" and platform_machine != \"aarch64\") and python_version >= \"3.8\" and python_version < \"3.9\""},
|
||||
{version = ">=1.23.5", markers = "python_version >= \"3.11\" and python_version < \"3.12\""},
|
||||
{version = ">=1.23.5", markers = "python_version >= \"3.11\""},
|
||||
{version = ">=1.21.4", markers = "python_version >= \"3.10\" and platform_system == \"Darwin\" and python_version < \"3.11\""},
|
||||
{version = ">=1.21.2", markers = "platform_system != \"Darwin\" and python_version >= \"3.10\" and python_version < \"3.11\""},
|
||||
]
|
||||
@@ -2601,31 +2587,12 @@ files = [
|
||||
{file = "opencv_python_headless-4.8.1.78-cp37-abi3-win_amd64.whl", hash = "sha256:0a0f1e9f836f7d5bad1dd164694944c8761711cbdf4b36ebbd4815a8ef731079"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
numpy = {version = ">=1.23.5", markers = "python_version >= \"3.11\""}
|
||||
|
||||
[[package]]
|
||||
name = "opencv-python-headless"
|
||||
version = "4.9.0.80"
|
||||
description = "Wrapper package for OpenCV python bindings."
|
||||
optional = false
|
||||
python-versions = ">=3.6"
|
||||
files = [
|
||||
{file = "opencv-python-headless-4.9.0.80.tar.gz", hash = "sha256:71a4cd8cf7c37122901d8e81295db7fb188730e33a0e40039a4e59c1030b0958"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-macosx_10_16_x86_64.whl", hash = "sha256:2ea8a2edc4db87841991b2fbab55fc07b97ecb602e0f47d5d485bd75cee17c1a"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-macosx_11_0_arm64.whl", hash = "sha256:e0ee54e27be493e8f7850847edae3128e18b540dac1d7b2e4001b8944e11e1c6"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:57ce2865e8fec431c6f97a81e9faaf23fa5be61011d0a75ccf47a3c0d65fa73d"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:976656362d68d9f40a5c66f83901430538002465f7db59142784f3893918f3df"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-win32.whl", hash = "sha256:11e3849d83e6651d4e7699aadda9ec7ed7c38957cbbcb99db074f2a2d2de9670"},
|
||||
{file = "opencv_python_headless-4.9.0.80-cp37-abi3-win_amd64.whl", hash = "sha256:a8056c2cb37cd65dfcdf4153ca16f7362afcf3a50d600d6bb69c660fc61ee29c"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
numpy = [
|
||||
{version = ">=1.21.0", markers = "python_version <= \"3.9\" and platform_system == \"Darwin\" and platform_machine == \"arm64\" and python_version >= \"3.8\""},
|
||||
{version = ">=1.19.3", markers = "platform_system == \"Linux\" and platform_machine == \"aarch64\" and python_version >= \"3.8\" and python_version < \"3.10\" or python_version > \"3.9\" and python_version < \"3.10\" or python_version >= \"3.9\" and platform_system != \"Darwin\" and python_version < \"3.10\" or python_version >= \"3.9\" and platform_machine != \"arm64\" and python_version < \"3.10\""},
|
||||
{version = ">=1.17.3", markers = "(platform_system != \"Darwin\" and platform_system != \"Linux\") and python_version >= \"3.8\" and python_version < \"3.9\" or platform_system != \"Darwin\" and python_version >= \"3.8\" and python_version < \"3.9\" and platform_machine != \"aarch64\" or platform_machine != \"arm64\" and python_version >= \"3.8\" and python_version < \"3.9\" and platform_system != \"Linux\" or (platform_machine != \"arm64\" and platform_machine != \"aarch64\") and python_version >= \"3.8\" and python_version < \"3.9\""},
|
||||
{version = ">=1.23.5", markers = "python_version >= \"3.11\" and python_version < \"3.12\""},
|
||||
{version = ">=1.23.5", markers = "python_version >= \"3.11\""},
|
||||
{version = ">=1.21.4", markers = "python_version >= \"3.10\" and platform_system == \"Darwin\" and python_version < \"3.11\""},
|
||||
{version = ">=1.21.2", markers = "platform_system != \"Darwin\" and python_version >= \"3.10\" and python_version < \"3.11\""},
|
||||
]
|
||||
@@ -3056,13 +3023,13 @@ tomli = {version = ">=1.1.0", markers = "python_version < \"3.11\""}
|
||||
|
||||
[[package]]
|
||||
name = "pytest"
|
||||
version = "8.0.2"
|
||||
version = "8.1.1"
|
||||
description = "pytest: simple powerful testing with Python"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "pytest-8.0.2-py3-none-any.whl", hash = "sha256:edfaaef32ce5172d5466b5127b42e0d6d35ebbe4453f0e3505d96afd93f6b096"},
|
||||
{file = "pytest-8.0.2.tar.gz", hash = "sha256:d4051d623a2e0b7e51960ba963193b09ce6daeb9759a451844a21e4ddedfc1bd"},
|
||||
{file = "pytest-8.1.1-py3-none-any.whl", hash = "sha256:2a8386cfc11fa9d2c50ee7b2a57e7d898ef90470a7a34c4b949ff59662bb78b7"},
|
||||
{file = "pytest-8.1.1.tar.gz", hash = "sha256:ac978141a75948948817d360297b7aae0fcb9d6ff6bc9ec6d514b85d5a65c044"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -3070,11 +3037,11 @@ colorama = {version = "*", markers = "sys_platform == \"win32\""}
|
||||
exceptiongroup = {version = ">=1.0.0rc8", markers = "python_version < \"3.11\""}
|
||||
iniconfig = "*"
|
||||
packaging = "*"
|
||||
pluggy = ">=1.3.0,<2.0"
|
||||
tomli = {version = ">=1.0.0", markers = "python_version < \"3.11\""}
|
||||
pluggy = ">=1.4,<2.0"
|
||||
tomli = {version = ">=1", markers = "python_version < \"3.11\""}
|
||||
|
||||
[package.extras]
|
||||
testing = ["argcomplete", "attrs (>=19.2.0)", "hypothesis (>=3.56)", "mock", "nose", "pygments (>=2.7.2)", "requests", "setuptools", "xmlschema"]
|
||||
testing = ["argcomplete", "attrs (>=19.2)", "hypothesis (>=3.56)", "mock", "pygments (>=2.7.2)", "requests", "setuptools", "xmlschema"]
|
||||
|
||||
[[package]]
|
||||
name = "python-dateutil"
|
||||
@@ -3173,6 +3140,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:69b023b2b4daa7548bcfbd4aa3da05b3a74b772db9e23b982788168117739938"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:81e0b275a9ecc9c0c0c07b4b90ba548307583c125f54d5b6946cfee6360c733d"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:ba336e390cd8e4d1739f42dfe9bb83a3cc2e80f567d8805e11b46f4a943f5515"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:326c013efe8048858a6d312ddd31d56e468118ad4cdeda36c719bf5bb6192290"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-win32.whl", hash = "sha256:bd4af7373a854424dabd882decdc5579653d7868b8fb26dc7d0e99f823aa5924"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-win_amd64.whl", hash = "sha256:fd1592b3fdf65fff2ad0004b5e363300ef59ced41c2e6b3a99d4089fa8c5435d"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:6965a7bc3cf88e5a1c3bd2e0b5c22f8d677dc88a455344035f03399034eb3007"},
|
||||
@@ -3180,8 +3148,16 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:42f8152b8dbc4fe7d96729ec2b99c7097d656dc1213a3229ca5383f973a5ed6d"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:062582fca9fabdd2c8b54a3ef1c978d786e0f6b3a1510e0ac93ef59e0ddae2bc"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d2b04aac4d386b172d5b9692e2d2da8de7bfb6c387fa4f801fbf6fb2e6ba4673"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:e7d73685e87afe9f3b36c799222440d6cf362062f78be1013661b00c5c6f678b"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-win32.whl", hash = "sha256:1635fd110e8d85d55237ab316b5b011de701ea0f29d07611174a1b42f1444741"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-win_amd64.whl", hash = "sha256:bf07ee2fef7014951eeb99f56f39c9bb4af143d8aa3c21b1677805985307da34"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:855fb52b0dc35af121542a76b9a84f8d1cd886ea97c84703eaa6d88e37a2ad28"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:40df9b996c2b73138957fe23a16a4f0ba614f4c0efce1e9406a184b6d07fa3a9"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:a08c6f0fe150303c1c6b71ebcd7213c2858041a7e01975da3a99aed1e7a378ef"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:6c22bec3fbe2524cde73d7ada88f6566758a8f7227bfbf93a408a9d86bcc12a0"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:8d4e9c88387b0f5c7d5f281e55304de64cf7f9c0021a3525bd3b1c542da3b0e4"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-win32.whl", hash = "sha256:d483d2cdf104e7c9fa60c544d92981f12ad66a457afae824d146093b8c294c54"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-win_amd64.whl", hash = "sha256:0d3304d8c0adc42be59c5f8a4d9e3d7379e6955ad754aa9d6ab7a398b59dd1df"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-macosx_10_9_x86_64.whl", hash = "sha256:50550eb667afee136e9a77d6dc71ae76a44df8b3e51e41b77f6de2932bfe0f47"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:1fe35611261b29bd1de0070f0b2f47cb6ff71fa6595c077e42bd0c419fa27b98"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:704219a11b772aea0d8ecd7058d0082713c3562b4e271b849ad7dc4a5c90c13c"},
|
||||
@@ -3198,6 +3174,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:a0cd17c15d3bb3fa06978b4e8958dcdc6e0174ccea823003a106c7d4d7899ac5"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:28c119d996beec18c05208a8bd78cbe4007878c6dd15091efb73a30e90539696"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:7e07cbde391ba96ab58e532ff4803f79c4129397514e1413a7dc761ccd755735"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:49a183be227561de579b4a36efbb21b3eab9651dd81b1858589f796549873dd6"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-win32.whl", hash = "sha256:184c5108a2aca3c5b3d3bf9395d50893a7ab82a38004c8f61c258d4428e80206"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-win_amd64.whl", hash = "sha256:1e2722cc9fbb45d9b87631ac70924c11d3a401b2d7f410cc0e3bbf249f2dca62"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:9eb6caa9a297fc2c2fb8862bc5370d0303ddba53ba97e71f08023b6cd73d16a8"},
|
||||
@@ -3205,6 +3182,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:5773183b6446b2c99bb77e77595dd486303b4faab2b086e7b17bc6bef28865f6"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:b786eecbdf8499b9ca1d697215862083bd6d2a99965554781d0d8d1ad31e13a0"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:bc1bf2925a1ecd43da378f4db9e4f799775d6367bdb94671027b73b393a7c42c"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:04ac92ad1925b2cff1db0cfebffb6ffc43457495c9b3c39d3fcae417d7125dc5"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-win32.whl", hash = "sha256:faca3bdcf85b2fc05d06ff3fbc1f83e1391b3e724afa3feba7d13eeab355484c"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-win_amd64.whl", hash = "sha256:510c9deebc5c0225e8c96813043e62b680ba2f9c50a08d3724c7f28a747d1486"},
|
||||
{file = "PyYAML-6.0.1.tar.gz", hash = "sha256:bfdf460b1736c775f2ba9f6a92bca30bc2095067b8a9d77876d1fad6cc3b4a43"},
|
||||
@@ -3668,28 +3646,28 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "ruff"
|
||||
version = "0.2.2"
|
||||
version = "0.3.4"
|
||||
description = "An extremely fast Python linter and code formatter, written in Rust."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "ruff-0.2.2-py3-none-macosx_10_12_x86_64.macosx_11_0_arm64.macosx_10_12_universal2.whl", hash = "sha256:0a9efb032855ffb3c21f6405751d5e147b0c6b631e3ca3f6b20f917572b97eb6"},
|
||||
{file = "ruff-0.2.2-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:d450b7fbff85913f866a5384d8912710936e2b96da74541c82c1b458472ddb39"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:ecd46e3106850a5c26aee114e562c329f9a1fbe9e4821b008c4404f64ff9ce73"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:5e22676a5b875bd72acd3d11d5fa9075d3a5f53b877fe7b4793e4673499318ba"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:1695700d1e25a99d28f7a1636d85bafcc5030bba9d0578c0781ba1790dbcf51c"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:b0c232af3d0bd8f521806223723456ffebf8e323bd1e4e82b0befb20ba18388e"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:f63d96494eeec2fc70d909393bcd76c69f35334cdbd9e20d089fb3f0640216ca"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:6a61ea0ff048e06de273b2e45bd72629f470f5da8f71daf09fe481278b175001"},
|
||||
{file = "ruff-0.2.2-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:5e1439c8f407e4f356470e54cdecdca1bd5439a0673792dbe34a2b0a551a2fe3"},
|
||||
{file = "ruff-0.2.2-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:940de32dc8853eba0f67f7198b3e79bc6ba95c2edbfdfac2144c8235114d6726"},
|
||||
{file = "ruff-0.2.2-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:0c126da55c38dd917621552ab430213bdb3273bb10ddb67bc4b761989210eb6e"},
|
||||
{file = "ruff-0.2.2-py3-none-musllinux_1_2_i686.whl", hash = "sha256:3b65494f7e4bed2e74110dac1f0d17dc8e1f42faaa784e7c58a98e335ec83d7e"},
|
||||
{file = "ruff-0.2.2-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:1ec49be4fe6ddac0503833f3ed8930528e26d1e60ad35c2446da372d16651ce9"},
|
||||
{file = "ruff-0.2.2-py3-none-win32.whl", hash = "sha256:d920499b576f6c68295bc04e7b17b6544d9d05f196bb3aac4358792ef6f34325"},
|
||||
{file = "ruff-0.2.2-py3-none-win_amd64.whl", hash = "sha256:cc9a91ae137d687f43a44c900e5d95e9617cb37d4c989e462980ba27039d239d"},
|
||||
{file = "ruff-0.2.2-py3-none-win_arm64.whl", hash = "sha256:c9d15fc41e6054bfc7200478720570078f0b41c9ae4f010bcc16bd6f4d1aacdd"},
|
||||
{file = "ruff-0.2.2.tar.gz", hash = "sha256:e62ed7f36b3068a30ba39193a14274cd706bc486fad521276458022f7bccb31d"},
|
||||
{file = "ruff-0.3.4-py3-none-macosx_10_12_x86_64.macosx_11_0_arm64.macosx_10_12_universal2.whl", hash = "sha256:60c870a7d46efcbc8385d27ec07fe534ac32f3b251e4fc44b3cbfd9e09609ef4"},
|
||||
{file = "ruff-0.3.4-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:6fc14fa742e1d8f24910e1fff0bd5e26d395b0e0e04cc1b15c7c5e5fe5b4af91"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:d3ee7880f653cc03749a3bfea720cf2a192e4f884925b0cf7eecce82f0ce5854"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:cf133dd744f2470b347f602452a88e70dadfbe0fcfb5fd46e093d55da65f82f7"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:3f3860057590e810c7ffea75669bdc6927bfd91e29b4baa9258fd48b540a4365"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:986f2377f7cf12efac1f515fc1a5b753c000ed1e0a6de96747cdf2da20a1b369"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:c4fd98e85869603e65f554fdc5cddf0712e352fe6e61d29d5a6fe087ec82b76c"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:64abeed785dad51801b423fa51840b1764b35d6c461ea8caef9cf9e5e5ab34d9"},
|
||||
{file = "ruff-0.3.4-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:df52972138318bc7546d92348a1ee58449bc3f9eaf0db278906eb511889c4b50"},
|
||||
{file = "ruff-0.3.4-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:98e98300056445ba2cc27d0b325fd044dc17fcc38e4e4d2c7711585bd0a958ed"},
|
||||
{file = "ruff-0.3.4-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:519cf6a0ebed244dce1dc8aecd3dc99add7a2ee15bb68cf19588bb5bf58e0488"},
|
||||
{file = "ruff-0.3.4-py3-none-musllinux_1_2_i686.whl", hash = "sha256:bb0acfb921030d00070539c038cd24bb1df73a2981e9f55942514af8b17be94e"},
|
||||
{file = "ruff-0.3.4-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:cf187a7e7098233d0d0c71175375c5162f880126c4c716fa28a8ac418dcf3378"},
|
||||
{file = "ruff-0.3.4-py3-none-win32.whl", hash = "sha256:af27ac187c0a331e8ef91d84bf1c3c6a5dea97e912a7560ac0cef25c526a4102"},
|
||||
{file = "ruff-0.3.4-py3-none-win_amd64.whl", hash = "sha256:de0d5069b165e5a32b3c6ffbb81c350b1e3d3483347196ffdf86dc0ef9e37dd6"},
|
||||
{file = "ruff-0.3.4-py3-none-win_arm64.whl", hash = "sha256:6810563cc08ad0096b57c717bd78aeac888a1bfd38654d9113cb3dc4d3f74232"},
|
||||
{file = "ruff-0.3.4.tar.gz", hash = "sha256:f0f4484c6541a99862b693e13a151435a279b271cff20e37101116a21e2a1ad1"},
|
||||
]
|
||||
|
||||
[[package]]
|
||||
@@ -3965,13 +3943,13 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "tox"
|
||||
version = "4.13.0"
|
||||
version = "4.14.2"
|
||||
description = "tox is a generic virtualenv management and test command line tool"
|
||||
optional = false
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "tox-4.13.0-py3-none-any.whl", hash = "sha256:1143c7e2489c68026a55d3d4ae84c02c449f073b28e62f80e3e440a3b72a4afa"},
|
||||
{file = "tox-4.13.0.tar.gz", hash = "sha256:dd789a554c16c4b532924ba393c92fc8991323c4b3d466712bfecc8c9b9f24f7"},
|
||||
{file = "tox-4.14.2-py3-none-any.whl", hash = "sha256:2900c4eb7b716af4a928a7fdc2ed248ad6575294ed7cfae2ea41203937422847"},
|
||||
{file = "tox-4.14.2.tar.gz", hash = "sha256:0defb44f6dafd911b61788325741cc6b2e12ea71f987ac025ad4d649f1f1a104"},
|
||||
]
|
||||
|
||||
[package.dependencies]
|
||||
@@ -4230,13 +4208,13 @@ test = ["websockets"]
|
||||
|
||||
[[package]]
|
||||
name = "wheel"
|
||||
version = "0.42.0"
|
||||
version = "0.43.0"
|
||||
description = "A built-package format for Python"
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
python-versions = ">=3.8"
|
||||
files = [
|
||||
{file = "wheel-0.42.0-py3-none-any.whl", hash = "sha256:177f9c9b0d45c47873b619f5b650346d632cdc35fb5e4d25058e09c9e581433d"},
|
||||
{file = "wheel-0.42.0.tar.gz", hash = "sha256:c45be39f7882c9d34243236f2d63cbd58039e360f85d0913425fbd7ceea617a8"},
|
||||
{file = "wheel-0.43.0-py3-none-any.whl", hash = "sha256:55c570405f142630c6b9f72fe09d9b67cf1477fcf543ae5b8dcb1f5b7377da81"},
|
||||
{file = "wheel-0.43.0.tar.gz", hash = "sha256:465ef92c69fa5c5da2d1cf8ac40559a8c940886afcef87dcf14b9470862f1d85"},
|
||||
]
|
||||
|
||||
[package.extras]
|
||||
@@ -4275,4 +4253,4 @@ desktop = ["opencv-python"]
|
||||
[metadata]
|
||||
lock-version = "2.0"
|
||||
python-versions = "^3.8"
|
||||
content-hash = "8010232d55d2b5ad5dd5b0ab950ca0e417e705f105bd5331d2e44afb26151010"
|
||||
content-hash = "56ddae6824a9f28c9954badd4c642c57f687b099c6169f97fa0372e294500c17"
|
||||
|
||||
+12
-17
@@ -1,6 +1,6 @@
|
||||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.19.0rc5"
|
||||
version = "0.20.0rc2"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
@@ -53,8 +53,8 @@ assets = ["requests","tqdm"]
|
||||
[tool.poetry.group.dev.dependencies]
|
||||
twine = ">=4.0.2,<6.0.0"
|
||||
pytest = ">=7.2.2,<9.0.0"
|
||||
wheel = ">=0.40,<0.43"
|
||||
build = ">=0.10,<1.1"
|
||||
wheel = ">=0.40,<0.44"
|
||||
build = ">=0.10,<1.3"
|
||||
ruff = ">=0.1.0"
|
||||
mypy = "^1.4.1"
|
||||
pre-commit = "^3.3.3"
|
||||
@@ -111,13 +111,6 @@ exclude = '''
|
||||
|
||||
[tool.ruff]
|
||||
target-version = "py38"
|
||||
# Enable pycodestyle (`E`) and Pyflakes (`F`) codes by default.
|
||||
lint.select = ["E", "F"]
|
||||
lint.ignore = []
|
||||
|
||||
# Allow autofix for all enabled rules (when `--fix`) is provided.
|
||||
lint.fixable = ["A", "B", "C", "D", "E", "F", "G", "I", "N", "Q", "S", "T", "W", "ANN", "ARG", "BLE", "COM", "DJ", "DTZ", "EM", "ERA", "EXE", "FBT", "ICN", "INP", "ISC", "NPY", "PD", "PGH", "PIE", "PL", "PT", "PTH", "PYI", "RET", "RSE", "RUF", "SIM", "SLF", "TCH", "TID", "TRY", "UP", "YTT"]
|
||||
lint.unfixable = []
|
||||
|
||||
# Exclude a variety of commonly ignored directories.
|
||||
exclude = [
|
||||
@@ -147,12 +140,19 @@ exclude = [
|
||||
"docs",
|
||||
]
|
||||
|
||||
# Same as Black.
|
||||
line-length = 88
|
||||
indent-width = 4
|
||||
|
||||
[tool.ruff.lint]
|
||||
# Enable pycodestyle (`E`) and Pyflakes (`F`) codes by default.
|
||||
select = ["E", "F"]
|
||||
ignore = []
|
||||
# Allow autofix for all enabled rules (when `--fix`) is provided.
|
||||
fixable = ["A", "B", "C", "D", "E", "F", "G", "I", "N", "Q", "S", "T", "W", "ANN", "ARG", "BLE", "COM", "DJ", "DTZ", "EM", "ERA", "EXE", "FBT", "ICN", "INP", "ISC", "NPY", "PD", "PGH", "PIE", "PL", "PT", "PTH", "PYI", "RET", "RSE", "RUF", "SIM", "SLF", "TCH", "TID", "TRY", "UP", "YTT"]
|
||||
unfixable = []
|
||||
# Allow unused variables when underscore-prefixed.
|
||||
lint.dummy-variable-rgx = "^(_+|(_+[a-zA-Z0-9_]*[a-zA-Z0-9]+?))$"
|
||||
dummy-variable-rgx = "^(_+|(_+[a-zA-Z0-9_]*[a-zA-Z0-9]+?))$"
|
||||
pylint.max-args = 20
|
||||
|
||||
[tool.ruff.lint.flake8-quotes]
|
||||
inline-quotes = "double"
|
||||
@@ -164,16 +164,11 @@ convention = "google"
|
||||
|
||||
[tool.ruff.lint.per-file-ignores]
|
||||
"__init__.py" = ["E402","F401"]
|
||||
"supervision/assets/list.py" = ["E501"]
|
||||
|
||||
[tool.ruff.lint.mccabe]
|
||||
# Flag errors (`C901`) whenever the complexity level exceeds 5.
|
||||
max-complexity = 20
|
||||
|
||||
|
||||
[tool.ruff.pylint]
|
||||
max-args = 20
|
||||
|
||||
[tool.ruff.format]
|
||||
# Like Black, use double quotes for strings.
|
||||
quote-style = "double"
|
||||
|
||||
@@ -12,6 +12,7 @@ from supervision.annotators.core import (
|
||||
BoxCornerAnnotator,
|
||||
CircleAnnotator,
|
||||
ColorAnnotator,
|
||||
CropAnnotator,
|
||||
DotAnnotator,
|
||||
EllipseAnnotator,
|
||||
HaloAnnotator,
|
||||
@@ -38,6 +39,7 @@ from supervision.detection.core import Detections
|
||||
from supervision.detection.line_zone import LineZone, LineZoneAnnotator
|
||||
from supervision.detection.tools.csv_sink import CSVSink
|
||||
from supervision.detection.tools.inference_slicer import InferenceSlicer
|
||||
from supervision.detection.tools.json_sink import JSONSink
|
||||
from supervision.detection.tools.polygon_zone import PolygonZone, PolygonZoneAnnotator
|
||||
from supervision.detection.tools.smoother import DetectionsSmoother
|
||||
from supervision.detection.utils import (
|
||||
@@ -56,8 +58,8 @@ from supervision.detection.utils import (
|
||||
)
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.draw.utils import (
|
||||
calculate_dynamic_line_thickness,
|
||||
calculate_dynamic_text_scale,
|
||||
calculate_optimal_line_thickness,
|
||||
calculate_optimal_text_scale,
|
||||
draw_filled_rectangle,
|
||||
draw_image,
|
||||
draw_line,
|
||||
@@ -70,7 +72,7 @@ from supervision.geometry.utils import get_polygon_center
|
||||
from supervision.metrics.detection import ConfusionMatrix, MeanAveragePrecision
|
||||
from supervision.tracker.byte_tracker.core import ByteTrack
|
||||
from supervision.utils.file import list_files_with_extensions
|
||||
from supervision.utils.image import ImageSink, crop_image
|
||||
from supervision.utils.image import ImageSink, crop_image, place_image, resize_image
|
||||
from supervision.utils.notebook import plot_image, plot_images_grid
|
||||
from supervision.utils.video import (
|
||||
FPSMonitor,
|
||||
|
||||
@@ -17,6 +17,7 @@ from supervision.detection.utils import clip_boxes, mask_to_polygons
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.draw.utils import draw_polygon
|
||||
from supervision.geometry.core import Position
|
||||
from supervision.utils.image import crop_image, place_image, resize_image
|
||||
|
||||
|
||||
class BoundingBoxAnnotator(BaseAnnotator):
|
||||
@@ -913,6 +914,7 @@ class LabelAnnotator:
|
||||
text_padding: int = 10,
|
||||
text_position: Position = Position.TOP_LEFT,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
border_radius: int = 0,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
@@ -926,7 +928,10 @@ class LabelAnnotator:
|
||||
Possible values are defined in the `Position` enum.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
border_radius (int): The radius to apply round edges. If the selected
|
||||
value is higher than the lower dimension, width or height, is clipped.
|
||||
"""
|
||||
self.border_radius: int = border_radius
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.text_color: Color = text_color
|
||||
self.text_scale: float = text_scale
|
||||
@@ -1014,15 +1019,22 @@ class LabelAnnotator:
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
|
||||
labels = [
|
||||
f"{class_name} {confidence:.2f}"
|
||||
for class_name, confidence
|
||||
in zip(detections['class_name'], detections.confidence)
|
||||
]
|
||||
|
||||
label_annotator = sv.LabelAnnotator(text_position=sv.Position.CENTER)
|
||||
annotated_frame = label_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
detections=detections,
|
||||
labels=labels
|
||||
)
|
||||
```
|
||||
|
||||
@@ -1079,12 +1091,11 @@ class LabelAnnotator:
|
||||
text_x = text_background_xyxy[0] + self.text_padding
|
||||
text_y = text_background_xyxy[1] + self.text_padding + text_h
|
||||
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=(text_background_xyxy[0], text_background_xyxy[1]),
|
||||
pt2=(text_background_xyxy[2], text_background_xyxy[3]),
|
||||
self.draw_rounded_rectangle(
|
||||
scene=scene,
|
||||
xyxy=text_background_xyxy,
|
||||
color=color.as_bgr(),
|
||||
thickness=cv2.FILLED,
|
||||
border_radius=self.border_radius,
|
||||
)
|
||||
cv2.putText(
|
||||
img=scene,
|
||||
@@ -1098,6 +1109,48 @@ class LabelAnnotator:
|
||||
)
|
||||
return scene
|
||||
|
||||
@staticmethod
|
||||
def draw_rounded_rectangle(
|
||||
scene: np.ndarray,
|
||||
xyxy: Tuple[int, int, int, int],
|
||||
color: Tuple[int, int, int],
|
||||
border_radius: int,
|
||||
) -> np.ndarray:
|
||||
x1, y1, x2, y2 = xyxy
|
||||
width = x2 - x1
|
||||
height = y2 - y1
|
||||
|
||||
border_radius = min(border_radius, min(width, height) // 2)
|
||||
|
||||
rectangle_coordinates = [
|
||||
((x1 + border_radius, y1), (x2 - border_radius, y2)),
|
||||
((x1, y1 + border_radius), (x2, y2 - border_radius)),
|
||||
]
|
||||
circle_centers = [
|
||||
(x1 + border_radius, y1 + border_radius),
|
||||
(x2 - border_radius, y1 + border_radius),
|
||||
(x1 + border_radius, y2 - border_radius),
|
||||
(x2 - border_radius, y2 - border_radius),
|
||||
]
|
||||
|
||||
for coordinates in rectangle_coordinates:
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=coordinates[0],
|
||||
pt2=coordinates[1],
|
||||
color=color,
|
||||
thickness=-1,
|
||||
)
|
||||
for center in circle_centers:
|
||||
cv2.circle(
|
||||
img=scene,
|
||||
center=center,
|
||||
radius=border_radius,
|
||||
color=color,
|
||||
thickness=-1,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
class BlurAnnotator(BaseAnnotator):
|
||||
"""
|
||||
@@ -1839,3 +1892,148 @@ class PercentageBarAnnotator(BaseAnnotator):
|
||||
|
||||
if not all(0 <= value <= 1 for value in custom_values):
|
||||
raise ValueError("All values in custom_values must be between 0 and 1.")
|
||||
|
||||
|
||||
class CropAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing scaled up crops of detections on the scene.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
position: Position = Position.TOP_CENTER,
|
||||
scale_factor: int = 2,
|
||||
border_color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
border_thickness: int = 2,
|
||||
border_color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
position (Position): The anchor position for placing the cropped and scaled
|
||||
part of the detection in the scene.
|
||||
scale_factor (int): The factor by which to scale the cropped image part. A
|
||||
factor of 2, for example, would double the size of the cropped area,
|
||||
allowing for a closer view of the detection.
|
||||
border_color (Union[Color, ColorPalette]): The color or color palette to
|
||||
use for annotating border around the cropped area.
|
||||
border_thickness (int): The thickness of the border around the cropped area.
|
||||
border_color_lookup (ColorLookup): Strategy for mapping colors to
|
||||
annotations. Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.position: Position = position
|
||||
self.scale_factor: int = scale_factor
|
||||
self.border_color: Union[Color, ColorPalette] = border_color
|
||||
self.border_thickness: int = border_thickness
|
||||
self.border_color_lookup: ColorLookup = border_color_lookup
|
||||
|
||||
@scene_to_annotator_img_type
|
||||
def annotate(
|
||||
self,
|
||||
scene: ImageType,
|
||||
detections: Detections,
|
||||
custom_color_lookup: Optional[np.ndarray] = None,
|
||||
) -> ImageType:
|
||||
"""
|
||||
Annotates the provided scene with scaled and cropped parts of the image based
|
||||
on the provided detections. Each detection is cropped from the original scene
|
||||
and scaled according to the annotator's scale factor before being placed back
|
||||
onto the scene at the specified position.
|
||||
|
||||
|
||||
Args:
|
||||
scene (ImageType): The image where cropped detection will be placed.
|
||||
`ImageType` is a flexible type, accepting either `numpy.ndarray`
|
||||
or `PIL.Image.Image`.
|
||||
detections (Detections): Object detections to annotate.
|
||||
custom_color_lookup (Optional[np.ndarray]): Custom color lookup array.
|
||||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
image = ...
|
||||
detections = sv.Detections(...)
|
||||
|
||||
crop_annotator = sv.CropAnnotator()
|
||||
annotated_frame = crop_annotator.annotate(
|
||||
scene=image.copy(),
|
||||
detections=detections
|
||||
)
|
||||
```
|
||||
"""
|
||||
crops = [
|
||||
crop_image(image=scene, xyxy=xyxy) for xyxy in detections.xyxy.astype(int)
|
||||
]
|
||||
resized_crops = [
|
||||
resize_image(image=crop, scale_factor=self.scale_factor) for crop in crops
|
||||
]
|
||||
anchors = detections.get_anchors_coordinates(anchor=self.position).astype(int)
|
||||
|
||||
for idx, (resized_crop, anchor) in enumerate(zip(resized_crops, anchors)):
|
||||
crop_wh = resized_crop.shape[1], resized_crop.shape[0]
|
||||
(x1, y1), (x2, y2) = self.calculate_crop_coordinates(
|
||||
anchor=anchor, crop_wh=crop_wh, position=self.position
|
||||
)
|
||||
scene = place_image(scene=scene, image=resized_crop, anchor=(x1, y1))
|
||||
color = resolve_color(
|
||||
color=self.border_color,
|
||||
detections=detections,
|
||||
detection_idx=idx,
|
||||
color_lookup=self.border_color_lookup
|
||||
if custom_color_lookup is None
|
||||
else custom_color_lookup,
|
||||
)
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=(x1, y1),
|
||||
pt2=(x2, y2),
|
||||
color=color.as_bgr(),
|
||||
thickness=self.border_thickness,
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
@staticmethod
|
||||
def calculate_crop_coordinates(
|
||||
anchor: Tuple[int, int], crop_wh: Tuple[int, int], position: Position
|
||||
) -> Tuple[Tuple[int, int], Tuple[int, int]]:
|
||||
anchor_x, anchor_y = anchor
|
||||
width, height = crop_wh
|
||||
|
||||
if position == Position.TOP_LEFT:
|
||||
return (anchor_x - width, anchor_y - height), (anchor_x, anchor_y)
|
||||
elif position == Position.TOP_CENTER:
|
||||
return (
|
||||
(anchor_x - width // 2, anchor_y - height),
|
||||
(anchor_x + width // 2, anchor_y),
|
||||
)
|
||||
elif position == Position.TOP_RIGHT:
|
||||
return (anchor_x, anchor_y - height), (anchor_x + width, anchor_y)
|
||||
elif position == Position.CENTER_LEFT:
|
||||
return (
|
||||
(anchor_x - width, anchor_y - height // 2),
|
||||
(anchor_x, anchor_y + height // 2),
|
||||
)
|
||||
elif position == Position.CENTER or position == Position.CENTER_OF_MASS:
|
||||
return (
|
||||
(anchor_x - width // 2, anchor_y - height // 2),
|
||||
(anchor_x + width // 2, anchor_y + height // 2),
|
||||
)
|
||||
elif position == Position.CENTER_RIGHT:
|
||||
return (
|
||||
(anchor_x, anchor_y - height // 2),
|
||||
(anchor_x + width, anchor_y + height // 2),
|
||||
)
|
||||
elif position == Position.BOTTOM_LEFT:
|
||||
return (anchor_x - width, anchor_y), (anchor_x, anchor_y + height)
|
||||
elif position == Position.BOTTOM_CENTER:
|
||||
return (
|
||||
(anchor_x - width // 2, anchor_y),
|
||||
(anchor_x + width // 2, anchor_y + height),
|
||||
)
|
||||
elif position == Position.BOTTOM_RIGHT:
|
||||
return (anchor_x, anchor_y), (anchor_x + width, anchor_y + height)
|
||||
|
||||
@@ -14,6 +14,7 @@ from supervision.detection.utils import (
|
||||
get_data_item,
|
||||
is_data_equal,
|
||||
mask_non_max_suppression,
|
||||
mask_to_xyxy,
|
||||
merge_data,
|
||||
process_roboflow_result,
|
||||
validate_detections_fields,
|
||||
@@ -390,18 +391,30 @@ class Detections:
|
||||
@classmethod
|
||||
def from_transformers(cls, transformers_results: dict) -> Detections:
|
||||
"""
|
||||
Creates a Detections instance from object detection
|
||||
Creates a Detections instance from object detection or segmentation
|
||||
[transformer](https://github.com/huggingface/transformers) inference result.
|
||||
|
||||
Returns:
|
||||
Detections: A new Detections object.
|
||||
"""
|
||||
boxes = transformers_results.get("boxes")
|
||||
|
||||
return cls(
|
||||
xyxy=transformers_results["boxes"].cpu().numpy(),
|
||||
confidence=transformers_results["scores"].cpu().numpy(),
|
||||
class_id=transformers_results["labels"].cpu().numpy().astype(int),
|
||||
)
|
||||
# If the boxes key is in the transformers_results then we know it's an
|
||||
# object detection result. Else, we can assume it's a segmentation model
|
||||
if boxes:
|
||||
return cls(
|
||||
xyxy=transformers_results["boxes"].cpu().numpy(),
|
||||
confidence=transformers_results["scores"].cpu().numpy(),
|
||||
class_id=transformers_results["labels"].cpu().numpy().astype(int),
|
||||
)
|
||||
else:
|
||||
masks = transformers_results["masks"].cpu().numpy().astype(bool)
|
||||
return cls(
|
||||
xyxy=mask_to_xyxy(masks),
|
||||
mask=masks,
|
||||
confidence=transformers_results["scores"].cpu().numpy(),
|
||||
class_id=transformers_results["labels"].cpu().numpy().astype(int),
|
||||
)
|
||||
|
||||
@classmethod
|
||||
def from_detectron2(cls, detectron2_results) -> Detections:
|
||||
|
||||
@@ -42,7 +42,7 @@ class CSVSink:
|
||||
csv_sink = sv.CSVSink(<RESULT_CSV_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with csv_sink:
|
||||
with csv_sink as sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
|
||||
@@ -0,0 +1,142 @@
|
||||
from __future__ import annotations
|
||||
|
||||
import json
|
||||
import os
|
||||
from typing import Any, Dict, List, Optional
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
|
||||
|
||||
class JSONSink:
|
||||
"""
|
||||
A utility class for saving detection data to a JSON file. This class is designed to
|
||||
efficiently serialize detection objects into a JSON format, allowing for the
|
||||
inclusion of bounding box coordinates and additional attributes like `confidence`,
|
||||
`class_id`, and `tracker_id`.
|
||||
|
||||
!!! tip
|
||||
|
||||
JSONsink allow to pass custom data alongside the detection fields, providing
|
||||
flexibility for logging various types of information.
|
||||
|
||||
Args:
|
||||
file_name (str): The name of the JSON file where the detections will be stored.
|
||||
Defaults to 'output.json'.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO(<SOURCE_MODEL_PATH>)
|
||||
json_sink = sv.JSONSink(<RESULT_JSON_FILE_PATH>)
|
||||
frames_generator = sv.get_video_frames_generator(<SOURCE_VIDEO_PATH>)
|
||||
|
||||
with json_sink as sink:
|
||||
for frame in frames_generator:
|
||||
result = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(result)
|
||||
sink.append(detections, custom_data={'<CUSTOM_LABEL>':'<CUSTOM_DATA>'})
|
||||
```
|
||||
""" # noqa: E501 // docs
|
||||
|
||||
def __init__(self, file_name: str = "output.json") -> None:
|
||||
"""
|
||||
Initialize the JSONSink instance.
|
||||
|
||||
Args:
|
||||
file_name (str): The name of the JSON file.
|
||||
|
||||
Returns:
|
||||
None
|
||||
"""
|
||||
self.file_name = file_name
|
||||
self.file: Optional[open] = None
|
||||
self.data: List[Dict[str, Any]] = []
|
||||
|
||||
def __enter__(self) -> JSONSink:
|
||||
self.open()
|
||||
return self
|
||||
|
||||
def __exit__(
|
||||
self,
|
||||
exc_type: Optional[type],
|
||||
exc_val: Optional[Exception],
|
||||
exc_tb: Optional[Any],
|
||||
) -> None:
|
||||
self.write_and_close()
|
||||
|
||||
def open(self) -> None:
|
||||
"""
|
||||
Open the JSON file for writing.
|
||||
|
||||
Returns:
|
||||
None
|
||||
"""
|
||||
parent_directory = os.path.dirname(self.file_name)
|
||||
if parent_directory and not os.path.exists(parent_directory):
|
||||
os.makedirs(parent_directory)
|
||||
|
||||
self.file = open(self.file_name, "w")
|
||||
|
||||
def write_and_close(self) -> None:
|
||||
"""
|
||||
Write and close the JSON file.
|
||||
|
||||
Returns:
|
||||
None
|
||||
"""
|
||||
if self.file:
|
||||
json.dump(self.data, self.file, indent=4)
|
||||
self.file.close()
|
||||
|
||||
@staticmethod
|
||||
def parse_detection_data(
|
||||
detections: Detections, custom_data: Dict[str, Any] = None
|
||||
) -> List[Dict[str, Any]]:
|
||||
parsed_rows = []
|
||||
for i in range(len(detections.xyxy)):
|
||||
row = {
|
||||
"x_min": float(detections.xyxy[i][0]),
|
||||
"y_min": float(detections.xyxy[i][1]),
|
||||
"x_max": float(detections.xyxy[i][2]),
|
||||
"y_max": float(detections.xyxy[i][3]),
|
||||
"class_id": ""
|
||||
if detections.class_id is None
|
||||
else int(detections.class_id[i]),
|
||||
"confidence": ""
|
||||
if detections.confidence is None
|
||||
else float(detections.confidence[i]),
|
||||
"tracker_id": ""
|
||||
if detections.tracker_id is None
|
||||
else int(detections.tracker_id[i]),
|
||||
}
|
||||
|
||||
if hasattr(detections, "data"):
|
||||
for key, value in detections.data.items():
|
||||
row[key] = (
|
||||
str(value[i])
|
||||
if hasattr(value, "__getitem__") and value.ndim != 0
|
||||
else str(value)
|
||||
)
|
||||
|
||||
if custom_data:
|
||||
row.update(custom_data)
|
||||
parsed_rows.append(row)
|
||||
return parsed_rows
|
||||
|
||||
def append(
|
||||
self, detections: Detections, custom_data: Dict[str, Any] = None
|
||||
) -> None:
|
||||
"""
|
||||
Append detection data to the JSON file.
|
||||
|
||||
Args:
|
||||
detections (Detections): The detection data.
|
||||
custom_data (Dict[str, Any]): Custom data to include.
|
||||
|
||||
Returns:
|
||||
None
|
||||
"""
|
||||
parsed_rows = JSONSink.parse_detection_data(detections, custom_data)
|
||||
self.data.extend(parsed_rows)
|
||||
@@ -3,6 +3,7 @@ from typing import Iterable, Optional, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
import numpy.typing as npt
|
||||
|
||||
from supervision import Detections
|
||||
from supervision.detection.utils import clip_boxes, polygon_to_mask
|
||||
@@ -39,7 +40,7 @@ class PolygonZone:
|
||||
)
|
||||
def __init__(
|
||||
self,
|
||||
polygon: np.ndarray,
|
||||
polygon: npt.NDArray[np.int64],
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
triggering_anchors: Iterable[Position] = (Position.BOTTOM_CENTER,),
|
||||
):
|
||||
@@ -54,7 +55,7 @@ class PolygonZone:
|
||||
polygon=polygon, resolution_wh=(width + 1, height + 1)
|
||||
)
|
||||
|
||||
def trigger(self, detections: Detections) -> np.ndarray:
|
||||
def trigger(self, detections: Detections) -> npt.NDArray[np.bool_]:
|
||||
"""
|
||||
Determines if the detections are within the polygon zone.
|
||||
|
||||
@@ -78,13 +79,13 @@ class PolygonZone:
|
||||
]
|
||||
)
|
||||
|
||||
is_in_zone = (
|
||||
is_in_zone: npt.NDArray[np.bool_] = (
|
||||
self.mask[all_clipped_anchors[:, :, 1], all_clipped_anchors[:, :, 0]]
|
||||
.transpose()
|
||||
.astype(bool)
|
||||
)
|
||||
is_in_zone = np.all(is_in_zone, axis=1)
|
||||
|
||||
is_in_zone: npt.NDArray[np.bool_] = np.all(is_in_zone, axis=1)
|
||||
self.current_count = int(np.sum(is_in_zone))
|
||||
return is_in_zone.astype(bool)
|
||||
|
||||
|
||||
@@ -845,8 +845,15 @@ def get_data_item(
|
||||
elif isinstance(value, list):
|
||||
if isinstance(index, slice):
|
||||
subset_data[key] = value[index]
|
||||
elif isinstance(index, (list, np.ndarray)):
|
||||
elif isinstance(index, list):
|
||||
subset_data[key] = [value[i] for i in index]
|
||||
elif isinstance(index, np.ndarray):
|
||||
if index.dtype == bool:
|
||||
subset_data[key] = [
|
||||
value[i] for i, index_value in enumerate(index) if index_value
|
||||
]
|
||||
else:
|
||||
subset_data[key] = [value[i] for i in index]
|
||||
elif isinstance(index, int):
|
||||
subset_data[key] = [value[index]]
|
||||
else:
|
||||
|
||||
@@ -176,31 +176,31 @@ class Color:
|
||||
return self.b, self.g, self.r
|
||||
|
||||
@classproperty
|
||||
def WHITE(cls):
|
||||
def WHITE(cls) -> Color:
|
||||
return Color.from_hex("#FFFFFF")
|
||||
|
||||
@classproperty
|
||||
def BLACK(cls):
|
||||
def BLACK(cls) -> Color:
|
||||
return Color.from_hex("#000000")
|
||||
|
||||
@classproperty
|
||||
def RED(cls):
|
||||
def RED(cls) -> Color:
|
||||
return Color.from_hex("#FF0000")
|
||||
|
||||
@classproperty
|
||||
def GREEN(cls):
|
||||
def GREEN(cls) -> Color:
|
||||
return Color.from_hex("#00FF00")
|
||||
|
||||
@classproperty
|
||||
def BLUE(cls):
|
||||
def BLUE(cls) -> Color:
|
||||
return Color.from_hex("#0000FF")
|
||||
|
||||
@classproperty
|
||||
def YELLOW(cls):
|
||||
def YELLOW(cls) -> Color:
|
||||
return Color.from_hex("#FFFF00")
|
||||
|
||||
@classproperty
|
||||
def ROBOFLOW(cls):
|
||||
def ROBOFLOW(cls) -> Color:
|
||||
return Color.from_hex("#A351FB")
|
||||
|
||||
@classmethod
|
||||
|
||||
@@ -238,13 +238,13 @@ def draw_image(
|
||||
return scene
|
||||
|
||||
|
||||
def calculate_dynamic_text_scale(resolution_wh: Tuple[int, int]) -> float:
|
||||
def calculate_optimal_text_scale(resolution_wh: Tuple[int, int]) -> float:
|
||||
"""
|
||||
Calculate a dynamic font scale based on the resolution of an image.
|
||||
Calculate font scale based on the resolution of an image.
|
||||
|
||||
Parameters:
|
||||
resolution_wh (Tuple[int, int]): A tuple representing the width and height
|
||||
of the image.
|
||||
of the image.
|
||||
|
||||
Returns:
|
||||
float: The calculated font scale factor.
|
||||
@@ -252,25 +252,17 @@ def calculate_dynamic_text_scale(resolution_wh: Tuple[int, int]) -> float:
|
||||
return min(resolution_wh) * 1e-3
|
||||
|
||||
|
||||
def calculate_dynamic_line_thickness(resolution_wh: Tuple[int, int]) -> int:
|
||||
def calculate_optimal_line_thickness(resolution_wh: Tuple[int, int]) -> int:
|
||||
"""
|
||||
Calculate a dynamic line thickness based on the resolution of an image.
|
||||
Calculate line thickness based on the resolution of an image.
|
||||
|
||||
Parameters:
|
||||
resolution_wh (Tuple[int, int]): A tuple representing the width and height
|
||||
of the image.
|
||||
of the image.
|
||||
|
||||
Returns:
|
||||
int: The calculated line thickness in pixels.
|
||||
"""
|
||||
min_dimension = min(resolution_wh)
|
||||
if min_dimension < 480:
|
||||
if min(resolution_wh) < 1080:
|
||||
return 2
|
||||
if min_dimension < 720:
|
||||
return 2
|
||||
if min_dimension < 1080:
|
||||
return 2
|
||||
if min_dimension < 2160:
|
||||
return 4
|
||||
else:
|
||||
return 4
|
||||
return 4
|
||||
|
||||
@@ -836,10 +836,10 @@ class MeanAveragePrecision:
|
||||
precision = true_positives / (true_positives + false_positives)
|
||||
|
||||
for iou_level_idx in range(matches.shape[1]):
|
||||
average_precisions[
|
||||
class_idx, iou_level_idx
|
||||
] = MeanAveragePrecision.compute_average_precision(
|
||||
recall[:, iou_level_idx], precision[:, iou_level_idx]
|
||||
average_precisions[class_idx, iou_level_idx] = (
|
||||
MeanAveragePrecision.compute_average_precision(
|
||||
recall[:, iou_level_idx], precision[:, iou_level_idx]
|
||||
)
|
||||
)
|
||||
|
||||
return average_precisions
|
||||
|
||||
@@ -3,6 +3,7 @@ from typing import List, Tuple
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.detection.utils import box_iou_batch
|
||||
from supervision.tracker.byte_tracker import matching
|
||||
from supervision.tracker.byte_tracker.basetrack import BaseTrack, TrackState
|
||||
from supervision.tracker.byte_tracker.kalman_filter import KalmanFilter
|
||||
@@ -270,27 +271,28 @@ class ByteTrack:
|
||||
```
|
||||
"""
|
||||
|
||||
tracks = self.update_with_tensors(
|
||||
tensors=detections2boxes(detections=detections)
|
||||
)
|
||||
detections = Detections.empty()
|
||||
tensors = detections2boxes(detections=detections)
|
||||
tracks = self.update_with_tensors(tensors=tensors)
|
||||
|
||||
if len(tracks) > 0:
|
||||
detections.xyxy = np.array(
|
||||
[track.tlbr for track in tracks], dtype=np.float32
|
||||
)
|
||||
detections.class_id = np.array(
|
||||
[int(t.class_ids) for t in tracks], dtype=int
|
||||
)
|
||||
detections.tracker_id = np.array(
|
||||
[int(t.track_id) for t in tracks], dtype=int
|
||||
)
|
||||
detections.confidence = np.array(
|
||||
[t.score for t in tracks], dtype=np.float32
|
||||
)
|
||||
detection_bounding_boxes = np.asarray([det[:4] for det in tensors])
|
||||
track_bounding_boxes = np.asarray([track.tlbr for track in tracks])
|
||||
|
||||
ious = box_iou_batch(detection_bounding_boxes, track_bounding_boxes)
|
||||
|
||||
iou_costs = 1 - ious
|
||||
|
||||
matches, _, _ = matching.linear_assignment(iou_costs, 0.5)
|
||||
detections.tracker_id = np.full(len(detections), -1, dtype=int)
|
||||
for i_detection, i_track in matches:
|
||||
detections.tracker_id[i_detection] = int(tracks[i_track].track_id)
|
||||
|
||||
return detections[detections.tracker_id != -1]
|
||||
|
||||
else:
|
||||
detections.tracker_id = np.array([], dtype=int)
|
||||
|
||||
return detections
|
||||
return detections
|
||||
|
||||
def reset(self):
|
||||
"""
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
import os
|
||||
import shutil
|
||||
from typing import Optional
|
||||
from typing import Optional, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
@@ -32,8 +32,76 @@ def crop_image(image: np.ndarray, xyxy: np.ndarray) -> np.ndarray:
|
||||
|
||||
xyxy = np.round(xyxy).astype(int)
|
||||
x1, y1, x2, y2 = xyxy
|
||||
cropped_img = image[y1:y2, x1:x2]
|
||||
return cropped_img
|
||||
return image[y1:y2, x1:x2]
|
||||
|
||||
|
||||
def resize_image(image: np.ndarray, scale_factor: float) -> np.ndarray:
|
||||
"""
|
||||
Resizes an image by a given scale factor using cv2.INTER_LINEAR interpolation.
|
||||
|
||||
Args:
|
||||
image (np.ndarray): The input image to be resized.
|
||||
scale_factor (float): The factor by which the image will be scaled. Scale factor
|
||||
> 1.0 zooms in, < 1.0 zooms out.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The resized image.
|
||||
|
||||
Raises:
|
||||
ValueError: If the scale factor is non-positive.
|
||||
"""
|
||||
if scale_factor <= 0:
|
||||
raise ValueError("Scale factor must be positive.")
|
||||
|
||||
old_width, old_height = image.shape[1], image.shape[0]
|
||||
nwe_width = int(old_width * scale_factor)
|
||||
new_height = int(old_height * scale_factor)
|
||||
|
||||
return cv2.resize(image, (nwe_width, new_height), interpolation=cv2.INTER_LINEAR)
|
||||
|
||||
|
||||
def place_image(
|
||||
scene: np.ndarray, image: np.ndarray, anchor: Tuple[int, int]
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Places an image onto a scene at a given anchor point, handling cases where
|
||||
the image's position is partially or completely outside the scene's bounds.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The background scene onto which the image is placed.
|
||||
image (np.ndarray): The image to be placed onto the scene.
|
||||
anchor (Tuple[int, int]): The (x, y) coordinates in the scene where the
|
||||
top-left corner of the image will be placed.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The modified scene with the image placed at the anchor point,
|
||||
or unchanged if the image placement is completely outside the scene.
|
||||
"""
|
||||
scene_height, scene_width = scene.shape[:2]
|
||||
image_height, image_width = image.shape[:2]
|
||||
anchor_x, anchor_y = anchor
|
||||
|
||||
is_out_horizontally = anchor_x + image_width <= 0 or anchor_x >= scene_width
|
||||
is_out_vertically = anchor_y + image_height <= 0 or anchor_y >= scene_height
|
||||
|
||||
if is_out_horizontally or is_out_vertically:
|
||||
return scene
|
||||
|
||||
start_y = max(anchor_y, 0)
|
||||
start_x = max(anchor_x, 0)
|
||||
end_y = min(scene_height, anchor_y + image_height)
|
||||
end_x = min(scene_width, anchor_x + image_width)
|
||||
|
||||
crop_start_y = max(-anchor_y, 0)
|
||||
crop_start_x = max(-anchor_x, 0)
|
||||
crop_end_y = image_height - max((anchor_y + image_height) - scene_height, 0)
|
||||
crop_end_x = image_width - max((anchor_x + image_width) - scene_width, 0)
|
||||
|
||||
scene[start_y:end_y, start_x:end_x] = image[
|
||||
crop_start_y:crop_end_y, crop_start_x:crop_end_x
|
||||
]
|
||||
|
||||
return scene
|
||||
|
||||
|
||||
class ImageSink:
|
||||
@@ -85,7 +153,8 @@ class ImageSink:
|
||||
Save a given image in the target directory.
|
||||
|
||||
Args:
|
||||
image (np.ndarray): The image to be saved.
|
||||
image (np.ndarray): The image to be saved. The image must be in BGR color
|
||||
format.
|
||||
image_name (str, optional): The name to use for the saved image.
|
||||
If not provided, a name will be
|
||||
generated using the `image_name_pattern`.
|
||||
|
||||
@@ -105,6 +105,13 @@ class VideoSink:
|
||||
return self
|
||||
|
||||
def write_frame(self, frame: np.ndarray):
|
||||
"""
|
||||
Writes a single video frame to the target video file.
|
||||
|
||||
Args:
|
||||
frame (np.ndarray): The video frame to be written to the file. The frame
|
||||
must be in BGR color format.
|
||||
"""
|
||||
self.__writer.write(frame)
|
||||
|
||||
def __exit__(self, exc_type, exc_value, exc_traceback):
|
||||
|
||||
@@ -0,0 +1,249 @@
|
||||
import json
|
||||
import os
|
||||
from test.test_utils import mock_detections
|
||||
from typing import Any, Dict, List
|
||||
|
||||
import pytest
|
||||
|
||||
import supervision as sv
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"detections, custom_data, "
|
||||
"second_detections, second_custom_data, "
|
||||
"file_name, expected_result",
|
||||
[
|
||||
(
|
||||
mock_detections(
|
||||
xyxy=[[10, 20, 30, 40], [50, 60, 70, 80]],
|
||||
confidence=[0.7, 0.8],
|
||||
class_id=[0, 0],
|
||||
tracker_id=[0, 1],
|
||||
data={"class_name": ["person", "person"]},
|
||||
),
|
||||
{"frame_number": 42},
|
||||
mock_detections(
|
||||
xyxy=[[15, 25, 35, 45], [55, 65, 75, 85]],
|
||||
confidence=[0.6, 0.9],
|
||||
class_id=[1, 1],
|
||||
tracker_id=[2, 3],
|
||||
data={"class_name": ["car", "car"]},
|
||||
),
|
||||
{"frame_number": 43},
|
||||
"test_detections.json",
|
||||
[
|
||||
{
|
||||
"x_min": 10,
|
||||
"y_min": 20,
|
||||
"x_max": 30,
|
||||
"y_max": 40,
|
||||
"class_id": 0,
|
||||
"confidence": 0.699999988079071,
|
||||
"tracker_id": 0,
|
||||
"class_name": "person",
|
||||
"frame_number": 42,
|
||||
},
|
||||
{
|
||||
"x_min": 50,
|
||||
"y_min": 60,
|
||||
"x_max": 70,
|
||||
"y_max": 80,
|
||||
"class_id": 0,
|
||||
"confidence": 0.800000011920929,
|
||||
"tracker_id": 1,
|
||||
"class_name": "person",
|
||||
"frame_number": 42,
|
||||
},
|
||||
{
|
||||
"x_min": 15,
|
||||
"y_min": 25,
|
||||
"x_max": 35,
|
||||
"y_max": 45,
|
||||
"class_id": 1,
|
||||
"confidence": 0.6000000238418579,
|
||||
"tracker_id": 2,
|
||||
"class_name": "car",
|
||||
"frame_number": 43,
|
||||
},
|
||||
{
|
||||
"x_min": 55,
|
||||
"y_min": 65,
|
||||
"x_max": 75,
|
||||
"y_max": 85,
|
||||
"class_id": 1,
|
||||
"confidence": 0.8999999761581421,
|
||||
"tracker_id": 3,
|
||||
"class_name": "car",
|
||||
"frame_number": 43,
|
||||
},
|
||||
],
|
||||
), # Multiple detections
|
||||
(
|
||||
mock_detections(
|
||||
xyxy=[[60, 70, 80, 90], [100, 110, 120, 130]],
|
||||
tracker_id=[4, 5],
|
||||
data={"class_name": ["bike", "dog"]},
|
||||
),
|
||||
{"frame_number": 44},
|
||||
mock_detections(
|
||||
xyxy=[[65, 75, 85, 95], [105, 115, 125, 135]],
|
||||
confidence=[0.5, 0.4],
|
||||
data={"class_name": ["tree", "cat"]},
|
||||
),
|
||||
{"frame_number": 45},
|
||||
"test_detections_missing_fields.json",
|
||||
[
|
||||
{
|
||||
"x_min": 60,
|
||||
"y_min": 70,
|
||||
"x_max": 80,
|
||||
"y_max": 90,
|
||||
"class_id": "",
|
||||
"confidence": "",
|
||||
"tracker_id": 4,
|
||||
"class_name": "bike",
|
||||
"frame_number": 44,
|
||||
},
|
||||
{
|
||||
"x_min": 100,
|
||||
"y_min": 110,
|
||||
"x_max": 120,
|
||||
"y_max": 130,
|
||||
"class_id": "",
|
||||
"confidence": "",
|
||||
"tracker_id": 5,
|
||||
"class_name": "dog",
|
||||
"frame_number": 44,
|
||||
},
|
||||
{
|
||||
"x_min": 65,
|
||||
"y_min": 75,
|
||||
"x_max": 85,
|
||||
"y_max": 95,
|
||||
"class_id": "",
|
||||
"confidence": 0.5,
|
||||
"tracker_id": "",
|
||||
"class_name": "tree",
|
||||
"frame_number": 45,
|
||||
},
|
||||
{
|
||||
"x_min": 105,
|
||||
"y_min": 115,
|
||||
"x_max": 125,
|
||||
"y_max": 135,
|
||||
"class_id": "",
|
||||
"confidence": 0.4000000059604645,
|
||||
"tracker_id": "",
|
||||
"class_name": "cat",
|
||||
"frame_number": 45,
|
||||
},
|
||||
],
|
||||
), # Missing fields
|
||||
(
|
||||
mock_detections(
|
||||
xyxy=[[10, 11, 12, 13]],
|
||||
confidence=[0.95],
|
||||
data={"class_name": "unknown", "is_detected": True, "score": 1},
|
||||
),
|
||||
{"frame_number": 46},
|
||||
mock_detections(
|
||||
xyxy=[[14, 15, 16, 17]],
|
||||
data={"class_name": "artifact", "is_detected": False, "score": 0.85},
|
||||
),
|
||||
{"frame_number": 47},
|
||||
"test_detections_varied_data.json",
|
||||
[
|
||||
{
|
||||
"x_min": 10,
|
||||
"y_min": 11,
|
||||
"x_max": 12,
|
||||
"y_max": 13,
|
||||
"class_id": "",
|
||||
"confidence": 0.949999988079071,
|
||||
"tracker_id": "",
|
||||
"class_name": "unknown",
|
||||
"is_detected": "True",
|
||||
"score": "1",
|
||||
"frame_number": 46,
|
||||
},
|
||||
{
|
||||
"x_min": 14,
|
||||
"y_min": 15,
|
||||
"x_max": 16,
|
||||
"y_max": 17,
|
||||
"class_id": "",
|
||||
"confidence": "",
|
||||
"tracker_id": "",
|
||||
"class_name": "artifact",
|
||||
"is_detected": "False",
|
||||
"score": "0.85",
|
||||
"frame_number": 47,
|
||||
},
|
||||
],
|
||||
), # Inconsistent Data Types
|
||||
(
|
||||
mock_detections(
|
||||
xyxy=[[20, 21, 22, 23]],
|
||||
),
|
||||
{
|
||||
"metadata": {"sensor_id": 101, "location": "north"},
|
||||
"tags": ["urgent", "review"],
|
||||
},
|
||||
mock_detections(
|
||||
xyxy=[[14, 15, 16, 17]],
|
||||
),
|
||||
{
|
||||
"metadata": {"sensor_id": 104, "location": "west"},
|
||||
"tags": ["not-urgent", "done"],
|
||||
},
|
||||
"test_detections_complex_data.json",
|
||||
[
|
||||
{
|
||||
"x_min": 20,
|
||||
"y_min": 21,
|
||||
"x_max": 22,
|
||||
"y_max": 23,
|
||||
"class_id": "",
|
||||
"confidence": "",
|
||||
"tracker_id": "",
|
||||
"metadata": {"sensor_id": 101, "location": "north"},
|
||||
"tags": ["urgent", "review"],
|
||||
},
|
||||
{
|
||||
"x_min": 14,
|
||||
"y_min": 15,
|
||||
"x_max": 16,
|
||||
"y_max": 17,
|
||||
"class_id": "",
|
||||
"confidence": "",
|
||||
"tracker_id": "",
|
||||
"metadata": {"sensor_id": 104, "location": "west"},
|
||||
"tags": ["not-urgent", "done"],
|
||||
},
|
||||
],
|
||||
), # Complex Data
|
||||
],
|
||||
)
|
||||
def test_json_sink(
|
||||
detections: mock_detections,
|
||||
custom_data: Dict[str, Any],
|
||||
second_detections: mock_detections,
|
||||
second_custom_data: Dict[str, Any],
|
||||
file_name: str,
|
||||
expected_result: List[List[Any]],
|
||||
) -> None:
|
||||
with sv.JSONSink(file_name) as sink:
|
||||
sink.append(detections, custom_data)
|
||||
sink.append(second_detections, second_custom_data)
|
||||
|
||||
assert_json_equal(file_name, expected_result)
|
||||
|
||||
|
||||
def assert_json_equal(file_name, expected_rows):
|
||||
with open(file_name, "r") as file:
|
||||
data = json.load(file)
|
||||
assert (
|
||||
data == expected_rows
|
||||
), f"Data in JSON file didn't match expected output: {data} != {expected_rows}"
|
||||
|
||||
os.remove(file_name)
|
||||
@@ -63,7 +63,9 @@ FRAME_RESOLUTION = (300, 300)
|
||||
(
|
||||
DETECTIONS,
|
||||
sv.PolygonZone(
|
||||
POLYGON, FRAME_RESOLUTION, triggering_position=sv.Position.BOTTOM_CENTER
|
||||
POLYGON,
|
||||
FRAME_RESOLUTION,
|
||||
triggering_anchors=[sv.Position.BOTTOM_CENTER],
|
||||
),
|
||||
np.array(
|
||||
[False, False, True, True, True, True, False, False, False], dtype=bool
|
||||
|
||||
@@ -1045,7 +1045,7 @@ def test_merge_data(
|
||||
"test_1": [1],
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and list values
|
||||
), # data dict with a single list field and integer index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
@@ -1055,7 +1055,7 @@ def test_merge_data(
|
||||
"test_1": np.array([1]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and np.array values as 1D arrays
|
||||
), # data dict with a single np.array field and integer index
|
||||
(
|
||||
{
|
||||
"test_1": [1, 2, 3],
|
||||
@@ -1065,7 +1065,7 @@ def test_merge_data(
|
||||
"test_1": [1, 2],
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and list values
|
||||
), # data dict with a single list field and slice index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
@@ -1075,7 +1075,7 @@ def test_merge_data(
|
||||
"test_1": np.array([1, 2]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and np.array values as 1D arrays
|
||||
), # data dict with a single np.array field and slice index
|
||||
(
|
||||
{
|
||||
"test_1": [1, 2, 3],
|
||||
@@ -1085,7 +1085,7 @@ def test_merge_data(
|
||||
"test_1": [3],
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and list values
|
||||
), # data dict with a single list field and negative integer index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
@@ -1095,7 +1095,7 @@ def test_merge_data(
|
||||
"test_1": np.array([3]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and np.array values as 1D arrays
|
||||
), # data dict with a single np.array field and negative integer index
|
||||
(
|
||||
{
|
||||
"test_1": [1, 2, 3],
|
||||
@@ -1105,7 +1105,7 @@ def test_merge_data(
|
||||
"test_1": [1, 3],
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and list values
|
||||
), # data dict with a single list field and integer list index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
@@ -1115,7 +1115,7 @@ def test_merge_data(
|
||||
"test_1": np.array([1, 3]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and np.array values as 1D arrays
|
||||
), # data dict with a single np.array field and integer list index
|
||||
(
|
||||
{
|
||||
"test_1": [1, 2, 3],
|
||||
@@ -1125,7 +1125,7 @@ def test_merge_data(
|
||||
"test_1": [1, 3],
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # single data dict with a single field name and list values
|
||||
), # data dict with a single list field and integer np.array index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
@@ -1135,7 +1135,55 @@ def test_merge_data(
|
||||
"test_1": np.array([1, 3]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
),
|
||||
), # data dict with a single np.array field and integer np.array index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
},
|
||||
np.array([True, True, True]),
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # data dict with a single np.array field and all-true bool np.array index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
},
|
||||
np.array([False, False, False]),
|
||||
{
|
||||
"test_1": np.array([]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # data dict with a single np.array field and all-false bool np.array index
|
||||
(
|
||||
{
|
||||
"test_1": np.array([1, 2, 3]),
|
||||
},
|
||||
np.array([False, True, False]),
|
||||
{
|
||||
"test_1": np.array([2]),
|
||||
},
|
||||
DoesNotRaise(),
|
||||
), # data dict with a single np.array field and mixed bool np.array index
|
||||
(
|
||||
{"test_1": np.array([1, 2, 3]), "test_2": ["a", "b", "c"]},
|
||||
0,
|
||||
{"test_1": np.array([1]), "test_2": ["a"]},
|
||||
DoesNotRaise(),
|
||||
), # data dict with two fields and integer index
|
||||
(
|
||||
{"test_1": np.array([1, 2, 3]), "test_2": ["a", "b", "c"]},
|
||||
-1,
|
||||
{"test_1": np.array([3]), "test_2": ["c"]},
|
||||
DoesNotRaise(),
|
||||
), # data dict with two fields and negative integer index
|
||||
(
|
||||
{"test_1": np.array([1, 2, 3]), "test_2": ["a", "b", "c"]},
|
||||
np.array([False, True, False]),
|
||||
{"test_1": np.array([2]), "test_2": ["b"]},
|
||||
DoesNotRaise(),
|
||||
), # data dict with two fields and mixed bool np.array index
|
||||
],
|
||||
)
|
||||
def test_get_data_item(
|
||||
|
||||
Reference in New Issue
Block a user