Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 Piotr Skalski |
36ab9dcb8e | ||
|
SkalskiP
|
01d6c5386a | ||
|
SkalskiP
|
7a1863835b | ||
|
Piotr Skalski
|
fb66e57103 | ||
|
SkalskiP
|
b87e07a06b | ||
|
Piotr Skalski
|
ba79dba26e | ||
|
SkalskiP
|
721935144b | ||
|
SkalskiP
|
26ad007b7c | ||
|
pre-commit-ci[bot]
|
c46ff15143 | ||
|
SkalskiP
|
f73829e941 | ||
|
pre-commit-ci[bot]
|
bf5d8ac29c | ||
|
SkalskiP
|
84713239ee | ||
|
pre-commit-ci[bot]
|
8d9228f7fd | ||
|
SkalskiP
|
4400ae05eb | ||
|
SkalskiP
|
366d39db48 | ||
|
pre-commit-ci[bot]
|
a618b7c369 | ||
|
SkalskiP
|
f94a8cb9a1 | ||
|
Piotr Skalski
|
186727243f | ||
|
pre-commit-ci[bot]
|
7ea8e75a78 | ||
|
SkalskiP
|
27979cf756 | ||
|
Piotr Skalski
|
a8c1431392 | ||
|
SkalskiP
|
58c8620a6f | ||
|
pre-commit-ci[bot]
|
9468f00997 | ||
|
SkalskiP
|
55f5f6a97a | ||
|
pre-commit-ci[bot]
|
a530b2ba5e | ||
|
SkalskiP
|
7cbf16be8a | ||
|
Piotr Skalski
|
a112292ed0 | ||
|
Onuralp SEZER
|
a64f3ff178 | ||
|
Piotr Skalski
|
07fc5609da | ||
|
SkalskiP
|
39117f19c4 | ||
|
SkalskiP
|
cb5e9c0df0 | ||
|
pre-commit-ci[bot]
|
38b87d6098 | ||
|
SkalskiP
|
a31f964947 | ||
|
dependabot[bot]
|
38297f85a5 | ||
|
Onuralp SEZER
|
5cf91676f6 | ||
|
Onuralp SEZER
|
c3c934f8c1 | ||
|
SkalskiP
|
f46326b7e4 | ||
|
Piotr Skalski
|
679fee9f16 | ||
|
SkalskiP
|
4774ace3c2 | ||
|
Piotr Skalski
|
2e7ecdd418 | ||
|
Onuralp SEZER
|
918970e7d6 | ||
|
James Gallagher
|
7f2b62a5ce | ||
|
James Gallagher
|
9c10308abc | ||
|
James Gallagher
|
d53181bb97 | ||
|
pre-commit-ci[bot]
|
9d836faa8a | ||
|
James Gallagher
|
c46e0f5c97 | ||
|
dependabot[bot]
|
c322cf8001 | ||
|
James Gallagher
|
fa8f31931c | ||
|
James Gallagher
|
b4b332a0e2 | ||
|
James Gallagher
|
c438b16e74 | ||
|
James Gallagher
|
3490c3e670 | ||
|
abhishek7kalra
|
9f901bb61e | ||
|
Abhishek Kalra
|
ece7164ce6 | ||
|
Abhishek Kalra
|
e927a3c0a5 | ||
|
Abhishek Kalra
|
b1f85969a5 |
@@ -8,7 +8,7 @@ idna==3.4
|
||||
iniconfig==2.0.0
|
||||
kiwisolver==1.4.5
|
||||
matplotlib==3.5.0
|
||||
numpy==1.24.4
|
||||
numpy==1.21.2
|
||||
opencv-python==4.5.5.64
|
||||
packaging==23.2
|
||||
Pillow==10.1.0
|
||||
|
||||
@@ -34,7 +34,7 @@ Pip install the supervision package in a
|
||||
[**3.11>=Python>=3.8**](https://www.python.org/) environment.
|
||||
|
||||
```bash
|
||||
pip install supervision[desktop]
|
||||
pip install supervision
|
||||
```
|
||||
|
||||
Read more about desktop, headless, and local installation in our [guide](https://roboflow.github.io/supervision/).
|
||||
|
||||
+30
-5
@@ -40,7 +40,7 @@
|
||||
|
||||
</div>
|
||||
|
||||
=== "BoxMask"
|
||||
=== "Color"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
@@ -48,8 +48,8 @@
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> box_mask_annotator = sv.BoxMaskAnnotator()
|
||||
>>> annotated_frame = box_mask_annotator.annotate(
|
||||
>>> color_annotator = sv.ColorAnnotator()
|
||||
>>> annotated_frame = color_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
@@ -103,6 +103,27 @@
|
||||
|
||||
</div>
|
||||
|
||||
=== "Triangle"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> triangle_annotator = sv.TriangleAnnotator()
|
||||
>>> annotated_frame = triangle_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
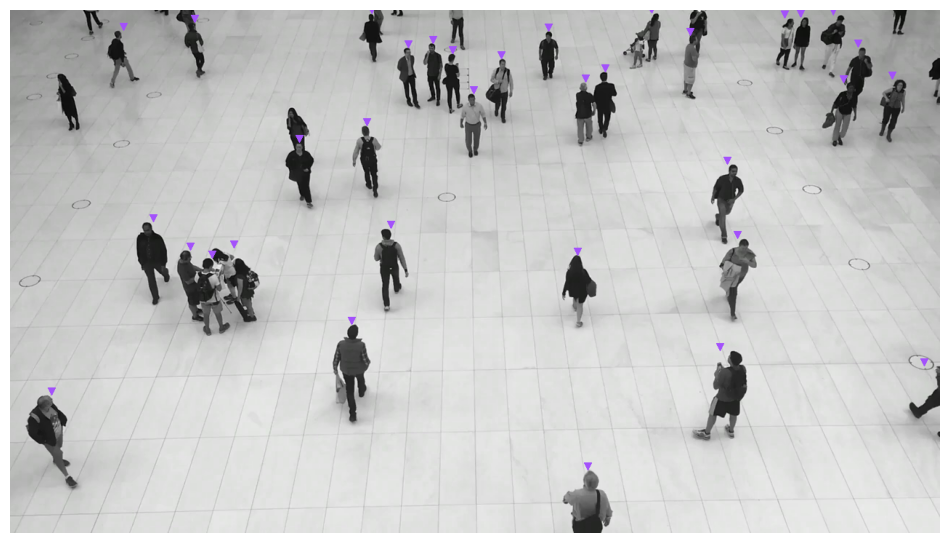{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
=== "Ellipse"
|
||||
|
||||
```python
|
||||
@@ -318,9 +339,9 @@
|
||||
|
||||
:::supervision.annotators.core.BoxCornerAnnotator
|
||||
|
||||
## BoxMaskAnnotator
|
||||
## ColorAnnotator
|
||||
|
||||
:::supervision.annotators.core.BoxMaskAnnotator
|
||||
:::supervision.annotators.core.ColorAnnotator
|
||||
|
||||
## CircleAnnotator
|
||||
|
||||
@@ -330,6 +351,10 @@
|
||||
|
||||
:::supervision.annotators.core.DotAnnotator
|
||||
|
||||
## TriangleAnnotator
|
||||
|
||||
:::supervision.annotators.core.TriangleAnnotator
|
||||
|
||||
## EllipseAnnotator
|
||||
|
||||
:::supervision.annotators.core.EllipseAnnotator
|
||||
|
||||
@@ -1,3 +1,56 @@
|
||||
### 0.17.0 <small>December 06, 2023</small>
|
||||
|
||||
- Added [#633](https://github.com/roboflow/supervision/pull/633): [`sv.PixelateAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.PixelateAnnotator) allowing to pixelate objects on images and videos.
|
||||
|
||||
- Added [#652](https://github.com/roboflow/supervision/pull/652): [`sv.TriangleAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.TriangleAnnotator) allowing to annotate images and videos with triangle markers.
|
||||
|
||||
- Added [#602](https://github.com/roboflow/supervision/pull/602): [`sv.PolygonAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.PolygonAnnotator) allowing to annotate images and videos with segmentation mask outline.
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> polygon_annotator = sv.PolygonAnnotator()
|
||||
>>> annotated_frame = polygon_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
- Added [#476](https://github.com/roboflow/supervision/pull/476): [`sv.assets`](https://supervision.roboflow.com/assets/) allowing download of video files that you can use in your demos.
|
||||
|
||||
```python
|
||||
>>> from supervision.assets import download_assets, VideoAssets
|
||||
>>> download_assets(VideoAssets.VEHICLES)
|
||||
"vehicles.mp4"
|
||||
```
|
||||
|
||||
- Added [#605](https://github.com/roboflow/supervision/pull/605): [`Position.CENTER_OF_MASS`](https://supervision.roboflow.com/geometry/core/#position) allowing to place labels in center of mass of segmentation masks.
|
||||
|
||||
- Added [#651](https://github.com/roboflow/supervision/pull/651): [`sv.scale_boxes`](https://supervision.roboflow.com/detection/utils/#supervision.detection.utils.scale_boxes) allowing to scale [`sv.Detections.xyxy`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections) values.
|
||||
|
||||
- Added [#637](https://github.com/roboflow/supervision/pull/637): [`sv.calculate_dynamic_text_scale`](https://supervision.roboflow.com/draw/utils/#supervision.draw.utils.calculate_dynamic_text_scale) and [`sv.calculate_dynamic_line_thickness`](https://supervision.roboflow.com/draw/utils/#supervision.draw.utils.calculate_dynamic_line_thickness) allowing text scale and line thickness to match image resolution.
|
||||
|
||||
- Added [#620](https://github.com/roboflow/supervision/pull/620): [`sv.Color.as_hex`](https://supervision.roboflow.com/draw/color/#supervision.draw.color.Color.as_hex) allowing to extract color value in HEX format.
|
||||
|
||||
- Added [#572](https://github.com/roboflow/supervision/pull/572): [`sv.Classifications.from_timm`](https://supervision.roboflow.com/classification/core/#supervision.classification.core.Classifications.from_timm) allowing to load classification result from [timm](https://huggingface.co/docs/hub/timm) models.
|
||||
|
||||
- Added [#478](https://github.com/roboflow/supervision/pull/478): [`sv.Classifications.from_clip`](https://supervision.roboflow.com/classification/core/#supervision.classification.core.Classifications.from_clip) allowing to load classification result from [clip](https://github.com/openai/clip) model.
|
||||
|
||||
- Added [#571](https://github.com/roboflow/supervision/pull/571): [`sv.Detections.from_azure_analyze_image`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_azure_analyze_image) allowing to load detection results from [Azure Image Analysis](https://learn.microsoft.com/en-us/azure/ai-services/computer-vision/concept-object-detection-40).
|
||||
|
||||
- Changed [#646](https://github.com/roboflow/supervision/pull/646): `sv.BoxMaskAnnotator` renaming it to [`sv.ColorAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.ColorAnnotator).
|
||||
|
||||
- Changed [#606](https://github.com/roboflow/supervision/pull/606): [`sv.MaskAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.MaskAnnotator) to make it **5x faster**.
|
||||
|
||||
- Fixed [#584](https://github.com/roboflow/supervision/pull/584): [`sv.DetectionDataset.from_yolo`](https://supervision.roboflow.com/datasets/#supervision.dataset.core.DetectionDataset.from_yolo) to ignore empty lines in annotation files.
|
||||
|
||||
- Fixed [#555](https://github.com/roboflow/supervision/pull/555): [`sv.BlurAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BlurAnnotator) to trim negative coordinates before bluring detections.
|
||||
|
||||
- Fixed [#511](https://github.com/roboflow/supervision/pull/511): [`sv.TraceAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.TraceAnnotator) to respect trace position.
|
||||
|
||||
### 0.16.0 <small>October 19, 2023</small>
|
||||
|
||||
- Added [#422](https://github.com/roboflow/supervision/pull/422): [`sv.BoxMaskAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BoxMaskAnnotator) allowing to annotate images and videos with mox masks.
|
||||
|
||||
@@ -25,3 +25,11 @@
|
||||
## filter_polygons_by_area
|
||||
|
||||
:::supervision.detection.utils.filter_polygons_by_area
|
||||
|
||||
## move_boxes
|
||||
|
||||
:::supervision.detection.utils.move_boxes
|
||||
|
||||
## scale_boxes
|
||||
|
||||
:::supervision.detection.utils.scale_boxes
|
||||
|
||||
Generated
+42
-22
@@ -1630,6 +1630,16 @@ files = [
|
||||
{file = "MarkupSafe-2.1.3-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:5bbe06f8eeafd38e5d0a4894ffec89378b6c6a625ff57e3028921f8ff59318ac"},
|
||||
{file = "MarkupSafe-2.1.3-cp311-cp311-win32.whl", hash = "sha256:dd15ff04ffd7e05ffcb7fe79f1b98041b8ea30ae9234aed2a9168b5797c3effb"},
|
||||
{file = "MarkupSafe-2.1.3-cp311-cp311-win_amd64.whl", hash = "sha256:134da1eca9ec0ae528110ccc9e48041e0828d79f24121a1a146161103c76e686"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-macosx_10_9_universal2.whl", hash = "sha256:f698de3fd0c4e6972b92290a45bd9b1536bffe8c6759c62471efaa8acb4c37bc"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:aa57bd9cf8ae831a362185ee444e15a93ecb2e344c8e52e4d721ea3ab6ef1823"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:ffcc3f7c66b5f5b7931a5aa68fc9cecc51e685ef90282f4a82f0f5e9b704ad11"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:47d4f1c5f80fc62fdd7777d0d40a2e9dda0a05883ab11374334f6c4de38adffd"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-manylinux_2_5_i686.manylinux1_i686.manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:1f67c7038d560d92149c060157d623c542173016c4babc0c1913cca0564b9939"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-musllinux_1_1_aarch64.whl", hash = "sha256:9aad3c1755095ce347e26488214ef77e0485a3c34a50c5a5e2471dff60b9dd9c"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-musllinux_1_1_i686.whl", hash = "sha256:14ff806850827afd6b07a5f32bd917fb7f45b046ba40c57abdb636674a8b559c"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:8f9293864fe09b8149f0cc42ce56e3f0e54de883a9de90cd427f191c346eb2e1"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-win32.whl", hash = "sha256:715d3562f79d540f251b99ebd6d8baa547118974341db04f5ad06d5ea3eb8007"},
|
||||
{file = "MarkupSafe-2.1.3-cp312-cp312-win_amd64.whl", hash = "sha256:1b8dd8c3fd14349433c79fa8abeb573a55fc0fdd769133baac1f5e07abf54aeb"},
|
||||
{file = "MarkupSafe-2.1.3-cp37-cp37m-macosx_10_9_x86_64.whl", hash = "sha256:8e254ae696c88d98da6555f5ace2279cf7cd5b3f52be2b5cf97feafe883b58d2"},
|
||||
{file = "MarkupSafe-2.1.3-cp37-cp37m-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:cb0932dc158471523c9637e807d9bfb93e06a95cbf010f1a38b98623b929ef2b"},
|
||||
{file = "MarkupSafe-2.1.3-cp37-cp37m-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:9402b03f1a1b4dc4c19845e5c749e3ab82d5078d16a2a4c2cd2df62d57bb0707"},
|
||||
@@ -2775,6 +2785,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:69b023b2b4daa7548bcfbd4aa3da05b3a74b772db9e23b982788168117739938"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:81e0b275a9ecc9c0c0c07b4b90ba548307583c125f54d5b6946cfee6360c733d"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:ba336e390cd8e4d1739f42dfe9bb83a3cc2e80f567d8805e11b46f4a943f5515"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-musllinux_1_1_x86_64.whl", hash = "sha256:326c013efe8048858a6d312ddd31d56e468118ad4cdeda36c719bf5bb6192290"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-win32.whl", hash = "sha256:bd4af7373a854424dabd882decdc5579653d7868b8fb26dc7d0e99f823aa5924"},
|
||||
{file = "PyYAML-6.0.1-cp310-cp310-win_amd64.whl", hash = "sha256:fd1592b3fdf65fff2ad0004b5e363300ef59ced41c2e6b3a99d4089fa8c5435d"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-macosx_10_9_x86_64.whl", hash = "sha256:6965a7bc3cf88e5a1c3bd2e0b5c22f8d677dc88a455344035f03399034eb3007"},
|
||||
@@ -2782,8 +2793,15 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:42f8152b8dbc4fe7d96729ec2b99c7097d656dc1213a3229ca5383f973a5ed6d"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:062582fca9fabdd2c8b54a3ef1c978d786e0f6b3a1510e0ac93ef59e0ddae2bc"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:d2b04aac4d386b172d5b9692e2d2da8de7bfb6c387fa4f801fbf6fb2e6ba4673"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-musllinux_1_1_x86_64.whl", hash = "sha256:e7d73685e87afe9f3b36c799222440d6cf362062f78be1013661b00c5c6f678b"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-win32.whl", hash = "sha256:1635fd110e8d85d55237ab316b5b011de701ea0f29d07611174a1b42f1444741"},
|
||||
{file = "PyYAML-6.0.1-cp311-cp311-win_amd64.whl", hash = "sha256:bf07ee2fef7014951eeb99f56f39c9bb4af143d8aa3c21b1677805985307da34"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-macosx_10_9_x86_64.whl", hash = "sha256:855fb52b0dc35af121542a76b9a84f8d1cd886ea97c84703eaa6d88e37a2ad28"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-macosx_11_0_arm64.whl", hash = "sha256:40df9b996c2b73138957fe23a16a4f0ba614f4c0efce1e9406a184b6d07fa3a9"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:6c22bec3fbe2524cde73d7ada88f6566758a8f7227bfbf93a408a9d86bcc12a0"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-musllinux_1_1_x86_64.whl", hash = "sha256:8d4e9c88387b0f5c7d5f281e55304de64cf7f9c0021a3525bd3b1c542da3b0e4"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-win32.whl", hash = "sha256:d483d2cdf104e7c9fa60c544d92981f12ad66a457afae824d146093b8c294c54"},
|
||||
{file = "PyYAML-6.0.1-cp312-cp312-win_amd64.whl", hash = "sha256:0d3304d8c0adc42be59c5f8a4d9e3d7379e6955ad754aa9d6ab7a398b59dd1df"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-macosx_10_9_x86_64.whl", hash = "sha256:50550eb667afee136e9a77d6dc71ae76a44df8b3e51e41b77f6de2932bfe0f47"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:1fe35611261b29bd1de0070f0b2f47cb6ff71fa6595c077e42bd0c419fa27b98"},
|
||||
{file = "PyYAML-6.0.1-cp36-cp36m-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:704219a11b772aea0d8ecd7058d0082713c3562b4e271b849ad7dc4a5c90c13c"},
|
||||
@@ -2800,6 +2818,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:a0cd17c15d3bb3fa06978b4e8958dcdc6e0174ccea823003a106c7d4d7899ac5"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:28c119d996beec18c05208a8bd78cbe4007878c6dd15091efb73a30e90539696"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:7e07cbde391ba96ab58e532ff4803f79c4129397514e1413a7dc761ccd755735"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-musllinux_1_1_x86_64.whl", hash = "sha256:49a183be227561de579b4a36efbb21b3eab9651dd81b1858589f796549873dd6"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-win32.whl", hash = "sha256:184c5108a2aca3c5b3d3bf9395d50893a7ab82a38004c8f61c258d4428e80206"},
|
||||
{file = "PyYAML-6.0.1-cp38-cp38-win_amd64.whl", hash = "sha256:1e2722cc9fbb45d9b87631ac70924c11d3a401b2d7f410cc0e3bbf249f2dca62"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-macosx_10_9_x86_64.whl", hash = "sha256:9eb6caa9a297fc2c2fb8862bc5370d0303ddba53ba97e71f08023b6cd73d16a8"},
|
||||
@@ -2807,6 +2826,7 @@ files = [
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:5773183b6446b2c99bb77e77595dd486303b4faab2b086e7b17bc6bef28865f6"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:b786eecbdf8499b9ca1d697215862083bd6d2a99965554781d0d8d1ad31e13a0"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:bc1bf2925a1ecd43da378f4db9e4f799775d6367bdb94671027b73b393a7c42c"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-musllinux_1_1_x86_64.whl", hash = "sha256:04ac92ad1925b2cff1db0cfebffb6ffc43457495c9b3c39d3fcae417d7125dc5"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-win32.whl", hash = "sha256:faca3bdcf85b2fc05d06ff3fbc1f83e1391b3e724afa3feba7d13eeab355484c"},
|
||||
{file = "PyYAML-6.0.1-cp39-cp39-win_amd64.whl", hash = "sha256:510c9deebc5c0225e8c96813043e62b680ba2f9c50a08d3724c7f28a747d1486"},
|
||||
{file = "PyYAML-6.0.1.tar.gz", hash = "sha256:bfdf460b1736c775f2ba9f6a92bca30bc2095067b8a9d77876d1fad6cc3b4a43"},
|
||||
@@ -3265,28 +3285,28 @@ files = [
|
||||
|
||||
[[package]]
|
||||
name = "ruff"
|
||||
version = "0.1.6"
|
||||
version = "0.1.7"
|
||||
description = "An extremely fast Python linter and code formatter, written in Rust."
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "ruff-0.1.6-py3-none-macosx_10_12_x86_64.macosx_11_0_arm64.macosx_10_12_universal2.whl", hash = "sha256:88b8cdf6abf98130991cbc9f6438f35f6e8d41a02622cc5ee130a02a0ed28703"},
|
||||
{file = "ruff-0.1.6-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:5c549ed437680b6105a1299d2cd30e4964211606eeb48a0ff7a93ef70b902248"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:1cf5f701062e294f2167e66d11b092bba7af6a057668ed618a9253e1e90cfd76"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:05991ee20d4ac4bb78385360c684e4b417edd971030ab12a4fbd075ff535050e"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:87455a0c1f739b3c069e2f4c43b66479a54dea0276dd5d4d67b091265f6fd1dc"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:683aa5bdda5a48cb8266fcde8eea2a6af4e5700a392c56ea5fb5f0d4bfdc0240"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:137852105586dcbf80c1717facb6781555c4e99f520c9c827bd414fac67ddfb6"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:bd98138a98d48a1c36c394fd6b84cd943ac92a08278aa8ac8c0fdefcf7138f35"},
|
||||
{file = "ruff-0.1.6-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:3a0cd909d25f227ac5c36d4e7e681577275fb74ba3b11d288aff7ec47e3ae745"},
|
||||
{file = "ruff-0.1.6-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:e8fd1c62a47aa88a02707b5dd20c5ff20d035d634aa74826b42a1da77861b5ff"},
|
||||
{file = "ruff-0.1.6-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:fd89b45d374935829134a082617954120d7a1470a9f0ec0e7f3ead983edc48cc"},
|
||||
{file = "ruff-0.1.6-py3-none-musllinux_1_2_i686.whl", hash = "sha256:491262006e92f825b145cd1e52948073c56560243b55fb3b4ecb142f6f0e9543"},
|
||||
{file = "ruff-0.1.6-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:ea284789861b8b5ca9d5443591a92a397ac183d4351882ab52f6296b4fdd5462"},
|
||||
{file = "ruff-0.1.6-py3-none-win32.whl", hash = "sha256:1610e14750826dfc207ccbcdd7331b6bd285607d4181df9c1c6ae26646d6848a"},
|
||||
{file = "ruff-0.1.6-py3-none-win_amd64.whl", hash = "sha256:4558b3e178145491e9bc3b2ee3c4b42f19d19384eaa5c59d10acf6e8f8b57e33"},
|
||||
{file = "ruff-0.1.6-py3-none-win_arm64.whl", hash = "sha256:03910e81df0d8db0e30050725a5802441c2022ea3ae4fe0609b76081731accbc"},
|
||||
{file = "ruff-0.1.6.tar.gz", hash = "sha256:1b09f29b16c6ead5ea6b097ef2764b42372aebe363722f1605ecbcd2b9207184"},
|
||||
{file = "ruff-0.1.7-py3-none-macosx_10_12_x86_64.macosx_11_0_arm64.macosx_10_12_universal2.whl", hash = "sha256:7f80496854fdc65b6659c271d2c26e90d4d401e6a4a31908e7e334fab4645aac"},
|
||||
{file = "ruff-0.1.7-py3-none-macosx_10_12_x86_64.whl", hash = "sha256:1ea109bdb23c2a4413f397ebd8ac32cb498bee234d4191ae1a310af760e5d287"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_aarch64.manylinux2014_aarch64.whl", hash = "sha256:8b0c2de9dd9daf5e07624c24add25c3a490dbf74b0e9bca4145c632457b3b42a"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_armv7l.manylinux2014_armv7l.whl", hash = "sha256:69a4bed13bc1d5dabf3902522b5a2aadfebe28226c6269694283c3b0cecb45fd"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_i686.manylinux2014_i686.whl", hash = "sha256:de02ca331f2143195a712983a57137c5ec0f10acc4aa81f7c1f86519e52b92a1"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_ppc64.manylinux2014_ppc64.whl", hash = "sha256:45b38c3f8788a65e6a2cab02e0f7adfa88872696839d9882c13b7e2f35d64c5f"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_ppc64le.manylinux2014_ppc64le.whl", hash = "sha256:6c64cb67b2025b1ac6d58e5ffca8f7b3f7fd921f35e78198411237e4f0db8e73"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_s390x.manylinux2014_s390x.whl", hash = "sha256:9dcc6bb2f4df59cb5b4b40ff14be7d57012179d69c6565c1da0d1f013d29951b"},
|
||||
{file = "ruff-0.1.7-py3-none-manylinux_2_17_x86_64.manylinux2014_x86_64.whl", hash = "sha256:df2bb4bb6bbe921f6b4f5b6fdd8d8468c940731cb9406f274ae8c5ed7a78c478"},
|
||||
{file = "ruff-0.1.7-py3-none-musllinux_1_2_aarch64.whl", hash = "sha256:276a89bcb149b3d8c1b11d91aa81898fe698900ed553a08129b38d9d6570e717"},
|
||||
{file = "ruff-0.1.7-py3-none-musllinux_1_2_armv7l.whl", hash = "sha256:90c958fe950735041f1c80d21b42184f1072cc3975d05e736e8d66fc377119ea"},
|
||||
{file = "ruff-0.1.7-py3-none-musllinux_1_2_i686.whl", hash = "sha256:6b05e3b123f93bb4146a761b7a7d57af8cb7384ccb2502d29d736eaade0db519"},
|
||||
{file = "ruff-0.1.7-py3-none-musllinux_1_2_x86_64.whl", hash = "sha256:290ecab680dce94affebefe0bbca2322a6277e83d4f29234627e0f8f6b4fa9ce"},
|
||||
{file = "ruff-0.1.7-py3-none-win32.whl", hash = "sha256:416dfd0bd45d1a2baa3b1b07b1b9758e7d993c256d3e51dc6e03a5e7901c7d80"},
|
||||
{file = "ruff-0.1.7-py3-none-win_amd64.whl", hash = "sha256:4af95fd1d3b001fc41325064336db36e3d27d2004cdb6d21fd617d45a172dd96"},
|
||||
{file = "ruff-0.1.7-py3-none-win_arm64.whl", hash = "sha256:0683b7bfbb95e6df3c7c04fe9d78f631f8e8ba4868dfc932d43d690698057e2e"},
|
||||
{file = "ruff-0.1.7.tar.gz", hash = "sha256:dffd699d07abf54833e5f6cc50b85a6ff043715da8788c4a79bcd4ab4734d306"},
|
||||
]
|
||||
|
||||
[[package]]
|
||||
@@ -3741,13 +3761,13 @@ test = ["websockets"]
|
||||
|
||||
[[package]]
|
||||
name = "wheel"
|
||||
version = "0.41.3"
|
||||
version = "0.42.0"
|
||||
description = "A built-package format for Python"
|
||||
optional = false
|
||||
python-versions = ">=3.7"
|
||||
files = [
|
||||
{file = "wheel-0.41.3-py3-none-any.whl", hash = "sha256:488609bc63a29322326e05560731bf7bfea8e48ad646e1f5e40d366607de0942"},
|
||||
{file = "wheel-0.41.3.tar.gz", hash = "sha256:4d4987ce51a49370ea65c0bfd2234e8ce80a12780820d9dc462597a6e60d0841"},
|
||||
{file = "wheel-0.42.0-py3-none-any.whl", hash = "sha256:177f9c9b0d45c47873b619f5b650346d632cdc35fb5e4d25058e09c9e581433d"},
|
||||
{file = "wheel-0.42.0.tar.gz", hash = "sha256:c45be39f7882c9d34243236f2d63cbd58039e360f85d0913425fbd7ceea617a8"},
|
||||
]
|
||||
|
||||
[package.extras]
|
||||
@@ -3775,4 +3795,4 @@ desktop = ["opencv-python"]
|
||||
[metadata]
|
||||
lock-version = "2.0"
|
||||
python-versions = ">=3.8,<3.12.0"
|
||||
content-hash = "abbd8c3b0bbed2349aa2ba8f4a822ab44d1092ea8b60118dc83fe11737e4ca12"
|
||||
content-hash = "62ad5b29a089dde783bbbe3f0df6ed314c602f7ae329bb2623f52b61d5d83e37"
|
||||
|
||||
+6
-6
@@ -1,6 +1,6 @@
|
||||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.17.0rc7"
|
||||
version = "0.17.0"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
@@ -36,10 +36,10 @@ classifiers=[
|
||||
|
||||
[tool.poetry.dependencies]
|
||||
python = ">=3.8,<3.12.0"
|
||||
numpy = ">=1.24.0,>=1.26.1"
|
||||
matplotlib = ">=3.5.0,>=3.8.1"
|
||||
numpy = ">=1.21.2"
|
||||
matplotlib = ">=3.5.0"
|
||||
pyyaml = ">=5.3,<=6.0.1"
|
||||
pillow = ">=9.4,<=10.1.0"
|
||||
pillow = ">=9.4"
|
||||
opencv-python = { version = ">=4.5.5.64,<=4.8.1.78", optional = true }
|
||||
opencv-python-headless = ">=4.5.5.64,<=4.8.1.78"
|
||||
scipy = ">=1.9.0,<=2.0.0"
|
||||
@@ -54,10 +54,10 @@ assets = ["requests","tqdm"]
|
||||
[tool.poetry.group.dev.dependencies]
|
||||
twine = "^4.0.2"
|
||||
pytest = "^7.2.2"
|
||||
wheel = ">=0.40,<0.42"
|
||||
wheel = ">=0.40,<0.43"
|
||||
notebook = ">=6.5.3,<8.0.0"
|
||||
build = ">=0.10,<1.1"
|
||||
ruff = ">=0.0.280,<0.1.7"
|
||||
ruff = ">=0.0.280,<0.1.8"
|
||||
isort = "^5.12.0"
|
||||
black = "^23.7.0"
|
||||
mypy = "^1.4.1"
|
||||
|
||||
@@ -10,8 +10,8 @@ from supervision.annotators.core import (
|
||||
BlurAnnotator,
|
||||
BoundingBoxAnnotator,
|
||||
BoxCornerAnnotator,
|
||||
BoxMaskAnnotator,
|
||||
CircleAnnotator,
|
||||
ColorAnnotator,
|
||||
DotAnnotator,
|
||||
EllipseAnnotator,
|
||||
HaloAnnotator,
|
||||
@@ -21,6 +21,7 @@ from supervision.annotators.core import (
|
||||
PixelateAnnotator,
|
||||
PolygonAnnotator,
|
||||
TraceAnnotator,
|
||||
TriangleAnnotator,
|
||||
)
|
||||
from supervision.annotators.utils import ColorLookup
|
||||
from supervision.classification.core import Classifications
|
||||
@@ -40,9 +41,11 @@ from supervision.detection.utils import (
|
||||
filter_polygons_by_area,
|
||||
mask_to_polygons,
|
||||
mask_to_xyxy,
|
||||
move_boxes,
|
||||
non_max_suppression,
|
||||
polygon_to_mask,
|
||||
polygon_to_xyxy,
|
||||
scale_boxes,
|
||||
)
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.draw.utils import (
|
||||
|
||||
@@ -260,7 +260,7 @@ class PolygonAnnotator(BaseAnnotator):
|
||||
return scene
|
||||
|
||||
|
||||
class BoxMaskAnnotator(BaseAnnotator):
|
||||
class ColorAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing box masks on an image using provided detections.
|
||||
"""
|
||||
@@ -308,8 +308,8 @@ class BoxMaskAnnotator(BaseAnnotator):
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> box_mask_annotator = sv.BoxMaskAnnotator()
|
||||
>>> annotated_frame = box_mask_annotator.annotate(
|
||||
>>> color_annotator = sv.ColorAnnotator()
|
||||
>>> annotated_frame = color_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
@@ -1030,8 +1030,7 @@ class TraceAnnotator:
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.position = position
|
||||
self.trace = Trace(max_size=trace_length)
|
||||
self.trace = Trace(max_size=trace_length, anchor=position)
|
||||
self.thickness = thickness
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
@@ -1263,3 +1262,93 @@ class PixelateAnnotator(BaseAnnotator):
|
||||
scene[y1:y2, x1:x2] = scaled_down_roi
|
||||
|
||||
return scene
|
||||
|
||||
|
||||
class TriangleAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing triangle markers on an image at specific coordinates based on
|
||||
provided detections.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
base: int = 10,
|
||||
height: int = 10,
|
||||
position: Position = Position.TOP_CENTER,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, ColorPalette]): The color or color palette to use for
|
||||
annotating detections.
|
||||
base (int): The base width of the triangle.
|
||||
height (int): The height of the triangle.
|
||||
position (Position): The anchor position for placing the triangle.
|
||||
color_lookup (ColorLookup): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.base: int = base
|
||||
self.height: int = height
|
||||
self.position: Position = position
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
def annotate(
|
||||
self,
|
||||
scene: np.ndarray,
|
||||
detections: Detections,
|
||||
custom_color_lookup: Optional[np.ndarray] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Annotates the given scene with triangles based on the provided detections.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image where triangles will be drawn.
|
||||
detections (Detections): Object detections to annotate.
|
||||
custom_color_lookup (Optional[np.ndarray]): Custom color lookup array.
|
||||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> triangle_annotator = sv.TriangleAnnotator()
|
||||
>>> annotated_frame = triangle_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
xy = detections.get_anchors_coordinates(anchor=self.position)
|
||||
for detection_idx in range(len(detections)):
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
detections=detections,
|
||||
detection_idx=detection_idx,
|
||||
color_lookup=self.color_lookup
|
||||
if custom_color_lookup is None
|
||||
else custom_color_lookup,
|
||||
)
|
||||
tip_x, tip_y = int(xy[detection_idx, 0]), int(xy[detection_idx, 1])
|
||||
vertices = np.array(
|
||||
[
|
||||
[tip_x - self.base // 2, tip_y - self.height],
|
||||
[tip_x + self.base // 2, tip_y - self.height],
|
||||
[tip_x, tip_y],
|
||||
],
|
||||
np.int32,
|
||||
)
|
||||
|
||||
cv2.fillPoly(scene, [vertices], color.as_bgr())
|
||||
|
||||
return scene
|
||||
|
||||
@@ -1,7 +1,7 @@
|
||||
from __future__ import annotations
|
||||
|
||||
from dataclasses import astuple, dataclass
|
||||
from typing import Any, Iterator, List, Optional, Tuple, Union
|
||||
from typing import Any, Dict, Iterator, List, Optional, Tuple, Union
|
||||
|
||||
import numpy as np
|
||||
|
||||
@@ -64,6 +64,7 @@ def _validate_tracker_id(tracker_id: Any, n: int) -> None:
|
||||
class Detections:
|
||||
"""
|
||||
Data class containing information about the detections in a video frame.
|
||||
|
||||
Attributes:
|
||||
xyxy (np.ndarray): An array of shape `(n, 4)` containing
|
||||
the bounding boxes coordinates in format `[x1, y1, x2, y2]`
|
||||
@@ -461,7 +462,7 @@ class Detections:
|
||||
>>> from segment_anything import (
|
||||
... sam_model_registry,
|
||||
... SamAutomaticMaskGenerator
|
||||
... )
|
||||
... )
|
||||
|
||||
>>> sam_model_reg = sam_model_registry[MODEL_TYPE]
|
||||
>>> sam = sam_model_reg(checkpoint=CHECKPOINT_PATH).to(device=DEVICE)
|
||||
@@ -484,6 +485,93 @@ class Detections:
|
||||
xyxy = xywh_to_xyxy(boxes_xywh=xywh)
|
||||
return cls(xyxy=xyxy, mask=mask)
|
||||
|
||||
@classmethod
|
||||
def from_azure_analyze_image(
|
||||
cls, azure_result: dict, class_map: Optional[Dict[int, str]] = None
|
||||
) -> Detections:
|
||||
"""
|
||||
Creates a Detections instance from [Azure Image Analysis 4.0](
|
||||
https://learn.microsoft.com/en-us/azure/ai-services/computer-vision/
|
||||
concept-object-detection-40).
|
||||
|
||||
Args:
|
||||
azure_result (dict): The result from Azure Image Analysis. It should
|
||||
contain detected objects and their bounding box coordinates.
|
||||
class_map (Optional[Dict[int, str]]): A mapping ofclass IDs (int) to class
|
||||
names (str). If None, a new mapping is created dynamically.
|
||||
|
||||
Returns:
|
||||
Detections: A new Detections object.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import requests
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = open(input, "rb").read()
|
||||
|
||||
>>> endpoint = "https://.cognitiveservices.azure.com/"
|
||||
>>> subscription_key = "..."
|
||||
|
||||
>>> headers = {
|
||||
... "Content-Type": "application/octet-stream",
|
||||
... "Ocp-Apim-Subscription-Key": subscription_key
|
||||
... }
|
||||
|
||||
>>> response = requests.post(endpoint,
|
||||
... headers=self.headers,
|
||||
... data=image
|
||||
... ).json()
|
||||
|
||||
>>> detections = sv.Detections.from_azure_analyze_image(response)
|
||||
```
|
||||
"""
|
||||
if "error" in azure_result:
|
||||
raise ValueError(
|
||||
f'Azure API returned an error {azure_result["error"]["message"]}'
|
||||
)
|
||||
|
||||
xyxy, confidences, class_ids = [], [], []
|
||||
|
||||
is_dynamic_mapping = class_map is None
|
||||
if is_dynamic_mapping:
|
||||
class_map = {}
|
||||
|
||||
class_map = {value: key for key, value in class_map.items()}
|
||||
|
||||
for detection in azure_result["objectsResult"]["values"]:
|
||||
bbox = detection["boundingBox"]
|
||||
|
||||
tags = detection["tags"]
|
||||
|
||||
x0 = bbox["x"]
|
||||
y0 = bbox["y"]
|
||||
x1 = x0 + bbox["w"]
|
||||
y1 = y0 + bbox["h"]
|
||||
|
||||
for tag in tags:
|
||||
confidence = tag["confidence"]
|
||||
class_name = tag["name"]
|
||||
class_id = class_map.get(class_name, None)
|
||||
|
||||
if is_dynamic_mapping and class_id is None:
|
||||
class_id = len(class_map)
|
||||
class_map[class_name] = class_id
|
||||
|
||||
if class_id is not None:
|
||||
xyxy.append([x0, y0, x1, y1])
|
||||
confidences.append(confidence)
|
||||
class_ids.append(class_id)
|
||||
|
||||
if len(xyxy) == 0:
|
||||
return Detections.empty()
|
||||
|
||||
return cls(
|
||||
xyxy=np.array(xyxy),
|
||||
class_id=np.array(class_ids),
|
||||
confidence=np.array(confidences),
|
||||
)
|
||||
|
||||
@classmethod
|
||||
def from_paddledet(cls, paddledet_result) -> Detections:
|
||||
"""
|
||||
|
||||
@@ -383,18 +383,65 @@ def process_roboflow_result(
|
||||
|
||||
def move_boxes(xyxy: np.ndarray, offset: np.ndarray) -> np.ndarray:
|
||||
"""
|
||||
Args:
|
||||
Parameters:
|
||||
xyxy (np.ndarray): An array of shape `(n, 4)` containing the bounding boxes
|
||||
coordinates in format `[x1, y1, x2, y2]`
|
||||
offset (np.array): An array of shape `(2,)` containing offset values in format
|
||||
is `[dx, dy]`.
|
||||
|
||||
Returns:
|
||||
(np.ndarray) repositioned bounding boxes
|
||||
np.ndarray: Repositioned bounding boxes.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import numpy as np
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> boxes = np.array([[10, 10, 20, 20], [30, 30, 40, 40]])
|
||||
>>> offset = np.array([5, 5])
|
||||
>>> sv.move_boxes(boxes, offset)
|
||||
... array([
|
||||
... [15, 15, 25, 25],
|
||||
... [35, 35, 45, 45]
|
||||
... ])
|
||||
```
|
||||
"""
|
||||
return xyxy + np.hstack([offset, offset])
|
||||
|
||||
|
||||
def scale_boxes(xyxy: np.ndarray, factor: float) -> np.ndarray:
|
||||
"""
|
||||
Scale the dimensions of bounding boxes.
|
||||
|
||||
Parameters:
|
||||
xyxy (np.ndarray): An array of shape `(n, 4)` containing the bounding boxes
|
||||
coordinates in format `[x1, y1, x2, y2]`
|
||||
factor (float): A float value representing the factor by which the box
|
||||
dimensions are scaled. A factor greater than 1 enlarges the boxes, while a
|
||||
factor less than 1 shrinks them.
|
||||
|
||||
Returns:
|
||||
np.ndarray: Scaled bounding boxes.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import numpy as np
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> boxes = np.array([[10, 10, 20, 20], [30, 30, 40, 40]])
|
||||
>>> factor = 1.5
|
||||
>>> sv.scale_boxes(boxes, factor)
|
||||
... array([
|
||||
... [ 7.5, 7.5, 22.5, 22.5],
|
||||
... [27.5, 27.5, 42.5, 42.5]
|
||||
... ])
|
||||
```
|
||||
"""
|
||||
centers = (xyxy[:, :2] + xyxy[:, 2:]) / 2
|
||||
new_sizes = (xyxy[:, 2:] - xyxy[:, :2]) * factor
|
||||
return np.concatenate((centers - new_sizes / 2, centers + new_sizes / 2), axis=1)
|
||||
|
||||
|
||||
def calculate_masks_centroids(masks: np.ndarray) -> np.ndarray:
|
||||
"""
|
||||
Calculate the centroids of binary masks in a tensor.
|
||||
|
||||
@@ -11,6 +11,7 @@ from supervision.detection.utils import (
|
||||
move_boxes,
|
||||
non_max_suppression,
|
||||
process_roboflow_result,
|
||||
scale_boxes,
|
||||
)
|
||||
|
||||
TEST_MASK = np.zeros((1, 1000, 1000), dtype=bool)
|
||||
@@ -504,6 +505,52 @@ def test_move_boxes(
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"xyxy, factor, expected_result, exception",
|
||||
[
|
||||
(
|
||||
np.empty(shape=(0, 4)),
|
||||
2.0,
|
||||
np.empty(shape=(0, 4)),
|
||||
DoesNotRaise(),
|
||||
), # empty xyxy array
|
||||
(
|
||||
np.array([[0, 0, 10, 10]]),
|
||||
1.0,
|
||||
np.array([[0, 0, 10, 10]]),
|
||||
DoesNotRaise(),
|
||||
), # single box with factor equal to 1.0
|
||||
(
|
||||
np.array([[0, 0, 10, 10]]),
|
||||
2.0,
|
||||
np.array([[-5, -5, 15, 15]]),
|
||||
DoesNotRaise(),
|
||||
), # single box with factor equal to 2.0
|
||||
(
|
||||
np.array([[0, 0, 10, 10]]),
|
||||
0.5,
|
||||
np.array([[2.5, 2.5, 7.5, 7.5]]),
|
||||
DoesNotRaise(),
|
||||
), # single box with factor equal to 0.5
|
||||
(
|
||||
np.array([[0, 0, 10, 10], [10, 10, 30, 30]]),
|
||||
2.0,
|
||||
np.array([[-5, -5, 15, 15], [0, 0, 40, 40]]),
|
||||
DoesNotRaise(),
|
||||
), # two boxes with factor equal to 2.0
|
||||
],
|
||||
)
|
||||
def test_scale_boxes(
|
||||
xyxy: np.ndarray,
|
||||
factor: float,
|
||||
expected_result: np.ndarray,
|
||||
exception: Exception,
|
||||
) -> None:
|
||||
with exception:
|
||||
result = scale_boxes(xyxy=xyxy, factor=factor)
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"masks, expected_result, exception",
|
||||
[
|
||||
|
||||
Reference in New Issue
Block a user