Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 SkalskiP |
239ea649c0 | ||
|
SkalskiP
|
6b14cc9572 | ||
|
SkalskiP
|
294a476977 | ||
|
Piotr Skalski
|
4fedb87f97 | ||
|
pre-commit-ci[bot]
|
a1b2297e9f | ||
|
SkalskiP
|
c064c1fc98 | ||
|
pre-commit-ci[bot]
|
0f3359c15f | ||
|
SkalskiP
|
a9987dbc83 | ||
|
SkalskiP
|
b14a035ede | ||
|
SkalskiP
|
295e8b725b | ||
|
pre-commit-ci[bot]
|
fa8a9cb5ac | ||
|
SkalskiP
|
66245dd0df | ||
|
SkalskiP
|
2d0a3f9d79 | ||
|
pre-commit-ci[bot]
|
7b2c09c0ab | ||
|
SkalskiP
|
d314bf0364 | ||
|
Onuralp SEZER
|
f5f068bffd | ||
|
SkalskiP
|
fc22a9ccd9 | ||
|
SkalskiP
|
45fe3c1c0f | ||
|
pre-commit-ci[bot]
|
027b60837a | ||
|
SkalskiP
|
fa569cb235 | ||
|
Onuralp SEZER
|
2bc58e7938 | ||
|
Onuralp SEZER
|
6f87069080 | ||
|
Onuralp SEZER
|
c0c541d121 | ||
|
pre-commit-ci[bot]
|
08173899a9 | ||
|
Onuralp SEZER
|
6e9bfc9a05 | ||
|
Onuralp SEZER
|
65eda0b80c | ||
|
Christoforos Aristeidou
|
740076d961 | ||
|
Christoforos Aristeidou
|
f3cb8e9d27 | ||
|
Christoforos Aristeidou
|
846b337155 | ||
|
Christoforos Aristeidou
|
ce19f917e9 | ||
|
Christoforos Aristeidou
|
c70ee87897 | ||
|
Christoforos Aristeidou
|
786942ba7e | ||
|
Christoforos Aristeidou
|
5ed3430b16 | ||
|
Christoforos Aristeidou
|
39ef293926 | ||
|
Christoforos Aristeidou
|
a59d84549f | ||
|
Christoforos Aristeidou
|
f94c0a4930 | ||
|
Christoforos Aristeidou
|
ae7360b5e0 | ||
|
Christoforos Aristeidou
|
e809e424e6 | ||
|
Christoforos Aristeidou
|
b1dbeaf9c4 | ||
|
Christoforos Aristeidou
|
fbcc211079 | ||
|
Onuralp SEZER
|
6b7ccfccd9 | ||
|
Onuralp SEZER
|
5677b4b5e3 | ||
|
pre-commit-ci[bot]
|
c323ecba8a | ||
|
dependabot[bot]
|
995f170e30 | ||
|
Onuralp SEZER
|
decbbb62ad | ||
|
Onuralp SEZER
|
7d3c2114dd | ||
|
dependabot[bot]
|
b008aadd41 | ||
|
dependabot[bot]
|
cca120915e | ||
|
Piotr Skalski
|
4e4fad9d04 | ||
|
pre-commit-ci[bot]
|
38bdeff171 | ||
|
Onuralp SEZER
|
6fee626828 | ||
|
Onuralp SEZER
|
bb4d741aff | ||
|
Piotr Skalski
|
d503e3aa50 | ||
|
Onuralp SEZER
|
3b13fc41a7 | ||
|
Piotr Skalski
|
9e6abc0fff | ||
|
Onuralp SEZER
|
3e48708910 | ||
|
Onuralp SEZER
|
215741fd83 | ||
|
Onuralp SEZER
|
c2a5583aa2 | ||
|
Piotr Skalski
|
c04edbcf85 | ||
|
pre-commit-ci[bot]
|
f768347d26 | ||
|
dependabot[bot]
|
ffc8c16993 | ||
|
pre-commit-ci[bot]
|
6128576ea1 | ||
|
Piotr Skalski
|
cda5016a5a | ||
|
SkalskiP
|
f8ee3a4290 | ||
|
SkalskiP
|
5f04836917 | ||
|
SkalskiP
|
616fc96ca8 | ||
|
rev
|
dca7fb43e5 | ||
|
rev
|
ec7baf3360 | ||
|
rev
|
9fb97e3c79 | ||
|
Piotr Skalski
|
536e0d86a8 | ||
|
SkalskiP
|
3a608eeb93 | ||
|
SkalskiP
|
008b0bd984 | ||
|
rev
|
353865e017 | ||
|
SkalskiP
|
da4ee62298 | ||
|
rev
|
ae758a655d | ||
|
pre-commit-ci[bot]
|
e38256f316 | ||
|
dependabot[bot]
|
713bacae08 | ||
|
rev
|
2367fcac82 | ||
|
rev
|
1f640980ad | ||
|
Piotr Skalski
|
64661a3e4a | ||
|
Piotr Skalski
|
1c414bd70f | ||
|
Piotr Skalski
|
e32b05a636 | ||
|
Piotr Skalski
|
688cf14f2a | ||
|
pre-commit-ci[bot]
|
e3529436e1 | ||
|
SkalskiP
|
99d1b6d130 | ||
|
pre-commit-ci[bot]
|
47eed7257c | ||
|
rev
|
602676bd9c | ||
|
rev
|
0e1f422a75 | ||
|
pre-commit-ci[bot]
|
4d8f15f295 | ||
|
SkalskiP
|
c78354203d |
@@ -45,7 +45,7 @@ jobs:
|
||||
python-dateutil==2.8.2 \
|
||||
PyYAML==5.3 \
|
||||
requests==2.26.0 \
|
||||
scipy==1.9.0 \
|
||||
scipy==1.10.0 \
|
||||
setuptools-scm==8.0.4 \
|
||||
six==1.16.0 \
|
||||
tomli==2.0.1 \
|
||||
|
||||
+21
@@ -135,3 +135,24 @@ dmypy.json
|
||||
|
||||
# Notebooks
|
||||
notebooks/
|
||||
|
||||
# OSX folder attributes
|
||||
.DS_Store
|
||||
.AppleDouble
|
||||
.LSOverride
|
||||
|
||||
# Thumbnails
|
||||
._*
|
||||
|
||||
# Files that might appear on external disk
|
||||
.Spotlight-V100
|
||||
.Trashes
|
||||
|
||||
# Windows
|
||||
Thumbs.db
|
||||
Desktop.ini
|
||||
|
||||
# Linux
|
||||
*~
|
||||
.directory
|
||||
.Trash-*
|
||||
|
||||
@@ -46,7 +46,7 @@ repos:
|
||||
|
||||
|
||||
- repo: https://github.com/astral-sh/ruff-pre-commit
|
||||
rev: v0.1.13
|
||||
rev: v0.1.14
|
||||
hooks:
|
||||
- id: ruff
|
||||
args: [--fix, --exit-non-zero-on-fix]
|
||||
|
||||
@@ -237,7 +237,7 @@ https://user-images.githubusercontent.com/26109316/207858600-ee862b22-0353-440b-
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/c9436828-9fbf-4c25-ae8c-60e9c81b3900
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/f84db7b5-79e2-4142-a1da-64daa43ce667
|
||||
https://github.com/roboflow/supervision/assets/26109316/3ac6982f-4943-4108-9b7f-51787ef1a69f
|
||||
|
||||
## 📚 documentation
|
||||
|
||||
|
||||
+36
-7
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
=== "BoundingBox"
|
||||
|
||||
```python
|
||||
@@ -120,7 +124,7 @@
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
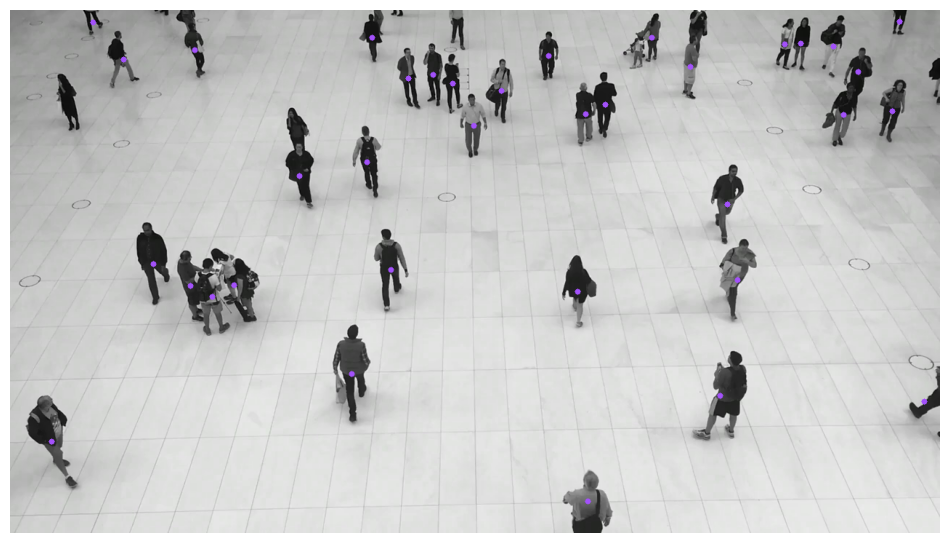{ align=center width="800" }
|
||||
{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
@@ -183,7 +187,28 @@
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
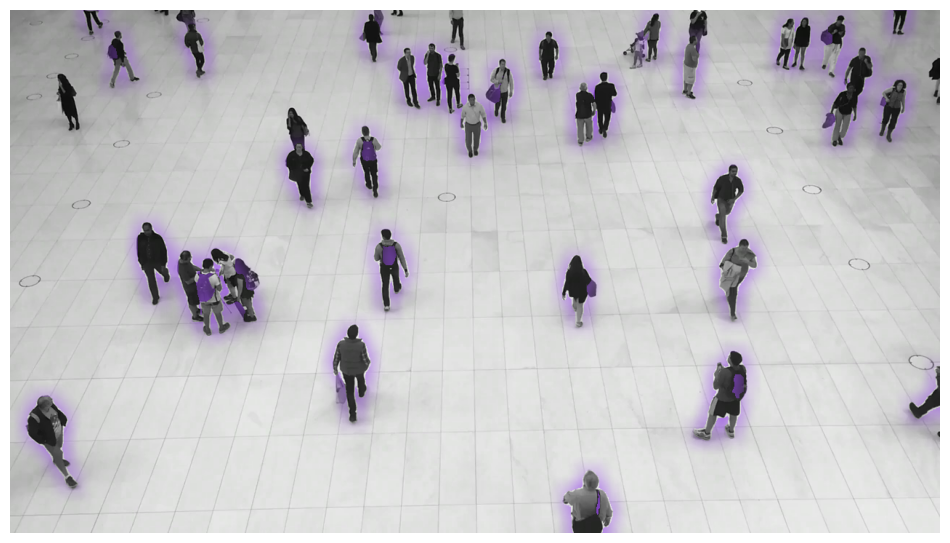{ align=center width="800" }
|
||||
{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
=== "PercentageBar"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> percentage_bar_annotator = sv.PercentageBarAnnotator()
|
||||
>>> annotated_frame = percentage_bar_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
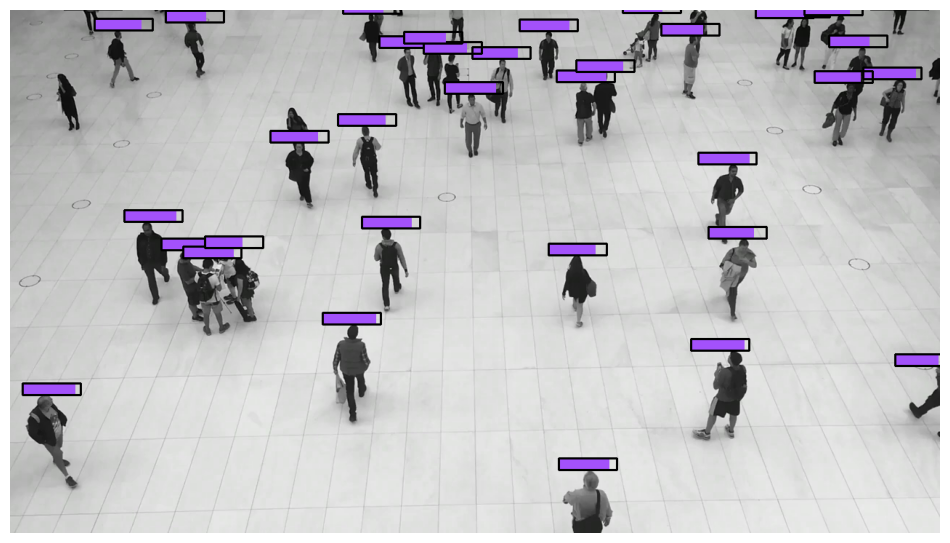{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
@@ -348,7 +373,7 @@
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
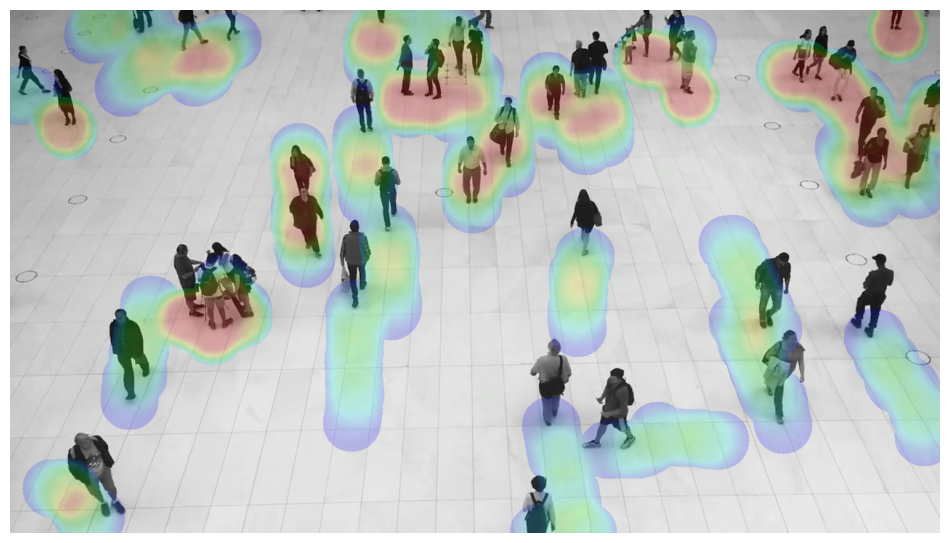{ align=center width="800" }
|
||||
{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
@@ -356,6 +381,10 @@
|
||||
|
||||
:::supervision.annotators.core.BoundingBoxAnnotator
|
||||
|
||||
## RoundBoxAnnotator
|
||||
|
||||
:::supervision.annotators.core.RoundBoxAnnotator
|
||||
|
||||
## BoxCornerAnnotator
|
||||
|
||||
:::supervision.annotators.core.BoxCornerAnnotator
|
||||
@@ -384,6 +413,10 @@
|
||||
|
||||
:::supervision.annotators.core.HaloAnnotator
|
||||
|
||||
## PercentageBarAnnotator
|
||||
|
||||
:::supervision.annotators.core.PercentageBarAnnotator
|
||||
|
||||
## HeatMapAnnotator
|
||||
|
||||
:::supervision.annotators.core.HeatMapAnnotator
|
||||
@@ -412,10 +445,6 @@
|
||||
|
||||
:::supervision.annotators.core.TraceAnnotator
|
||||
|
||||
## RoundBoxAnnotator
|
||||
|
||||
:::supervision.annotators.core.RoundBoxAnnotator
|
||||
|
||||
## ColorLookup
|
||||
|
||||
:::supervision.annotators.utils.ColorLookup
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
Supervision offers an assets download utility that allows you to download video files
|
||||
that you can use in your demos.
|
||||
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## Classifications
|
||||
|
||||
:::supervision.classification.core.Classifications
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
!!! warning
|
||||
|
||||
Dataset API is still fluid and may change. If you use Dataset API in your project until further notice, freeze the
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## Detections
|
||||
|
||||
:::supervision.detection.core.Detections
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## InferenceSlicer
|
||||
|
||||
:::supervision.detection.tools.inference_slicer.InferenceSlicer
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## LineZone
|
||||
|
||||
:::supervision.detection.line_counter.LineZone
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## PolygonZone
|
||||
|
||||
:::supervision.detection.tools.polygon_zone.PolygonZone
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## box_iou_batch
|
||||
|
||||
:::supervision.detection.utils.box_iou_batch
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## Color
|
||||
|
||||
:::supervision.draw.color.Color
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## draw_line
|
||||
|
||||
:::supervision.draw.utils.draw_line
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## Position
|
||||
|
||||
:::supervision.geometry.core.Position
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
Supervision offers a streamlined solution to effortlessly annotate predictions from a
|
||||
range of object detection and segmentation models. This guide demonstrates how to
|
||||
execute inference using the YOLOv8 model with either the
|
||||
|
||||
@@ -1 +1,5 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
🚧 Page under construction.
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
The advanced filtering capabilities of the `Detections` class offer users a versatile and efficient way to narrow down
|
||||
and refine object detections. This section outlines various filtering methods, including filtering by specific class
|
||||
or a set of classes, confidence, object area, bounding box area, relative area, box dimensions, and designated zones.
|
||||
|
||||
@@ -1 +1,5 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
🚧 Page under construction.
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
Leverage Supervision's advanced capabilities for enhancing your video analysis by
|
||||
seamlessly [tracking](https://supervision.roboflow.com/trackers/) objects recognized by
|
||||
a multitude of object detection and segmentation models. This comprehensive guide will
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
<div align="center">
|
||||
<p>
|
||||
<a align="center" href="" target="_blank">
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
!!! warning
|
||||
|
||||
Evaluation API is still fluid and may change. If you use Evaluation API in your project until further notice, freeze the
|
||||
|
||||
Vendored
+51
@@ -0,0 +1,51 @@
|
||||
{% if page.meta.comments %}
|
||||
<h2 id="__comments">{{ lang.t("meta.comments") }}</h2>
|
||||
|
||||
<!-- Insert Giscus code snippet from https://giscus.app/ here -->
|
||||
<script src="https://giscus.app/client.js"
|
||||
data-repo="roboflow/supervision"
|
||||
data-repo-id="R_kgDOIhIiww"
|
||||
data-category="Docs"
|
||||
data-category-id="DIC_kwDOIhIiw84Ccet_"
|
||||
data-mapping="pathname"
|
||||
data-strict="0"
|
||||
data-reactions-enabled="1"
|
||||
data-emit-metadata="1"
|
||||
data-input-position="top"
|
||||
data-theme="preferred_color_scheme"
|
||||
data-lang="en"
|
||||
data-loading="lazy"
|
||||
crossorigin="anonymous"
|
||||
async>
|
||||
</script>
|
||||
|
||||
<!-- Synchronize Giscus theme with palette -->
|
||||
<script>
|
||||
var giscus = document.querySelector("script[src*=giscus]")
|
||||
|
||||
/* Set palette on initial load */
|
||||
var palette = __md_get("__palette")
|
||||
if (palette && typeof palette.color === "object") {
|
||||
var theme = palette.color.scheme === "slate" ? "dark" : "light"
|
||||
giscus.setAttribute("data-theme", theme)
|
||||
}
|
||||
|
||||
/* Register event handlers after documented loaded */
|
||||
document.addEventListener("DOMContentLoaded", function() {
|
||||
var ref = document.querySelector("[data-md-component=palette]")
|
||||
ref.addEventListener("change", function() {
|
||||
var palette = __md_get("__palette")
|
||||
if (palette && typeof palette.color === "object") {
|
||||
var theme = palette.color.scheme === "slate" ? "dark" : "light"
|
||||
|
||||
/* Instruct Giscus to change theme */
|
||||
var frame = document.querySelector(".giscus-frame")
|
||||
frame.contentWindow.postMessage(
|
||||
{ giscus: { setConfig: { theme } } },
|
||||
"https://giscus.app"
|
||||
)
|
||||
}
|
||||
})
|
||||
})
|
||||
</script>
|
||||
{% endif %}
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## ByteTrack
|
||||
|
||||
:::supervision.tracker.byte_tracker.core.ByteTrack
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## list_files_with_extensions
|
||||
|
||||
:::supervision.utils.file.list_files_with_extensions
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## ImageSink
|
||||
|
||||
:::supervision.utils.image.ImageSink
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## plot_image
|
||||
|
||||
:::supervision.utils.notebook.plot_image
|
||||
|
||||
@@ -1,3 +1,7 @@
|
||||
---
|
||||
comments: true
|
||||
---
|
||||
|
||||
## VideoInfo
|
||||
|
||||
:::supervision.utils.video.VideoInfo
|
||||
|
||||
@@ -3,3 +3,11 @@ data/*
|
||||
|
||||
# But re-include all .json files
|
||||
!data/*.json
|
||||
|
||||
*.pt
|
||||
*.pth
|
||||
*.mp4
|
||||
*.mov
|
||||
*.png
|
||||
*.jpg
|
||||
*.jpeg
|
||||
|
||||
@@ -1,2 +1,9 @@
|
||||
data/
|
||||
venv*/
|
||||
*.pt
|
||||
*.pth
|
||||
*.mp4
|
||||
*.mov
|
||||
*.png
|
||||
*.jpg
|
||||
*.jpeg
|
||||
|
||||
@@ -1,18 +1,24 @@
|
||||
# speed estimation
|
||||
|
||||
[](https://colab.research.google.com/github/roboflow-ai/notebooks/blob/main/notebooks/how-to-estimate-vehicle-speed-with-computer-vision.ipynb)
|
||||
[](https://youtu.be/uWP6UjDeZvY)
|
||||
|
||||
## 👋 hello
|
||||
|
||||
This example performs speed estimation analysis using various object-detection models
|
||||
and ByteTrack - a simple yet effective online multi-object tracking method. It uses the
|
||||
supervision package for multiple tasks such as tracking, annotations, etc.
|
||||
|
||||
https://github.com/roboflow/supervision/assets/26109316/0542fd3c-bb5f-475e-b96c-793560abeb18
|
||||
https://github.com/roboflow/supervision/assets/26109316/d50118c1-2ae4-458d-915a-5d860fd36f71
|
||||
|
||||
> [!IMPORTANT]
|
||||
> Adjust the [`SOURCE`](https://github.com/roboflow/supervision/blob/e32b05a636dab2ea1f39299e529c4b22b8baa8da/examples/speed_estimation/ultralytics_example.py#L10)
|
||||
> and [`TARGET`](https://github.com/roboflow/supervision/blob/e32b05a636dab2ea1f39299e529c4b22b8baa8da/examples/speed_estimation/ultralytics_example.py#L15)
|
||||
> configuration if you plan to run a speed estimation script on your video file. Those must be adjusted separately for each camera view. You can learn more
|
||||
> from our YouTube [tutorial](https://youtu.be/uWP6UjDeZvY).
|
||||
|
||||
## 💻 install
|
||||
|
||||
> [!NOTE]
|
||||
> YOLO-NAS is compatible with Python versions up to and including Python 3.10.
|
||||
|
||||
- clone repository and navigate to example directory
|
||||
|
||||
```bash
|
||||
|
||||
@@ -1,6 +1,6 @@
|
||||
supervision==0.18.0rc1
|
||||
tqdm
|
||||
tqdm==4.66.1
|
||||
requests
|
||||
ultralytics
|
||||
super-gradients
|
||||
inference
|
||||
ultralytics==8.0.237
|
||||
super-gradients==3.5.0
|
||||
inference==0.9.8
|
||||
|
||||
@@ -29,6 +29,9 @@ class ViewTransformer:
|
||||
self.m = cv2.getPerspectiveTransform(source, target)
|
||||
|
||||
def transform_points(self, points: np.ndarray) -> np.ndarray:
|
||||
if points.size == 0:
|
||||
return points
|
||||
|
||||
reshaped_points = points.reshape(-1, 1, 2).astype(np.float32)
|
||||
transformed_points = cv2.perspectiveTransform(reshaped_points, self.m)
|
||||
return transformed_points.reshape(-1, 2)
|
||||
|
||||
@@ -1,2 +1,9 @@
|
||||
data/
|
||||
venv/
|
||||
*.pt
|
||||
*.pth
|
||||
*.mp4
|
||||
*.mov
|
||||
*.png
|
||||
*.jpg
|
||||
*.jpeg
|
||||
|
||||
Generated
+577
-493
File diff suppressed because it is too large
Load Diff
+8
-5
@@ -1,6 +1,6 @@
|
||||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.18.0rc2"
|
||||
version = "0.18.0rc3"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
@@ -33,12 +33,15 @@ classifiers=[
|
||||
[tool.poetry.dependencies]
|
||||
python = "^3.8"
|
||||
numpy = ">=1.21.2"
|
||||
scipy = ">=1.9.0"
|
||||
scipy = [
|
||||
{ version = "1.10.0", python = "<3.9" },
|
||||
{ version = "^1.10.0", python = ">=3.9" }
|
||||
]
|
||||
matplotlib = ">=3.5.0"
|
||||
pyyaml = ">=5.3"
|
||||
pillow = ">=9.4"
|
||||
opencv-python = { version = ">=4.5.5.64,<=4.8.1.78", optional = true }
|
||||
opencv-python-headless = ">=4.5.5.64,<=4.8.1.78"
|
||||
opencv-python = { version = ">=4.5.5.64", optional = true }
|
||||
opencv-python-headless = ">=4.5.5.64"
|
||||
requests = { version = ">=2.26.0,<=2.31.0", optional = true }
|
||||
tqdm = { version = ">=4.62.3,<=4.66.1", optional = true }
|
||||
defusedxml = "^0.7.1"
|
||||
@@ -62,7 +65,7 @@ tox = "^4.11.4"
|
||||
|
||||
|
||||
[tool.poetry.group.docs.dependencies]
|
||||
mkdocs-material = "^9.1.4"
|
||||
mkdocs-material = {extras = ["imaging"], version = "^9.5.4"}
|
||||
mkdocstrings = {extras = ["python"], version = ">=0.20,<0.25"}
|
||||
|
||||
|
||||
|
||||
@@ -18,6 +18,7 @@ from supervision.annotators.core import (
|
||||
HeatMapAnnotator,
|
||||
LabelAnnotator,
|
||||
MaskAnnotator,
|
||||
PercentageBarAnnotator,
|
||||
PixelateAnnotator,
|
||||
PolygonAnnotator,
|
||||
RoundBoxAnnotator,
|
||||
|
||||
+189
-15
@@ -21,7 +21,7 @@ class BoundingBoxAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
@@ -103,7 +103,7 @@ class MaskAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
opacity: float = 0.5,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
@@ -186,7 +186,7 @@ class PolygonAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
@@ -268,7 +268,7 @@ class ColorAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
opacity: float = 0.5,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
@@ -354,7 +354,7 @@ class HaloAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
opacity: float = 0.8,
|
||||
kernel_size: int = 40,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
@@ -446,7 +446,7 @@ class EllipseAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
start_angle: int = -45,
|
||||
end_angle: int = 235,
|
||||
@@ -536,7 +536,7 @@ class BoxCornerAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 4,
|
||||
corner_length: int = 15,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
@@ -622,7 +622,7 @@ class CircleAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
@@ -706,7 +706,7 @@ class DotAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
radius: int = 4,
|
||||
position: Position = Position.CENTER,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
@@ -782,8 +782,8 @@ class LabelAnnotator:
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
text_color: Color = Color.black(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
text_color: Color = Color.WHITE,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
@@ -1027,7 +1027,7 @@ class TraceAnnotator:
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
position: Position = Position.CENTER,
|
||||
trace_length: int = 30,
|
||||
thickness: int = 2,
|
||||
@@ -1288,7 +1288,7 @@ class TriangleAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
base: int = 10,
|
||||
height: int = 10,
|
||||
position: Position = Position.TOP_CENTER,
|
||||
@@ -1378,7 +1378,7 @@ class RoundBoxAnnotator(BaseAnnotator):
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
roundness: float = 0.6,
|
||||
@@ -1436,7 +1436,7 @@ class RoundBoxAnnotator(BaseAnnotator):
|
||||
```
|
||||
|
||||

|
||||
supervision-annotator-examples/round-box-annotator-example-purple.png)
|
||||
"""
|
||||
|
||||
for detection_idx in range(len(detections)):
|
||||
@@ -1496,3 +1496,177 @@ class RoundBoxAnnotator(BaseAnnotator):
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
|
||||
class PercentageBarAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing percentage bars on an image using provided detections.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
height: int = 16,
|
||||
width: int = 80,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
border_color: Color = Color.BLACK,
|
||||
position: Position = Position.TOP_CENTER,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
border_thickness: int = None,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
height (int): The height in pixels of the percentage bar.
|
||||
width (int): The width in pixels of the percentage bar.
|
||||
color (Union[Color, ColorPalette]): The color or color palette to use for
|
||||
annotating detections.
|
||||
border_color (Color): The color of the border lines.
|
||||
position (Position): The anchor position of drawing the percentage bar.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
border_thickness (int): The thickness of the border lines.
|
||||
"""
|
||||
self.height: int = height
|
||||
self.width: int = width
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.border_color: Color = border_color
|
||||
self.position: Position = position
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
if border_thickness is None:
|
||||
self.border_thickness = int(0.15 * self.height)
|
||||
|
||||
def annotate(
|
||||
self,
|
||||
scene: np.ndarray,
|
||||
detections: Detections,
|
||||
custom_color_lookup: Optional[np.ndarray] = None,
|
||||
custom_values: Optional[np.ndarray] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Annotates the given scene with percentage bars based on the provided
|
||||
detections. The percentage bars visually represent the confidence or custom
|
||||
values associated with each detection.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image where percentage bars will be drawn.
|
||||
detections (Detections): Object detections to annotate.
|
||||
custom_color_lookup (Optional[np.ndarray]): Custom color lookup array.
|
||||
Allows to override the default color mapping strategy.
|
||||
custom_values (Optional[np.ndarray]): Custom values array to use instead
|
||||
of the default detection confidences. This array should have the
|
||||
same length as the number of detections and contain a value between
|
||||
0 and 1 (inclusive) for each detection, representing the percentage
|
||||
to be displayed.
|
||||
|
||||
Returns:
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> percentage_bar_annotator = sv.BoundingBoxAnnotator()
|
||||
>>> annotated_frame = percentage_bar_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
self.validate_custom_values(
|
||||
custom_values=custom_values, detections_count=len(detections)
|
||||
)
|
||||
anchors = detections.get_anchors_coordinates(anchor=self.position)
|
||||
for detection_idx in range(len(detections)):
|
||||
anchor = anchors[detection_idx]
|
||||
border_coordinates = self.calculate_border_coordinates(
|
||||
anchor_xy=(int(anchor[0]), int(anchor[1])),
|
||||
border_wh=(self.width, self.height),
|
||||
position=self.position,
|
||||
)
|
||||
border_width = border_coordinates[1][0] - border_coordinates[0][0]
|
||||
|
||||
value = (
|
||||
custom_values[detection_idx]
|
||||
if custom_values is not None
|
||||
else detections.confidence[detection_idx]
|
||||
)
|
||||
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
detections=detections,
|
||||
detection_idx=detection_idx,
|
||||
color_lookup=self.color_lookup
|
||||
if custom_color_lookup is None
|
||||
else custom_color_lookup,
|
||||
)
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=border_coordinates[0],
|
||||
pt2=(
|
||||
border_coordinates[0][0] + int(border_width * value),
|
||||
border_coordinates[1][1],
|
||||
),
|
||||
color=color.as_bgr(),
|
||||
thickness=-1,
|
||||
)
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
pt1=border_coordinates[0],
|
||||
pt2=border_coordinates[1],
|
||||
color=self.border_color.as_bgr(),
|
||||
thickness=self.border_thickness,
|
||||
)
|
||||
return scene
|
||||
|
||||
@staticmethod
|
||||
def calculate_border_coordinates(
|
||||
anchor_xy: Tuple[int, int], border_wh: Tuple[int, int], position: Position
|
||||
) -> Tuple[Tuple[int, int], Tuple[int, int]]:
|
||||
cx, cy = anchor_xy
|
||||
width, height = border_wh
|
||||
|
||||
if position == Position.TOP_LEFT:
|
||||
return (cx - width, cy - height), (cx, cy)
|
||||
elif position == Position.TOP_CENTER:
|
||||
return (cx - width // 2, cy), (cx + width // 2, cy - height)
|
||||
elif position == Position.TOP_RIGHT:
|
||||
return (cx, cy), (cx + width, cy - height)
|
||||
elif position == Position.CENTER_LEFT:
|
||||
return (cx - width, cy - height // 2), (cx, cy + height // 2)
|
||||
elif position == Position.CENTER or position == Position.CENTER_OF_MASS:
|
||||
return (
|
||||
(cx - width // 2, cy - height // 2),
|
||||
(cx + width // 2, cy + height // 2),
|
||||
)
|
||||
elif position == Position.CENTER_RIGHT:
|
||||
return (cx, cy - height // 2), (cx + width, cy + height // 2)
|
||||
elif position == Position.BOTTOM_LEFT:
|
||||
return (cx - width, cy), (cx, cy + height)
|
||||
elif position == Position.BOTTOM_CENTER:
|
||||
return (cx - width // 2, cy), (cx + width // 2, cy + height)
|
||||
elif position == Position.BOTTOM_RIGHT:
|
||||
return (cx, cy), (cx + width, cy + height)
|
||||
|
||||
@staticmethod
|
||||
def validate_custom_values(
|
||||
custom_values: Optional[Union[np.ndarray, List[float]]], detections_count: int
|
||||
) -> None:
|
||||
if custom_values is not None:
|
||||
if not isinstance(custom_values, (np.ndarray, list)):
|
||||
raise TypeError(
|
||||
"custom_values must be either a numpy array or a list of floats."
|
||||
)
|
||||
|
||||
if len(custom_values) != detections_count:
|
||||
raise ValueError(
|
||||
"The length of custom_values must match the number of detections."
|
||||
)
|
||||
|
||||
if not all(0 <= value <= 1 for value in custom_values):
|
||||
raise ValueError("All values in custom_values must be between 0 and 1.")
|
||||
|
||||
@@ -26,9 +26,9 @@ class BoxAnnotator:
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
color: Union[Color, ColorPalette] = ColorPalette.DEFAULT,
|
||||
thickness: int = 2,
|
||||
text_color: Color = Color.black(),
|
||||
text_color: Color = Color.BLACK,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
|
||||
@@ -1,11 +1,11 @@
|
||||
from typing import Dict, Optional, Tuple
|
||||
from typing import Dict, Iterable, Optional, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.draw.color import Color
|
||||
from supervision.geometry.core import Point, Rect, Vector
|
||||
from supervision.geometry.core import Point, Position, Rect, Vector
|
||||
|
||||
|
||||
class LineZone:
|
||||
@@ -26,16 +26,71 @@ class LineZone:
|
||||
to outside.
|
||||
"""
|
||||
|
||||
def __init__(self, start: Point, end: Point):
|
||||
def __init__(
|
||||
self,
|
||||
start: Point,
|
||||
end: Point,
|
||||
triggering_anchors: Iterable[Position] = (
|
||||
Position.TOP_LEFT,
|
||||
Position.TOP_RIGHT,
|
||||
Position.BOTTOM_LEFT,
|
||||
Position.BOTTOM_RIGHT,
|
||||
),
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
start (Point): The starting point of the line.
|
||||
end (Point): The ending point of the line.
|
||||
triggering_anchors (List[sv.Position]): A list of positions
|
||||
specifying which anchors of the detections bounding box
|
||||
to consider when deciding on whether the detection
|
||||
has passed the line counter or not. By default, this
|
||||
contains the four corners of the detection's bounding box
|
||||
"""
|
||||
self.vector = Vector(start=start, end=end)
|
||||
self.limits = self.calculate_region_of_interest_limits(vector=self.vector)
|
||||
self.tracker_state: Dict[str, bool] = {}
|
||||
self.in_count: int = 0
|
||||
self.out_count: int = 0
|
||||
self.triggering_anchors = triggering_anchors
|
||||
|
||||
@staticmethod
|
||||
def calculate_region_of_interest_limits(vector: Vector) -> Tuple[Vector, Vector]:
|
||||
magnitude = vector.magnitude
|
||||
|
||||
if magnitude == 0:
|
||||
raise ValueError("The magnitude of the vector cannot be zero.")
|
||||
|
||||
delta_x = vector.end.x - vector.start.x
|
||||
delta_y = vector.end.y - vector.start.y
|
||||
|
||||
unit_vector_x = delta_x / magnitude
|
||||
unit_vector_y = delta_y / magnitude
|
||||
|
||||
perpendicular_vector_x = -unit_vector_y
|
||||
perpendicular_vector_y = unit_vector_x
|
||||
|
||||
start_region_limit = Vector(
|
||||
start=vector.start,
|
||||
end=Point(
|
||||
x=vector.start.x + perpendicular_vector_x,
|
||||
y=vector.start.y + perpendicular_vector_y,
|
||||
),
|
||||
)
|
||||
end_region_limit = Vector(
|
||||
start=vector.end,
|
||||
end=Point(
|
||||
x=vector.end.x - perpendicular_vector_x,
|
||||
y=vector.end.y - perpendicular_vector_y,
|
||||
),
|
||||
)
|
||||
return start_region_limit, end_region_limit
|
||||
|
||||
@staticmethod
|
||||
def is_point_in_limits(point: Point, limits: Tuple[Vector, Vector]) -> bool:
|
||||
cross_product_1 = limits[0].cross_product(point)
|
||||
cross_product_2 = limits[1].cross_product(point)
|
||||
return (cross_product_1 > 0) == (cross_product_2 > 0)
|
||||
|
||||
def trigger(self, detections: Detections) -> Tuple[np.ndarray, np.ndarray]:
|
||||
"""
|
||||
@@ -54,20 +109,35 @@ class LineZone:
|
||||
crossed_in = np.full(len(detections), False)
|
||||
crossed_out = np.full(len(detections), False)
|
||||
|
||||
for i, (xyxy, tracker_id) in enumerate(
|
||||
zip(detections.xyxy, detections.tracker_id)
|
||||
):
|
||||
if len(detections) == 0:
|
||||
return crossed_in, crossed_out
|
||||
|
||||
all_anchors = np.array(
|
||||
[
|
||||
detections.get_anchors_coordinates(anchor)
|
||||
for anchor in self.triggering_anchors
|
||||
]
|
||||
)
|
||||
|
||||
for i, tracker_id in enumerate(detections.tracker_id):
|
||||
if tracker_id is None:
|
||||
continue
|
||||
|
||||
x1, y1, x2, y2 = xyxy
|
||||
anchors = [
|
||||
Point(x=x1, y=y1),
|
||||
Point(x=x1, y=y2),
|
||||
Point(x=x2, y=y1),
|
||||
Point(x=x2, y=y2),
|
||||
box_anchors = [Point(x=x, y=y) for x, y in all_anchors[:, i, :]]
|
||||
|
||||
in_limits = all(
|
||||
[
|
||||
self.is_point_in_limits(point=anchor, limits=self.limits)
|
||||
for anchor in box_anchors
|
||||
]
|
||||
)
|
||||
|
||||
if not in_limits:
|
||||
continue
|
||||
|
||||
triggers = [
|
||||
self.vector.cross_product(point=anchor) > 0 for anchor in box_anchors
|
||||
]
|
||||
triggers = [self.vector.is_in(point=anchor) for anchor in anchors]
|
||||
|
||||
if len(set(triggers)) == 2:
|
||||
continue
|
||||
@@ -96,9 +166,9 @@ class LineZoneAnnotator:
|
||||
def __init__(
|
||||
self,
|
||||
thickness: float = 2,
|
||||
color: Color = Color.white(),
|
||||
color: Color = Color.WHITE,
|
||||
text_thickness: float = 2,
|
||||
text_color: Color = Color.black(),
|
||||
text_color: Color = Color.BLACK,
|
||||
text_scale: float = 0.5,
|
||||
text_offset: float = 1.5,
|
||||
text_padding: int = 10,
|
||||
|
||||
@@ -90,7 +90,7 @@ class PolygonZoneAnnotator:
|
||||
zone: PolygonZone,
|
||||
color: Color,
|
||||
thickness: int = 2,
|
||||
text_color: Color = Color.black(),
|
||||
text_color: Color = Color.BLACK,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
|
||||
+236
-42
@@ -3,26 +3,56 @@ from __future__ import annotations
|
||||
from dataclasses import dataclass
|
||||
from typing import List, Tuple
|
||||
|
||||
import matplotlib.pyplot as plt
|
||||
|
||||
from supervision.utils.internal import classproperty, deprecated
|
||||
|
||||
DEFAULT_COLOR_PALETTE = [
|
||||
"#a351fb",
|
||||
"#e6194b",
|
||||
"#3cb44b",
|
||||
"#ffe119",
|
||||
"#0082c8",
|
||||
"#f58231",
|
||||
"#911eb4",
|
||||
"#46f0f0",
|
||||
"#f032e6",
|
||||
"#d2f53c",
|
||||
"#fabebe",
|
||||
"#008080",
|
||||
"#e6beff",
|
||||
"#aa6e28",
|
||||
"#fffac8",
|
||||
"#800000",
|
||||
"#aaffc3",
|
||||
"A351FB",
|
||||
"FF4040",
|
||||
"FFA1A0",
|
||||
"FF7633",
|
||||
"FFB633",
|
||||
"D1D435",
|
||||
"4CFB12",
|
||||
"94CF1A",
|
||||
"40DE8A",
|
||||
"1B9640",
|
||||
"00D6C1",
|
||||
"2E9CAA",
|
||||
"00C4FF",
|
||||
"364797",
|
||||
"6675FF",
|
||||
"0019EF",
|
||||
"863AFF",
|
||||
"530087",
|
||||
"CD3AFF",
|
||||
"FF97CA",
|
||||
"FF39C9",
|
||||
]
|
||||
|
||||
LEGACY_COLOR_PALETTE = [
|
||||
"#A351FB",
|
||||
"#E6194B",
|
||||
"#3CB44B",
|
||||
"#FFE119",
|
||||
"#0082C8",
|
||||
"#F58231",
|
||||
"#911EB4",
|
||||
"#46F0F0",
|
||||
"#F032E6",
|
||||
"#D2F53C",
|
||||
"#FABEBE",
|
||||
"#008080",
|
||||
"#E6BEFF",
|
||||
"#AA6E28",
|
||||
"#FFFAC8",
|
||||
"#800000",
|
||||
"#AAFFC3",
|
||||
]
|
||||
|
||||
ROBOFLOW_COLOR_PALETTE = ["C28DFC", "A351FB", "8315F9", "6706CE", "5905B3", "4D049A"]
|
||||
|
||||
|
||||
def _validate_color_hex(color_hex: str):
|
||||
color_hex = color_hex.lstrip("#")
|
||||
@@ -37,10 +67,31 @@ class Color:
|
||||
"""
|
||||
Represents a color in RGB format.
|
||||
|
||||
This class provides methods to work with colors, including creating colors from hex
|
||||
codes, converting colors to hex strings, RGB tuples, and BGR tuples.
|
||||
|
||||
Attributes:
|
||||
r (int): Red channel.
|
||||
g (int): Green channel.
|
||||
b (int): Blue channel.
|
||||
r (int): Red channel value (0-255).
|
||||
g (int): Green channel value (0-255).
|
||||
b (int): Blue channel value (0-255).
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.Color.WHITE
|
||||
# Color(r=255, g=255, b=255)
|
||||
```
|
||||
|
||||
| Constant | Hex Code | RGB |
|
||||
|------------|------------|------------------|
|
||||
| `WHITE` | `#FFFFFF` | `(255, 255, 255)`|
|
||||
| `BLACK` | `#000000` | `(0, 0, 0)` |
|
||||
| `RED` | `#FF0000` | `(255, 0, 0)` |
|
||||
| `GREEN` | `#00FF00` | `(0, 255, 0)` |
|
||||
| `BLUE` | `#0000FF` | `(0, 0, 255)` |
|
||||
| `YELLOW` | `#FFFF00` | `(255, 255, 0)` |
|
||||
| `ROBOFLOW` | `#A351FB` | `(163, 81, 251)` |
|
||||
"""
|
||||
|
||||
r: int
|
||||
@@ -59,9 +110,11 @@ class Color:
|
||||
Color: Instance representing the color.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> Color.from_hex('#ff00ff')
|
||||
Color(r=255, g=0, b=255)
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.Color.from_hex('#ff00ff')
|
||||
# Color(r=255, g=0, b=255)
|
||||
```
|
||||
"""
|
||||
_validate_color_hex(color_hex)
|
||||
@@ -79,9 +132,11 @@ class Color:
|
||||
str: The hexadecimal color string.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> Color(r=255, g=0, b=255).as_hex()
|
||||
'#ff00ff'
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.Color(r=255, g=255, b=0).as_hex()
|
||||
# '#ffff00'
|
||||
```
|
||||
"""
|
||||
return f"#{self.r:02x}{self.g:02x}{self.b:02x}"
|
||||
@@ -94,9 +149,11 @@ class Color:
|
||||
Tuple[int, int, int]: RGB tuple.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> color.as_rgb()
|
||||
(255, 0, 255)
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.Color(r=255, g=255, b=0).as_rgb()
|
||||
# (255, 255, 0)
|
||||
```
|
||||
"""
|
||||
return self.r, self.g, self.b
|
||||
@@ -109,30 +166,80 @@ class Color:
|
||||
Tuple[int, int, int]: BGR tuple.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> color.as_bgr()
|
||||
(255, 0, 255)
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.Color(r=255, g=255, b=0).as_bgr()
|
||||
# (0, 255, 255)
|
||||
```
|
||||
"""
|
||||
return self.b, self.g, self.r
|
||||
|
||||
@classproperty
|
||||
def WHITE(cls):
|
||||
return Color.from_hex("#FFFFFF")
|
||||
|
||||
@classproperty
|
||||
def BLACK(cls):
|
||||
return Color.from_hex("#000000")
|
||||
|
||||
@classproperty
|
||||
def RED(cls):
|
||||
return Color.from_hex("#FF0000")
|
||||
|
||||
@classproperty
|
||||
def GREEN(cls):
|
||||
return Color.from_hex("#00FF00")
|
||||
|
||||
@classproperty
|
||||
def BLUE(cls):
|
||||
return Color.from_hex("#0000FF")
|
||||
|
||||
@classproperty
|
||||
def YELLOW(cls):
|
||||
return Color.from_hex("#FFFF00")
|
||||
|
||||
@classproperty
|
||||
def ROBOFLOW(cls):
|
||||
return Color.from_hex("#A351FB")
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`Color.white()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.WHITE` instead."
|
||||
)
|
||||
def white(cls) -> Color:
|
||||
return Color.from_hex(color_hex="#ffffff")
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`Color.black()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.BLACK` instead."
|
||||
)
|
||||
def black(cls) -> Color:
|
||||
return Color.from_hex(color_hex="#000000")
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`Color.red()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.RED` instead."
|
||||
)
|
||||
def red(cls) -> Color:
|
||||
return Color.from_hex(color_hex="#ff0000")
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`Color.green()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.GREEN` instead."
|
||||
)
|
||||
def green(cls) -> Color:
|
||||
return Color.from_hex(color_hex="#00ff00")
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`Color.blue()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.BLUE` instead."
|
||||
)
|
||||
def blue(cls) -> Color:
|
||||
return Color.from_hex(color_hex="#0000ff")
|
||||
|
||||
@@ -141,7 +248,57 @@ class Color:
|
||||
class ColorPalette:
|
||||
colors: List[Color]
|
||||
|
||||
@classproperty
|
||||
def DEFAULT(cls) -> ColorPalette:
|
||||
"""
|
||||
Returns a default color palette.
|
||||
|
||||
Returns:
|
||||
ColorPalette: A ColorPalette instance with default colors.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.ColorPalette.DEFAULT
|
||||
# ColorPalette(colors=[Color(r=255, g=64, b=64), Color(r=255, g=161, b=160), ...])
|
||||
```
|
||||
|
||||

|
||||
""" # noqa: E501 // docs
|
||||
return ColorPalette.from_hex(color_hex_list=DEFAULT_COLOR_PALETTE)
|
||||
|
||||
@classproperty
|
||||
def ROBOFLOW(cls) -> ColorPalette:
|
||||
"""
|
||||
Returns a Roboflow color palette.
|
||||
|
||||
Returns:
|
||||
ColorPalette: A ColorPalette instance with Roboflow colors.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.ColorPalette.ROBOFLOW
|
||||
# ColorPalette(colors=[Color(r=194, g=141, b=252), Color(r=163, g=81, b=251), ...])
|
||||
```
|
||||
|
||||

|
||||
""" # noqa: E501 // docs
|
||||
return ColorPalette.from_hex(color_hex_list=ROBOFLOW_COLOR_PALETTE)
|
||||
|
||||
@classproperty
|
||||
def LEGACY(cls) -> ColorPalette:
|
||||
return ColorPalette.from_hex(color_hex_list=LEGACY_COLOR_PALETTE)
|
||||
|
||||
@classmethod
|
||||
@deprecated(
|
||||
"`ColorPalette.default()` is deprecated and will be removed in "
|
||||
"`supervision-0.20.0`. Use `Color.DEFAULT` instead."
|
||||
)
|
||||
def default(cls) -> ColorPalette:
|
||||
"""
|
||||
Returns a default color palette.
|
||||
@@ -150,11 +307,13 @@ class ColorPalette:
|
||||
ColorPalette: A ColorPalette instance with default colors.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.ColorPalette.default()
|
||||
# ColorPalette(colors=[Color(r=255, g=64, b=64), Color(r=255, g=161, b=160), ...])
|
||||
```
|
||||
>>> ColorPalette.default()
|
||||
ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
```
|
||||
"""
|
||||
""" # noqa: E501 // docs
|
||||
return ColorPalette.from_hex(color_hex_list=DEFAULT_COLOR_PALETTE)
|
||||
|
||||
@classmethod
|
||||
@@ -169,14 +328,46 @@ class ColorPalette:
|
||||
ColorPalette: A ColorPalette instance.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
# ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
```
|
||||
"""
|
||||
colors = [Color.from_hex(color_hex) for color_hex in color_hex_list]
|
||||
return cls(colors)
|
||||
|
||||
@classmethod
|
||||
def from_matplotlib(cls, palette_name: str, color_count: int) -> ColorPalette:
|
||||
"""
|
||||
Create a ColorPalette instance from a Matplotlib color palette.
|
||||
|
||||
Args:
|
||||
palette_name (str): Name of the Matplotlib palette.
|
||||
color_count (int): Number of colors to sample from the palette.
|
||||
|
||||
Returns:
|
||||
ColorPalette: A ColorPalette instance.
|
||||
|
||||
Example:
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
sv.ColorPalette.from_matplotlib('viridis', 5)
|
||||
# ColorPalette(colors=[Color(r=68, g=1, b=84), Color(r=59, g=82, b=139), ...])
|
||||
```
|
||||
|
||||

|
||||
""" # noqa: E501 // docs
|
||||
mpl_palette = plt.get_cmap(palette_name, color_count)
|
||||
colors = [
|
||||
Color(int(r * 255), int(g * 255), int(b * 255))
|
||||
for r, g, b, _ in mpl_palette.colors
|
||||
]
|
||||
return cls(colors)
|
||||
|
||||
def by_idx(self, idx: int) -> Color:
|
||||
"""
|
||||
Return the color at a given index in the palette.
|
||||
@@ -188,9 +379,12 @@ class ColorPalette:
|
||||
Color: Color at the given index.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> color_palette.by_idx(1)
|
||||
Color(r=0, g=255, b=0)
|
||||
```python
|
||||
import supervision as sv
|
||||
|
||||
color_palette = sv.ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
color_palette.by_idx(1)
|
||||
# Color(r=0, g=255, b=0)
|
||||
```
|
||||
"""
|
||||
if idx < 0:
|
||||
|
||||
@@ -105,7 +105,7 @@ def draw_text(
|
||||
scene: np.ndarray,
|
||||
text: str,
|
||||
text_anchor: Point,
|
||||
text_color: Color = Color.black(),
|
||||
text_color: Color = Color.BLACK,
|
||||
text_scale: float = 0.5,
|
||||
text_thickness: int = 1,
|
||||
text_padding: int = 10,
|
||||
|
||||
@@ -2,6 +2,7 @@ from __future__ import annotations
|
||||
|
||||
from dataclasses import dataclass
|
||||
from enum import Enum
|
||||
from math import sqrt
|
||||
from typing import Tuple
|
||||
|
||||
|
||||
@@ -43,13 +44,38 @@ class Vector:
|
||||
start: Point
|
||||
end: Point
|
||||
|
||||
def is_in(self, point: Point) -> bool:
|
||||
v1 = Vector(self.start, self.end)
|
||||
v2 = Vector(self.start, point)
|
||||
cross_product = (v1.end.x - v1.start.x) * (v2.end.y - v2.start.y) - (
|
||||
v1.end.y - v1.start.y
|
||||
) * (v2.end.x - v2.start.x)
|
||||
return cross_product < 0
|
||||
@property
|
||||
def magnitude(self) -> float:
|
||||
"""
|
||||
Calculate the magnitude (length) of the vector.
|
||||
|
||||
Returns:
|
||||
float: The magnitude of the vector.
|
||||
"""
|
||||
dx = self.end.x - self.start.x
|
||||
dy = self.end.y - self.start.y
|
||||
return sqrt(dx**2 + dy**2)
|
||||
|
||||
def cross_product(self, point: Point) -> float:
|
||||
"""
|
||||
Calculate the 2D cross product (also known as the vector product or outer
|
||||
product) of the vector and a point, treated as vectors in 2D space.
|
||||
|
||||
Args:
|
||||
point (Point): The point to be evaluated, treated as the endpoint of a
|
||||
vector originating from the 'start' of the main vector.
|
||||
|
||||
Returns:
|
||||
float: The scalar value of the cross product. It is positive if 'point'
|
||||
lies to the left of the vector (when moving from 'start' to 'end'),
|
||||
negative if it lies to the right, and 0 if it is collinear with the
|
||||
vector.
|
||||
"""
|
||||
dx_vector = self.end.x - self.start.x
|
||||
dy_vector = self.end.y - self.start.y
|
||||
dx_point = point.x - self.start.x
|
||||
dy_point = point.y - self.start.y
|
||||
return (dx_vector * dy_point) - (dy_vector * dx_point)
|
||||
|
||||
|
||||
@dataclass
|
||||
|
||||
@@ -16,3 +16,29 @@ def deprecated(reason: str):
|
||||
return wrapper
|
||||
|
||||
return decorator
|
||||
|
||||
|
||||
class classproperty(property):
|
||||
"""
|
||||
A decorator that combines @classmethod and @property.
|
||||
It allows a method to be accessed as a property of the class,
|
||||
rather than an instance, similar to a classmethod.
|
||||
|
||||
Usage:
|
||||
@classproperty
|
||||
def my_method(cls):
|
||||
...
|
||||
"""
|
||||
|
||||
def __get__(self, owner_self: object, owner_cls: type) -> object:
|
||||
"""
|
||||
Override the __get__ method to return the result of the function call.
|
||||
|
||||
Args:
|
||||
owner_self: The instance through which the attribute was accessed, or None.
|
||||
owner_cls: The class through which the attribute was accessed.
|
||||
|
||||
Returns:
|
||||
The result of calling the function stored in 'fget' with 'owner_cls'.
|
||||
"""
|
||||
return self.fget(owner_cls)
|
||||
|
||||
@@ -0,0 +1,72 @@
|
||||
from contextlib import ExitStack as DoesNotRaise
|
||||
from typing import Optional, Tuple
|
||||
|
||||
import pytest
|
||||
|
||||
from supervision import LineZone
|
||||
from supervision.geometry.core import Point, Vector
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"vector, expected_result, exception",
|
||||
[
|
||||
(
|
||||
Vector(start=Point(x=0.0, y=0.0), end=Point(x=0.0, y=0.0)),
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
),
|
||||
(
|
||||
Vector(start=Point(x=1.0, y=1.0), end=Point(x=1.0, y=1.0)),
|
||||
None,
|
||||
pytest.raises(ValueError),
|
||||
),
|
||||
(
|
||||
Vector(start=Point(x=0.0, y=0.0), end=Point(x=0.0, y=4.0)),
|
||||
(
|
||||
Vector(start=Point(x=0.0, y=0.0), end=Point(x=-1.0, y=0.0)),
|
||||
Vector(start=Point(x=0.0, y=4.0), end=Point(x=1.0, y=4.0)),
|
||||
),
|
||||
DoesNotRaise(),
|
||||
),
|
||||
(
|
||||
Vector(Point(0.0, 0.0), Point(4.0, 0.0)),
|
||||
(
|
||||
Vector(start=Point(x=0.0, y=0.0), end=Point(x=0.0, y=1.0)),
|
||||
Vector(start=Point(x=4.0, y=0.0), end=Point(x=4.0, y=-1.0)),
|
||||
),
|
||||
DoesNotRaise(),
|
||||
),
|
||||
(
|
||||
Vector(Point(0.0, 0.0), Point(3.0, 4.0)),
|
||||
(
|
||||
Vector(start=Point(x=0, y=0), end=Point(x=-0.8, y=0.6)),
|
||||
Vector(start=Point(x=3, y=4), end=Point(x=3.8, y=3.4)),
|
||||
),
|
||||
DoesNotRaise(),
|
||||
),
|
||||
(
|
||||
Vector(Point(0.0, 0.0), Point(4.0, 3.0)),
|
||||
(
|
||||
Vector(start=Point(x=0, y=0), end=Point(x=-0.6, y=0.8)),
|
||||
Vector(start=Point(x=4, y=3), end=Point(x=4.6, y=2.2)),
|
||||
),
|
||||
DoesNotRaise(),
|
||||
),
|
||||
(
|
||||
Vector(Point(0.0, 0.0), Point(3.0, -4.0)),
|
||||
(
|
||||
Vector(start=Point(x=0, y=0), end=Point(x=0.8, y=0.6)),
|
||||
Vector(start=Point(x=3, y=-4), end=Point(x=2.2, y=-4.6)),
|
||||
),
|
||||
DoesNotRaise(),
|
||||
),
|
||||
],
|
||||
)
|
||||
def test_calculate_region_of_interest_limits(
|
||||
vector: Vector,
|
||||
expected_result: Optional[Tuple[Vector, Vector]],
|
||||
exception: Exception,
|
||||
) -> None:
|
||||
with exception:
|
||||
result = LineZone.calculate_region_of_interest_limits(vector=vector)
|
||||
assert result == expected_result
|
||||
+12
-12
@@ -9,13 +9,13 @@ from supervision.draw.color import Color
|
||||
@pytest.mark.parametrize(
|
||||
"color_hex, expected_result, exception",
|
||||
[
|
||||
("fff", Color.white(), DoesNotRaise()),
|
||||
("#fff", Color.white(), DoesNotRaise()),
|
||||
("ffffff", Color.white(), DoesNotRaise()),
|
||||
("#ffffff", Color.white(), DoesNotRaise()),
|
||||
("f00", Color.red(), DoesNotRaise()),
|
||||
("0f0", Color.green(), DoesNotRaise()),
|
||||
("00f", Color.blue(), DoesNotRaise()),
|
||||
("fff", Color.WHITE, DoesNotRaise()),
|
||||
("#fff", Color.WHITE, DoesNotRaise()),
|
||||
("ffffff", Color.WHITE, DoesNotRaise()),
|
||||
("#ffffff", Color.WHITE, DoesNotRaise()),
|
||||
("f00", Color.RED, DoesNotRaise()),
|
||||
("0f0", Color.GREEN, DoesNotRaise()),
|
||||
("00f", Color.BLUE, DoesNotRaise()),
|
||||
("#808000", Color(r=128, g=128, b=0), DoesNotRaise()),
|
||||
("", None, pytest.raises(ValueError)),
|
||||
("00", None, pytest.raises(ValueError)),
|
||||
@@ -35,11 +35,11 @@ def test_color_from_hex(
|
||||
@pytest.mark.parametrize(
|
||||
"color, expected_result, exception",
|
||||
[
|
||||
(Color.white(), "#ffffff", DoesNotRaise()),
|
||||
(Color.black(), "#000000", DoesNotRaise()),
|
||||
(Color.red(), "#ff0000", DoesNotRaise()),
|
||||
(Color.green(), "#00ff00", DoesNotRaise()),
|
||||
(Color.blue(), "#0000ff", DoesNotRaise()),
|
||||
(Color.WHITE, "#ffffff", DoesNotRaise()),
|
||||
(Color.BLACK, "#000000", DoesNotRaise()),
|
||||
(Color.RED, "#ff0000", DoesNotRaise()),
|
||||
(Color.GREEN, "#00ff00", DoesNotRaise()),
|
||||
(Color.BLUE, "#0000ff", DoesNotRaise()),
|
||||
(Color(r=128, g=128, b=0), "#808000", DoesNotRaise()),
|
||||
],
|
||||
)
|
||||
|
||||
@@ -0,0 +1,59 @@
|
||||
import pytest
|
||||
|
||||
from supervision.geometry.core import Point, Vector
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"vector, point, expected_result",
|
||||
[
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=-1, y=1), 10.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=6, y=6), 0.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=3, y=6), 15.0),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=-1, y=1), -10.0),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=6, y=6), 0.0),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=3, y=6), -15.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=0), 0.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=-1), -1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=1), 1.0),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=0), 0.0),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=-1), 1.0),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=1), -1.0),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=0, y=0), 2.0),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=1, y=4), 0.0),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=2, y=4), -2.0),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=0, y=0), -2.0),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=1, y=4), 0.0),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=2, y=4), 2.0),
|
||||
],
|
||||
)
|
||||
def test_vector_cross_product(
|
||||
vector: Vector, point: Point, expected_result: float
|
||||
) -> None:
|
||||
result = vector.cross_product(point=point)
|
||||
assert result == expected_result
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"vector, expected_result",
|
||||
[
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=0, y=0)), 0.0),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=1), end=Point(x=0, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=0, y=1)), 1.0),
|
||||
(Vector(start=Point(x=-1, y=0), end=Point(x=0, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=-1), end=Point(x=0, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=-1, y=0)), 1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=0, y=-1)), 1.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=3, y=4)), 5.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=-3, y=4)), 5.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=3, y=-4)), 5.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=-3, y=-4)), 5.0),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=4, y=3)), 5.0),
|
||||
(Vector(start=Point(x=3, y=4), end=Point(x=0, y=0)), 5.0),
|
||||
(Vector(start=Point(x=4, y=3), end=Point(x=0, y=0)), 5.0),
|
||||
],
|
||||
)
|
||||
def test_vector_magnitude(vector: Vector, expected_result: float) -> None:
|
||||
result = vector.magnitude
|
||||
assert result == expected_result
|
||||
@@ -1,31 +0,0 @@
|
||||
import pytest
|
||||
|
||||
from supervision.geometry.core import Point, Vector
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"vector, point, expected_result",
|
||||
[
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=-1, y=1), False),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=6, y=6), False),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=5, y=5)), Point(x=3, y=6), False),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=-1, y=1), True),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=6, y=6), False),
|
||||
(Vector(start=Point(x=5, y=5), end=Point(x=0, y=0)), Point(x=3, y=6), True),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=0), False),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=-1), True),
|
||||
(Vector(start=Point(x=0, y=0), end=Point(x=1, y=0)), Point(x=0, y=1), False),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=0), False),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=-1), False),
|
||||
(Vector(start=Point(x=1, y=0), end=Point(x=0, y=0)), Point(x=0, y=1), True),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=0, y=0), False),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=1, y=4), False),
|
||||
(Vector(start=Point(x=1, y=1), end=Point(x=1, y=3)), Point(x=2, y=4), True),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=0, y=0), True),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=1, y=4), False),
|
||||
(Vector(start=Point(x=1, y=3), end=Point(x=1, y=1)), Point(x=2, y=4), False),
|
||||
],
|
||||
)
|
||||
def test_vector_is_in(vector: Vector, point: Point, expected_result: bool) -> None:
|
||||
result = vector.is_in(point=point)
|
||||
assert result == expected_result
|
||||
Reference in New Issue
Block a user