Merge branch 'develop' into add-classification-annotator
This commit is contained in:
 James
 GitHub
commit
fc9acc456b
|
|
@ -0,0 +1,16 @@
|
|||
version: 2
|
||||
updates:
|
||||
# GitHub Actions
|
||||
- package-ecosystem: "github-actions"
|
||||
directory: "/"
|
||||
schedule:
|
||||
interval: "daily"
|
||||
commit-message:
|
||||
prefix: ⬆️
|
||||
# Python
|
||||
- package-ecosystem: "pip"
|
||||
directory: "/"
|
||||
schedule:
|
||||
interval: "daily"
|
||||
commit-message:
|
||||
prefix: ⬆️
|
||||
|
|
@ -14,7 +14,7 @@ jobs:
|
|||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- name: Clear cache
|
||||
uses: actions/github-script@v6
|
||||
uses: actions/github-script@v7
|
||||
with:
|
||||
script: |
|
||||
console.log("About to clear")
|
||||
|
|
|
|||
|
|
@ -6,11 +6,17 @@ on:
|
|||
- master
|
||||
- main
|
||||
- develop
|
||||
|
||||
permissions:
|
||||
contents: write
|
||||
pages: write
|
||||
pull-requests: write
|
||||
|
||||
jobs:
|
||||
deploy:
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- uses: actions/checkout@v3
|
||||
- uses: actions/checkout@v4
|
||||
- uses: actions/setup-python@v4
|
||||
with:
|
||||
python-version: 3.x
|
||||
|
|
|
|||
|
|
@ -16,7 +16,7 @@ jobs:
|
|||
|
||||
steps:
|
||||
- name: Checkout source
|
||||
uses: actions/checkout@v3
|
||||
uses: actions/checkout@v4
|
||||
|
||||
- name: 🐍 Set up Python 3.8 environment for build
|
||||
uses: actions/setup-python@v4
|
||||
|
|
|
|||
|
|
@ -17,7 +17,7 @@ jobs:
|
|||
python-version: [3.8]
|
||||
steps:
|
||||
- name: 🛎️ Checkout
|
||||
uses: actions/checkout@v3
|
||||
uses: actions/checkout@v4
|
||||
with:
|
||||
ref: ${{ github.head_ref }}
|
||||
- name: 🐍 Set up Python ${{ matrix.python-version }}
|
||||
|
|
|
|||
|
|
@ -12,7 +12,7 @@ jobs:
|
|||
python-version: ["3.8", "3.9", "3.10","3.11"]
|
||||
steps:
|
||||
- name: 🛎️ Checkout
|
||||
uses: actions/checkout@v3
|
||||
uses: actions/checkout@v4
|
||||
- name: 🐍 Set up Python ${{ matrix.python-version }}
|
||||
uses: actions/setup-python@v4
|
||||
# id based on python version
|
||||
|
|
|
|||
|
|
@ -11,7 +11,7 @@ jobs:
|
|||
name: 👋 Welcome
|
||||
runs-on: ubuntu-latest
|
||||
steps:
|
||||
- uses: actions/first-interaction@v1.1.1
|
||||
- uses: actions/first-interaction@v1.2.0
|
||||
with:
|
||||
repo-token: ${{ secrets.GITHUB_TOKEN }}
|
||||
issue-message: "Hello there, thank you for opening an Issue ! 🙏🏻 The team was notified and they will get back to you asap."
|
||||
|
|
|
|||
|
|
@ -11,6 +11,7 @@ repos:
|
|||
hooks:
|
||||
- id: end-of-file-fixer
|
||||
- id: trailing-whitespace
|
||||
exclude: test/.*\.py
|
||||
- id: check-yaml
|
||||
- id: check-docstring-first
|
||||
- id: check-executables-have-shebangs
|
||||
|
|
@ -65,12 +66,12 @@ repos:
|
|||
|
||||
|
||||
- repo: https://github.com/psf/black
|
||||
rev: 23.9.1
|
||||
rev: 23.11.0
|
||||
hooks:
|
||||
- id: black
|
||||
|
||||
- repo: https://github.com/astral-sh/ruff-pre-commit
|
||||
rev: v0.0.292
|
||||
rev: v0.1.6
|
||||
hooks:
|
||||
- id: ruff
|
||||
args: [--fix, --exit-non-zero-on-fix]
|
||||
|
|
|
|||
|
|
@ -24,10 +24,6 @@
|
|||
|
||||
</div>
|
||||
|
||||
<a href="https://github.com/roboflow/supervision/issues?q=is%3Aissue+label%3Ahacktoberfest+">
|
||||
<img width="100%" src="https://media.roboflow.com/open-source/supervision/hacktoberfest-banner-3.png">
|
||||
</a>
|
||||
|
||||
## 👋 hello
|
||||
|
||||
**We write your reusable computer vision tools.** Whether you need to load your dataset from your hard drive, draw detections on an image or video, or count how many detections are in a zone. You can count on us! 🤝
|
||||
|
|
@ -364,5 +360,4 @@ We love your input! Please see our [contributing guide](https://github.com/robof
|
|||
</a>
|
||||
</a>
|
||||
</div>
|
||||
|
||||
</div>
|
||||
|
|
|
|||
|
|
@ -226,7 +226,7 @@
|
|||
"output_type": "stream",
|
||||
"text": [
|
||||
"\u001b[?25l \u001b[90m━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━\u001b[0m \u001b[32m0.0/45.4 kB\u001b[0m \u001b[31m?\u001b[0m eta \u001b[36m-:--:--\u001b[0m\r\u001b[2K \u001b[90m━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━━\u001b[0m \u001b[32m45.4/45.4 kB\u001b[0m \u001b[31m3.4 MB/s\u001b[0m eta \u001b[36m0:00:00\u001b[0m\n",
|
||||
"\u001b[?25h0.15.0\n"
|
||||
"\u001b[?25h0.16.0\n"
|
||||
]
|
||||
}
|
||||
],
|
||||
|
|
@ -540,7 +540,7 @@
|
|||
}
|
||||
],
|
||||
"source": [
|
||||
"mask_annotator = sv.MaskAnnotator(color_map=\"index\")\n",
|
||||
"mask_annotator = sv.MaskAnnotator(color_lookup=sv.ColorLookup.INDEX)\n",
|
||||
"\n",
|
||||
"annotated_image = mask_annotator.annotate(image.copy(), detections=detections)\n",
|
||||
"\n",
|
||||
|
|
|
|||
|
|
@ -82,6 +82,27 @@
|
|||
|
||||
</div>
|
||||
|
||||
=== "Dot"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> dot_annotator = sv.DotAnnotator()
|
||||
>>> annotated_frame = dot_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
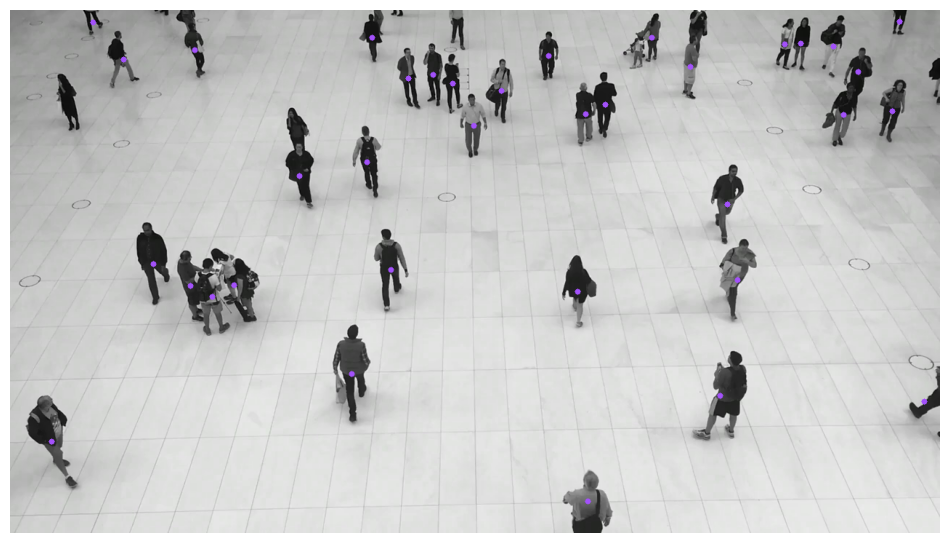{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
=== "Ellipse"
|
||||
|
||||
```python
|
||||
|
|
@ -145,6 +166,27 @@
|
|||
|
||||
</div>
|
||||
|
||||
=== "Polygon"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> polygon_annotator = sv.PolygonAnnotator()
|
||||
>>> annotated_frame = polygon_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
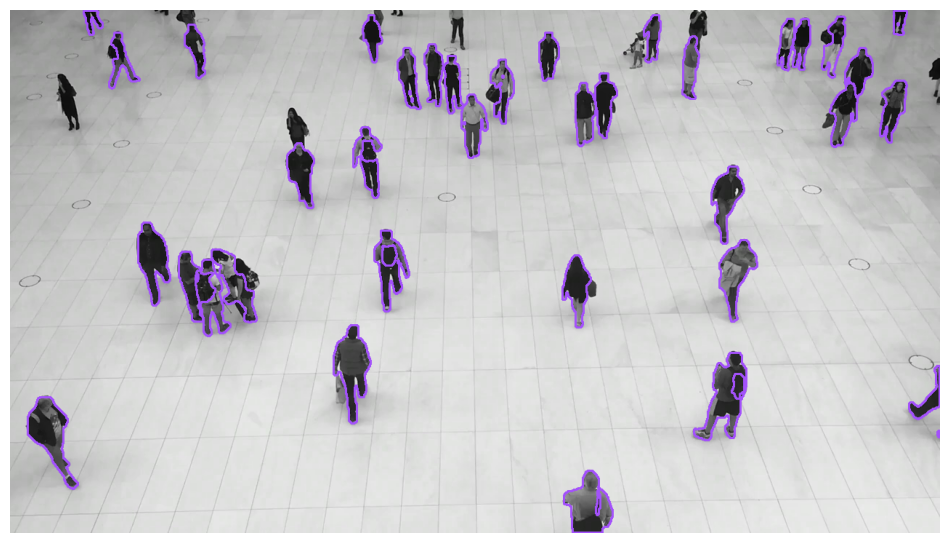{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
=== "Label"
|
||||
|
||||
```python
|
||||
|
|
@ -191,15 +233,25 @@
|
|||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
>>> from ultralytics import YOLO
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
>>> model = YOLO('yolov8x.pt')
|
||||
|
||||
>>> trace_annotator = sv.TraceAnnotator()
|
||||
>>> annotated_frame = trace_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
|
||||
>>> video_info = sv.VideoInfo.from_video_path(video_path='...')
|
||||
>>> frames_generator = get_video_frames_generator(source_path='...')
|
||||
>>> tracker = sv.ByteTrack()
|
||||
|
||||
>>> with sv.VideoSink(target_path='...', video_info=video_info) as sink:
|
||||
... for frame in frames_generator:
|
||||
... result = model(frame)[0]
|
||||
... detections = sv.Detections.from_ultralytics(result)
|
||||
... detections = tracker.update_with_detections(detections)
|
||||
... annotated_frame = trace_annotator.annotate(
|
||||
... scene=frame.copy(),
|
||||
... detections=detections)
|
||||
... sink.write_frame(frame=annotated_frame)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
|
@ -208,6 +260,35 @@
|
|||
|
||||
</div>
|
||||
|
||||
=== "HeatMap"
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
>>> from ultralytics import YOLO
|
||||
|
||||
>>> model = YOLO('yolov8x.pt')
|
||||
|
||||
>>> heat_map_annotator = sv.HeatMapAnnotator()
|
||||
|
||||
>>> video_info = sv.VideoInfo.from_video_path(video_path='...')
|
||||
>>> frames_generator = get_video_frames_generator(source_path='...')
|
||||
|
||||
>>> with sv.VideoSink(target_path='...', video_info=video_info) as sink:
|
||||
... for frame in frames_generator:
|
||||
... result = model(frame)[0]
|
||||
... detections = sv.Detections.from_ultralytics(result)
|
||||
... annotated_frame = heat_map_annotator.annotate(
|
||||
... scene=frame.copy(),
|
||||
... detections=detections)
|
||||
... sink.write_frame(frame=annotated_frame)
|
||||
```
|
||||
|
||||
<div class="result" markdown>
|
||||
|
||||
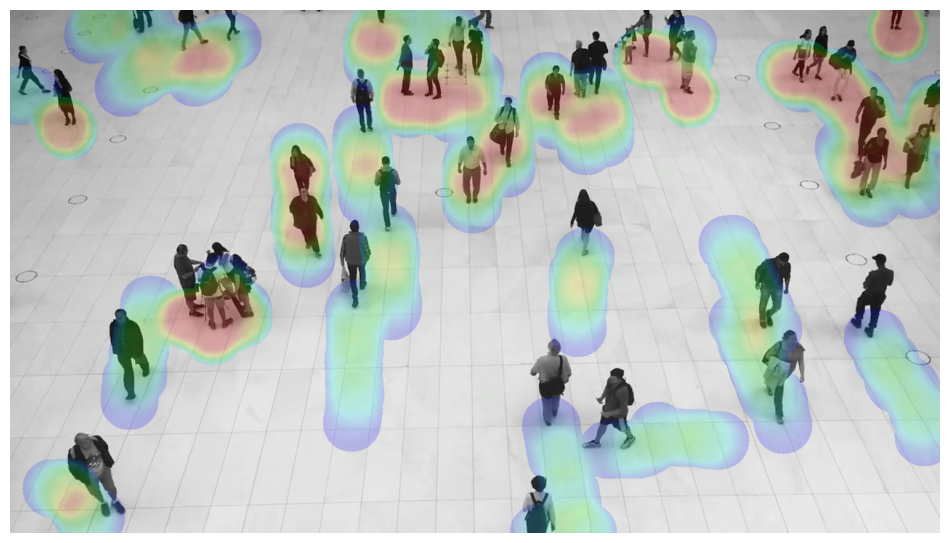{ align=center width="800" }
|
||||
|
||||
</div>
|
||||
|
||||
## BoundingBoxAnnotator
|
||||
|
||||
:::supervision.annotators.core.BoundingBoxAnnotator
|
||||
|
|
@ -224,6 +305,10 @@
|
|||
|
||||
:::supervision.annotators.core.CircleAnnotator
|
||||
|
||||
## DotAnnotator
|
||||
|
||||
:::supervision.annotators.core.DotAnnotator
|
||||
|
||||
## EllipseAnnotator
|
||||
|
||||
:::supervision.annotators.core.EllipseAnnotator
|
||||
|
|
@ -232,10 +317,18 @@
|
|||
|
||||
:::supervision.annotators.core.HaloAnnotator
|
||||
|
||||
## HeatMapAnnotator
|
||||
|
||||
:::supervision.annotators.core.HeatMapAnnotator
|
||||
|
||||
## MaskAnnotator
|
||||
|
||||
:::supervision.annotators.core.MaskAnnotator
|
||||
|
||||
## PolygonAnnotator
|
||||
|
||||
:::supervision.annotators.core.PolygonAnnotator
|
||||
|
||||
## LabelAnnotator
|
||||
|
||||
:::supervision.annotators.core.LabelAnnotator
|
||||
|
|
@ -247,3 +340,7 @@
|
|||
## TraceAnnotator
|
||||
|
||||
:::supervision.annotators.core.TraceAnnotator
|
||||
|
||||
## ColorLookup
|
||||
|
||||
:::supervision.annotators.utils.ColorLookup
|
||||
|
|
|
|||
|
|
@ -0,0 +1,21 @@
|
|||
Supervision offers an assets download utility that allows you to download video files
|
||||
that you can use in your demos.
|
||||
|
||||
## install extra
|
||||
|
||||
To install the Supervision assets utility, you can use `pip`. This utility is available
|
||||
as an extra within the Supervision package.
|
||||
|
||||
!!! example "pip install"
|
||||
|
||||
```bash
|
||||
pip install supervision[assets]
|
||||
```
|
||||
|
||||
## download_assets
|
||||
|
||||
:::supervision.assets.downloader.download_assets
|
||||
|
||||
## VideoAssets
|
||||
|
||||
:::supervision.assets.list.VideoAssets
|
||||
|
|
@ -1,3 +1,47 @@
|
|||
### 0.16.0 <small>October 19, 2023</small>
|
||||
|
||||
- Added [#422](https://github.com/roboflow/supervision/pull/422): [`sv.BoxMaskAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BoxMaskAnnotator) allowing to annotate images and videos with mox masks.
|
||||
|
||||
- Added [#433](https://github.com/roboflow/supervision/pull/433): [`sv.HaloAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.HaloAnnotator) allowing to annotate images and videos with halo effect.
|
||||
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> halo_annotator = sv.HaloAnnotator()
|
||||
>>> annotated_frame = halo_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||
- Added [#466](https://github.com/roboflow/supervision/pull/466): [`sv.HeatMapAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.HeatMapAnnotator) allowing to annotate videos with heat maps.
|
||||
|
||||
- Added [#492](https://github.com/roboflow/supervision/pull/492): [`sv.DotAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.DotAnnotator) allowing to annotate images and videos with dots.
|
||||
|
||||
- Added [#449](https://github.com/roboflow/supervision/pull/449): [`sv.draw_image`](https://supervision.roboflow.com/draw/utils/#supervision.draw.utils.draw_image) allowing to draw an image onto a given scene with specified opacity and dimensions.
|
||||
|
||||
- Added [#280](https://github.com/roboflow/supervision/pull/280): [`sv.FPSMonitor`](https://supervision.roboflow.com/utils/video/#supervision.utils.video.FPSMonitor) for monitoring frames per second (FPS) to benchmark latency.
|
||||
|
||||
- Added [#454](https://github.com/roboflow/supervision/pull/454): 🤗 Hugging Face Annotators [space](https://huggingface.co/spaces/Roboflow/Annotators).
|
||||
|
||||
- Changed [#482](https://github.com/roboflow/supervision/pull/482): [`sv.LineZone.tigger`](https://supervision.roboflow.com/detection/tools/line_zone/#supervision.detection.line_counter.LineZone.trigger) now return `Tuple[np.ndarray, np.ndarray]`. The first array indicates which detections have crossed the line from outside to inside. The second array indicates which detections have crossed the line from inside to outside.
|
||||
|
||||
- Changed [#465](https://github.com/roboflow/supervision/pull/465): Annotator argument name from `color_map: str` to `color_lookup: ColorLookup` enum to increase type safety.
|
||||
|
||||
- Changed [#426](https://github.com/roboflow/supervision/pull/426): [`sv.MaskAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.MaskAnnotator) allowing 2x faster annotation.
|
||||
|
||||
- Fixed [#477](https://github.com/roboflow/supervision/pull/477): Poetry env definition allowing proper local installation.
|
||||
|
||||
- Fixed [#430](https://github.com/roboflow/supervision/pull/430): [`sv.ByteTrack`](https://supervision.roboflow.com/trackers/#supervision.tracker.byte_tracker.core.ByteTrack) to return `np.array([], dtype=int)` when `svDetections` is empty.
|
||||
|
||||
!!! warning
|
||||
|
||||
`sv.Detections.from_yolov8` and `sv.Classifications.from_yolov8` as those are now replaced by [`sv.Detections.from_ultralytics`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_ultralytics) and [`sv.Classifications.from_ultralytics`](https://supervision.roboflow.com/classification/core/#supervision.classification.core.Classifications.from_ultralytics).
|
||||
|
||||
|
||||
### 0.15.0 <small>October 5, 2023</small>
|
||||
|
||||
- Added [#170](https://github.com/roboflow/supervision/pull/170): [`sv.BoundingBoxAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BoundingBoxAnnotator) allowing to annotate images and videos with bounding boxes.
|
||||
|
|
|
|||
|
|
@ -0,0 +1,3 @@
|
|||
## LineZone
|
||||
|
||||
:::supervision.detection.line_counter.LineZone
|
||||
|
|
@ -0,0 +1,7 @@
|
|||
## Color
|
||||
|
||||
:::supervision.draw.color.Color
|
||||
|
||||
## ColorPalette
|
||||
|
||||
:::supervision.draw.color.ColorPalette
|
||||
|
|
@ -17,3 +17,7 @@
|
|||
## draw_text
|
||||
|
||||
:::supervision.draw.utils.draw_text
|
||||
|
||||
## draw_image
|
||||
|
||||
:::supervision.draw.utils.draw_image
|
||||
|
|
|
|||
|
|
@ -1 +1,78 @@
|
|||
🚧 Page under construction.
|
||||
With Supervision, you can easily [annotate](https://supervision.roboflow.com/annotators/) predictions obtained from a variety of object detection and segmentation models. This document outlines how to run inference using the [Ultralytics](https://github.com/ultralytics/ultralytics) YOLOv8 model, load these predictions into Supervision, and annotate the image.
|
||||
|
||||
## Run Inference
|
||||
|
||||
First, you'll need to obtain predictions from your object detection or segmentation model.
|
||||
```python
|
||||
import cv2
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread("image.jpg")
|
||||
results = model(image)[0]
|
||||
```
|
||||
|
||||
## Load Predictions into Supervision
|
||||
|
||||
Now that we have predictions from a model, we can load them into Supervision. We can do so using the [`sv.Detections.from_ultralytics`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_ultralytics) method, which accepts model results from both detection and segmentation models.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
from ultralytics import YOLO
|
||||
import supervision as sv
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread("image.jpg")
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
```
|
||||
|
||||
You can conveniently load predictions from other computer vision frameworks and libraries using:
|
||||
|
||||
- [`from_deepsparse`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_deepsparse) ([Deepsparse](https://github.com/neuralmagic/deepsparse))
|
||||
- [`from_detectron2`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_detectron2) ([Detectron2](https://github.com/facebookresearch/detectron2))
|
||||
- [`from_mmdetection`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_mmdetection) ([MMDetection](https://github.com/open-mmlab/mmdetection))
|
||||
- [`from_roboflow`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_roboflow) ([Roboflow Inference](https://github.com/roboflow/inference))
|
||||
- [`from_sam`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_sam) ([Segment Anything Model](https://github.com/facebookresearch/segment-anything))
|
||||
- [`from_transformers`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_transformers) ([HuggingFace Transformers](https://github.com/huggingface/transformers))
|
||||
- [`from_yolo_nas`](https://supervision.roboflow.com/detection/core/#supervision.detection.core.Detections.from_yolo_nas) ([YOLO-NAS](https://github.com/Deci-AI/super-gradients/blob/master/YOLONAS.md))
|
||||
|
||||
|
||||
## Annotate Image
|
||||
|
||||
Finally, we can annotate the image with the predictions. Since we are working with an object detection model, we will use the [`sv.BoundingBoxAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BoundingBoxAnnotator) and [`sv.LabelAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.LabelAnnotator) classes. If you are running the segmentation model [`sv.MaskAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.MaskAnnotator) is a drop-in replacement for [`sv.BoundingBoxAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.BoundingBoxAnnotator) that will allow you to draw masks instead of boxes.
|
||||
|
||||
```python
|
||||
import cv2
|
||||
from ultralytics import YOLO
|
||||
import supervision as sv
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
image = cv2.imread("image.jpg")
|
||||
results = model(image)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
|
||||
bounding_box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
labels = [
|
||||
results.names[class_id]
|
||||
for class_id
|
||||
in detections.class_id
|
||||
]
|
||||
|
||||
annotated_image = bounding_box_annotator.annotate(
|
||||
scene=image, detections=detections)
|
||||
annotated_image = label_annotator.annotate(
|
||||
scene=annotated_image, detections=detections, labels=labels)
|
||||
```
|
||||
|
||||
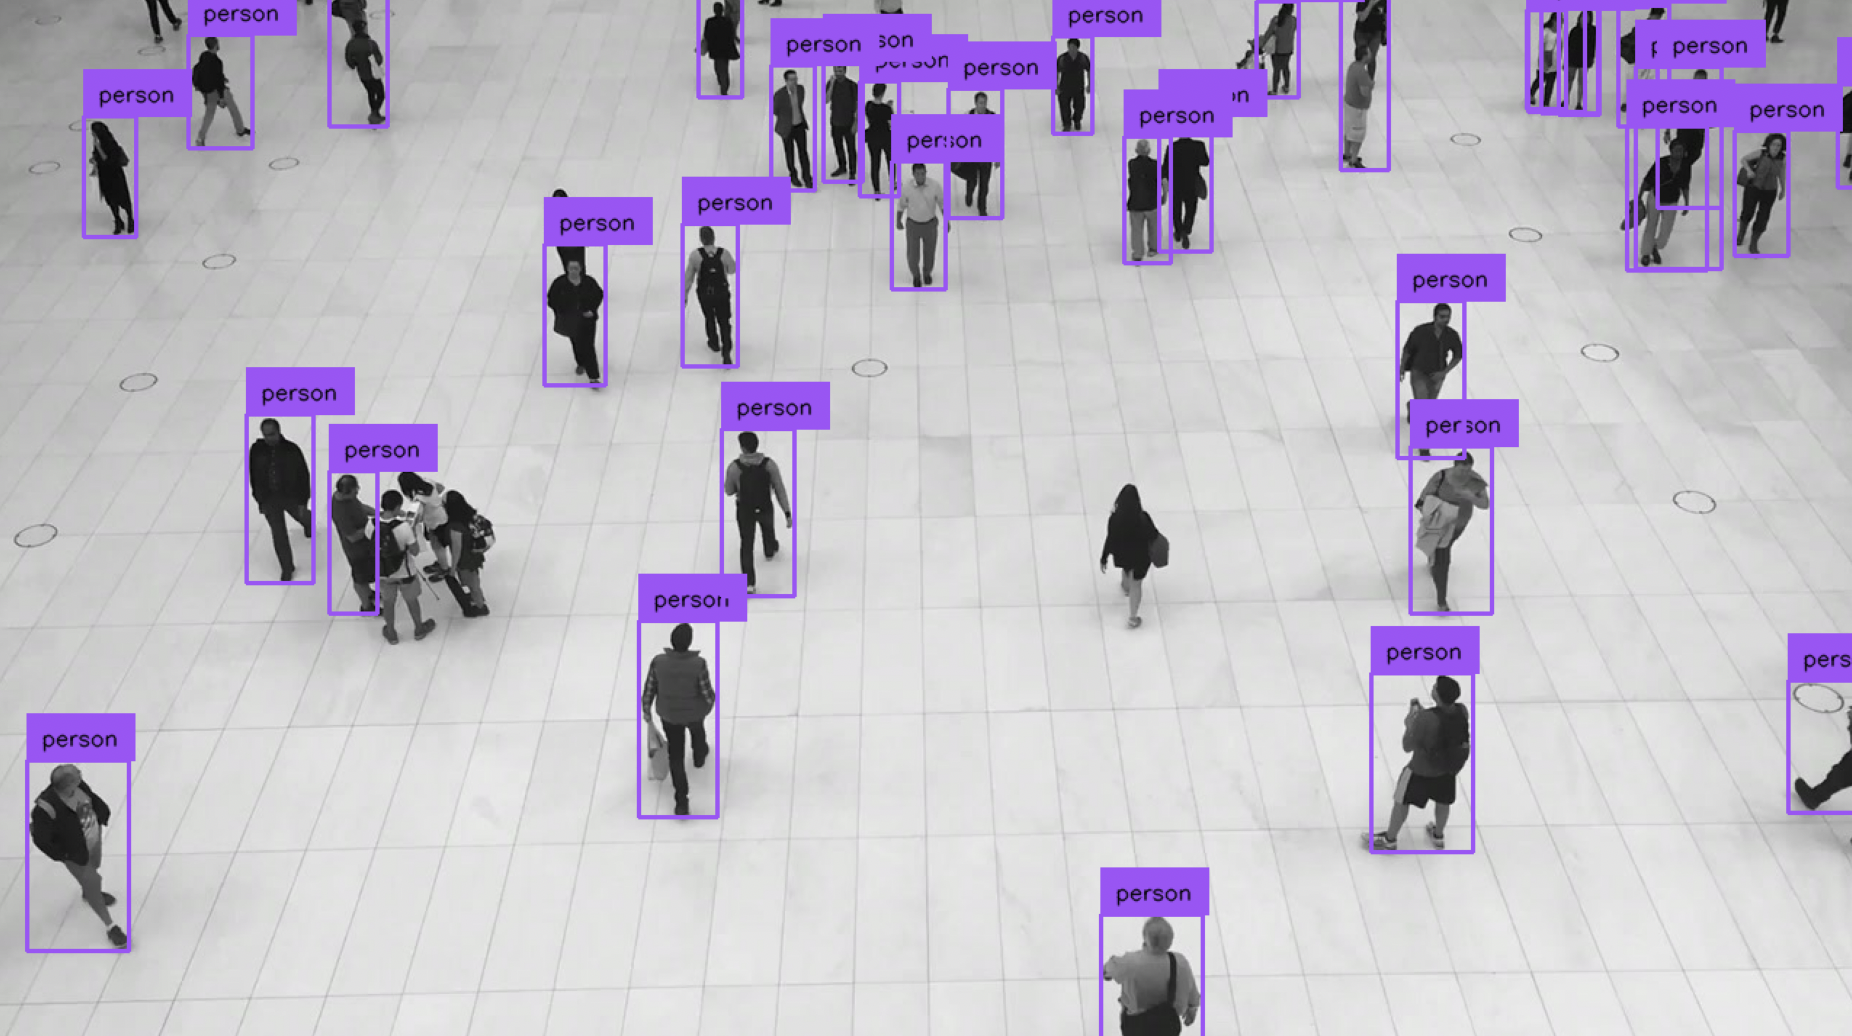
|
||||
|
||||
## Display Annotated Image
|
||||
|
||||
To display the annotated image in Jupyter Notebook or Google Colab, use the [`sv.plot_image`](https://supervision.roboflow.com/utils/notebook/#supervision.utils.notebook.plot_image) function.
|
||||
|
||||
```python
|
||||
sv.plot_image(annotated_image)
|
||||
```
|
||||
|
|
|
|||
|
|
@ -1 +1,183 @@
|
|||
🚧 Page under construction.
|
||||
Utilize Supervision to elevate your video analysis capabilities by effortlessly
|
||||
[tracking](https://supervision.roboflow.com/trackers/) objects identified by various
|
||||
object detection and segmentation models. This guide will walk you through the process
|
||||
of running inference using the [Ultralytics](https://github.com/ultralytics/ultralytics)
|
||||
YOLOv8 model, subsequently tracking these objects, and annotating the video.
|
||||
|
||||
To make it easier for you to follow our tutorial download the video we will use as an
|
||||
example. You can do this using
|
||||
[`supervision[assets]`](https://supervision.roboflow.com/assets/) extension.
|
||||
|
||||
```python
|
||||
from supervision.assets import download_assets, VideoAssets
|
||||
|
||||
download_assets(VideoAssets.PEOPLE_WALKING)
|
||||
```
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision/video-examples/people-walking.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
## Run Inference
|
||||
|
||||
First, you'll need to obtain predictions from your object detection or segmentation
|
||||
model. In this tutorial, we are using the YOLOv8 model as an example. However,
|
||||
Supervision is versatile and compatible with various models. Check this
|
||||
[link](https://supervision.roboflow.com/how_to/detect_and_annotate/#load-predictions-into-supervision)
|
||||
for guidance on how to plug in other models.
|
||||
|
||||
We will define a `callback` function, which will process each frame of the video
|
||||
by obtaining model predictions and then annotating the frame based on these predictions.
|
||||
This `callback` function will be essential in the subsequent steps of the tutorial, as
|
||||
it will be modified to include tracking, labeling, and trace annotations.
|
||||
|
||||
```{ .py }
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
box_annotator = sv.BoundingBoxAnnotator()
|
||||
|
||||
def callback(frame: np.ndarray, _: int) -> np.ndarray:
|
||||
results = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
return box_annotator.annotate(frame.copy(), detections=detections)
|
||||
|
||||
sv.process_video(
|
||||
source_path="people-walking.mp4",
|
||||
target_path="result.mp4",
|
||||
callback=callback
|
||||
)
|
||||
```
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision/video-examples/how-to/track-objects/run-inference.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
## Tracking
|
||||
|
||||
After running inference and obtaining predictions, the next step is to track the
|
||||
detected objects throughout the video. Utilizing Supervision’s
|
||||
[`sv.ByteTrack`](https://supervision.roboflow.com/trackers/#supervision.tracker.byte_tracker.core.ByteTrack)
|
||||
functionality, each detected object is assigned a unique tracker ID,
|
||||
enabling the continuous following of the object's motion path across different frames.
|
||||
|
||||
```{ .py hl_lines="6 12" }
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
tracker = sv.ByteTrack()
|
||||
box_annotator = sv.BoundingBoxAnnotator()
|
||||
|
||||
def callback(frame: np.ndarray, _: int) -> np.ndarray:
|
||||
results = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
detections = tracker.update_with_detections(detections)
|
||||
return box_annotator.annotate(frame.copy(), detections=detections)
|
||||
|
||||
sv.process_video(
|
||||
source_path="people-walking.mp4",
|
||||
target_path="result.mp4",
|
||||
callback=callback
|
||||
)
|
||||
```
|
||||
|
||||
## Annotate Video with Tracking IDs
|
||||
|
||||
Annotating the video with tracking IDs helps in distinguishing and following each object
|
||||
distinctly. With the
|
||||
[`sv.LabelAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.LabelAnnotator)
|
||||
in Supervision, we can overlay the tracker IDs and class labels on the detected objects,
|
||||
offering a clear visual representation of each object's class and unique identifier.
|
||||
|
||||
```{ .py hl_lines="8 15-19 23-24" }
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
tracker = sv.ByteTrack()
|
||||
box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
|
||||
def callback(frame: np.ndarray, _: int) -> np.ndarray:
|
||||
results = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
labels = [
|
||||
f"#{tracker_id} {results.names[class_id]}"
|
||||
for class_id, tracker_id
|
||||
in zip(detections.class_id, detections.tracker_id)
|
||||
]
|
||||
|
||||
annotated_frame = box_annotator.annotate(
|
||||
frame.copy(), detections=detections)
|
||||
return label_annotator.annotate(
|
||||
annotated_frame, detections=detections, labels=labels)
|
||||
|
||||
sv.process_video(
|
||||
source_path="people-walking.mp4",
|
||||
target_path="result.mp4",
|
||||
callback=callback
|
||||
)
|
||||
```
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision/video-examples/how-to/track-objects/annotate-video-with-tracking-ids.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
## Annotate Video with Traces
|
||||
|
||||
Adding traces to the video involves overlaying the historical paths of the detected
|
||||
objects. This feature, powered by the
|
||||
[`sv.TraceAnnotator`](https://supervision.roboflow.com/annotators/#supervision.annotators.core.TraceAnnotator),
|
||||
allows for visualizing the trajectories of objects, helping in understanding the
|
||||
movement patterns and interactions between objects in the video.
|
||||
|
||||
```{ .py hl_lines="9 26-27" }
|
||||
import numpy as np
|
||||
import supervision as sv
|
||||
from ultralytics import YOLO
|
||||
|
||||
model = YOLO("yolov8n.pt")
|
||||
tracker = sv.ByteTrack()
|
||||
box_annotator = sv.BoundingBoxAnnotator()
|
||||
label_annotator = sv.LabelAnnotator()
|
||||
trace_annotator = sv.TraceAnnotator()
|
||||
|
||||
def callback(frame: np.ndarray, _: int) -> np.ndarray:
|
||||
results = model(frame)[0]
|
||||
detections = sv.Detections.from_ultralytics(results)
|
||||
detections = tracker.update_with_detections(detections)
|
||||
|
||||
labels = [
|
||||
f"#{tracker_id} {results.names[class_id]}"
|
||||
for class_id, tracker_id
|
||||
in zip(detections.class_id, detections.tracker_id)
|
||||
]
|
||||
|
||||
annotated_frame = box_annotator.annotate(
|
||||
frame.copy(), detections=detections)
|
||||
annotated_frame = label_annotator.annotate(
|
||||
annotated_frame, detections=detections, labels=labels)
|
||||
return trace_annotator.annotate(
|
||||
annotated_frame, detections=detections)
|
||||
|
||||
sv.process_video(
|
||||
source_path="people-walking.mp4",
|
||||
target_path="result.mp4",
|
||||
callback=callback
|
||||
)
|
||||
```
|
||||
|
||||
<video controls>
|
||||
<source src="https://media.roboflow.com/supervision/video-examples/how-to/track-objects/annotate-video-with-traces.mp4" type="video/mp4">
|
||||
</video>
|
||||
|
||||
This structured walkthrough should give a detailed pathway to annotate videos
|
||||
effectively using Supervision’s various functionalities, including object tracking and
|
||||
trace annotations.
|
||||
|
|
|
|||
|
|
@ -63,7 +63,7 @@ You can install `supervision` with pip in a
|
|||
cd supervision
|
||||
|
||||
# setup python environment and activate it
|
||||
poetry env use python 3.10
|
||||
poetry env use python3.10
|
||||
poetry shell
|
||||
|
||||
# headless install
|
||||
|
|
|
|||
|
|
@ -0,0 +1,10 @@
|
|||
document.addEventListener("DOMContentLoaded", function () {
|
||||
var script = document.createElement("script");
|
||||
script.src = "https://widget.kapa.ai/kapa-widget.bundle.js";
|
||||
script.setAttribute("data-website-id", "e83c5c60-2968-410b-a2da-08fb104f23df");
|
||||
script.setAttribute("data-project-name", "Roboflow");
|
||||
script.setAttribute("data-project-color", "#6405C9");
|
||||
script.setAttribute("data-project-logo", "https://media.roboflow.com/chat.png");
|
||||
script.async = true;
|
||||
document.head.appendChild(script);
|
||||
});
|
||||
|
|
@ -1,5 +1,5 @@
|
|||
site_name: Supervision
|
||||
site_url: https://roboflow.github.io/supervision
|
||||
site_url: https://supervision.roboflow.com/
|
||||
site_author: Roboflow
|
||||
site_description: A set of easy-to-use utils that will come in handy in any Computer Vision project
|
||||
repo_name: roboflow/supervision
|
||||
|
|
@ -39,6 +39,7 @@ nav:
|
|||
- Core: detection/core.md
|
||||
- Utils: detection/utils.md
|
||||
- Tools:
|
||||
- Line Zone: detection/tools/line_zone.md
|
||||
- Polygon Zone: detection/tools/polygon_zone.md
|
||||
- Inference Slicer: detection/tools/inference_slicer.md
|
||||
- Annotators: annotators.md
|
||||
|
|
@ -47,12 +48,14 @@ nav:
|
|||
- Metrics:
|
||||
- Object Detection: metrics/detection.md
|
||||
- Draw:
|
||||
- Color: draw/color.md
|
||||
- Utils: draw/utils.md
|
||||
- Utils:
|
||||
- Video: utils/video.md
|
||||
- Image: utils/image.md
|
||||
- Notebook: utils/notebook.md
|
||||
- File: utils/file.md
|
||||
- Assets: assets.md
|
||||
- Changelog: changelog.md
|
||||
|
||||
theme:
|
||||
|
|
@ -91,3 +94,7 @@ markdown_extensions:
|
|||
alternate_style: true
|
||||
- toc:
|
||||
permalink: true
|
||||
|
||||
extra_javascript:
|
||||
- "https://widget.kapa.ai/kapa-widget.bundle.js"
|
||||
- "javascript/init_kapa_widget.js"
|
||||
|
|
|
|||
File diff suppressed because it is too large
Load Diff
|
|
@ -1,6 +1,6 @@
|
|||
[tool.poetry]
|
||||
name = "supervision"
|
||||
version = "0.16.0rc2"
|
||||
version = "0.17.0rc4"
|
||||
description = "A set of easy-to-use utils that will come in handy in any Computer Vision project"
|
||||
authors = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
maintainers = ["Piotr Skalski <piotr.skalski92@gmail.com>"]
|
||||
|
|
@ -43,19 +43,21 @@ pillow = ">=9.4,<11.0"
|
|||
opencv-python = { version = "^4.8.0.74", optional = true }
|
||||
opencv-python-headless = "^4.8.0.74"
|
||||
scipy = "^1.9.0"
|
||||
requests = { version = "^2.31.0", optional = true }
|
||||
tqdm = { version = "^4.66.1", optional = true }
|
||||
|
||||
|
||||
[tool.poetry.extras]
|
||||
desktop = ["opencv-python"]
|
||||
|
||||
assets = ["requests","tqdm"]
|
||||
|
||||
[tool.poetry.group.dev.dependencies]
|
||||
twine = "^4.0.2"
|
||||
pytest = "^7.2.2"
|
||||
wheel = "^0.40.0"
|
||||
notebook = "^6.5.3"
|
||||
build = "^0.10.0"
|
||||
ruff = "^0.0.280"
|
||||
wheel = ">=0.40,<0.42"
|
||||
notebook = ">=6.5.3,<8.0.0"
|
||||
build = ">=0.10,<1.1"
|
||||
ruff = ">=0.0.280,<0.1.7"
|
||||
isort = "^5.12.0"
|
||||
black = "^23.7.0"
|
||||
mypy = "^1.4.1"
|
||||
|
|
@ -65,7 +67,7 @@ flake8 = { version = "*", python = ">=3.8.1,<3.12.0" }
|
|||
|
||||
[tool.poetry.group.docs.dependencies]
|
||||
mkdocs-material = "^9.1.4"
|
||||
mkdocstrings = {extras = ["python"], version = "^0.20.0"}
|
||||
mkdocstrings = {extras = ["python"], version = ">=0.20,<0.25"}
|
||||
|
||||
[tool.flake8]
|
||||
exclude = ".venv"
|
||||
|
|
@ -79,6 +81,7 @@ extend-ignore = """
|
|||
"""
|
||||
per-file-ignores = """
|
||||
__init__.py: F401
|
||||
supervision/assets/list.py: E501
|
||||
"""
|
||||
|
||||
[tool.isort]
|
||||
|
|
@ -149,6 +152,7 @@ exclude = [
|
|||
"yarn-error.log",
|
||||
"yarn.lock",
|
||||
"docs",
|
||||
"supervision/assets/list.py"
|
||||
]
|
||||
|
||||
# Same as Black.
|
||||
|
|
@ -167,6 +171,8 @@ convention = "google"
|
|||
|
||||
[tool.ruff.per-file-ignores]
|
||||
"__init__.py" = ["E402","F401"]
|
||||
"supervision/assets/list.py" = ["E501"]
|
||||
|
||||
|
||||
[tool.ruff.pylint]
|
||||
max-args = 20
|
||||
|
|
|
|||
|
|
@ -13,10 +13,13 @@ from supervision.annotators.core import (
|
|||
BoxMaskAnnotator,
|
||||
CircleAnnotator,
|
||||
ClassificationAnnotator,
|
||||
DotAnnotator,
|
||||
EllipseAnnotator,
|
||||
HaloAnnotator,
|
||||
HeatMapAnnotator,
|
||||
LabelAnnotator,
|
||||
MaskAnnotator,
|
||||
PolygonAnnotator,
|
||||
TraceAnnotator,
|
||||
)
|
||||
from supervision.annotators.utils import ColorLookup
|
||||
|
|
@ -33,6 +36,7 @@ from supervision.detection.tools.inference_slicer import InferenceSlicer
|
|||
from supervision.detection.tools.polygon_zone import PolygonZone, PolygonZoneAnnotator
|
||||
from supervision.detection.utils import (
|
||||
box_iou_batch,
|
||||
calculate_masks_centroids,
|
||||
filter_polygons_by_area,
|
||||
mask_to_polygons,
|
||||
mask_to_xyxy,
|
||||
|
|
@ -41,7 +45,14 @@ from supervision.detection.utils import (
|
|||
polygon_to_xyxy,
|
||||
)
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.draw.utils import draw_filled_rectangle, draw_polygon, draw_text
|
||||
from supervision.draw.utils import (
|
||||
draw_filled_rectangle,
|
||||
draw_image,
|
||||
draw_line,
|
||||
draw_polygon,
|
||||
draw_rectangle,
|
||||
draw_text,
|
||||
)
|
||||
from supervision.geometry.core import Point, Position, Rect
|
||||
from supervision.geometry.utils import get_polygon_center
|
||||
from supervision.metrics.detection import ConfusionMatrix, MeanAveragePrecision
|
||||
|
|
|
|||
|
|
@ -8,7 +8,9 @@ from supervision.annotators.base import BaseAnnotator
|
|||
from supervision.annotators.utils import ColorLookup, Trace, resolve_color
|
||||
from supervision.classification.core import Classifications
|
||||
from supervision.detection.core import Detections
|
||||
from supervision.detection.utils import clip_boxes, mask_to_polygons
|
||||
from supervision.draw.color import Color, ColorPalette
|
||||
from supervision.draw.utils import draw_polygon
|
||||
from supervision.geometry.core import Position
|
||||
|
||||
|
||||
|
|
@ -29,7 +31,7 @@ class BoundingBoxAnnotator(BaseAnnotator):
|
|||
annotating detections.
|
||||
thickness (int): Thickness of the bounding box lines.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.thickness: int = thickness
|
||||
|
|
@ -51,7 +53,7 @@ class BoundingBoxAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -93,6 +95,10 @@ class BoundingBoxAnnotator(BaseAnnotator):
|
|||
class MaskAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing masks on an image using provided detections.
|
||||
|
||||
!!! warning
|
||||
|
||||
This annotator utilizes the `sv.Detections.mask`.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
|
|
@ -107,7 +113,7 @@ class MaskAnnotator(BaseAnnotator):
|
|||
annotating detections.
|
||||
opacity (float): Opacity of the overlay mask. Must be between `0` and `1`.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.opacity = opacity
|
||||
|
|
@ -129,7 +135,7 @@ class MaskAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -151,6 +157,8 @@ class MaskAnnotator(BaseAnnotator):
|
|||
if detections.mask is None:
|
||||
return scene
|
||||
|
||||
colored_mask = np.array(scene, copy=True, dtype=np.uint8)
|
||||
|
||||
for detection_idx in np.flip(np.argsort(detections.area)):
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
|
|
@ -161,11 +169,94 @@ class MaskAnnotator(BaseAnnotator):
|
|||
else custom_color_lookup,
|
||||
)
|
||||
mask = detections.mask[detection_idx]
|
||||
colored_mask = np.zeros_like(scene, dtype=np.uint8)
|
||||
colored_mask[:] = color.as_bgr()
|
||||
scene[mask] = cv2.addWeighted(
|
||||
colored_mask, self.opacity, scene, 1 - self.opacity, 0
|
||||
)[mask]
|
||||
colored_mask[mask] = color.as_bgr()
|
||||
|
||||
scene = cv2.addWeighted(colored_mask, self.opacity, scene, 1 - self.opacity, 0)
|
||||
return scene.astype(np.uint8)
|
||||
|
||||
|
||||
class PolygonAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing polygons on an image using provided detections.
|
||||
|
||||
!!! warning
|
||||
|
||||
This annotator utilizes the `sv.Detections.mask`.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, ColorPalette]): The color or color palette to use for
|
||||
annotating detections.
|
||||
thickness (int): Thickness of the polygon lines.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.thickness: int = thickness
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
def annotate(
|
||||
self,
|
||||
scene: np.ndarray,
|
||||
detections: Detections,
|
||||
custom_color_lookup: Optional[np.ndarray] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Annotates the given scene with polygons based on the provided detections.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image where polygons will be drawn.
|
||||
detections (Detections): Object detections to annotate.
|
||||
custom_color_lookup (Optional[np.ndarray]): Custom color lookup array.
|
||||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> polygon_annotator = sv.PolygonAnnotator()
|
||||
>>> annotated_frame = polygon_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
if detections.mask is None:
|
||||
return scene
|
||||
|
||||
for detection_idx in range(len(detections)):
|
||||
mask = detections.mask[detection_idx]
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
detections=detections,
|
||||
detection_idx=detection_idx,
|
||||
color_lookup=self.color_lookup
|
||||
if custom_color_lookup is None
|
||||
else custom_color_lookup,
|
||||
)
|
||||
for polygon in mask_to_polygons(mask=mask):
|
||||
scene = draw_polygon(
|
||||
scene=scene,
|
||||
polygon=polygon,
|
||||
color=color,
|
||||
thickness=self.thickness,
|
||||
)
|
||||
|
||||
return scene
|
||||
|
||||
|
|
@ -187,7 +278,7 @@ class BoxMaskAnnotator(BaseAnnotator):
|
|||
annotating detections.
|
||||
opacity (float): Opacity of the overlay mask. Must be between `0` and `1`.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
|
@ -209,7 +300,7 @@ class BoxMaskAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -255,6 +346,10 @@ class BoxMaskAnnotator(BaseAnnotator):
|
|||
class HaloAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing Halos on an image using provided detections.
|
||||
|
||||
!!! warning
|
||||
|
||||
This annotator utilizes the `sv.Detections.mask`.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
|
|
@ -272,7 +367,7 @@ class HaloAnnotator(BaseAnnotator):
|
|||
kernel_size (int): The size of the average pooling kernel used for creating
|
||||
the halo.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.opacity = opacity
|
||||
|
|
@ -295,7 +390,7 @@ class HaloAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -365,7 +460,7 @@ class EllipseAnnotator(BaseAnnotator):
|
|||
start_angle (int): Starting angle of the ellipse.
|
||||
end_angle (int): Ending angle of the ellipse.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.thickness: int = thickness
|
||||
|
|
@ -389,7 +484,7 @@ class EllipseAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -453,7 +548,7 @@ class BoxCornerAnnotator(BaseAnnotator):
|
|||
thickness (int): Thickness of the corner lines.
|
||||
corner_length (int): Length of each corner line.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.thickness: int = thickness
|
||||
|
|
@ -476,7 +571,7 @@ class BoxCornerAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -537,7 +632,7 @@ class CircleAnnotator(BaseAnnotator):
|
|||
annotating detections.
|
||||
thickness (int): Thickness of the circle line.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
|
|
@ -560,7 +655,7 @@ class CircleAnnotator(BaseAnnotator):
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -603,6 +698,83 @@ class CircleAnnotator(BaseAnnotator):
|
|||
return scene
|
||||
|
||||
|
||||
class DotAnnotator(BaseAnnotator):
|
||||
"""
|
||||
A class for drawing dots on an image at specific coordinates based on provided
|
||||
detections.
|
||||
"""
|
||||
|
||||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
radius: int = 4,
|
||||
position: Position = Position.CENTER,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
):
|
||||
"""
|
||||
Args:
|
||||
color (Union[Color, ColorPalette]): The color or color palette to use for
|
||||
annotating detections.
|
||||
radius (int): Radius of the drawn dots.
|
||||
position (Position): The anchor position for placing the dot.
|
||||
color_lookup (ColorLookup): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.radius: int = radius
|
||||
self.position: Position = position
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
def annotate(
|
||||
self,
|
||||
scene: np.ndarray,
|
||||
detections: Detections,
|
||||
custom_color_lookup: Optional[np.ndarray] = None,
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Annotates the given scene with dots based on the provided detections.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image where dots will be drawn.
|
||||
detections (Detections): Object detections to annotate.
|
||||
custom_color_lookup (Optional[np.ndarray]): Custom color lookup array.
|
||||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> dot_annotator = sv.DotAnnotator()
|
||||
>>> annotated_frame = dot_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
xy = detections.get_anchors_coordinates(anchor=self.position)
|
||||
for detection_idx in range(len(detections)):
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
detections=detections,
|
||||
detection_idx=detection_idx,
|
||||
color_lookup=self.color_lookup
|
||||
if custom_color_lookup is None
|
||||
else custom_color_lookup,
|
||||
)
|
||||
center = (int(xy[detection_idx, 0]), int(xy[detection_idx, 1]))
|
||||
cv2.circle(scene, center, self.radius, color.as_bgr(), -1)
|
||||
return scene
|
||||
|
||||
|
||||
class LabelAnnotator:
|
||||
"""
|
||||
A class for annotating labels on an image using provided detections.
|
||||
|
|
@ -629,56 +801,53 @@ class LabelAnnotator:
|
|||
text_position (Position): Position of the text relative to the detection.
|
||||
Possible values are defined in the `Position` enum.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.text_color: Color = text_color
|
||||
self.text_scale: float = text_scale
|
||||
self.text_thickness: int = text_thickness
|
||||
self.text_padding: int = text_padding
|
||||
self.text_position: Position = text_position
|
||||
self.text_anchor: Position = text_position
|
||||
self.color_lookup: ColorLookup = color_lookup
|
||||
|
||||
@staticmethod
|
||||
def resolve_text_background_xyxy(
|
||||
detection_xyxy: Tuple[int, int, int, int],
|
||||
center_coordinates: Tuple[int, int],
|
||||
text_wh: Tuple[int, int],
|
||||
text_padding: int,
|
||||
position: Position,
|
||||
) -> Tuple[int, int, int, int]:
|
||||
padded_text_wh = (text_wh[0] + 2 * text_padding, text_wh[1] + 2 * text_padding)
|
||||
x1, y1, x2, y2 = detection_xyxy
|
||||
center_x = (x1 + x2) // 2
|
||||
center_y = (y1 + y2) // 2
|
||||
center_x, center_y = center_coordinates
|
||||
text_w, text_h = text_wh
|
||||
|
||||
if position == Position.TOP_LEFT:
|
||||
return x1, y1 - padded_text_wh[1], x1 + padded_text_wh[0], y1
|
||||
return center_x, center_y - text_h, center_x + text_w, center_y
|
||||
elif position == Position.TOP_RIGHT:
|
||||
return x2 - padded_text_wh[0], y1 - padded_text_wh[1], x2, y1
|
||||
return center_x - text_w, center_y - text_h, center_x, center_y
|
||||
elif position == Position.TOP_CENTER:
|
||||
return (
|
||||
center_x - padded_text_wh[0] // 2,
|
||||
y1 - padded_text_wh[1],
|
||||
center_x + padded_text_wh[0] // 2,
|
||||
y1,
|
||||
center_x - text_w // 2,
|
||||
center_y - text_h,
|
||||
center_x + text_w // 2,
|
||||
center_y,
|
||||
)
|
||||
elif position == Position.CENTER:
|
||||
elif position == Position.CENTER or position == Position.CENTER_OF_MASS:
|
||||
return (
|
||||
center_x - padded_text_wh[0] // 2,
|
||||
center_y - padded_text_wh[1] // 2,
|
||||
center_x + padded_text_wh[0] // 2,
|
||||
center_y + padded_text_wh[1] // 2,
|
||||
center_x - text_w // 2,
|
||||
center_y - text_h // 2,
|
||||
center_x + text_w // 2,
|
||||
center_y + text_h // 2,
|
||||
)
|
||||
elif position == Position.BOTTOM_LEFT:
|
||||
return x1, y2, x1 + padded_text_wh[0], y2 + padded_text_wh[1]
|
||||
return center_x, center_y, center_x + text_w, center_y + text_h
|
||||
elif position == Position.BOTTOM_RIGHT:
|
||||
return x2 - padded_text_wh[0], y2, x2, y2 + padded_text_wh[1]
|
||||
return center_x - text_w, center_y, center_x, center_y + text_h
|
||||
elif position == Position.BOTTOM_CENTER:
|
||||
return (
|
||||
center_x - padded_text_wh[0] // 2,
|
||||
y2,
|
||||
center_x + padded_text_wh[0] // 2,
|
||||
y2 + padded_text_wh[1],
|
||||
center_x - text_w // 2,
|
||||
center_y,
|
||||
center_x + text_w // 2,
|
||||
center_y + text_h,
|
||||
)
|
||||
|
||||
def annotate(
|
||||
|
|
@ -699,7 +868,7 @@ class LabelAnnotator:
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -719,8 +888,10 @@ class LabelAnnotator:
|
|||
supervision-annotator-examples/label-annotator-example-purple.png)
|
||||
"""
|
||||
font = cv2.FONT_HERSHEY_SIMPLEX
|
||||
for detection_idx in range(len(detections)):
|
||||
detection_xyxy = detections.xyxy[detection_idx].astype(int)
|
||||
anchors_coordinates = detections.get_anchors_coordinates(
|
||||
anchor=self.text_anchor
|
||||
).astype(int)
|
||||
for detection_idx, center_coordinates in enumerate(anchors_coordinates):
|
||||
color = resolve_color(
|
||||
color=self.color,
|
||||
detections=detections,
|
||||
|
|
@ -734,22 +905,22 @@ class LabelAnnotator:
|
|||
if (labels is None or len(detections) != len(labels))
|
||||
else labels[detection_idx]
|
||||
)
|
||||
text_wh = cv2.getTextSize(
|
||||
text_w, text_h = cv2.getTextSize(
|
||||
text=text,
|
||||
fontFace=font,
|
||||
fontScale=self.text_scale,
|
||||
thickness=self.text_thickness,
|
||||
)[0]
|
||||
|
||||
text_w_padded = text_w + 2 * self.text_padding
|
||||
text_h_padded = text_h + 2 * self.text_padding
|
||||
text_background_xyxy = self.resolve_text_background_xyxy(
|
||||
detection_xyxy=detection_xyxy,
|
||||
text_wh=text_wh,
|
||||
text_padding=self.text_padding,
|
||||
position=self.text_position,
|
||||
center_coordinates=tuple(center_coordinates),
|
||||
text_wh=(text_w_padded, text_h_padded),
|
||||
position=self.text_anchor,
|
||||
)
|
||||
|
||||
text_x = text_background_xyxy[0] + self.text_padding
|
||||
text_y = text_background_xyxy[1] + self.text_padding + text_wh[1]
|
||||
text_y = text_background_xyxy[1] + self.text_padding + text_h
|
||||
|
||||
cv2.rectangle(
|
||||
img=scene,
|
||||
|
|
@ -796,7 +967,7 @@ class BlurAnnotator(BaseAnnotator):
|
|||
detections (Detections): Object detections to annotate.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The annotated image.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
|
|
@ -806,7 +977,7 @@ class BlurAnnotator(BaseAnnotator):
|
|||
>>> detections = sv.Detections(...)
|
||||
|
||||
>>> blur_annotator = sv.BlurAnnotator()
|
||||
>>> annotated_frame = blur_annotator.annotate(
|
||||
>>> annotated_frame = circle_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
|
|
@ -815,10 +986,13 @@ class BlurAnnotator(BaseAnnotator):
|
|||

|
||||
"""
|
||||
for detection_idx in range(len(detections)):
|
||||
x1, y1, x2, y2 = detections.xyxy[detection_idx].astype(int)
|
||||
roi = scene[y1:y2, x1:x2]
|
||||
image_height, image_width = scene.shape[:2]
|
||||
clipped_xyxy = clip_boxes(
|
||||
xyxy=detections.xyxy, resolution_wh=(image_width, image_height)
|
||||
).astype(int)
|
||||
|
||||
for x1, y1, x2, y2 in clipped_xyxy:
|
||||
roi = scene[y1:y2, x1:x2]
|
||||
roi = cv2.blur(roi, (self.kernel_size, self.kernel_size))
|
||||
scene[y1:y2, x1:x2] = roi
|
||||
|
||||
|
|
@ -831,7 +1005,7 @@ class TraceAnnotator:
|
|||
|
||||
!!! warning
|
||||
|
||||
This annotator utilizes the `tracker_id`. Read
|
||||
This annotator utilizes the `sv.Detections.tracker_id`. Read
|
||||
[here](https://supervision.roboflow.com/trackers/) to learn how to plug
|
||||
tracking into your inference pipeline.
|
||||
"""
|
||||
|
|
@ -839,7 +1013,7 @@ class TraceAnnotator:
|
|||
def __init__(
|
||||
self,
|
||||
color: Union[Color, ColorPalette] = ColorPalette.default(),
|
||||
position: Optional[Position] = Position.CENTER,
|
||||
position: Position = Position.CENTER,
|
||||
trace_length: int = 30,
|
||||
thickness: int = 2,
|
||||
color_lookup: ColorLookup = ColorLookup.CLASS,
|
||||
|
|
@ -848,13 +1022,13 @@ class TraceAnnotator:
|
|||
Args:
|
||||
color (Union[Color, ColorPalette]): The color to draw the trace, can be
|
||||
a single color or a color palette.
|
||||
position (Optional[Position]): The position of the trace.
|
||||
position (Position): The position of the trace.
|
||||
Defaults to `CENTER`.
|
||||
trace_length (int): The maximum length of the trace in terms of historical
|
||||
points. Defaults to `30`.
|
||||
thickness (int): The thickness of the trace lines. Defaults to `2`.
|
||||
color_lookup (str): Strategy for mapping colors to annotations.
|
||||
Options are `INDEX`, `CLASS`, `TRACE`.
|
||||
Options are `INDEX`, `CLASS`, `TRACK`.
|
||||
"""
|
||||
self.color: Union[Color, ColorPalette] = color
|
||||
self.position = position
|
||||
|
|
@ -879,20 +1053,30 @@ class TraceAnnotator:
|
|||
Allows to override the default color mapping strategy.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The image with the trace paths drawn on it.
|
||||
The annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
>>> from ultralytics import YOLO
|
||||
|
||||
>>> image = ...
|
||||
>>> detections = sv.Detections(...)
|
||||
>>> model = YOLO('yolov8x.pt')
|
||||
|
||||
>>> trace_annotator = sv.TraceAnnotator()
|
||||
>>> annotated_frame = trace_annotator.annotate(
|
||||
... scene=image.copy(),
|
||||
... detections=detections
|
||||
... )
|
||||
|
||||
>>> video_info = sv.VideoInfo.from_video_path(video_path='...')
|
||||
>>> frames_generator = sv.get_video_frames_generator(source_path='...')
|
||||
>>> tracker = sv.ByteTrack()
|
||||
|
||||
>>> with sv.VideoSink(target_path='...', video_info=video_info) as sink:
|
||||
... for frame in frames_generator:
|
||||
... result = model(frame)[0]
|
||||
... detections = sv.Detections.from_ultralytics(result)
|
||||
... detections = tracker.update_with_detections(detections)
|
||||
... annotated_frame = trace_annotator.annotate(
|
||||
... scene=frame.copy(),
|
||||
... detections=detections)
|
||||
... sink.write_frame(frame=annotated_frame)
|
||||
```
|
||||
|
||||
:
|
||||
"""
|
||||
Args:
|
||||
position (Position): The position of the heatmap. Defaults to
|
||||
`BOTTOM_CENTER`.
|
||||
opacity (float): Opacity of the overlay mask, between 0 and 1.
|
||||
radius (int): Radius of the heat circle.
|
||||
kernel_size (int): Kernel size for blurring the heatmap.
|
||||
top_hue (int): Hue at the top of the heatmap. Defaults to 0 (red).
|
||||
low_hue (int): Hue at the bottom of the heatmap. Defaults to 125 (blue).
|
||||
"""
|
||||
self.position = position
|
||||
self.opacity = opacity
|
||||
self.radius = radius
|
||||
self.kernel_size = kernel_size
|
||||
self.heat_mask = None
|
||||
self.top_hue = top_hue
|
||||
self.low_hue = low_hue
|
||||
|
||||
def annotate(self, scene: np.ndarray, detections: Detections) -> np.ndarray:
|
||||
"""
|
||||
Annotates the scene with a heatmap based on the provided detections.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): The image where the heatmap will be drawn.
|
||||
detections (Detections): Object detections to annotate.
|
||||
|
||||
Returns:
|
||||
Annotated image.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> import supervision as sv
|
||||
>>> from ultralytics import YOLO
|
||||
|
||||
>>> model = YOLO('yolov8x.pt')
|
||||
|
||||
>>> heat_map_annotator = sv.HeatMapAnnotator()
|
||||
|
||||
>>> video_info = sv.VideoInfo.from_video_path(video_path='...')
|
||||
>>> frames_generator = get_video_frames_generator(source_path='...')
|
||||
|
||||
>>> with sv.VideoSink(target_path='...', video_info=video_info) as sink:
|
||||
... for frame in frames_generator:
|
||||
... result = model(frame)[0]
|
||||
... detections = sv.Detections.from_ultralytics(result)
|
||||
... annotated_frame = heat_map_annotator.annotate(
|
||||
... scene=frame.copy(),
|
||||
... detections=detections)
|
||||
... sink.write_frame(frame=annotated_frame)
|
||||
```
|
||||
|
||||

|
||||
"""
|
||||
|
||||
if self.heat_mask is None:
|
||||
self.heat_mask = np.zeros(scene.shape[:2])
|
||||
mask = np.zeros(scene.shape[:2])
|
||||
for xy in detections.get_anchors_coordinates(self.position):
|
||||
cv2.circle(mask, (int(xy[0]), int(xy[1])), self.radius, 1, -1)
|
||||
self.heat_mask = mask + self.heat_mask
|
||||
temp = self.heat_mask.copy()
|
||||
temp = self.low_hue - temp / temp.max() * (self.low_hue - self.top_hue)
|
||||
temp = temp.astype(np.uint8)
|
||||
if self.kernel_size is not None:
|
||||
temp = cv2.blur(temp, (self.kernel_size, self.kernel_size))
|
||||
hsv = np.zeros(scene.shape)
|
||||
hsv[..., 0] = temp
|
||||
hsv[..., 1] = 255
|
||||
hsv[..., 2] = 255
|
||||
temp = cv2.cvtColor(hsv.astype(np.uint8), cv2.COLOR_HSV2BGR)
|
||||
mask = cv2.cvtColor(self.heat_mask.astype(np.uint8), cv2.COLOR_GRAY2BGR) > 0
|
||||
scene[mask] = cv2.addWeighted(temp, self.opacity, scene, 1 - self.opacity, 0)[
|
||||
mask
|
||||
]
|
||||
return scene
|
||||
|
||||
|
||||
class ClassificationAnnotator:
|
||||
"""
|
||||
Annotate classification results on an image.
|
||||
|
|
|
|||
|
|
@ -10,13 +10,22 @@ from supervision.geometry.core import Position
|
|||
|
||||
class ColorLookup(Enum):
|
||||
"""
|
||||
Enum for annotator color lookup.
|
||||
Enumeration class to define strategies for mapping colors to annotations.
|
||||
|
||||
This enum supports three different lookup strategies:
|
||||
- `INDEX`: Colors are determined by the index of the detection within the scene.
|
||||
- `CLASS`: Colors are determined by the class label of the detected object.
|
||||
- `TRACK`: Colors are determined by the tracking identifier of the object.
|
||||
"""
|
||||
|
||||
INDEX = "index"
|
||||
CLASS = "class"
|
||||
TRACK = "track"
|
||||
|
||||
@classmethod
|
||||
def list(cls):
|
||||
return list(map(lambda c: c.value, cls))
|
||||
|
||||
|
||||
def resolve_color_idx(
|
||||
detections: Detections,
|
||||
|
|
@ -93,7 +102,7 @@ class Trace:
|
|||
frame_id = np.full(len(detections), self.current_frame_id, dtype=int)
|
||||
self.frame_id = np.concatenate([self.frame_id, frame_id])
|
||||
self.xy = np.concatenate(
|
||||
[self.xy, detections.get_anchor_coordinates(self.anchor)]
|
||||
[self.xy, detections.get_anchors_coordinates(self.anchor)]
|
||||
)
|
||||
self.tracker_id = np.concatenate([self.tracker_id, detections.tracker_id])
|
||||
|
||||
|
|
|
|||
|
|
@ -0,0 +1,2 @@
|
|||
from supervision.assets.downloader import download_assets
|
||||
from supervision.assets.list import VideoAssets
|
||||
|
|
@ -0,0 +1,94 @@
|
|||
import os
|
||||
from hashlib import md5
|
||||
from pathlib import Path
|
||||
from shutil import copyfileobj
|
||||
from typing import Union
|
||||
|
||||
from supervision.assets.list import VIDEO_ASSETS, VideoAssets
|
||||
|
||||
try:
|
||||
from requests import get
|
||||
from tqdm.auto import tqdm
|
||||
except ImportError:
|
||||
raise ValueError(
|
||||
"\n"
|
||||
"Please install requests and tqdm to download assets \n"
|
||||
"or install supervision with assets \n"
|
||||
"pip install supervision[assets] \n"
|
||||
"\n"
|
||||
)
|
||||
|
||||
|
||||
def is_md5_hash_matching(filename: str, original_md5_hash: str) -> bool:
|
||||
"""
|
||||
Check if the MD5 hash of a file matches the original hash.
|
||||
|
||||
Parameters:
|
||||
filename (str): The path to the file to be checked as a string.
|
||||
original_md5_hash (str): The original MD5 hash to compare against.
|
||||
|
||||
Returns:
|
||||
bool: True if the hashes match, False otherwise.
|
||||
"""
|
||||
if not os.path.exists(filename):
|
||||
return False
|
||||
|
||||
with open(filename, "rb") as file:
|
||||
file_contents = file.read()
|
||||
computed_md5_hash = md5(file_contents).hexdigest()
|
||||
|
||||
return computed_md5_hash == original_md5_hash
|
||||
|
||||
|
||||
def download_assets(asset_name: Union[VideoAssets, str]) -> str:
|
||||
"""
|
||||
Download a specified asset if it doesn't already exist or is corrupted.
|
||||
|
||||
Parameters:
|
||||
asset_name (Union[VideoAssets, str]): The name or type of the asset to be
|
||||
downloaded.
|
||||
|
||||
Returns:
|
||||
str: The filename of the downloaded asset.
|
||||
|
||||
Example:
|
||||
```python
|
||||
>>> from supervision.assets import download_assets, VideoAssets
|
||||
|
||||
>>> download_assets(VideoAssets.VEHICLES)
|
||||
"vehicles.mp4"
|
||||
```
|
||||
"""
|
||||
|
||||
filename = asset_name.value if isinstance(asset_name, VideoAssets) else asset_name
|
||||
|
||||
if not Path(filename).exists() and filename in VIDEO_ASSETS:
|
||||
print(f"Downloading {filename} assets \n")
|
||||
response = get(VIDEO_ASSETS[filename][0], stream=True, allow_redirects=True)
|
||||
response.raise_for_status()
|
||||
|
||||
file_size = int(response.headers.get("Content-Length", 0))
|
||||
folder_path = Path(filename).expanduser().resolve()
|
||||
folder_path.parent.mkdir(parents=True, exist_ok=True)
|
||||
|
||||
with tqdm.wrapattr(
|
||||
response.raw, "read", total=file_size, desc="", colour="#a351fb"
|
||||
) as raw_resp:
|
||||
with folder_path.open("wb") as file:
|
||||
copyfileobj(raw_resp, file)
|
||||
|
||||
elif Path(filename).exists():
|
||||
if not is_md5_hash_matching(filename, VIDEO_ASSETS[filename][1]):
|
||||
print("File corrupted. Re-downloading... \n")
|
||||
os.remove(filename)
|
||||
return download_assets(filename)
|
||||
|
||||
print(f"{filename} asset download complete. \n")
|
||||
|
||||
else:
|
||||
valid_assets = ", ".join(asset.value for asset in VideoAssets)
|
||||
raise ValueError(
|
||||
f"Invalid asset. It should be one of the following: {valid_assets}."
|
||||
)
|
||||
|
||||
return filename
|
||||
|
|
@ -0,0 +1,65 @@
|
|||
from enum import Enum
|
||||
from typing import Dict, Tuple
|
||||
|
||||
BASE_VIDEO_URL = "https://media.roboflow.com/supervision/video-examples/"
|
||||
|
||||
|
||||
class VideoAssets(Enum):
|
||||
"""
|
||||
Each member of this enum represents a video asset. The value associated with each
|
||||
member is the filename of the video.
|
||||
|
||||
| Enum Member | Video Filename | Video URL |
|
||||
|------------------------|----------------------------|---------------------------------------------------------------------------------------|
|
||||
| `VEHICLES` | `vehicles.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/vehicles.mp4) |
|
||||
| `MILK_BOTTLING_PLANT` | `milk-bottling-plant.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/milk-bottling-plant.mp4) |
|
||||
| `VEHICLES_2` | `vehicles-2.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/vehicles-2.mp4) |
|
||||
| `GROCERY_STORE` | `grocery-store.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/grocery-store.mp4) |
|
||||
| `SUBWAY` | `subway.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/subway.mp4) |
|
||||
| `MARKET_SQUARE` | `market-square.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/market-square.mp4) |
|
||||
| `PEOPLE_WALKING` | `people-walking.mp4` | [Link](https://media.roboflow.com/supervision/video-examples/people-walking.mp4) |
|
||||
"""
|
||||
|
||||
VEHICLES = "vehicles.mp4"
|
||||
MILK_BOTTLING_PLANT = "milk-bottling-plant.mp4"
|
||||
VEHICLES_2 = "vehicles-2.mp4"
|
||||
GROCERY_STORE = "grocery-store.mp4"
|
||||
SUBWAY = "subway.mp4"
|
||||
MARKET_SQUARE = "market-square.mp4"
|
||||
PEOPLE_WALKING = "people-walking.mp4"
|
||||
|
||||
@classmethod
|
||||
def list(cls):
|
||||
return list(map(lambda c: c.value, cls))
|
||||
|
||||
|
||||
VIDEO_ASSETS: Dict[str, Tuple[str, str]] = {
|
||||
VideoAssets.VEHICLES.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.VEHICLES.value}",
|
||||
"8155ff4e4de08cfa25f39de96483f918",
|
||||
),
|
||||
VideoAssets.VEHICLES_2.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.VEHICLES_2.value}",
|
||||
"830af6fba21ffbf14867a7fea595937b",
|
||||
),
|
||||
VideoAssets.MILK_BOTTLING_PLANT.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.MILK_BOTTLING_PLANT.value}",
|
||||
"9e8fb6e883f842a38b3d34267290bdc7",
|
||||
),
|
||||
VideoAssets.GROCERY_STORE.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.GROCERY_STORE.value}",
|
||||
"11402e7b861c1980527d3d74cbe3b366",
|
||||
),
|
||||
VideoAssets.SUBWAY.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.SUBWAY.value}",
|
||||
"453475750691fb23c56a0cffef089194",
|
||||
),
|
||||
VideoAssets.MARKET_SQUARE.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.MARKET_SQUARE.value}",
|
||||
"859179bf4a21f80a8baabfdb2ed716dc",
|
||||
),
|
||||
VideoAssets.PEOPLE_WALKING.value: (
|
||||
f"{BASE_VIDEO_URL}{VideoAssets.PEOPLE_WALKING.value}",
|
||||
"0574c053c8686c3f1dc0aa3743e45cb9",
|
||||
),
|
||||
}
|
||||
|
|
@ -149,7 +149,7 @@ def load_yolo_annotations(
|
|||
annotations[image_path] = Detections.empty()
|
||||
continue
|
||||
|
||||
lines = read_txt_file(str(annotation_path))
|
||||
lines = read_txt_file(file_path=annotation_path, skip_empty=True)
|
||||
h, w, _ = image.shape
|
||||
resolution_wh = (w, h)
|
||||
|
||||
|
|
|
|||
|
|
@ -6,6 +6,7 @@ from typing import Any, Iterator, List, Optional, Tuple, Union
|
|||
import numpy as np
|
||||
|
||||
from supervision.detection.utils import (
|
||||
calculate_masks_centroids,
|
||||
extract_ultralytics_masks,
|
||||
non_max_suppression,
|
||||
process_roboflow_result,
|
||||
|
|
@ -323,7 +324,7 @@ class Detections:
|
|||
|
||||
>>> inferencer = DetInferencer(model_name, checkpoint, device)
|
||||
>>> mmdet_result = inferencer(SOURCE_IMAGE_PATH, out_dir='./output',
|
||||
... return_datasample=True)["predictions"][0]
|
||||
... return_datasamples=True)["predictions"][0]
|
||||
>>> detections = sv.Detections.from_mmdet(mmdet_result)
|
||||
```
|
||||
"""
|
||||
|
|
@ -600,7 +601,7 @@ class Detections:
|
|||
tracker_id=tracker_id,
|
||||
)
|
||||
|
||||
def get_anchor_coordinates(self, anchor: Position) -> np.ndarray:
|
||||
def get_anchors_coordinates(self, anchor: Position) -> np.ndarray:
|
||||
"""
|
||||
Calculates and returns the coordinates of a specific anchor point
|
||||
within the bounding boxes defined by the `xyxy` attribute. The anchor
|
||||
|
|
@ -627,6 +628,12 @@ class Detections:
|
|||
(self.xyxy[:, 1] + self.xyxy[:, 3]) / 2,
|
||||
]
|
||||
).transpose()
|
||||
elif anchor == Position.CENTER_OF_MASS:
|
||||
if self.mask is None:
|
||||
raise ValueError(
|
||||
"Cannot use `Position.CENTER_OF_MASS` without a detection mask."
|
||||
)
|
||||
return calculate_masks_centroids(masks=self.mask)
|
||||
elif anchor == Position.CENTER_LEFT:
|
||||
return np.array(
|
||||
[
|
||||
|
|
|
|||
|
|
@ -1,4 +1,4 @@
|
|||
from typing import Dict, Optional
|
||||
from typing import Dict, Optional, Tuple
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
|
@ -10,37 +10,54 @@ from supervision.geometry.core import Point, Rect, Vector
|
|||
|
||||
class LineZone:
|
||||
"""
|
||||
Count the number of objects that cross a line.
|
||||
This class is responsible for counting the number of objects that cross a
|
||||
predefined line.
|
||||
|
||||
!!! warning
|
||||
|
||||
LineZone utilizes the `tracker_id`. Read
|
||||
[here](https://supervision.roboflow.com/trackers/) to learn how to plug
|
||||
tracking into your inference pipeline.
|
||||
|
||||
Attributes:
|
||||
in_count (int): The number of objects that have crossed the line from outside
|
||||
to inside.
|
||||
out_count (int): The number of objects that have crossed the line from inside
|
||||
to outside.
|
||||
"""
|
||||
|
||||
def __init__(self, start: Point, end: Point):
|
||||
"""
|
||||
Initialize a LineCounter object.
|
||||
|
||||
Attributes:
|
||||
Args:
|
||||
start (Point): The starting point of the line.
|
||||
end (Point): The ending point of the line.
|
||||
|
||||
"""
|
||||
self.vector = Vector(start=start, end=end)
|
||||
self.tracker_state: Dict[str, bool] = {}
|
||||
self.in_count: int = 0
|
||||
self.out_count: int = 0
|
||||
|
||||
def trigger(self, detections: Detections):
|
||||
def trigger(self, detections: Detections) -> Tuple[np.ndarray, np.ndarray]:
|
||||
"""
|
||||
Update the in_count and out_count for the detections that cross the line.
|
||||
Update the `in_count` and `out_count` based on the objects that cross the line.
|
||||
|
||||
Attributes:
|
||||
detections (Detections): The detections for which to update the counts.
|
||||
Args:
|
||||
detections (Detections): A list of detections for which to update the
|
||||
counts.
|
||||
|
||||
Returns:
|
||||
A tuple of two boolean NumPy arrays. The first array indicates which
|
||||
detections have crossed the line from outside to inside. The second
|
||||
array indicates which detections have crossed the line from inside to
|
||||
outside.
|
||||
"""
|
||||
for xyxy, _, confidence, class_id, tracker_id in detections:
|
||||
# handle detections with no tracker_id
|
||||
crossed_in = np.full(len(detections), False)
|
||||
crossed_out = np.full(len(detections), False)
|
||||
|
||||
for i, (xyxy, _, confidence, class_id, tracker_id) in enumerate(detections):
|
||||
if tracker_id is None:
|
||||
continue
|
||||
|
||||
# we check if all four anchors of bbox are on the same side of vector
|
||||
x1, y1, x2, y2 = xyxy
|
||||
anchors = [
|
||||
Point(x=x1, y=y1),
|
||||
|
|
@ -50,25 +67,27 @@ class LineZone:
|
|||
]
|
||||
triggers = [self.vector.is_in(point=anchor) for anchor in anchors]
|
||||
|
||||
# detection is partially in and partially out
|
||||
if len(set(triggers)) == 2:
|
||||
continue
|
||||
|
||||
tracker_state = triggers[0]
|
||||
# handle new detection
|
||||
|
||||
if tracker_id not in self.tracker_state:
|
||||
self.tracker_state[tracker_id] = tracker_state
|
||||
continue
|
||||
|
||||
# handle detection on the same side of the line
|
||||
if self.tracker_state.get(tracker_id) == tracker_state:
|
||||
continue
|
||||
|
||||
self.tracker_state[tracker_id] = tracker_state
|
||||
if tracker_state:
|
||||
self.in_count += 1
|
||||
crossed_in[i] = True
|
||||
else:
|
||||
self.out_count += 1
|
||||
crossed_out[i] = True
|
||||
|
||||
return crossed_in, crossed_out
|
||||
|
||||
|
||||
class LineZoneAnnotator:
|
||||
|
|
|
|||
|
|
@ -56,11 +56,11 @@ class PolygonZone:
|
|||
"""
|
||||
|
||||
clipped_xyxy = clip_boxes(
|
||||
boxes_xyxy=detections.xyxy, frame_resolution_wh=self.frame_resolution_wh
|
||||
xyxy=detections.xyxy, resolution_wh=self.frame_resolution_wh
|
||||
)
|
||||
clipped_detections = replace(detections, xyxy=clipped_xyxy)
|
||||
clipped_anchors = np.ceil(
|
||||
clipped_detections.get_anchor_coordinates(anchor=self.triggering_position)
|
||||
clipped_detections.get_anchors_coordinates(anchor=self.triggering_position)
|
||||
).astype(int)
|
||||
is_in_zone = self.mask[clipped_anchors[:, 1], clipped_anchors[:, 0]]
|
||||
self.current_count = int(np.sum(is_in_zone))
|
||||
|
|
|
|||
|
|
@ -110,17 +110,15 @@ def non_max_suppression(
|
|||
return keep[sort_index.argsort()]
|
||||
|
||||
|
||||
def clip_boxes(
|
||||
boxes_xyxy: np.ndarray, frame_resolution_wh: Tuple[int, int]
|
||||
) -> np.ndarray:
|
||||
def clip_boxes(xyxy: np.ndarray, resolution_wh: Tuple[int, int]) -> np.ndarray:
|
||||
"""
|
||||
Clips bounding boxes coordinates to fit within the frame resolution.
|
||||
|
||||
Args:
|
||||
boxes_xyxy (np.ndarray): A numpy array of shape `(N, 4)` where each
|
||||
xyxy (np.ndarray): A numpy array of shape `(N, 4)` where each
|
||||
row corresponds to a bounding box in
|
||||
the format `(x_min, y_min, x_max, y_max)`.
|
||||
frame_resolution_wh (Tuple[int, int]): A tuple of the form `(width, height)`
|
||||
resolution_wh (Tuple[int, int]): A tuple of the form `(width, height)`
|
||||
representing the resolution of the frame.
|
||||
|
||||
Returns:
|
||||
|
|
@ -128,8 +126,8 @@ def clip_boxes(
|
|||
corresponds to a bounding box with coordinates clipped to fit
|
||||
within the frame resolution.
|
||||
"""
|
||||
result = np.copy(boxes_xyxy)
|
||||
width, height = frame_resolution_wh
|
||||
result = np.copy(xyxy)
|
||||
width, height = resolution_wh
|
||||
result[:, [0, 2]] = result[:, [0, 2]].clip(0, width)
|
||||
result[:, [1, 3]] = result[:, [1, 3]].clip(0, height)
|
||||
return result
|
||||
|
|
@ -395,3 +393,33 @@ def move_boxes(xyxy: np.ndarray, offset: np.ndarray) -> np.ndarray:
|
|||
(np.ndarray) repositioned bounding boxes
|
||||
"""
|
||||
return xyxy + np.hstack([offset, offset])
|
||||
|
||||
|
||||
def calculate_masks_centroids(masks: np.ndarray) -> np.ndarray:
|
||||
"""
|
||||
Calculate the centroids of binary masks in a tensor.
|
||||
|
||||
Parameters:
|
||||
masks (np.ndarray): A 3D NumPy array of shape (num_masks, height, width).
|
||||
Each 2D array in the tensor represents a binary mask.
|
||||
|
||||
Returns:
|
||||
A 2D NumPy array of shape (num_masks, 2), where each row contains the x and y
|
||||
coordinates (in that order) of the centroid of the corresponding mask.
|
||||
"""
|
||||
num_masks, height, width = masks.shape
|
||||
total_pixels = masks.sum(axis=(1, 2))
|
||||
|
||||
# offset for 1-based indexing
|
||||
vertical_indices, horizontal_indices = np.indices((height, width)) + 0.5
|
||||
# avoid division by zero for empty masks
|
||||
total_pixels[total_pixels == 0] = 1
|
||||
|
||||
def sum_over_mask(indices: np.ndarray, axis: tuple) -> np.ndarray:
|
||||
return np.tensordot(masks, indices, axes=axis)
|
||||
|
||||
aggregation_axis = ([1, 2], [0, 1])
|
||||
centroid_x = sum_over_mask(horizontal_indices, aggregation_axis) / total_pixels
|
||||
centroid_y = sum_over_mask(vertical_indices, aggregation_axis) / total_pixels
|
||||
|
||||
return np.column_stack((centroid_x, centroid_y)).astype(int)
|
||||
|
|
|
|||
|
|
@ -34,21 +34,35 @@ def _validate_color_hex(color_hex: str):
|
|||
|
||||
@dataclass
|
||||
class Color:
|
||||
"""
|
||||
Represents a color in RGB format.
|
||||
|
||||
Attributes:
|
||||
r (int): Red channel.
|
||||
g (int): Green channel.
|
||||
b (int): Blue channel.
|
||||
"""
|
||||
|
||||
r: int
|
||||
g: int
|
||||
b: int
|
||||
|
||||
@classmethod
|
||||
def from_hex(cls, color_hex: str):
|
||||
def from_hex(cls, color_hex: str) -> Color:
|
||||
"""
|
||||
Creates a Color instance from a color hex string
|
||||
Create a Color instance from a hex string.
|
||||
|
||||
:param color_hex: str : The color hex string in the format
|
||||
of "fff", "ffffff", "#fff", or "#ffffff"
|
||||
:return: Color : A Color instance representing the color
|
||||
Args:
|
||||
color_hex (str): Hex string of the color.
|
||||
|
||||
Returns:
|
||||
Color: Instance representing the color.
|
||||
|
||||
Example:
|
||||
color = Color.from_hex('#ff00ff')
|
||||
```
|
||||
>>> Color.from_hex('#ff00ff')
|
||||
Color(r=255, g=0, b=255)
|
||||
```
|
||||
"""
|
||||
_validate_color_hex(color_hex)
|
||||
color_hex = color_hex.lstrip("#")
|
||||
|
|
@ -57,19 +71,48 @@ class Color:
|
|||
r, g, b = (int(color_hex[i : i + 2], 16) for i in range(0, 6, 2))
|
||||
return cls(r, g, b)
|
||||
|
||||
def as_hex(self) -> str:
|
||||
"""
|
||||
Converts the Color instance to a hex string.
|
||||
|
||||
Returns:
|
||||
str: The hexadecimal color string.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> Color(r=255, g=0, b=255).as_hex()
|
||||
'#ff00ff'
|
||||
```
|
||||
"""
|
||||
return f"#{self.r:02x}{self.g:02x}{self.b:02x}"
|
||||
|
||||
def as_rgb(self) -> Tuple[int, int, int]:
|
||||
"""
|
||||
Returns the color as a tuple of integers in the RGB format
|
||||
Returns the color as an RGB tuple.
|
||||
|
||||
:return: Tuple[int, int, int] : The color in the RGB format
|
||||
Returns:
|
||||
Tuple[int, int, int]: RGB tuple.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> color.as_rgb()
|
||||
(255, 0, 255)
|
||||
```
|
||||
"""
|
||||
return self.r, self.g, self.b
|
||||
|
||||
def as_bgr(self) -> Tuple[int, int, int]:
|
||||
"""
|
||||
Returns the color as a tuple of integers in the BGR format
|
||||
Returns the color as a BGR tuple.
|
||||
|
||||
:return: Tuple[int, int, int] : The color in the BGR format
|
||||
Returns:
|
||||
Tuple[int, int, int]: BGR tuple.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> color.as_bgr()
|
||||
(255, 0, 255)
|
||||
```
|
||||
"""
|
||||
return self.b, self.g, self.r
|
||||
|
||||
|
|
@ -100,33 +143,55 @@ class ColorPalette:
|
|||
|
||||
@classmethod
|
||||
def default(cls) -> ColorPalette:
|
||||
"""
|
||||
Returns a default color palette.
|
||||
|
||||
Returns:
|
||||
ColorPalette: A ColorPalette instance with default colors.
|
||||
|
||||
Example:
|
||||
```
|
||||
>>> ColorPalette.default()
|
||||
ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
```
|
||||
"""
|
||||
return ColorPalette.from_hex(color_hex_list=DEFAULT_COLOR_PALETTE)
|
||||
|
||||
@classmethod
|
||||
def from_hex(cls, color_hex_list: List[str]):
|
||||
def from_hex(cls, color_hex_list: List[str]) -> ColorPalette:
|
||||
"""
|
||||
Creates a ColorPalette instance from a list of color hex strings
|
||||
Create a ColorPalette instance from a list of hex strings.
|
||||
|
||||
:param color_hex_list: List[str] : A list of color hex strings in the
|
||||
format of "fff", "ffffff", "#fff", or "#ffffff"
|
||||
:return: ColorPalette : A ColorPalette instance representing the color palette
|
||||
Args:
|
||||
color_hex_list (List[str]): List of color hex strings.
|
||||
|
||||
Returns:
|
||||
ColorPalette: A ColorPalette instance.
|
||||
|
||||
Example:
|
||||
color_palette = ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
```
|
||||
>>> ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
ColorPalette(colors=[Color(r=255, g=0, b=0), Color(r=0, g=255, b=0), ...])
|
||||
```
|
||||
"""
|
||||
colors = [Color.from_hex(color_hex) for color_hex in color_hex_list]
|
||||
return cls(colors)
|
||||
|
||||
def by_idx(self, idx: int) -> Color:
|
||||
"""
|
||||
Returns the color at a given index in the color palette.
|
||||
Return the color at a given index in the palette.
|
||||
|
||||
:param idx: int : The index of the color in the color palette
|
||||
:return: Color : The color at the given index
|
||||
Args:
|
||||
idx (int): Index of the color in the palette.
|
||||
|
||||
Returns:
|
||||
Color: Color at the given index.
|
||||
|
||||
Example:
|
||||
color_palette = ColorPalette.from_hex(['#ff0000', '#00ff00', '#0000ff'])
|
||||
color = color_palette.by_idx(1)
|
||||
```
|
||||
>>> color_palette.by_idx(1)
|
||||
Color(r=0, g=255, b=0)
|
||||
```
|
||||
"""
|
||||
if idx < 0:
|
||||
raise ValueError("idx argument should not be negative")
|
||||
|
|
|
|||
|
|
@ -1,4 +1,5 @@
|
|||
from typing import Optional
|
||||
import os
|
||||
from typing import Optional, Union
|
||||
|
||||
import cv2
|
||||
import numpy as np
|
||||
|
|
@ -168,3 +169,65 @@ def draw_text(
|
|||
lineType=cv2.LINE_AA,
|
||||
)
|
||||
return scene
|
||||
|
||||
|
||||
def draw_image(
|
||||
scene: np.ndarray, image: Union[str, np.ndarray], opacity: float, rect: Rect
|
||||
) -> np.ndarray:
|
||||
"""
|
||||
Draws an image onto a given scene with specified opacity and dimensions.
|
||||
|
||||
Args:
|
||||
scene (np.ndarray): Background image where the new image will be drawn.
|
||||
image (Union[str, np.ndarray]): Image to draw.
|
||||
opacity (float): Opacity of the image to be drawn.
|
||||
rect (Rect): Rectangle specifying where to draw the image.
|
||||
|
||||
Returns:
|
||||
np.ndarray: The updated scene.
|
||||
|
||||
Raises:
|
||||
FileNotFoundError: If the image path does not exist.
|
||||
ValueError: For invalid opacity or rectangle dimensions.
|
||||
"""
|
||||
|
||||
# Validate and load image
|
||||
if isinstance(image, str):
|
||||
if not os.path.exists(image):
|
||||
raise FileNotFoundError(f"Image path ('{image}') does not exist.")
|
||||
image = cv2.imread(image, cv2.IMREAD_UNCHANGED)
|
||||
|
||||
# Validate opacity
|
||||
if not 0.0 <= opacity <= 1.0:
|
||||
raise ValueError("Opacity must be between 0.0 and 1.0.")
|
||||
|
||||
# Validate rectangle dimensions
|
||||
if (
|
||||
rect.x < 0
|
||||
or rect.y < 0
|
||||
or rect.x + rect.width > scene.shape[1]
|
||||
or rect.y + rect.height > scene.shape[0]
|
||||
):
|
||||
raise ValueError("Invalid rectangle dimensions.")
|
||||
|
||||
# Resize and isolate alpha channel
|
||||
image = cv2.resize(image, (rect.width, rect.height))
|
||||
alpha_channel = (
|
||||
image[:, :, 3]
|
||||
if image.shape[2] == 4
|
||||
else np.ones((rect.height, rect.width), dtype=image.dtype) * 255
|
||||
)
|
||||
alpha_scaled = cv2.convertScaleAbs(alpha_channel * opacity)
|
||||
|
||||
# Perform blending
|
||||
scene_roi = scene[rect.y : rect.y + rect.height, rect.x : rect.x + rect.width]
|
||||
alpha_float = alpha_scaled.astype(np.float32) / 255.0
|
||||
blended_roi = cv2.convertScaleAbs(
|
||||
(1 - alpha_float[..., np.newaxis]) * scene_roi
|
||||
+ alpha_float[..., np.newaxis] * image[:, :, :3]
|
||||
)
|
||||
|
||||
# Update the scene
|
||||
scene[rect.y : rect.y + rect.height, rect.x : rect.x + rect.width] = blended_roi
|
||||
|
||||
return scene
|
||||
|
|
|
|||
|
|
@ -19,6 +19,7 @@ class Position(Enum):
|
|||
BOTTOM_LEFT = "BOTTOM_LEFT"
|
||||
BOTTOM_CENTER = "BOTTOM_CENTER"
|
||||
BOTTOM_RIGHT = "BOTTOM_RIGHT"
|
||||
CENTER_OF_MASS = "CENTER_OF_MASS"
|
||||
|
||||
@classmethod
|
||||
def list(cls):
|
||||
|
|
|
|||
|
|
@ -57,19 +57,24 @@ def list_files_with_extensions(
|
|||
return files_with_extensions
|
||||
|
||||
|
||||
def read_txt_file(file_path: str) -> List[str]:
|
||||
def read_txt_file(file_path: str, skip_empty: bool = False) -> List[str]:
|
||||
"""
|
||||
Read a text file and return a list of strings without newline characters.
|
||||
Optionally skip empty lines.
|
||||
|
||||
Args:
|
||||
file_path (str): The path to the text file.
|
||||
skip_empty (bool): If True, skip lines that are empty or contain only
|
||||
whitespace. Default is False.
|
||||
|
||||
Returns:
|
||||
List[str]: A list of strings representing the lines in the text file.
|
||||
"""
|
||||
with open(file_path, "r") as file:
|
||||
lines = file.readlines()
|
||||
lines = [line.rstrip("\n") for line in lines]
|
||||
if skip_empty:
|
||||
lines = [line.rstrip("\n") for line in file if line.strip()]
|
||||
else:
|
||||
lines = [line.rstrip("\n") for line in file]
|
||||
|
||||
return lines
|
||||
|
||||
|
|
|
|||
|
|
@ -1,5 +1,5 @@
|
|||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import mock_detections
|
||||
from test.test_utils import mock_detections
|
||||
from typing import Optional
|
||||
|
||||
import numpy as np
|
||||
|
|
|
|||
|
|
@ -1,6 +1,6 @@
|
|||
import xml.etree.ElementTree as ET
|
||||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import mock_detections
|
||||
from test.test_utils import mock_detections
|
||||
from typing import List, Optional
|
||||
|
||||
import numpy as np
|
||||
|
|
|
|||
|
|
@ -1,5 +1,5 @@
|
|||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import mock_detections
|
||||
from test.test_utils import mock_detections
|
||||
from typing import List, Optional
|
||||
|
||||
import numpy as np
|
||||
|
|
|
|||
|
|
@ -1,5 +1,5 @@
|
|||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import mock_detections
|
||||
from test.test_utils import mock_detections
|
||||
from typing import Dict, List, Optional, Tuple, TypeVar
|
||||
|
||||
import pytest
|
||||
|
|
|
|||
|
|
@ -1,5 +1,5 @@
|
|||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import mock_detections
|
||||
from test.test_utils import mock_detections
|
||||
from typing import List, Optional, Union
|
||||
|
||||
import numpy as np
|
||||
|
|
@ -270,6 +270,6 @@ def test_get_anchor_coordinates(
|
|||
expected_result: np.ndarray,
|
||||
exception: Exception,
|
||||
) -> None:
|
||||
result = detections.get_anchor_coordinates(anchor)
|
||||
result = detections.get_anchors_coordinates(anchor)
|
||||
with exception:
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
|
|
|||
|
|
@ -5,6 +5,7 @@ import numpy as np
|
|||
import pytest
|
||||
|
||||
from supervision.detection.utils import (
|
||||
calculate_masks_centroids,
|
||||
clip_boxes,
|
||||
filter_polygons_by_area,
|
||||
move_boxes,
|
||||
|
|
@ -122,7 +123,7 @@ def test_non_max_suppression(
|
|||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"boxes_xyxy, frame_resolution_wh, expected_result",
|
||||
"xyxy, resolution_wh, expected_result",
|
||||
[
|
||||
(
|
||||
np.empty(shape=(0, 4)),
|
||||
|
|
@ -157,11 +158,11 @@ def test_non_max_suppression(
|
|||
],
|
||||
)
|
||||
def test_clip_boxes(
|
||||
boxes_xyxy: np.ndarray,
|
||||
frame_resolution_wh: Tuple[int, int],
|
||||
xyxy: np.ndarray,
|
||||
resolution_wh: Tuple[int, int],
|
||||
expected_result: np.ndarray,
|
||||
) -> None:
|
||||
result = clip_boxes(boxes_xyxy=boxes_xyxy, frame_resolution_wh=frame_resolution_wh)
|
||||
result = clip_boxes(xyxy=xyxy, resolution_wh=resolution_wh)
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
||||
|
||||
|
|
@ -498,5 +499,97 @@ def test_move_boxes(
|
|||
expected_result: np.ndarray,
|
||||
exception: Exception,
|
||||
) -> None:
|
||||
result = move_boxes(xyxy=xyxy, offset=offset)
|
||||
assert np.array_equal(result, expected_result)
|
||||
with exception:
|
||||
result = move_boxes(xyxy=xyxy, offset=offset)
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"masks, expected_result, exception",
|
||||
[
|
||||
(
|
||||
np.array(
|
||||
[
|
||||
[
|
||||
[0, 0, 0, 0],
|
||||
[0, 0, 0, 0],
|
||||
[0, 0, 0, 0],
|
||||
[0, 0, 0, 0],
|
||||
]
|
||||
]
|
||||
),
|
||||
np.array([[0, 0]]),
|
||||
DoesNotRaise(),
|
||||
), # single mask with all zeros
|
||||
(
|
||||
np.array(
|
||||
[
|
||||
[
|
||||
[1, 1, 1, 1],
|
||||
[1, 1, 1, 1],
|
||||
[1, 1, 1, 1],
|
||||
[1, 1, 1, 1],
|
||||
]
|
||||
]
|
||||
),
|
||||
np.array([[2, 2]]),
|
||||
DoesNotRaise(),
|
||||
), # single mask with all ones
|
||||
(
|
||||
np.array(
|
||||
[
|
||||
[
|
||||
[0, 1, 1, 0],
|
||||
[1, 1, 1, 1],
|
||||
[1, 1, 1, 1],
|
||||
[0, 1, 1, 0],
|
||||
]
|
||||
]
|
||||
),
|
||||
np.array([[2, 2]]),
|
||||
DoesNotRaise(),
|
||||
), # single mask with symmetric ones
|
||||
(
|
||||
np.array(
|
||||
[
|
||||
[
|
||||
[0, 0, 0, 0],
|
||||
[0, 0, 1, 1],
|
||||
[0, 0, 1, 1],
|
||||
[0, 0, 0, 0],
|
||||
]
|
||||
]
|
||||
),
|
||||
np.array([[3, 2]]),
|
||||
DoesNotRaise(),
|
||||
), # single mask with asymmetric ones
|
||||
(
|
||||
np.array(
|
||||
[
|
||||
[
|
||||
[0, 1, 1, 0],
|
||||
[1, 1, 1, 1],
|
||||
[1, 1, 1, 1],
|
||||
[0, 1, 1, 0],
|
||||
],
|
||||
[
|
||||
[0, 0, 0, 0],
|
||||
[0, 0, 1, 1],
|
||||
[0, 0, 1, 1],
|
||||
[0, 0, 0, 0],
|
||||
],
|
||||
]
|
||||
),
|
||||
np.array([[2, 2], [3, 2]]),
|
||||
DoesNotRaise(),
|
||||
), # two masks
|
||||
],
|
||||
)
|
||||
def test_calculate_masks_centroids(
|
||||
masks: np.ndarray,
|
||||
expected_result: np.ndarray,
|
||||
exception: Exception,
|
||||
) -> None:
|
||||
with exception:
|
||||
result = calculate_masks_centroids(masks=masks)
|
||||
assert np.array_equal(result, expected_result)
|
||||
|
|
|
|||
|
|
@ -30,3 +30,22 @@ def test_color_from_hex(
|
|||
with exception:
|
||||
result = Color.from_hex(color_hex=color_hex)
|
||||
assert result == expected_result
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"color, expected_result, exception",
|
||||
[
|
||||
(Color.white(), "#ffffff", DoesNotRaise()),
|
||||
(Color.black(), "#000000", DoesNotRaise()),
|
||||
(Color.red(), "#ff0000", DoesNotRaise()),
|
||||
(Color.green(), "#00ff00", DoesNotRaise()),
|
||||
(Color.blue(), "#0000ff", DoesNotRaise()),
|
||||
(Color(r=128, g=128, b=0), "#808000", DoesNotRaise()),
|
||||
],
|
||||
)
|
||||
def test_color_as_hex(
|
||||
color: Color, expected_result: Optional[str], exception: Exception
|
||||
) -> None:
|
||||
with exception:
|
||||
result = color.as_hex()
|
||||
assert result == expected_result
|
||||
|
|
|
|||
|
|
@ -1,5 +1,5 @@
|
|||
from contextlib import ExitStack as DoesNotRaise
|
||||
from test.utils import assert_almost_equal, mock_detections
|
||||
from test.test_utils import assert_almost_equal, mock_detections
|
||||
from typing import Optional, Union
|
||||
|
||||
import numpy as np
|
||||
|
|
|
|||
|
|
@ -0,0 +1,64 @@
|
|||
import os
|
||||
from contextlib import ExitStack as DoesNotRaise
|
||||
from typing import List, Optional
|
||||
|
||||
import pytest
|
||||
|
||||
from supervision.utils.file import read_txt_file
|
||||
|
||||
FILE_1_CONTENT = """Line 1
|
||||
Line 2
|
||||
Line 3
|
||||
"""
|
||||
|
||||
FILE_2_CONTENT = """
|
||||
Line 2
|
||||
|
||||
Line 4
|
||||
|
||||
""" # noqa
|
||||
|
||||
FILE_3_CONTENT = """
|
||||
Line 2
|
||||
|
||||
Line 4
|
||||
|
||||
"""
|
||||
|
||||
|
||||
@pytest.fixture(scope="module", autouse=True)
|
||||
def setup_and_teardown_files():
|
||||
with open("file_1.txt", "w") as file:
|
||||
file.write(FILE_1_CONTENT)
|
||||
with open("file_2.txt", "w") as file:
|
||||
file.write(FILE_2_CONTENT)
|
||||
with open("file_3.txt", "w") as file:
|
||||
file.write(FILE_3_CONTENT)
|
||||
|
||||
yield
|
||||
|
||||
os.remove("file_1.txt")
|
||||
os.remove("file_2.txt")
|
||||
os.remove("file_3.txt")
|
||||
|
||||
|
||||
@pytest.mark.parametrize(
|
||||
"file_name, skip_empty, expected_result, exception",
|
||||
[
|
||||
("file_1.txt", False, ["Line 1", "Line 2", "Line 3"], DoesNotRaise()),
|
||||
("file_2.txt", True, ["Line 2", "Line 4"], DoesNotRaise()),
|
||||
("file_2.txt", False, [" ", "Line 2", "", "Line 4", ""], DoesNotRaise()),
|
||||
("file_3.txt", True, ["Line 2", "Line 4"], DoesNotRaise()),
|
||||
("file_3.txt", False, ["", "Line 2", "", "Line 4", ""], DoesNotRaise()),
|
||||
("file_4.txt", True, None, pytest.raises(FileNotFoundError)),
|
||||
],
|
||||
)
|
||||
def test_read_txt_file(
|
||||
file_name: str,
|
||||
skip_empty: bool,
|
||||
expected_result: Optional[List[str]],
|
||||
exception: Exception,
|
||||
):
|
||||
with exception:
|
||||
result = read_txt_file(file_name, skip_empty)
|
||||
assert result == expected_result
|
||||
Loading…
Reference in New Issue