 75023c5f2f
- Added `sv.mask_to_roi` as an explicit migration path for exclusive mask bounds
- Fixed COCO, CreateML, and Pascal VOC export validation to reject ambiguous or colliding dataset paths before writing
- Fixed in-memory `DetectionDataset` split and merge behavior
- Fixed `supervision` imports to avoid loading ByteTrack until it is used
- Fixed detection conversion helpers to support coordinate-convention migration while preserving legacy inclusive defaults
- Fixed Azure tag mapping, anchor rounding, and line-zone smoothing to avoid incorrect or ghost detections
- Fixed video processing shutdown handling for timeout and full-queue cases
- Improved downloader, validator, documentation, and regression coverage for the shipped dataset, detection, annotator, image, and video behavior

---------

Co-authored-by: Codex <codex@openai.com>
Co-authored-by: pre-commit-ci[bot] <66853113+pre-commit-ci[bot]@users.noreply.github.com>
4.0 KiB
4.0 KiB
comments
| comments |
|---|
| true |
Annotators
=== "VertexAnnotator"
```python
import supervision as sv
image = ...
key_points = sv.KeyPoints(...)
vertex_annotator = sv.VertexAnnotator(
color=sv.Color.GREEN,
radius=10,
)
annotated_frame = vertex_annotator.annotate(
scene=image.copy(),
key_points=key_points,
)
```
<div class="result" markdown>
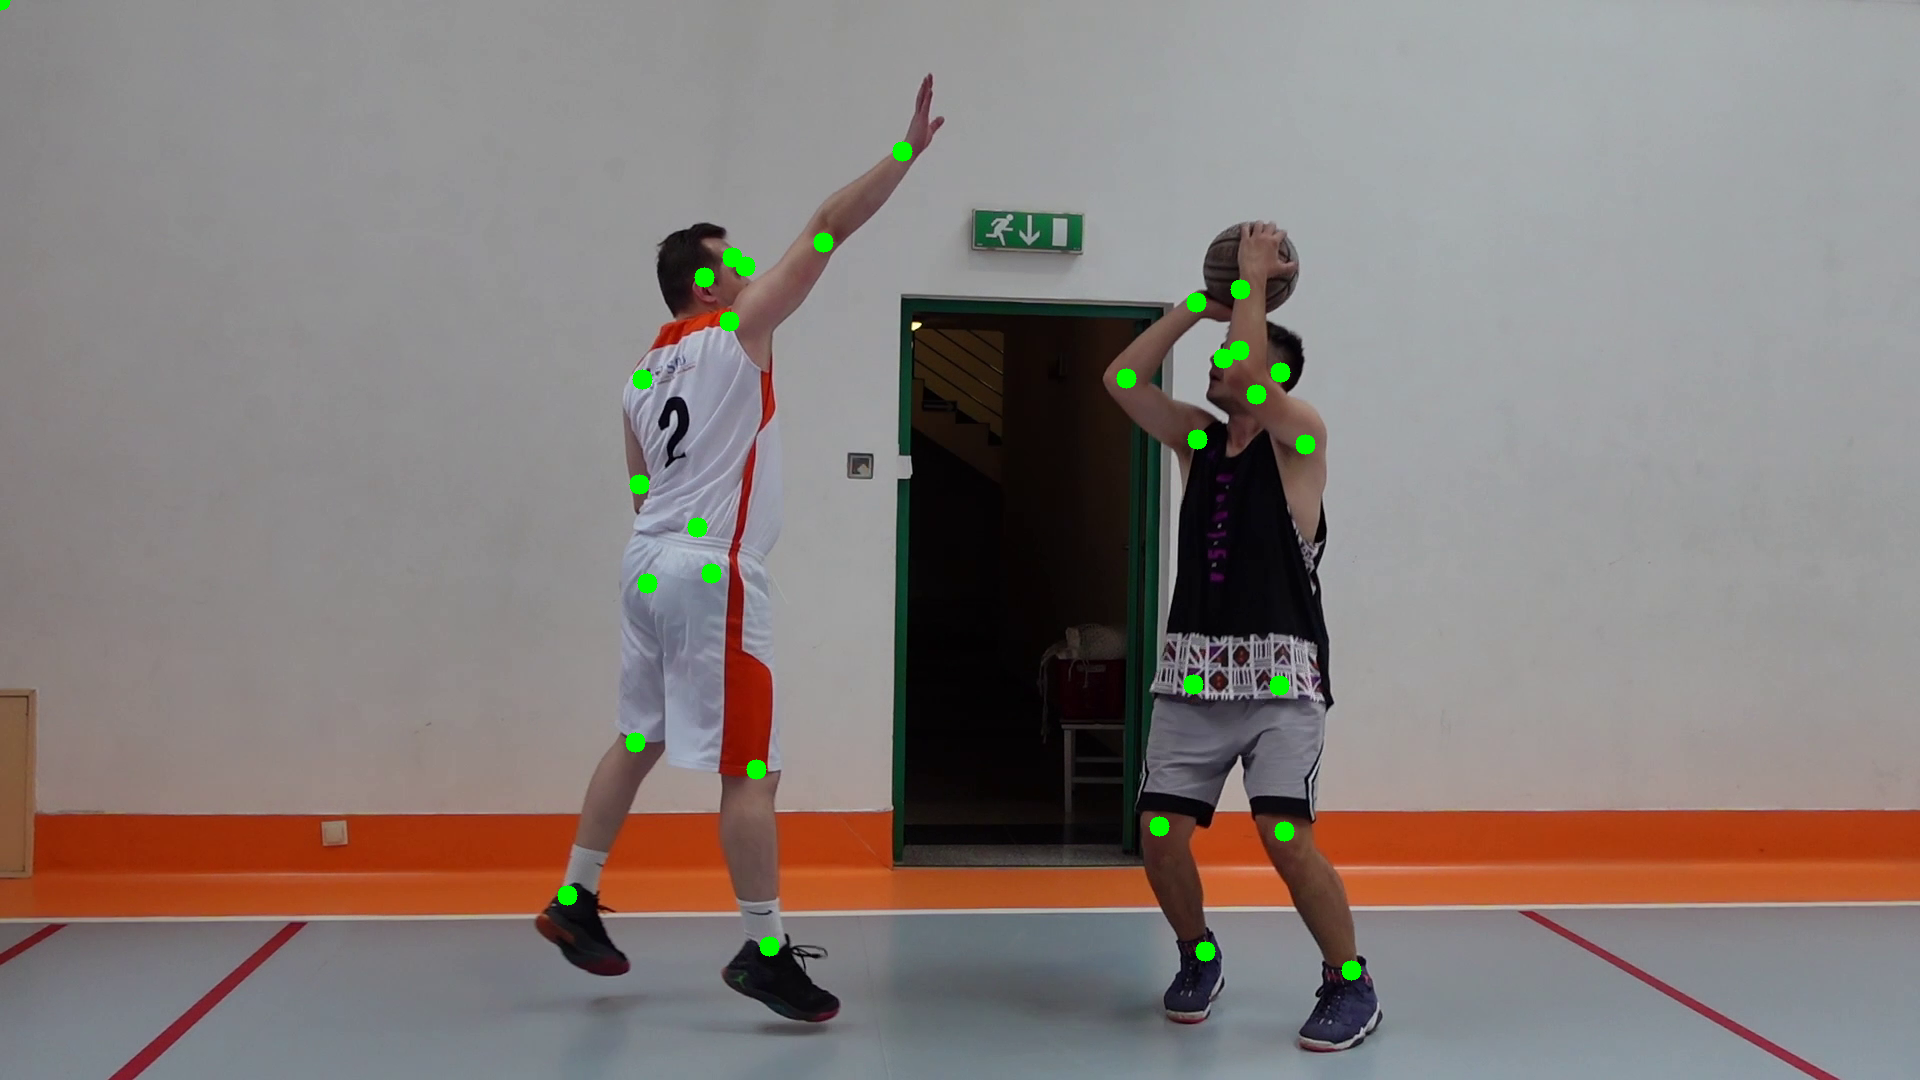{ align=center width="800" }
</div>
=== "EdgeAnnotator"
```python
import supervision as sv
image = ...
key_points = sv.KeyPoints(...)
edge_annotator = sv.EdgeAnnotator(
color=sv.Color.GREEN,
thickness=5,
)
annotated_frame = edge_annotator.annotate(
scene=image.copy(),
key_points=key_points,
)
```
<div class="result" markdown>
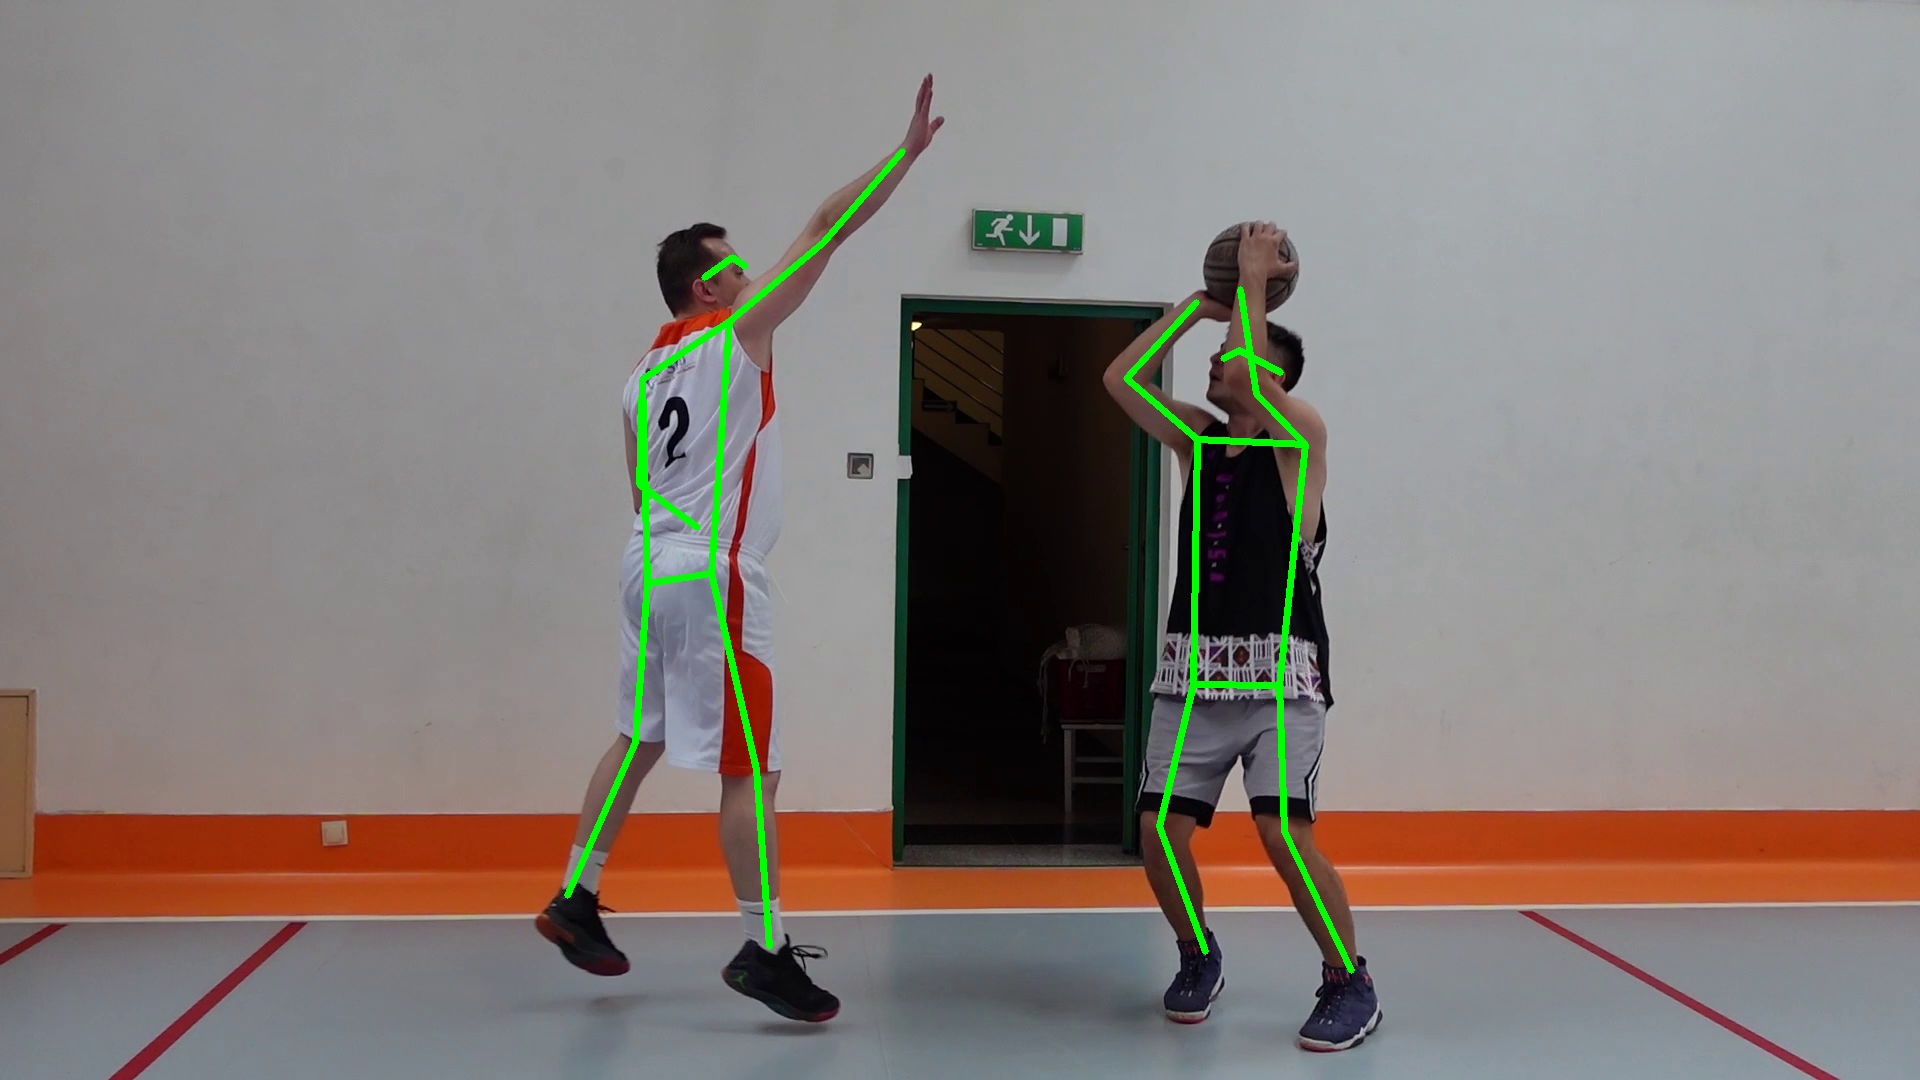{ align=center width="800" }
</div>
=== "VertexLabelAnnotator"
```python
import supervision as sv
image = ...
key_points = sv.KeyPoints(...)
vertex_label_annotator = sv.VertexLabelAnnotator(
color=sv.Color.GREEN,
text_color=sv.Color.BLACK,
border_radius=5,
)
annotated_frame = vertex_label_annotator.annotate(
scene=image.copy(),
key_points=key_points,
)
```
<div class="result" markdown>
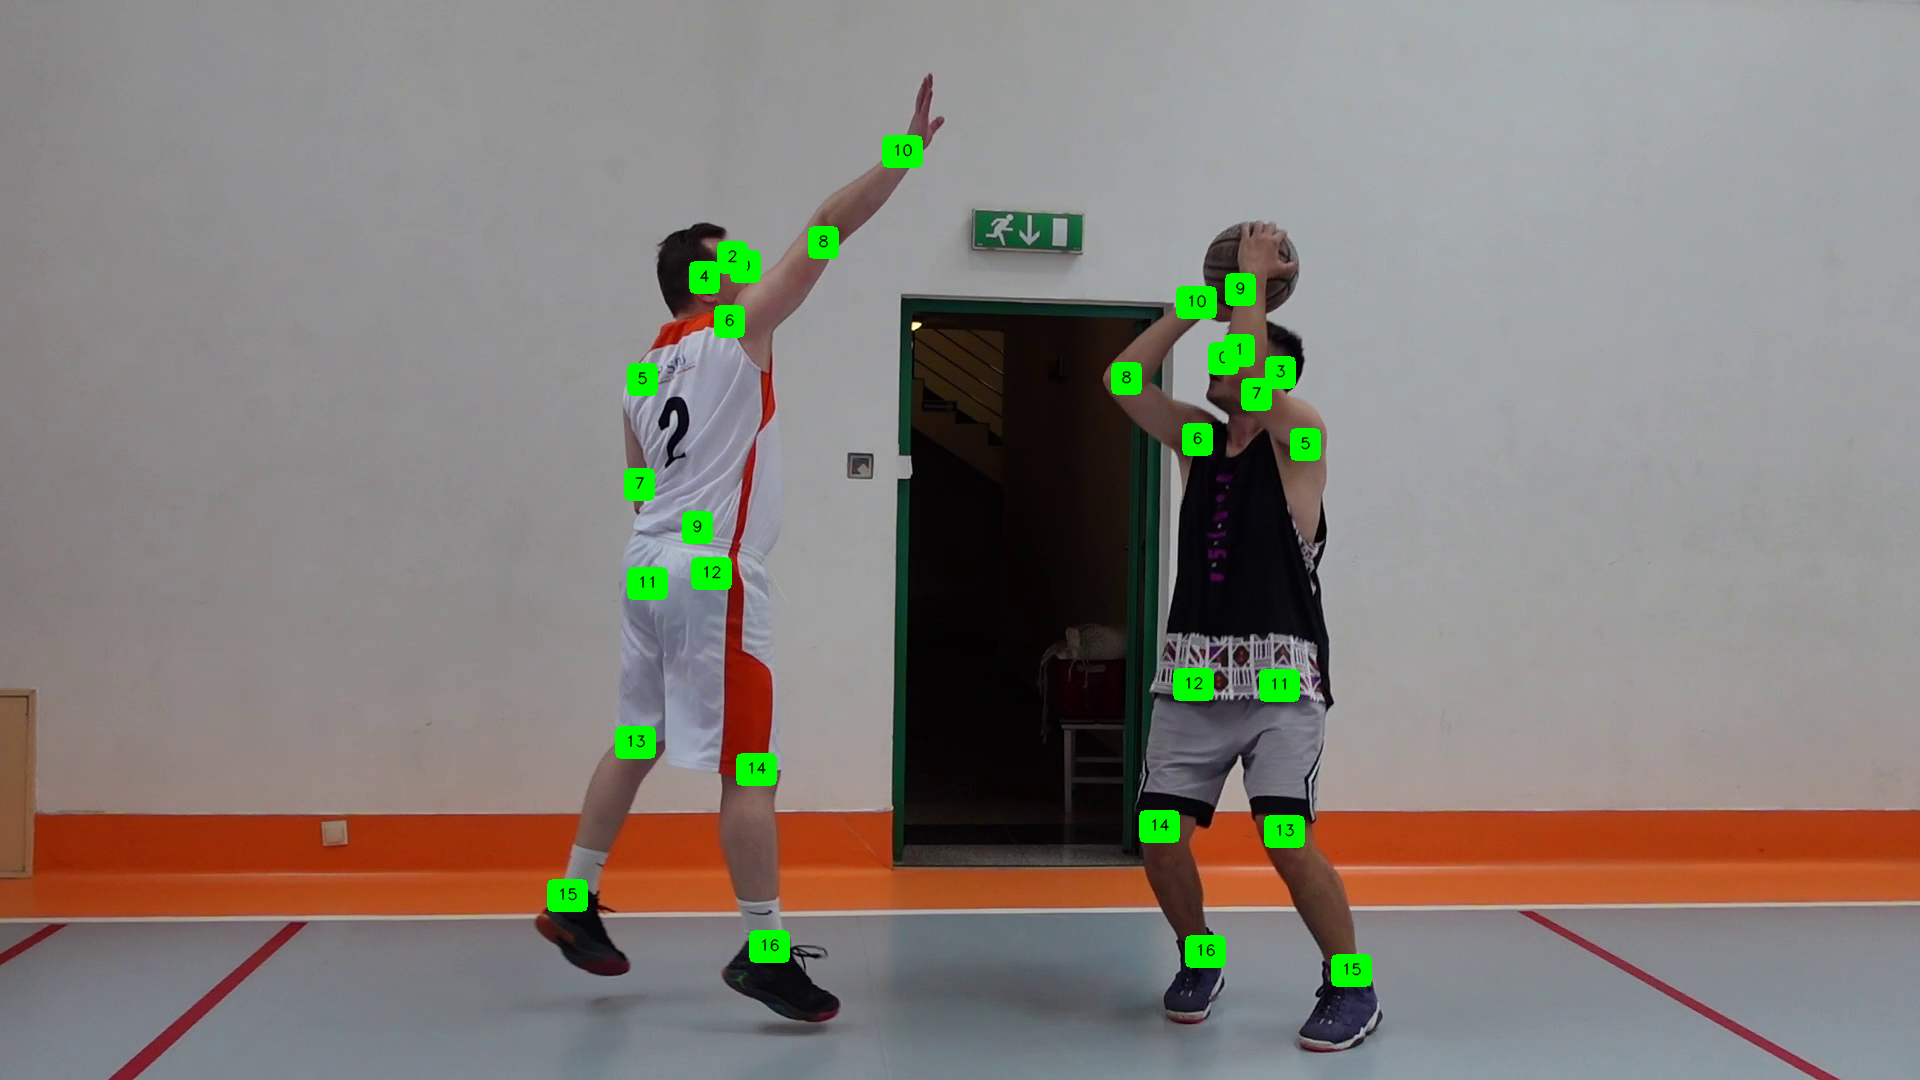{ align=center width="800" }
</div>
=== "VertexEllipseAreaAnnotator"
```python
import supervision as sv

image = ...
key_points = sv.KeyPoints(...)

area_annotator = sv.VertexEllipseAreaAnnotator(
    color=sv.Color.GREEN,
    sigma=2.0,
)
annotated_frame = area_annotator.annotate(
    scene=image.copy(),
    key_points=key_points,
)
```

`sv.VertexEllipseAnnotator` is a compatibility alias for `sv.VertexEllipseAreaAnnotator`.
=== "VertexEllipseOutlineAnnotator"
```python
import supervision as sv

image = ...
key_points = sv.KeyPoints(...)

outline_annotator = sv.VertexEllipseOutlineAnnotator(
    color=sv.Color.GREEN,
    sigma=2.0,
    thickness=2,
)
annotated_frame = outline_annotator.annotate(
    scene=image.copy(),
    key_points=key_points,
)
```
=== "VertexEllipseHaloAnnotator"
```python
import supervision as sv

image = ...
key_points = sv.KeyPoints(...)

halo_annotator = sv.VertexEllipseHaloAnnotator(
    color=sv.Color.GREEN,
    sigma=2.0,
)
annotated_frame = halo_annotator.annotate(
    scene=image.copy(),
    key_points=key_points,
)
```
:::supervision.key_points.annotators.VertexAnnotator
:::supervision.key_points.annotators.EdgeAnnotator
:::supervision.key_points.annotators.VertexLabelAnnotator
:::supervision.key_points.annotators.VertexEllipseAreaAnnotator
:::supervision.key_points.annotators.VertexEllipseOutlineAnnotator
:::supervision.key_points.annotators.VertexEllipseHaloAnnotator